Mounting an HTC VIVE Tracker 3.0 on Wuji Glove
CombinationWuji GloveHTC VIVE Tracker 3.0
The glove captures finger shape and the tracker gives the hand position in space. Mounting options, parts, steps and frame alignment, with diagrams.
What you need
Make sure you have everything before you start.
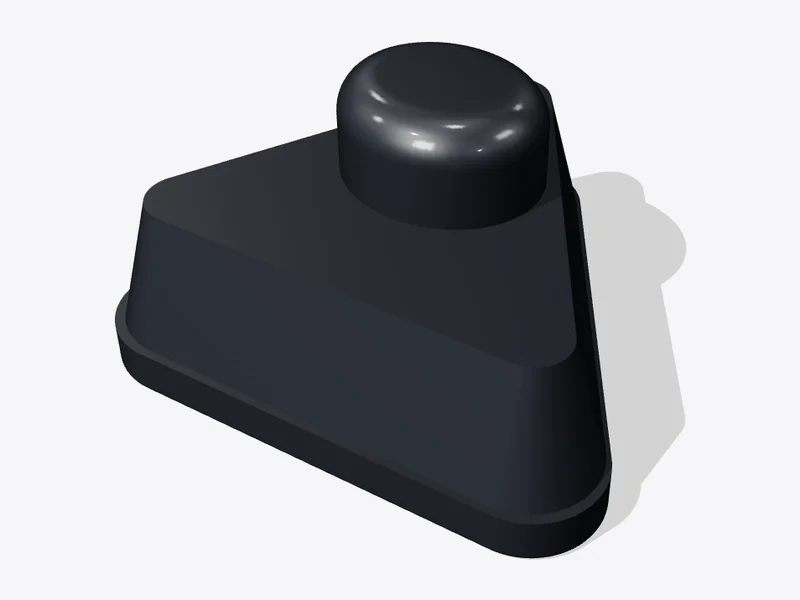
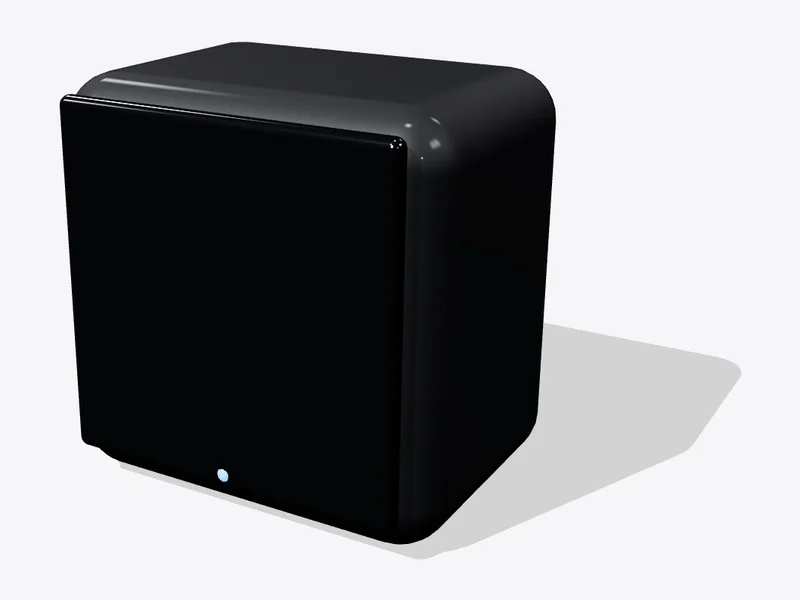
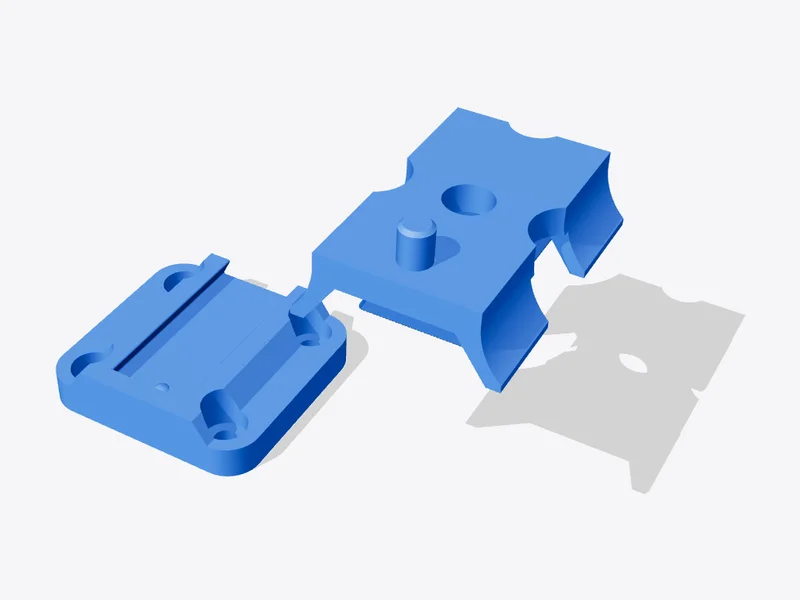
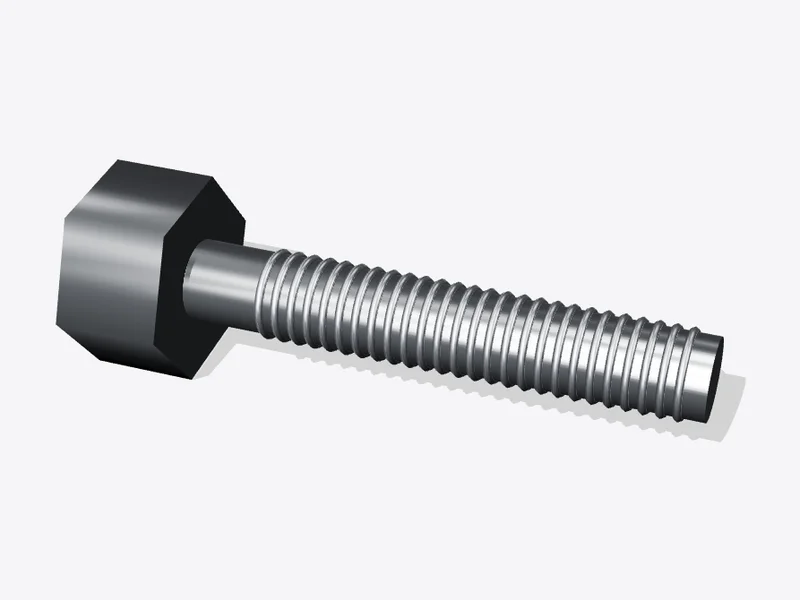
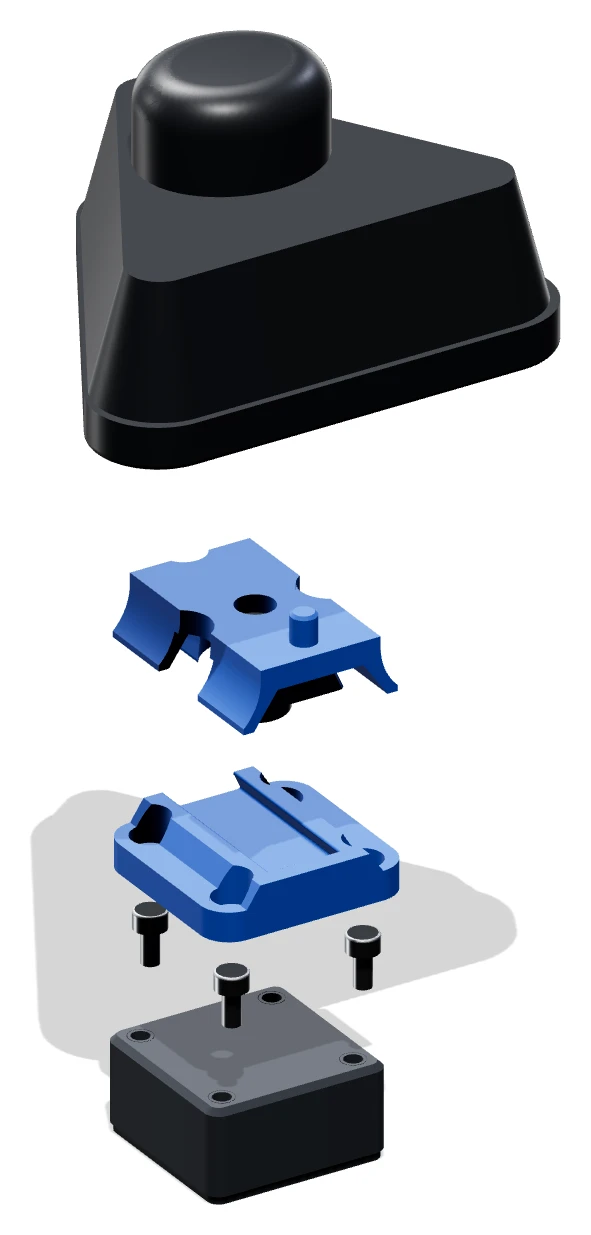
BuyHTC VIVE Tracker 3.0with dongle & USB cable BuySteamVR Base Station 2.0 (2 recommended) 3D print (files provided)Mounting block & base Buy1/4" bolt × 1 (3/8")plastic is better for accuracy IncludedWuji Glove (mounting plate) You provide3D printer (PLA / PETG) Steps
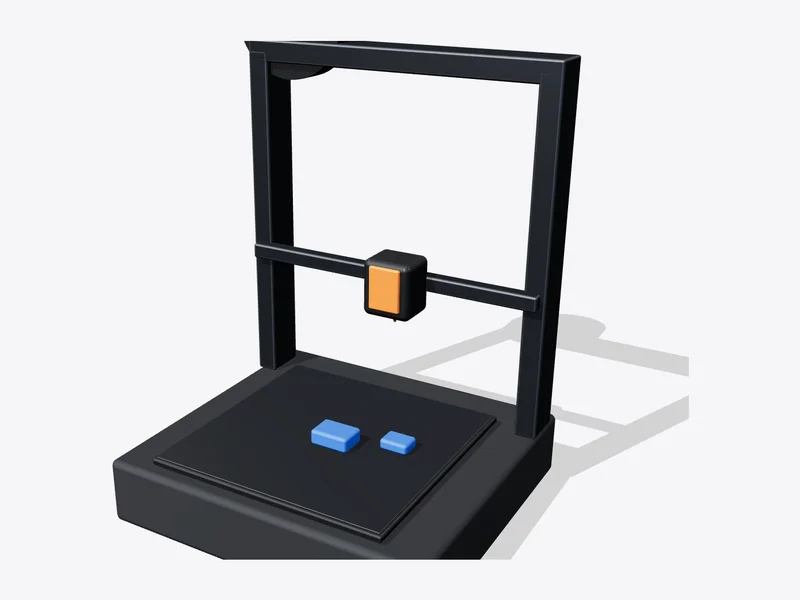
1Print the parts
Pin facing up, with supports.
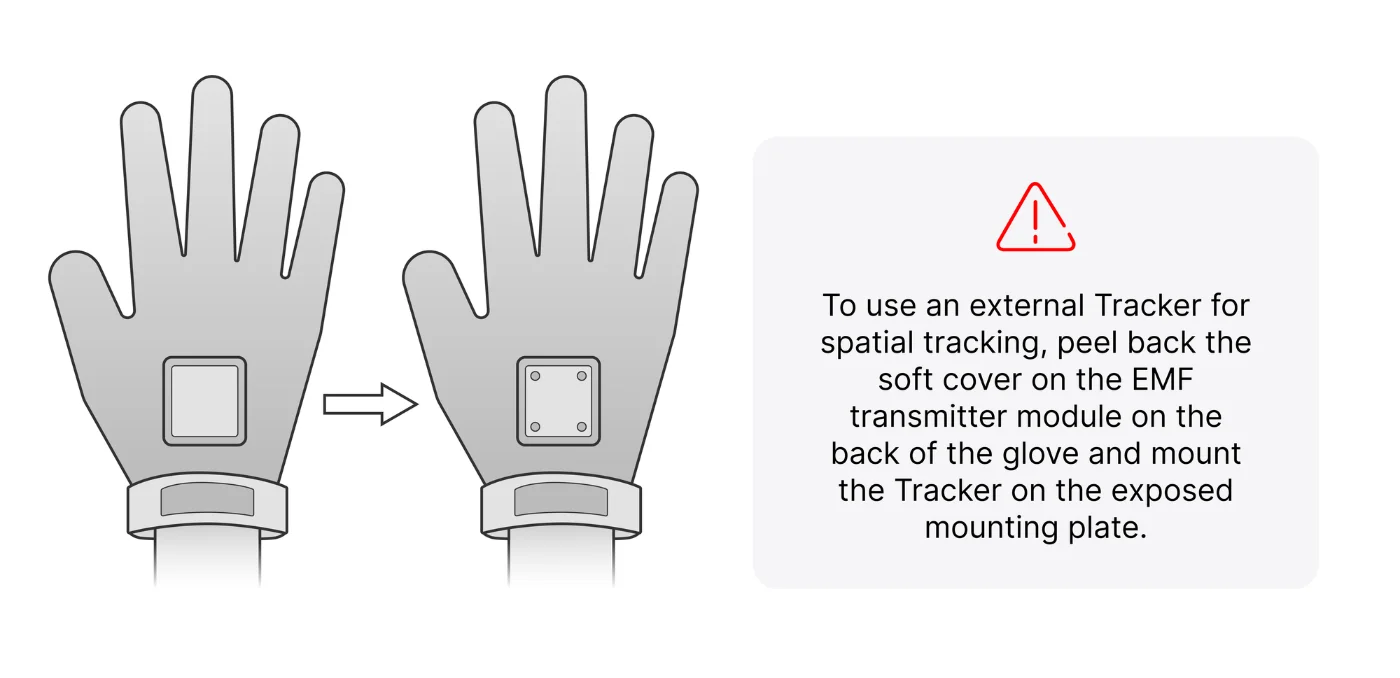
2Lift the cover
Under the soft cover: four M3 holes.
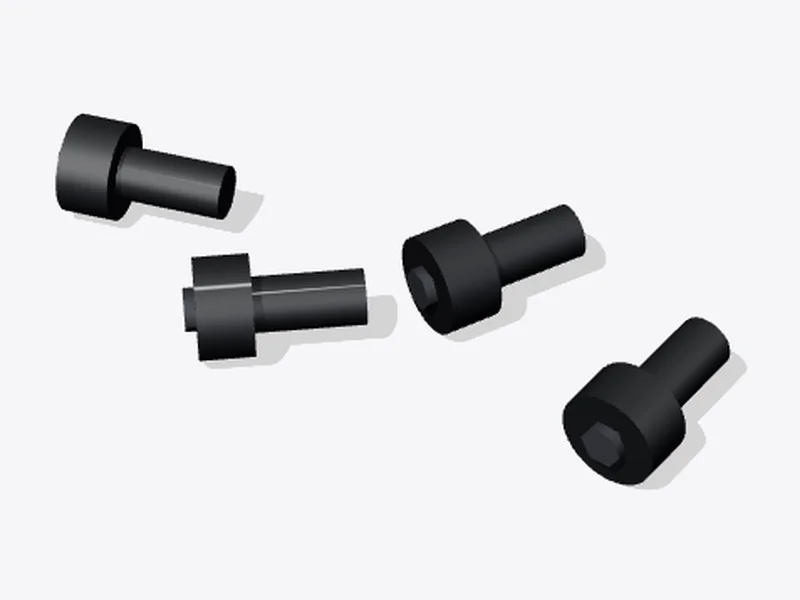
3Screw on the base
Four M3 bolts, diagonal order.
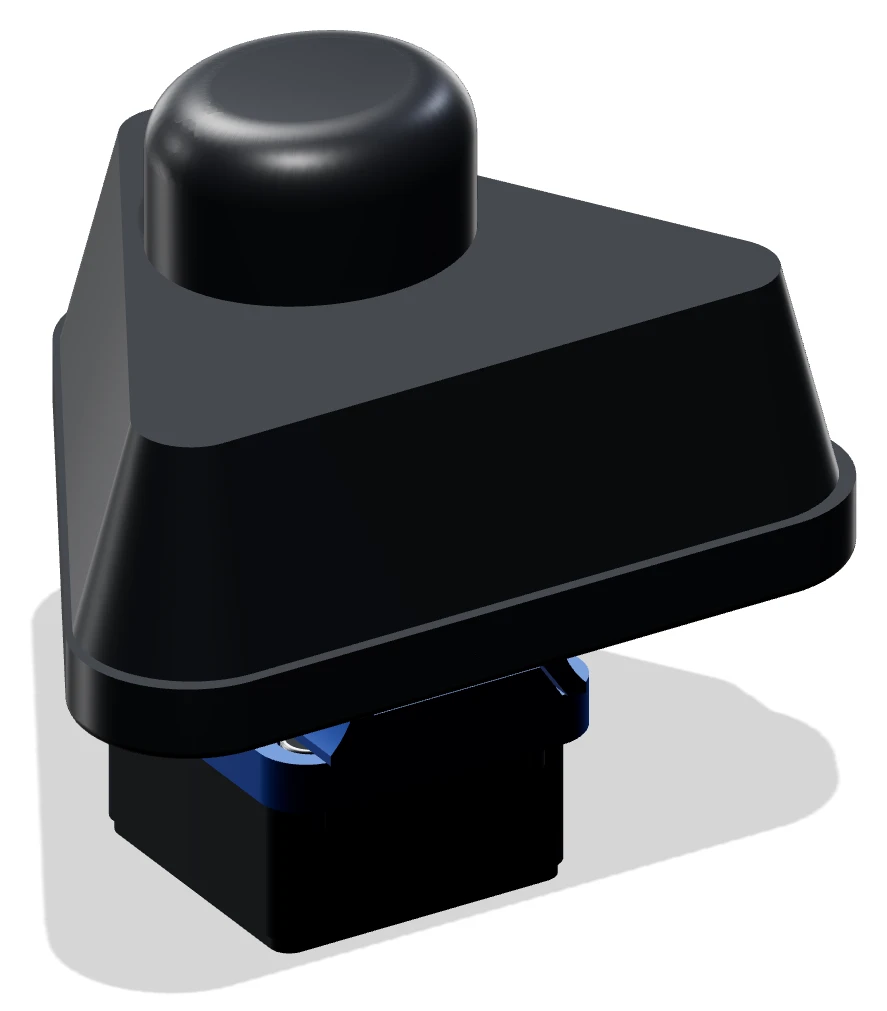
4Attach the tracker
1/4" bolt, align the pin.
5Keep the dome clear
Make sure fingers do not cover the sensor dome.
6Pair and verify
Pair in SteamVR, check fingers in Wuji Studio.
!Keep metal ≥ 3 cm from the fingertip receivers. Compare fingertip accuracy before and after mounting; use a plastic bolt if needed.
✓
DoneDone when the tracker is tracked and finger data is normal.
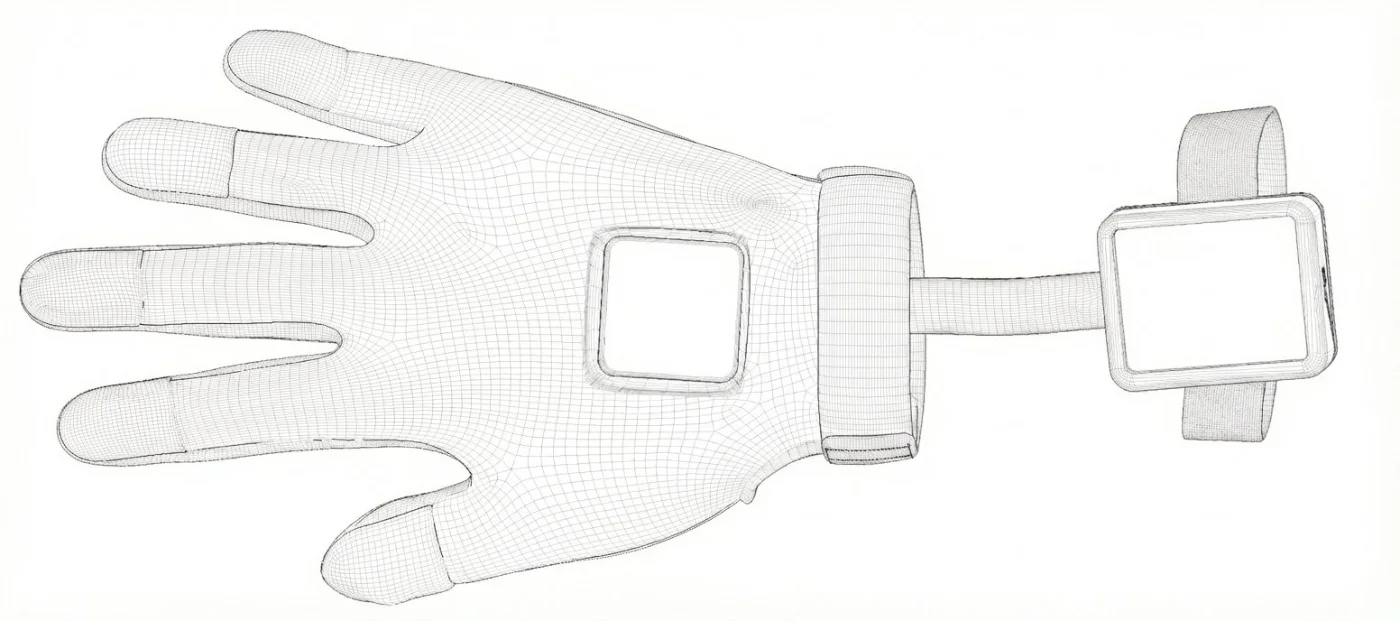
Wrist option
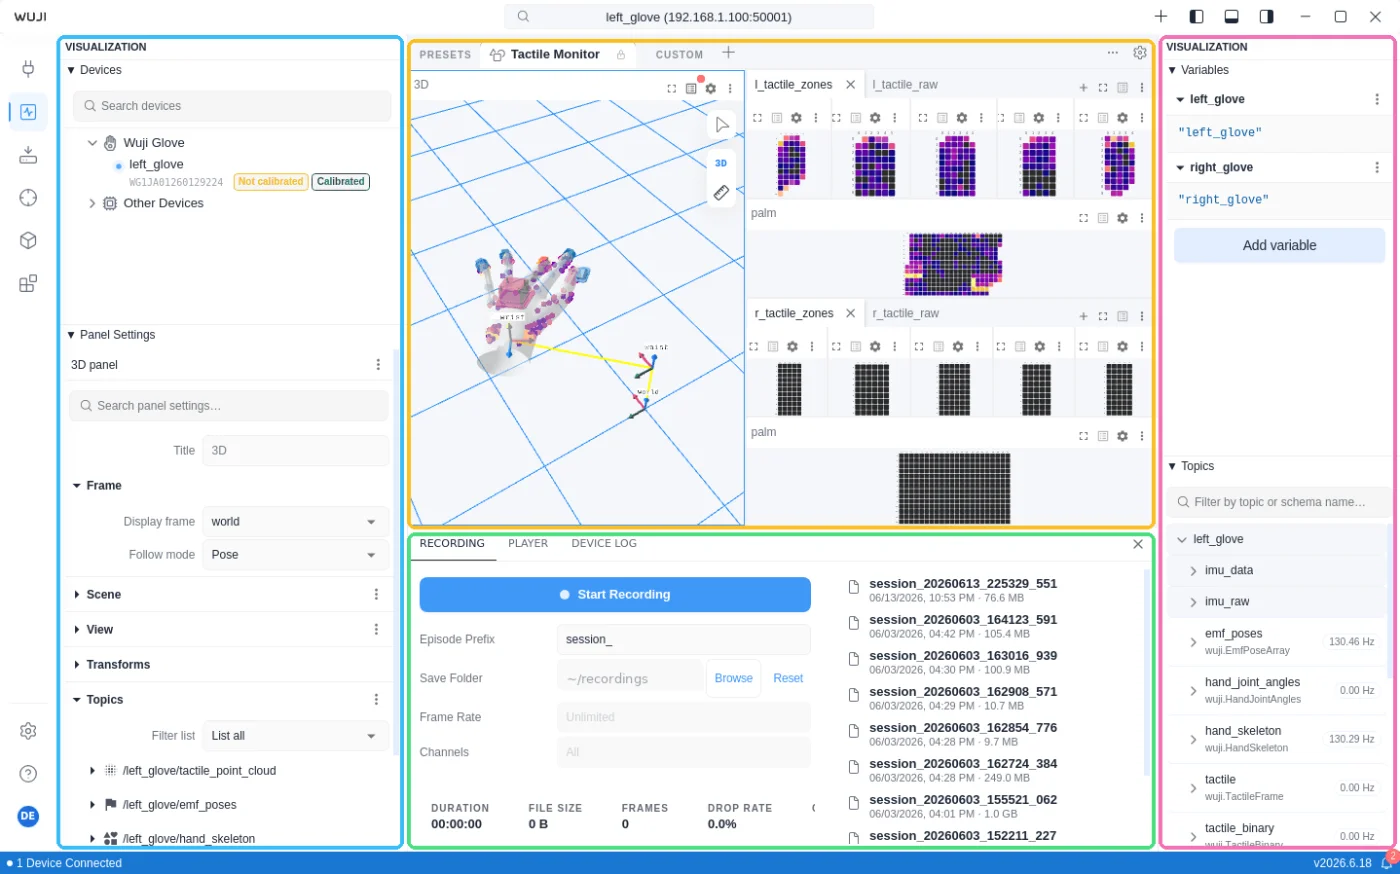
Two mounting positions (right hand, viewed from the back)Aligning frames
Combining frames: the tracker gives the wrist position in space, the glove gives the finger shapeRelated documentation
 Documentation
 2
 3
 4
 →Hand poseworld