 Documentation
BXI Elf3 with multi-finger hands and PICO teleoperation
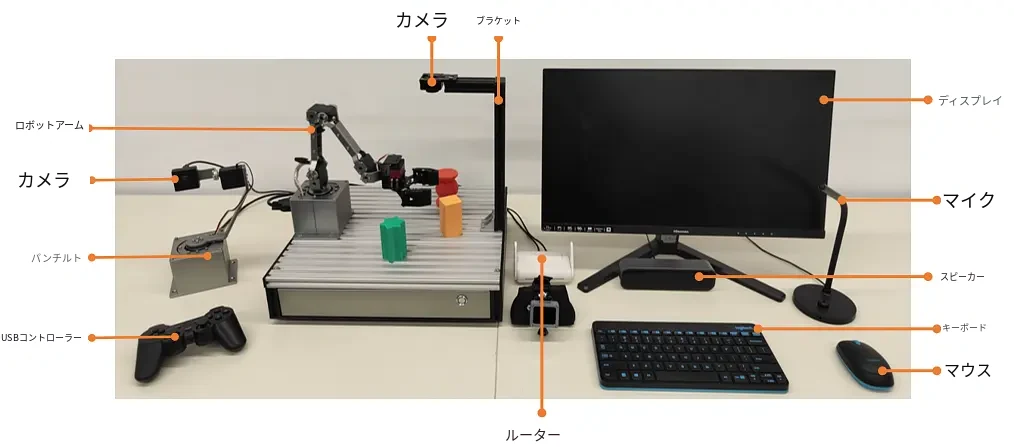
Hand wiring (CANFD) and the upper-body teleoperation setup with PICO.
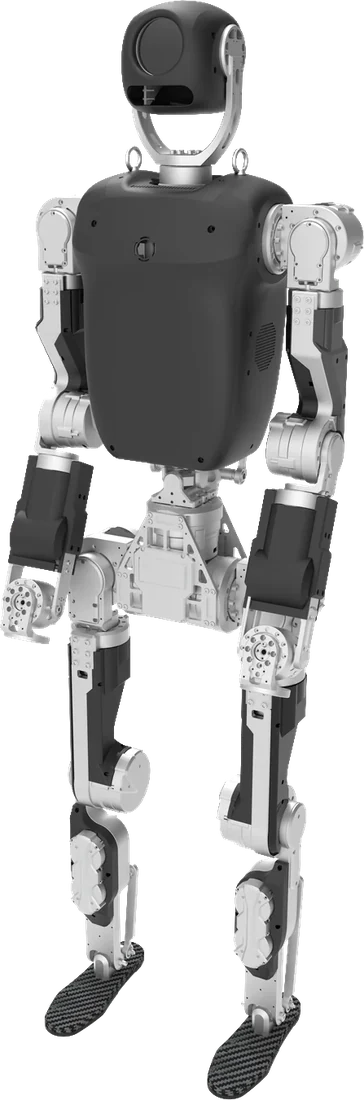
What you need
Make sure you have everything before you start.
Steps
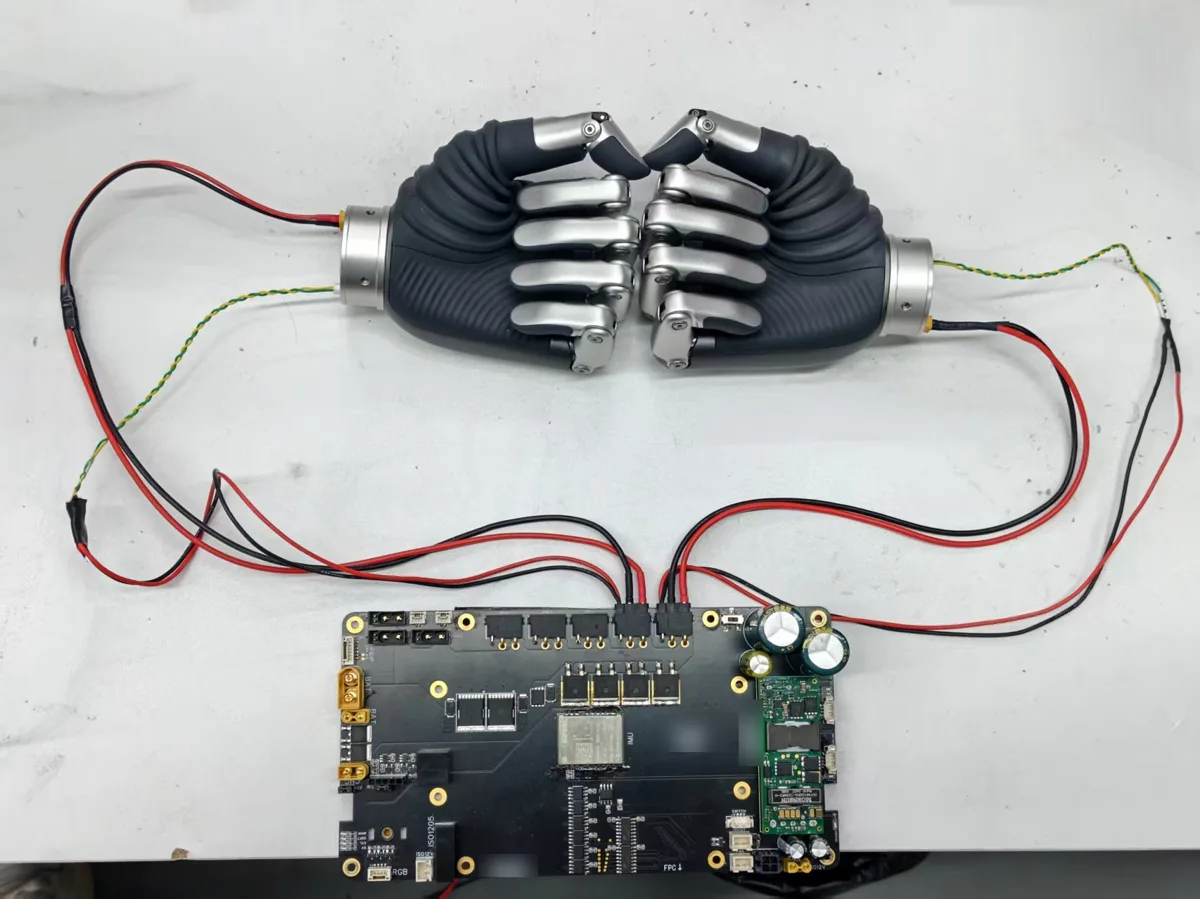
- 58 VCheck the rated voltageother versions may be damaged2
Check voltage
Only hands rated for the robot supply.
- PICOXRoboToolkit
 →BXI Elf3teleop Mod
 →HandsCAN5 / CAN6
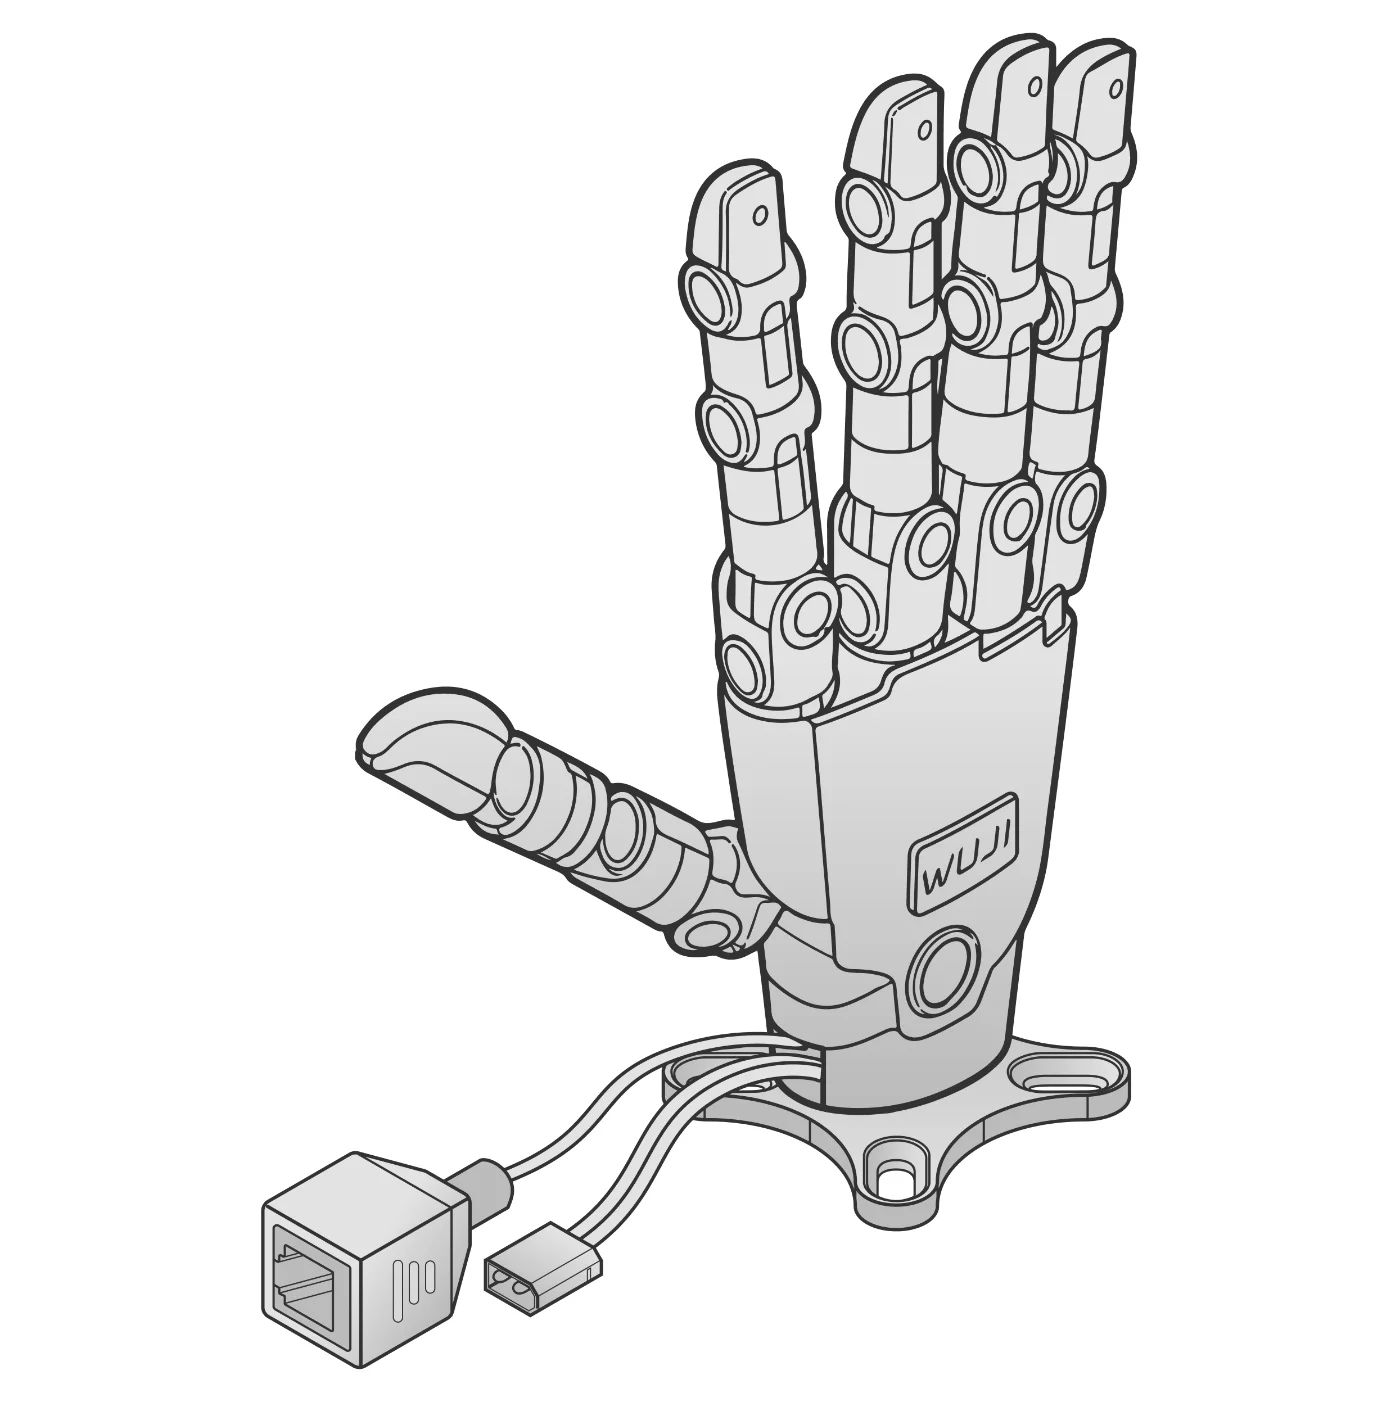
 4
Trackers on the legs
Wear on both legs and calibrate.
- 5
Connect and move
Connect to the robot LAN IP. Simulation first; on the real robot use a gantry and move slowly.
✓
DoneDone when the upper body and hands follow you.