 Documentation
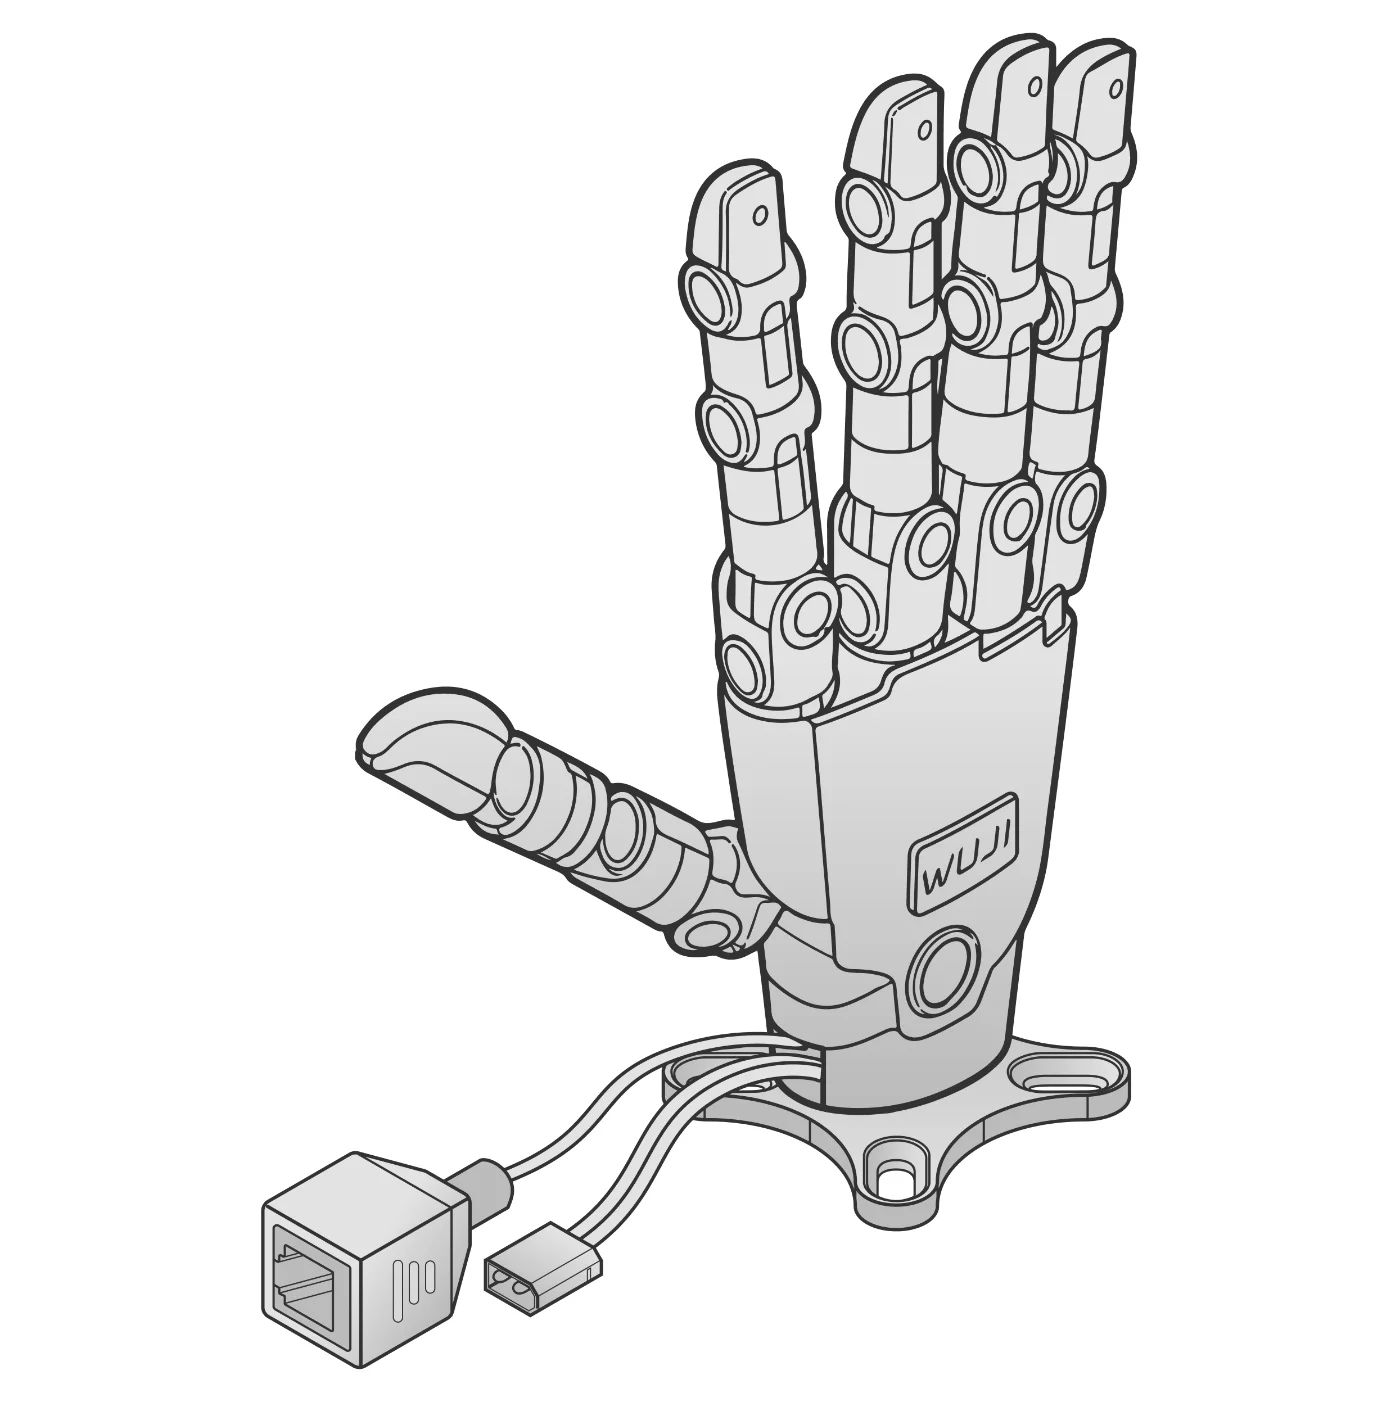
Mounting Wuji Hand 2 on a third-party robot arm
Matching the flange, wiring 12 V power and Ethernet, and splitting control between arm and hand.
What you need
Make sure you have everything before you start.
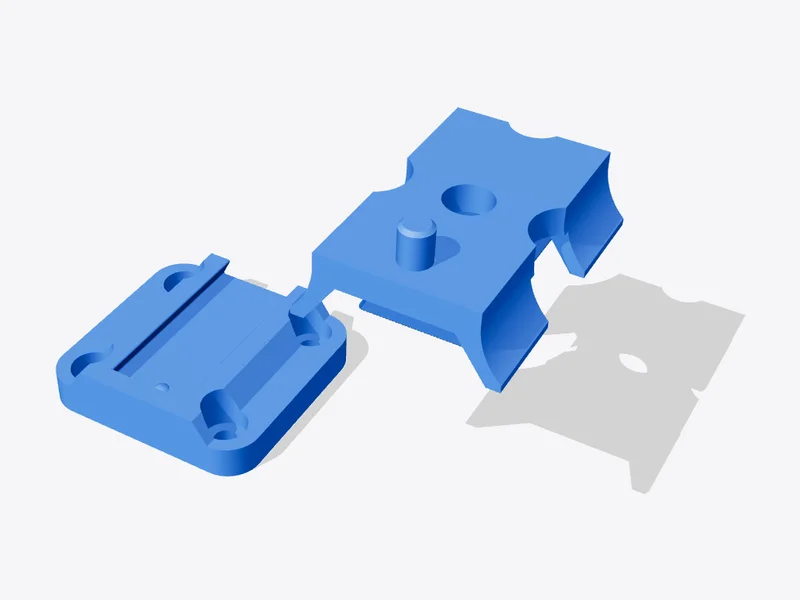
Steps
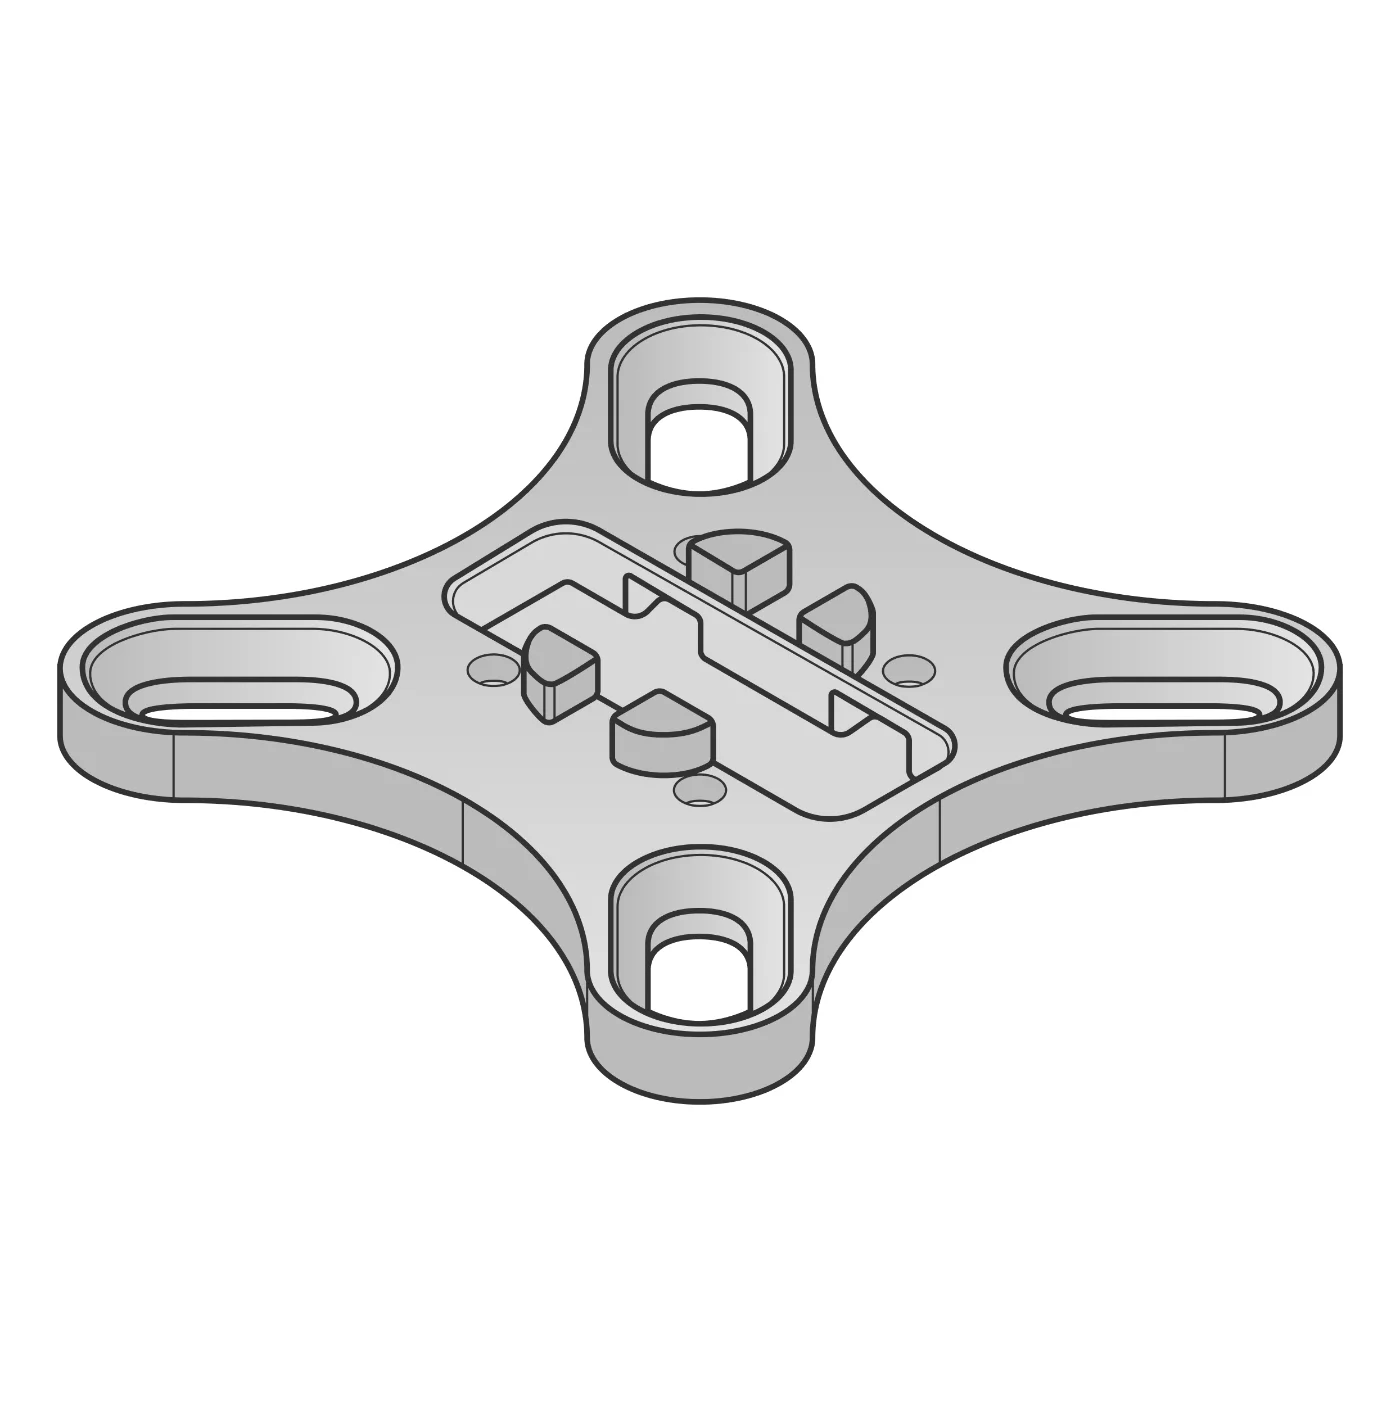
Flange 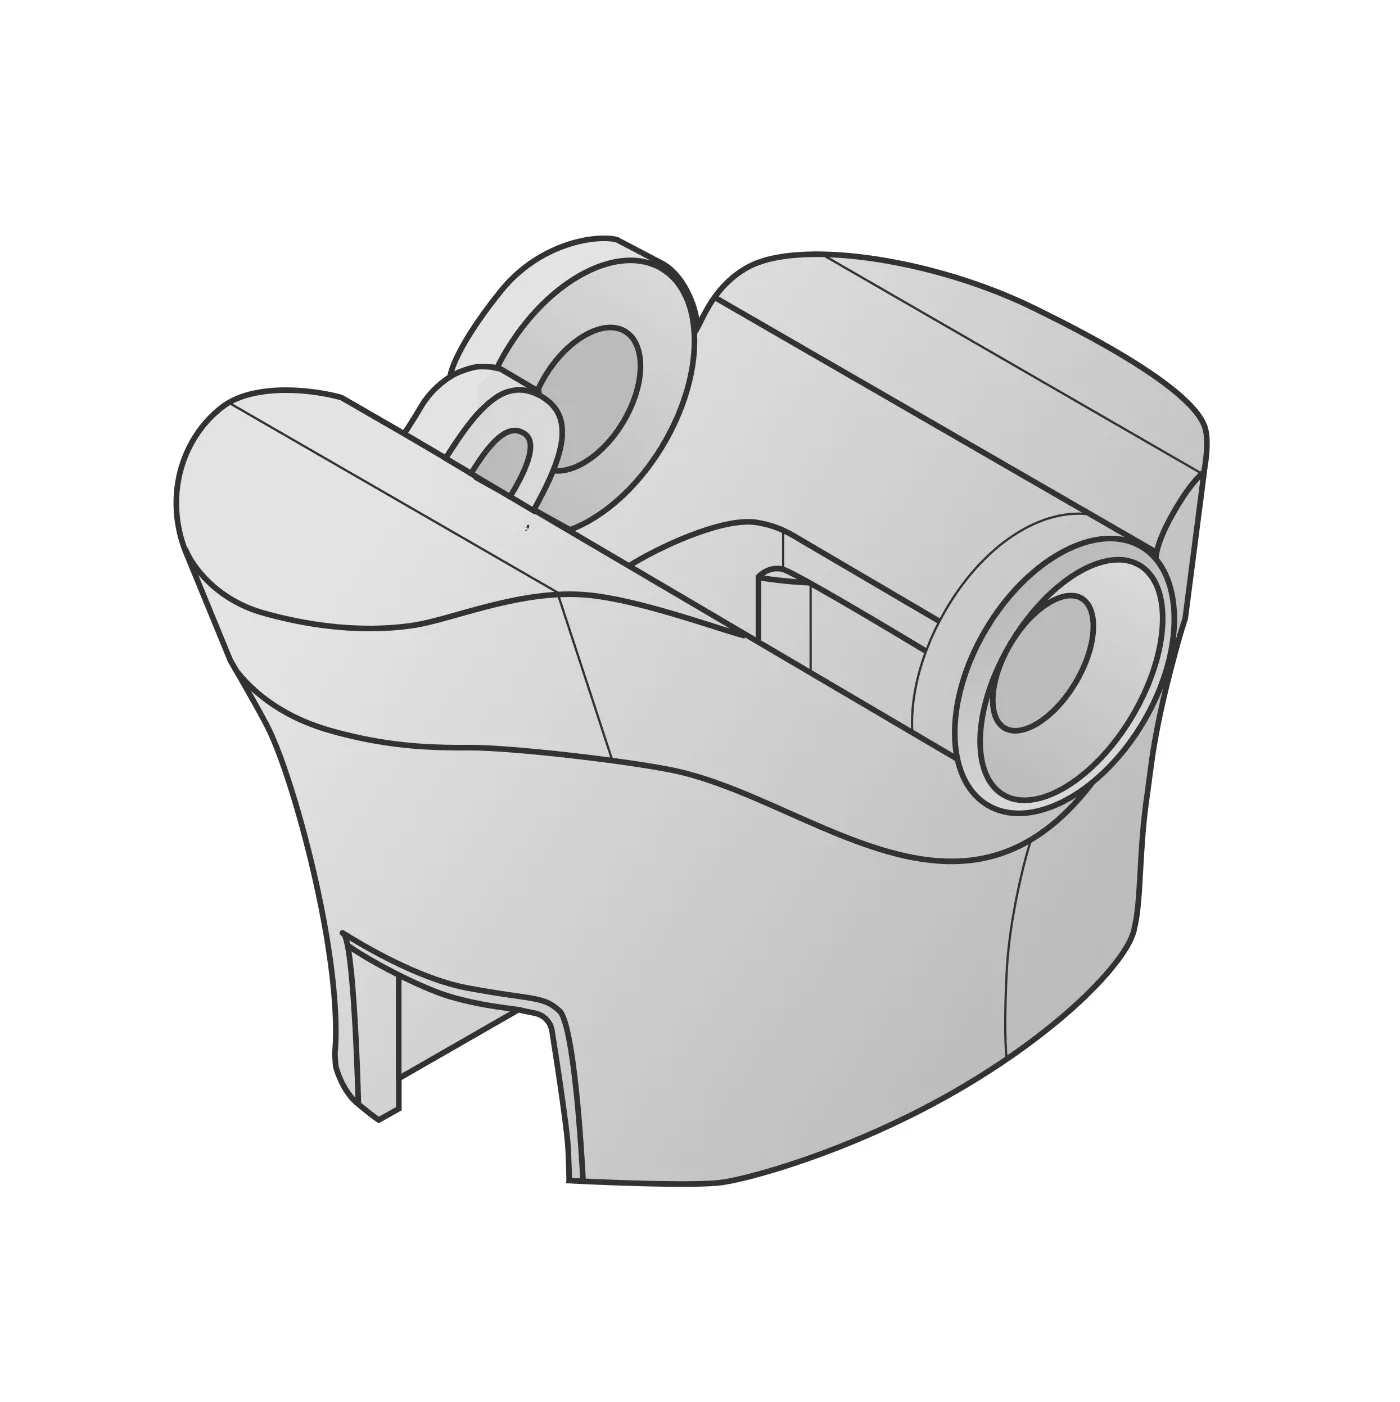
Mount Hand 2 - 800 gHand mass+ adapter + payload2
Check the payload
Leave margin in the arm payload.
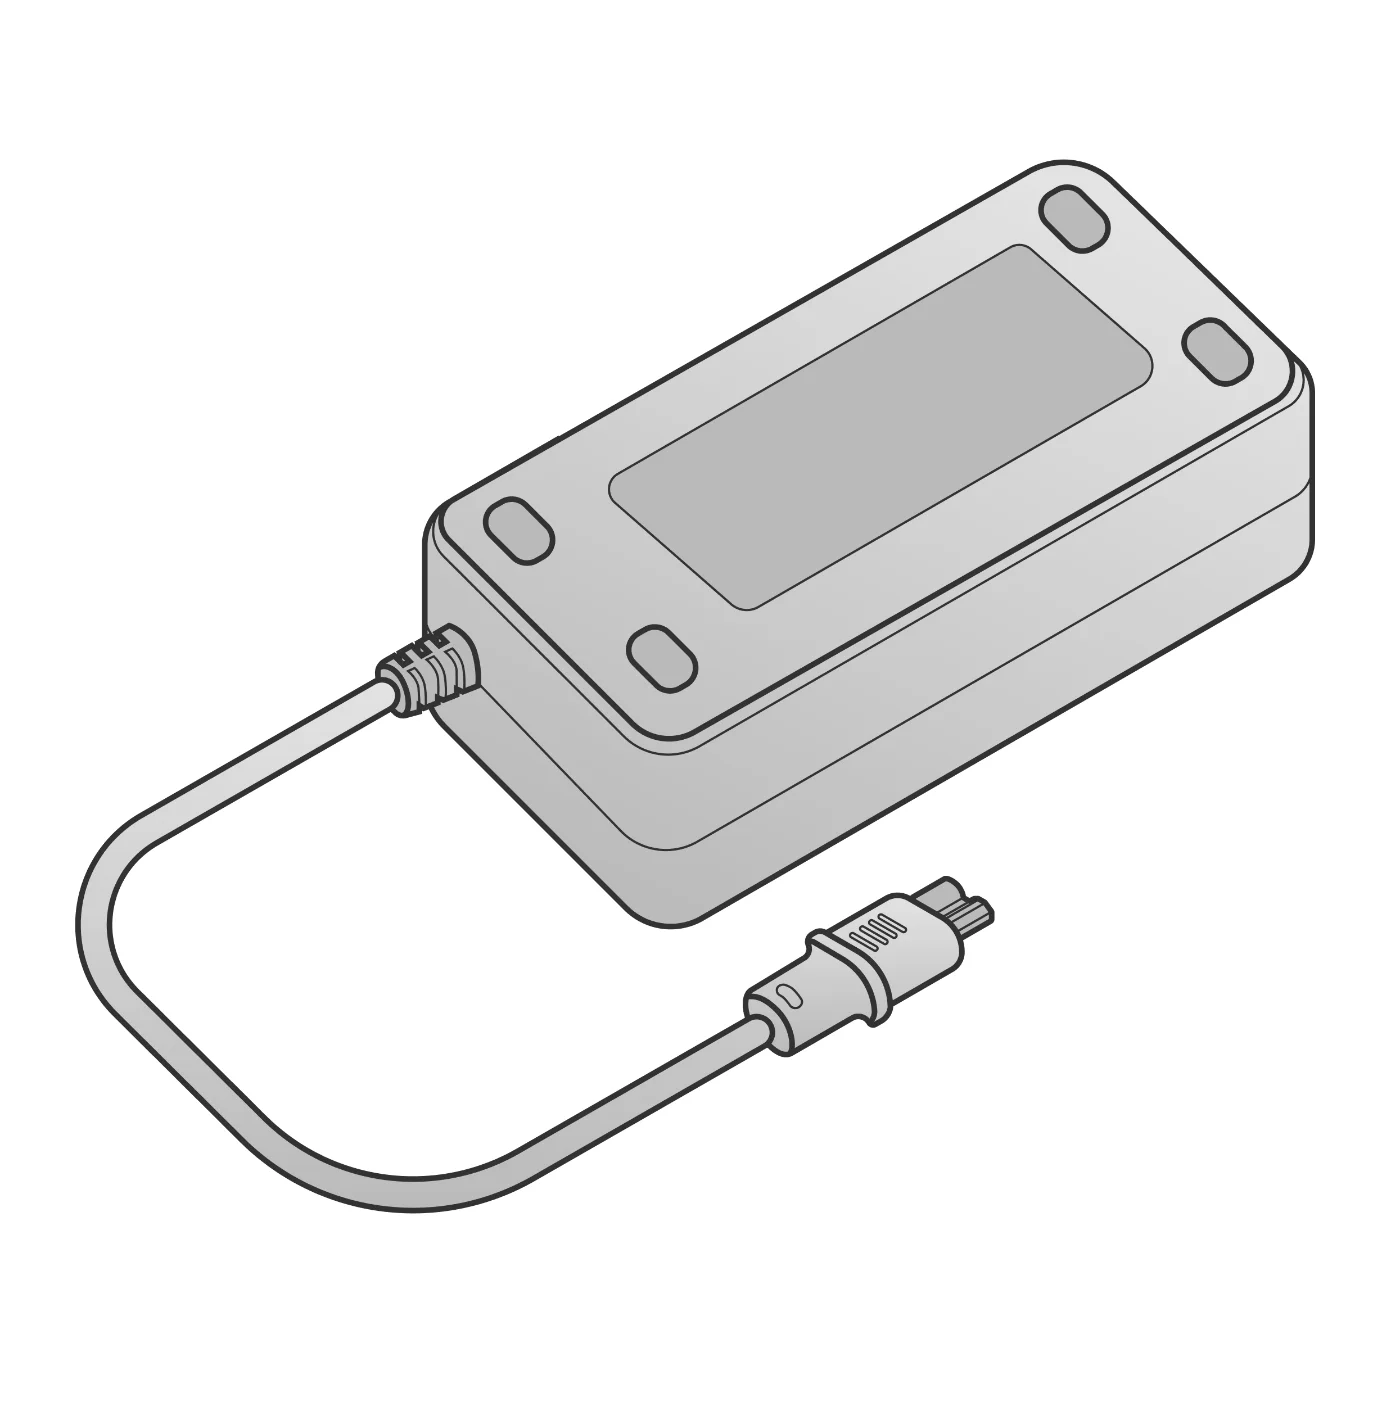
- 12 V200 W+
 →Hand 2XT303
Wire 12 V
A dedicated 12 V, not the arm 24 V. Hand-side XT30 first.
- PC192.168.1.50
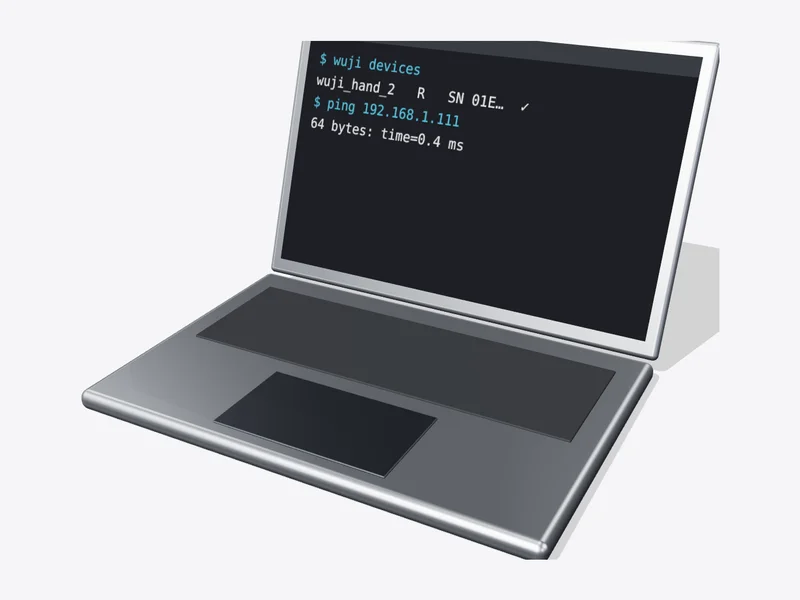 Hand 2192.168.1.111Armown network4
Network
Keep the hand and arm IPs separate.
- PCyour app→Armarm SDK→Hand 2Wuji SDK
✓
DoneDone when the hand runs stably while the arm moves. Set the payload on force-controlled arms.