 Documentation
BXI Elf3
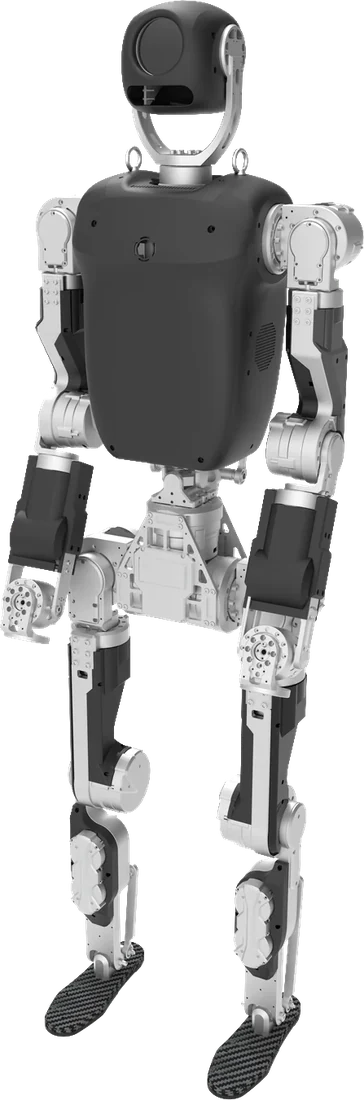
A highly dynamic humanoid with 31 DoF, standing 145 cm tall. Run, jump, dance — field-proven motion performance for research and development.
Exterior Design
A refined design combining human-like proportions with aluminum and carbon components. With 31 DoF across the whole body, it naturally expresses a wide range of postures — standing, crouching and sitting.
Highly dynamic motion, proven in the real world.
Motion control validated not only in simulation but in real competitions and field use. The robot reliably performs highly dynamic movements such as running, jumping, dancing and climbing over obstacles.
Joint Modules Built for Humanoids
The BXI-50/70/85 hollow planetary series. Just three motor types are enough to build a humanoid with more than 30 DoF, greatly reducing design, manufacturing and maintenance costs.
| Item | BXI-50 | BXI-70 | BXI-85 |
|---|---|---|---|
| Rated torque | 7 N·m | 15 N·m | 40 N·m |
| Peak torque | 25 N·m | 50 N·m | 150 N·m |
| Peak phase current | 30 A(rms) | 60 A(rms) | 90 A(rms) |
| Outer diameter × height | 64 × 65.5 mm | 81 × 66.5 mm | 99 × 71.5 mm |
| Hollow diameter | 6 mm | 9 mm | 10 mm |
| Weight | 0.5 kg | 0.8 kg | 1.4 kg |
| Common specifications | Rated voltage 24–48 V / no-load speed 200 rpm / rated speed 100 rpm / gear ratio 19.5 / cross-roller bearing / dual encoders (motor side: magnetic, output side: inductive) / MIT protocol with hybrid torque, position and velocity control / CAN, CAN FD (RS485 coming soon) |
Motion Control ("Cerebellum") Solution
Reinforcement-learning-based motion control enables highly dynamic whole-body movement. With a systematized pipeline from data to the real robot, it is ready for exhibitions and performances.
Automatic conversion of human motion into robot joint trajectories
Reinforcement learning in parallel simulation environments
Quality validation in high-fidelity simulation
Deploying the control policy to real hardware
- Reinforcement learning
- Whole-body motion tracking
- Sim2Sim validation
- Real-robot deployment
Main Applications
Combine with Hands and Bases
Combine HumansX Physical AI solutions to configure a robot for your application.