 Documentation
Packaging Instructions
This page explains how to pack the BXI Elf3 robot back into its shipping case. Before starting, make sure the case, foam inserts, hoist, and lifting strap are in good condition, and reserve enough space for the work.
Operation safety
- At least 2 people are recommended for the whole process. Keep the robot stable while lifting and lowering it.
- Lower the robot slowly into the case to avoid hitting the case or compressing the foam inserts incorrectly.
- Before closing the case, confirm that the lid can close naturally. Do not force the lid closed.
Preparation
| Item | Requirement |
|---|---|
| Personnel | At least 2 people are recommended |
| Lifting | Prepare the hoist and the robot lifting strap |
| Packing parts | Confirm that the case and all foam inserts are complete and identifiable |
| Accessories | Prepare the tablet, controller, charger, and leg foam inserts |
Process Overview
| Step | Goal | Key Check |
|---|---|---|
| 1 | Place the accessories and leg foam inserts | All accessories are in their corresponding slots |
| 2 | Lift the robot and lower it into the case | The rear handle aligns with the foam recess |
| 3 | Place the arm and elbow foam inserts | The arms are seated in the lower foam slots |
| 4 | Position the legs and finish packing | The toes face the slot edge, and the lid can close naturally |
Detailed Steps
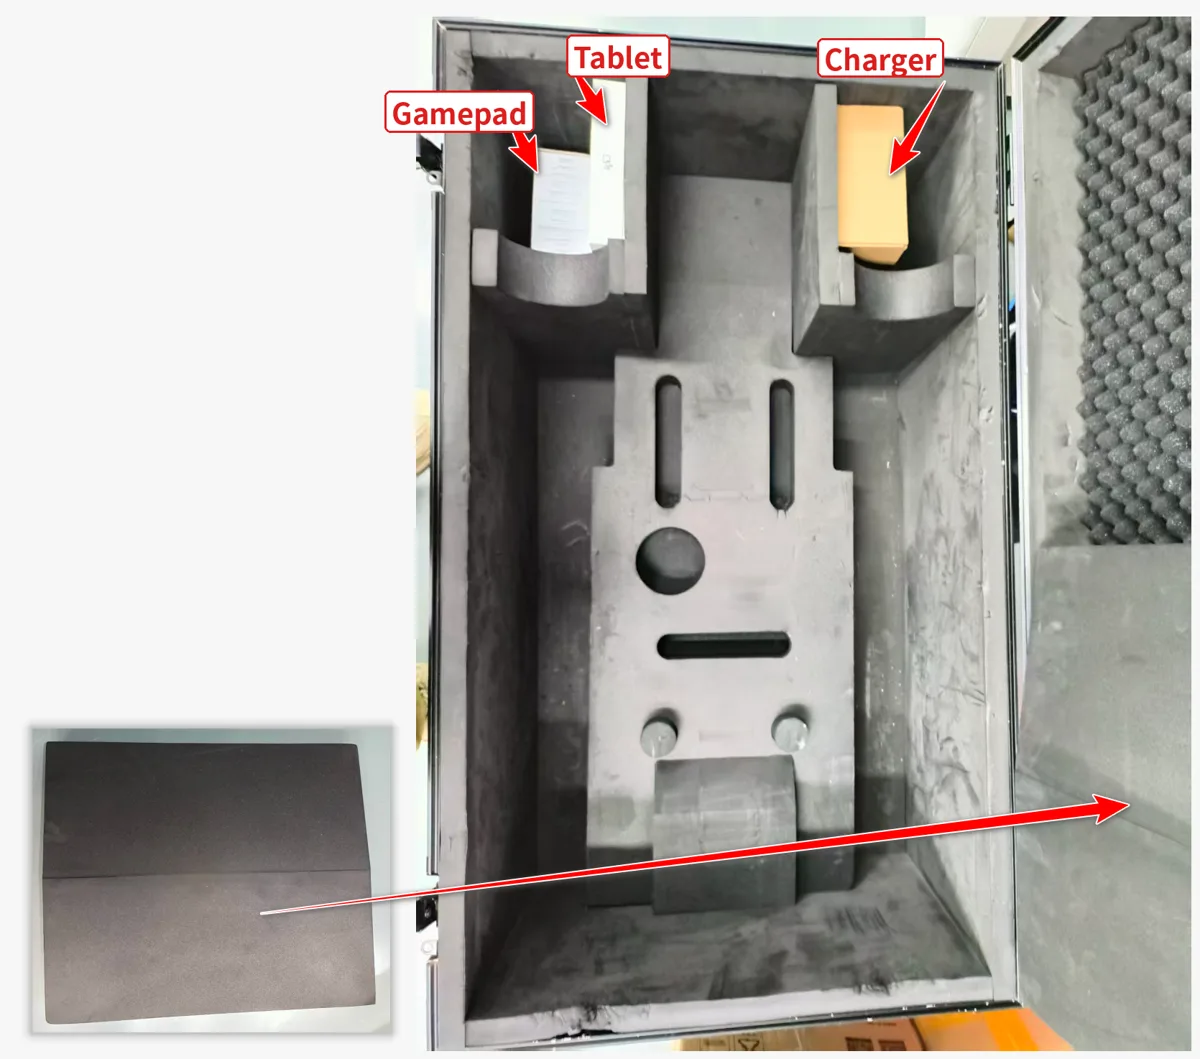
1. Place Accessories and Leg Foam Inserts
Operation
- Place the tablet, controller, and charger into their corresponding slots in the case.
- Place the leg foam inserts into their slots in the case.
Check
- Accessories should not sit higher than the surrounding foam surface.
- The leg foam inserts should be in the correct orientation for their slots.
2. Lift the Robot and Lower It Into the Case
Operation
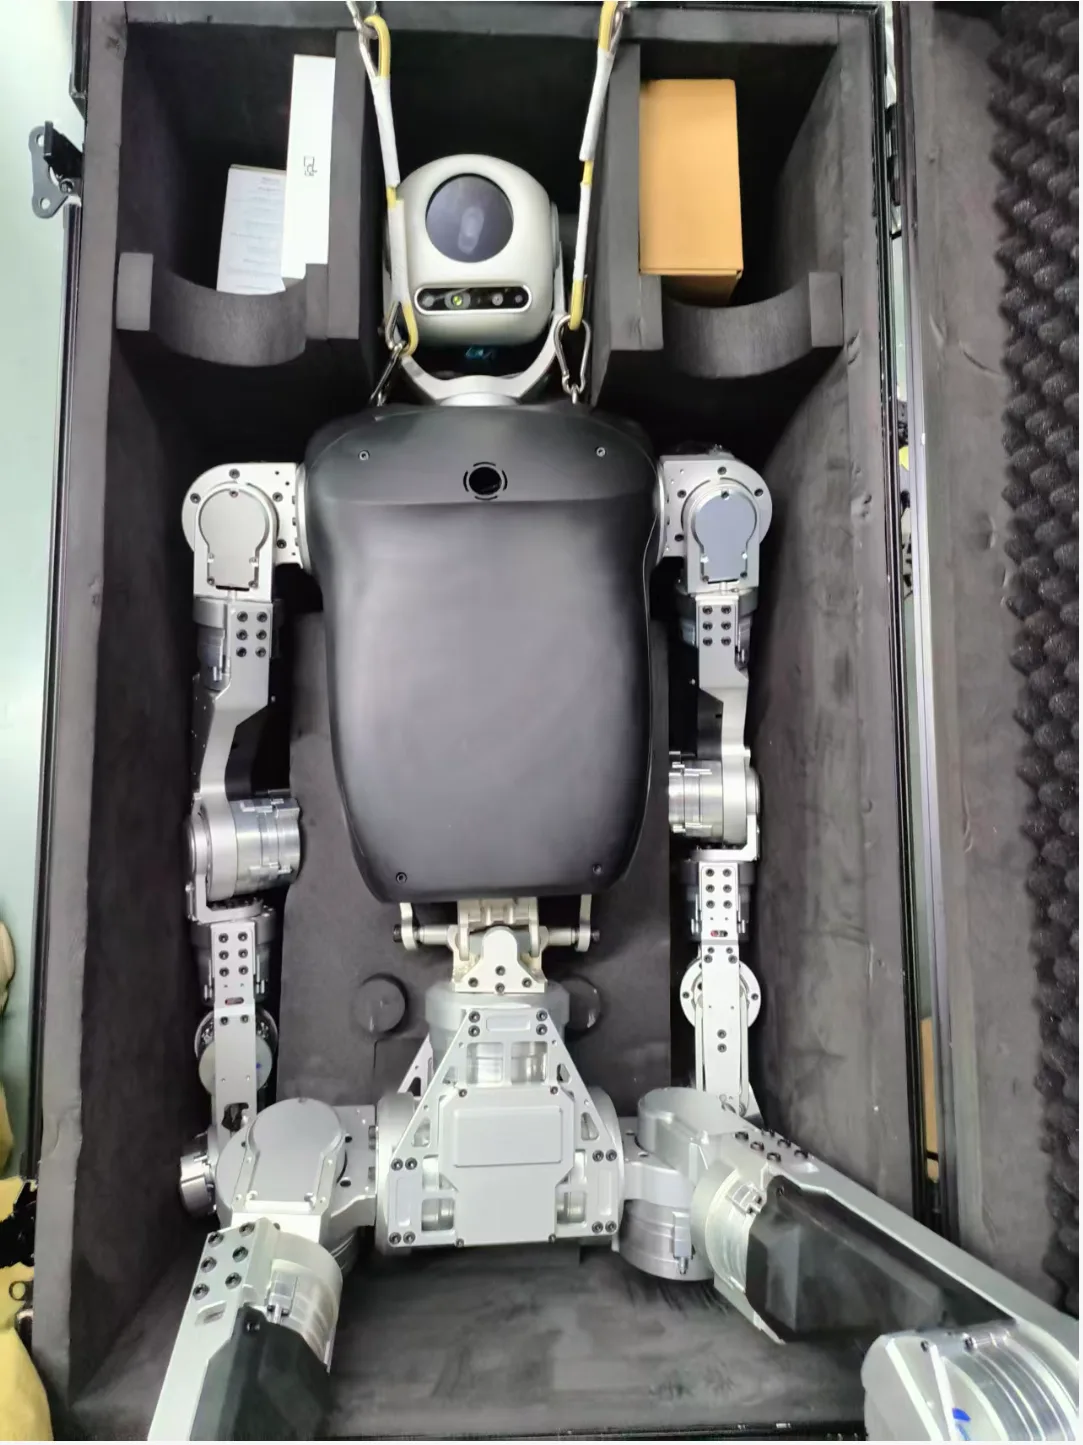
- After the accessories are in place, lift the robot with the hoist.
- Move the case under the robot, then lower the robot slowly.
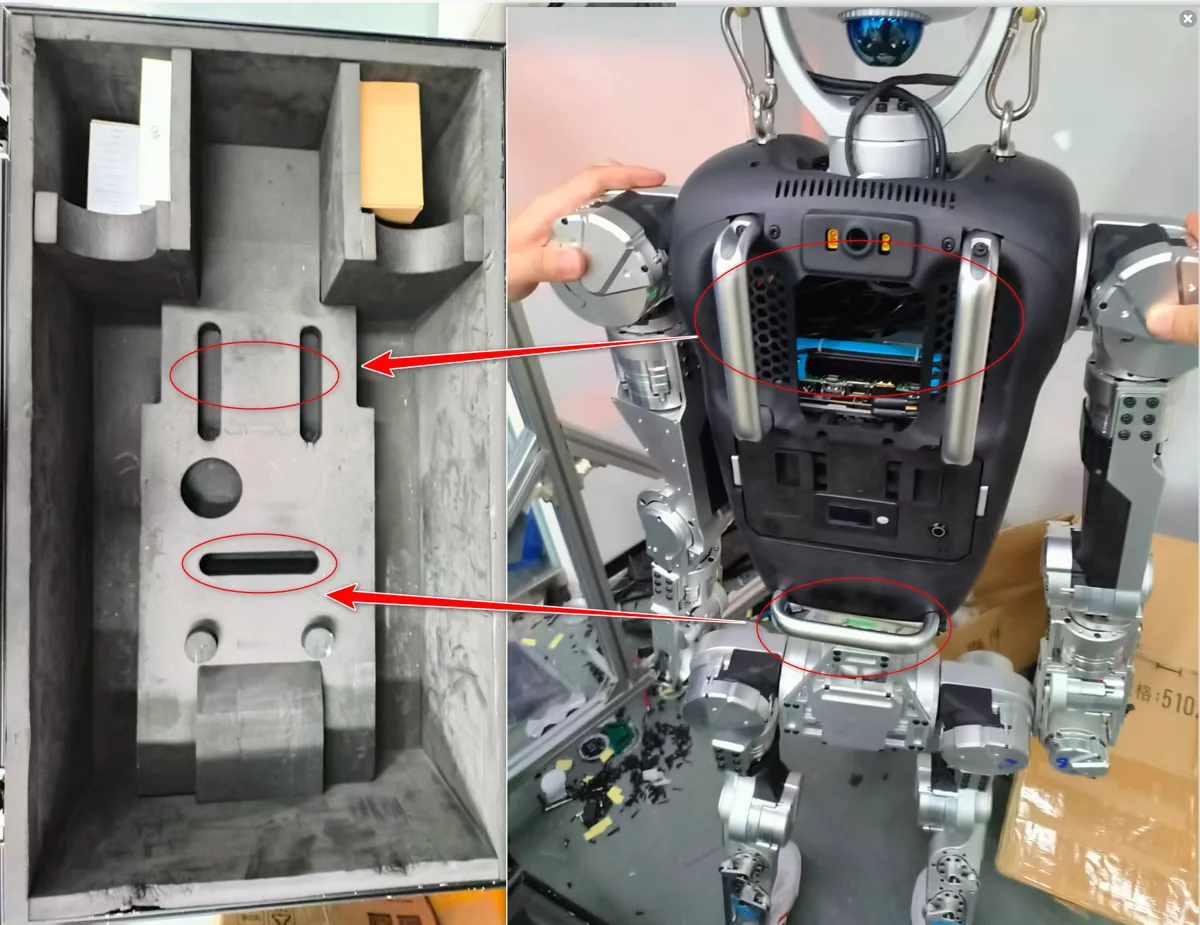
- Once the robot's hips contact the bottom foam insert, remove the upper hook from the hoist.
Two-person coordination
- One person holds the robot's rear lifting strap.
- One person supports the robot's legs.
- Lower the robot while aligning the rear handle with the foam recess.
- Once the robot is seated, remove the lifting strap from the robot and place it in its designated slot.
Check
- The robot's hips rest on the bottom foam insert.
- The rear handle is aligned with the foam recess.
- The lifting strap has been removed and placed in its designated slot.
3. Place the Arm and Elbow Foam Inserts
Operation
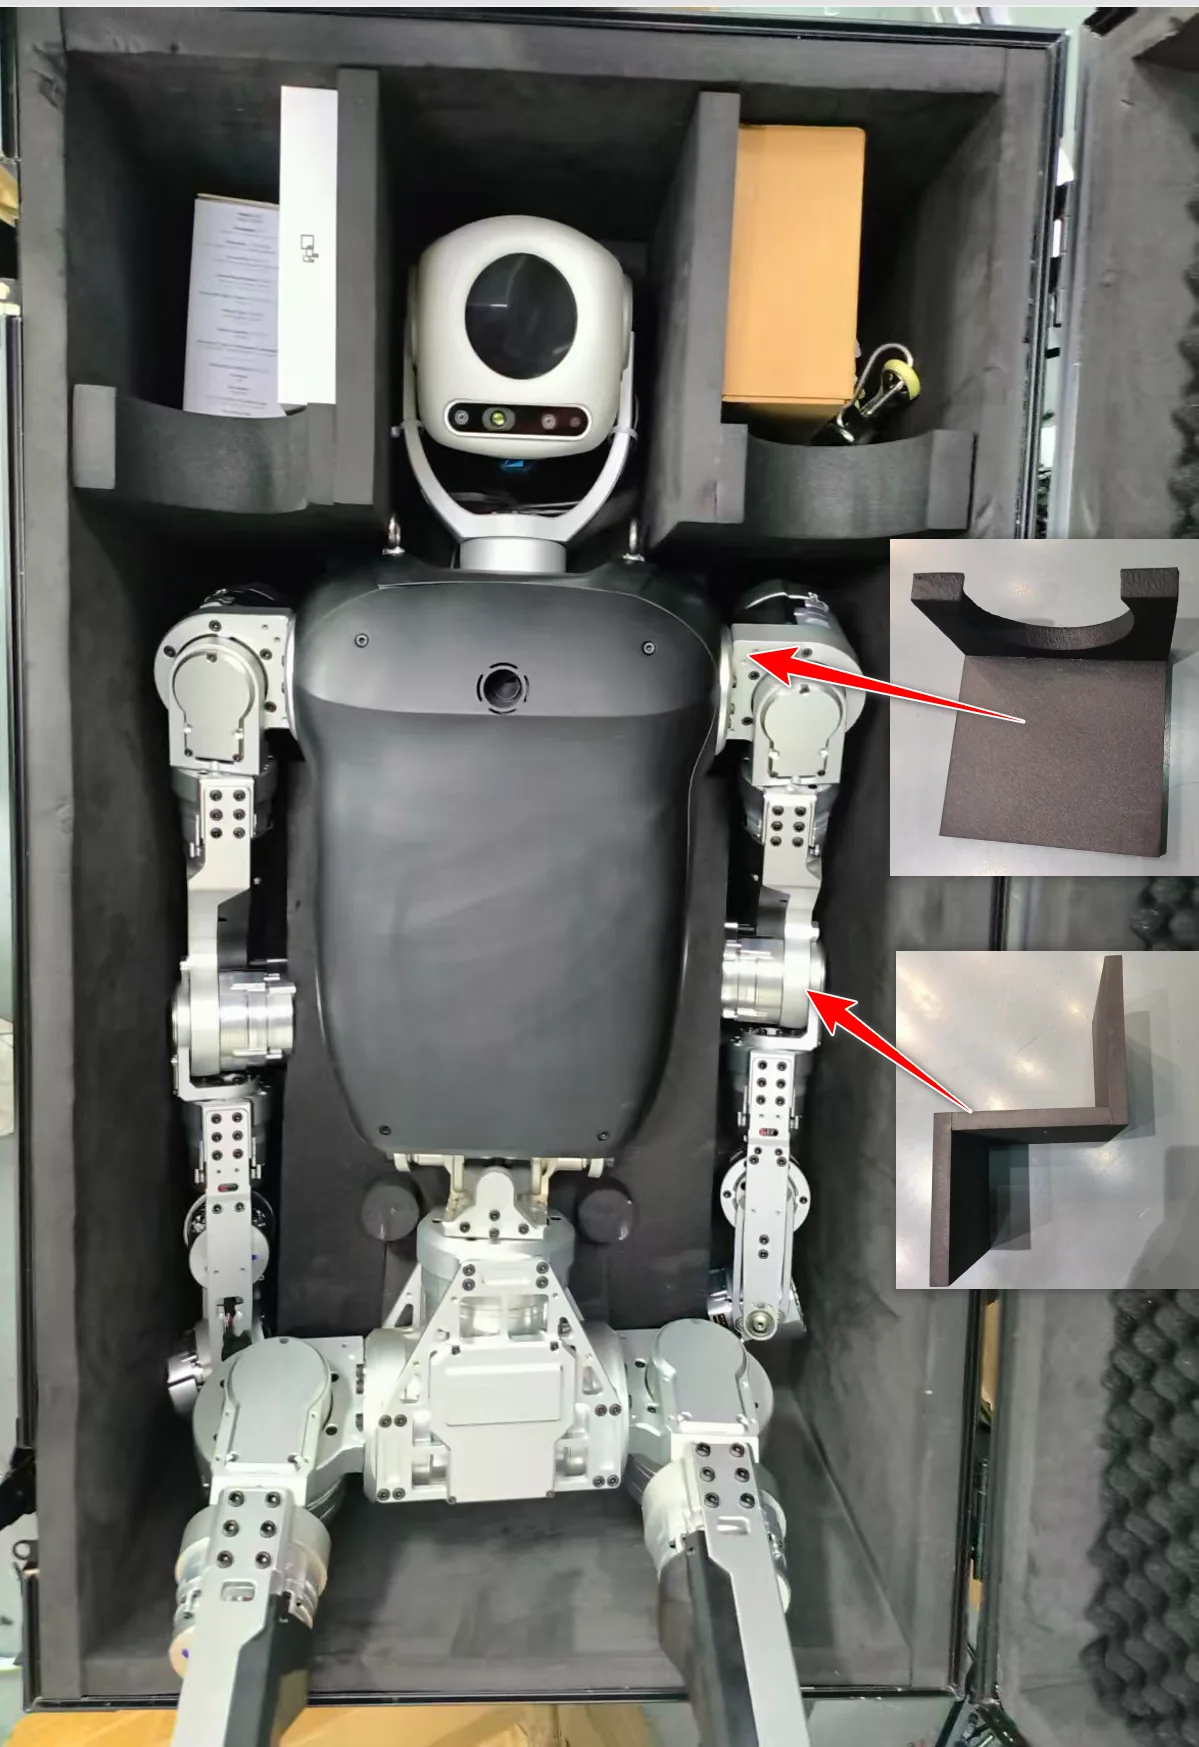
- Pull the robot's left and right legs and slowly rotate the waist.
- Place the robot's arms into the lower foam slots and seat them securely.
- Place the foam inserts around the arms and elbows.
Check
- The arms are fully seated in the foam slots.
- The elbow foam inserts are not loose or shifted.
- No joint is moved into an extreme limit position during adjustment.
4. Position the Legs and Finish Packing
Operation
- Rotate the robot's legs.
- Slowly place the left and right legs into their designated positions in the case.
- Keep the toes facing the edge of the slot.
Check
- The left and right legs are in their designated positions.
- The toes face the edge of the slot.
- No foam inserts are squeezed out or visibly deformed.
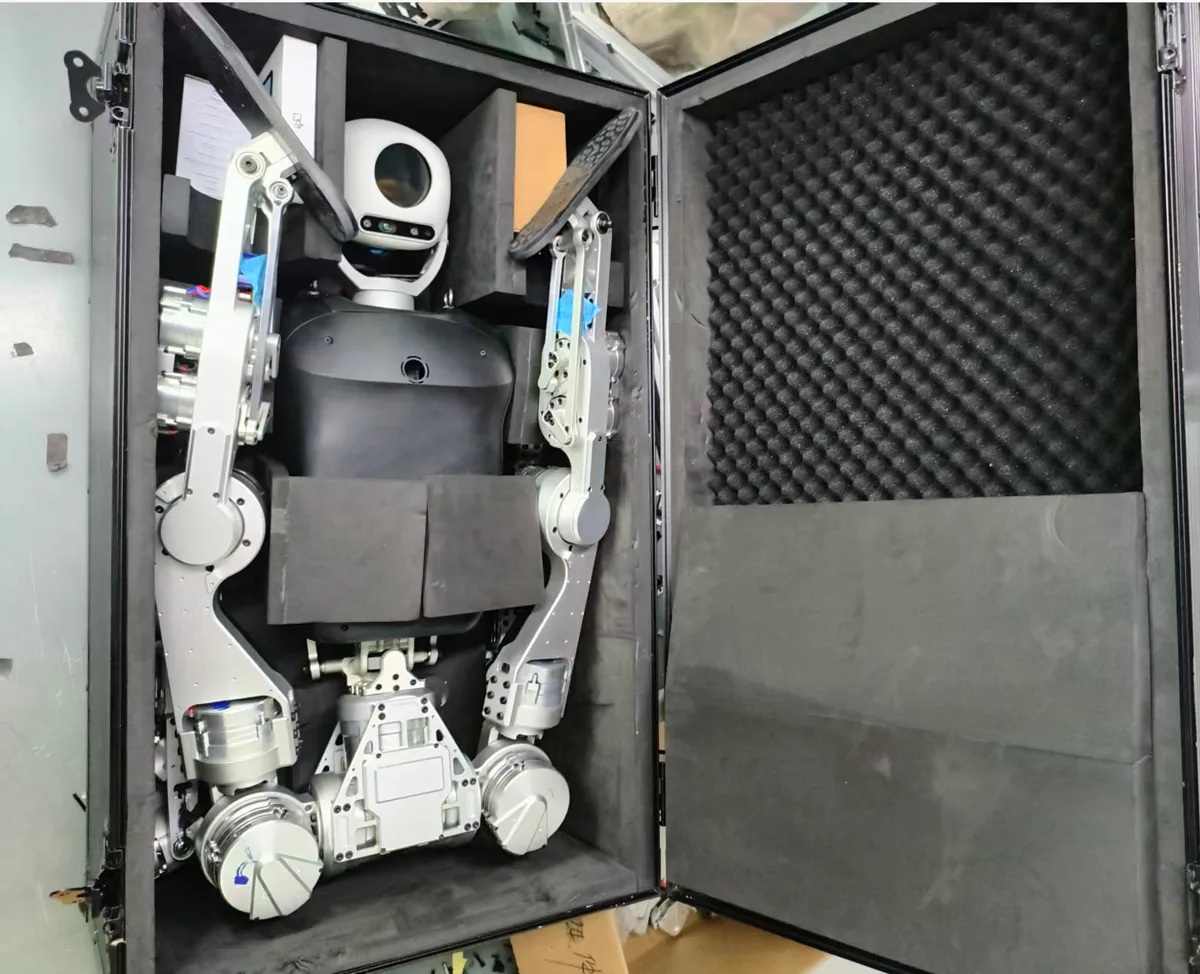
Final Check
Before locking the case
- Check whether the robot is still powered on before locking the case.
- After closing the lid, check whether it is lifted or misaligned. If anything is abnormal, adjust it immediately.
- Do not force the case closed. When the robot is placed correctly, the upper lid will not lift.
- If the lid lifts, check that the upper foam insert and the foot positions are correct.