 Documentation
Quick Start
This guide covers unboxing, basic operation, safety precautions, and secondary development for the BXI Elf3 humanoid robot.
Unboxing Instructions
- Placement and unboxing: Open the box face up, remove the surrounding foam, and lift the robot out with at least two people.
- Pay close attention to cable positions while lifting the robot out to avoid crushing or tearing them.
- After taking the robot out, it is recommended to suspend it from a hanger or lay it flat on the ground.
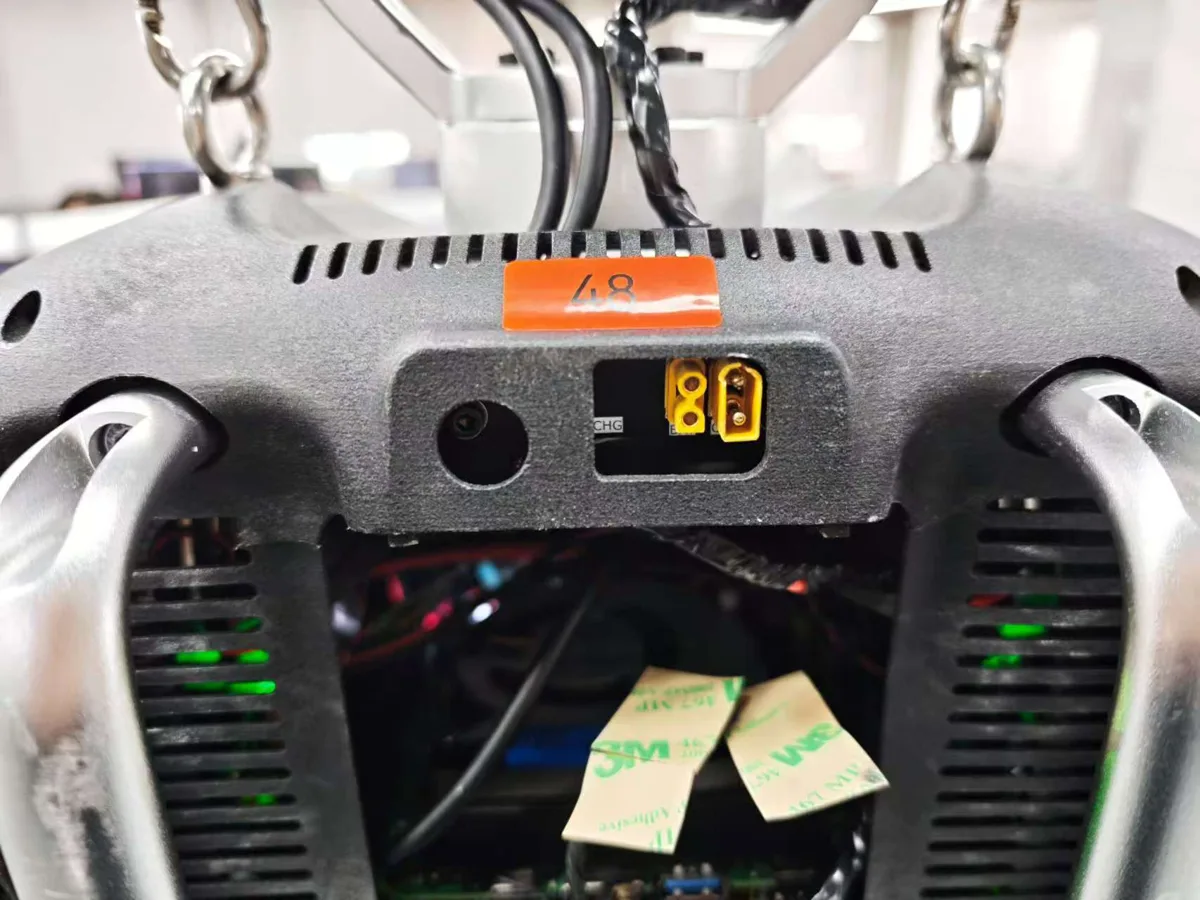
- Backplate layout:
- Upper display screen: Shows voltage, reference battery level, and temperature. Press the button on the right side of the screen to wake it; it turns off automatically after 10 seconds.
- Use the voltage value as the main battery-state reference. The percentage / battery bars are for reference only and may not match the actual remaining capacity.
- Lower right: Power switch button for the main battery.
- Upper body: Charging port.
- Upper display screen: Shows voltage, reference battery level, and temperature. Press the button on the right side of the screen to wake it; it turns off automatically after 10 seconds.
- Host system information:
- Host operating system: Ubuntu 22
- Username:
bxi - Password: please contact HumansX.
Power-on and Operation Steps
1. Turn on Battery Power and Host Power
- Press the battery power button. The battery supplies power and the host powers on at the same time. Check the voltage value on the backplate display. The percentage / battery bars may be inaccurate, so use the voltage value as the reference.
- Voltage notes:
- New 58V machines: The backplate display shows the current battery-pack voltage. Fully charged, it is about 58.8V, and it gradually decreases during use. If the voltage is clearly low (below 50V), stop and charge the robot first.
- Older 48V machines: The backplate display shows the current battery-pack voltage. Fully charged, it is about 48.8V, and it gradually decreases during use. If the voltage is clearly low (below 40V), stop and charge the robot first.
Charging notes
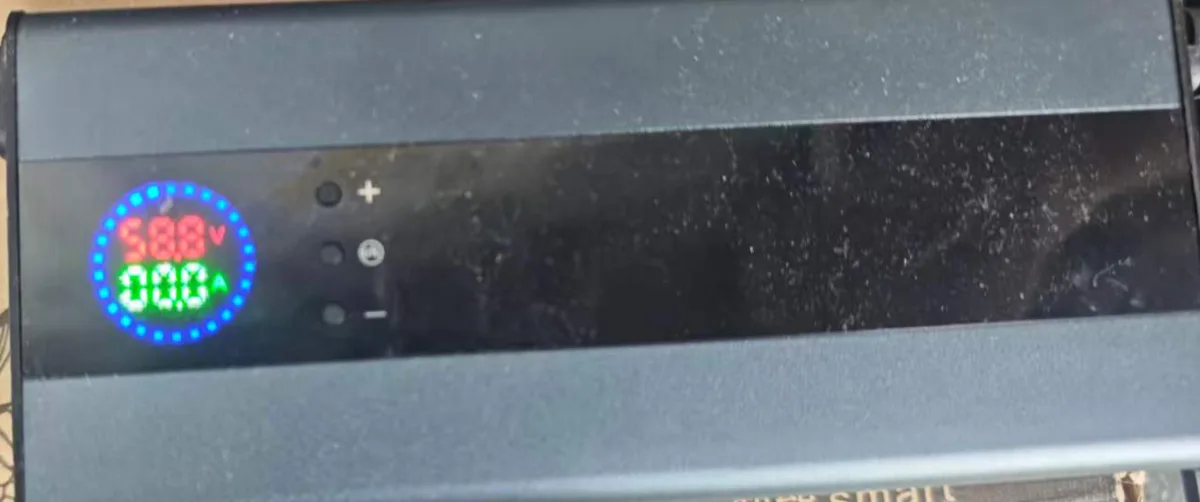
Verify the charger output voltage: Connect the charger directly to a power source (without connecting the robot) and check that the charger display is within the specified range:
- Older machines with 48V batteries: The recommended voltage is 48.8V. If it differs, adjust it before connecting the robot.
- New machines with 58V batteries: The recommended voltage is 58.8V. If it differs, adjust it before connecting the robot.
Note: The percentage / battery bars may be inaccurate. Before powering on or moving the robot, use the voltage value as the primary battery-state reference.
The charger connects to the charging port on the robot's backplate.
2. Connect the Remote Controller
The remote controller connects to the robot PC via Bluetooth and is pre-paired at the factory.
- Long-press the Xbox button.
- Wait until the indicator light below the button stays solid; this means the controller is connected to the robot PC.
3. Run the Control Program
Watch the operation instruction video carefully before proceeding.
The robot's built-in control program has multiple modes, including Walking, Zero Torque, Initial Posture, Zero-position, High-speed Run, Medium-speed Run, Dance, Recovery, Front Flip (run without dummy hands installed), Clap, and Wave. Modes will continue to be added through updates.
Important: Pre-movement preparation
- To prevent accidental falls, make sure the robot is hung from a gantry crane with a lanyard, sitting on a chair, or sitting upright on the ground. It is strongly recommended to use a hanger and suspend the robot at an appropriate height.
- Remove all cables from the body (such as the charging cable) to prevent tangling during movement.
- Make sure the battery voltage is sufficient (55V or above is recommended; use the backplate display voltage, not the percentage / battery bars) so the robot does not fall because it lacks the power to complete a motion.
- Always prioritize safety. No one may enter the robot's range of motion; take care not to be struck by swinging joints.
3.1 Start the Program
Important: Check before switching to Initial Posture
- Make sure the robot's limbs are not in a posture that could cause motor stalling when switching to the initial posture.
(Keeping the robot suspended is recommended.) After the robot powers on, wait about 30 seconds for the system to finish starting up, then press the right stick (RS/R3) to start the robot. If the chest light turns on, the control program is running. The robot enters Zero Torque mode by default. After the chest light turns on, wait about 10 seconds for the self-check to complete before switching to Initial Posture, Walking, or other modes.
3.2 Initial Posture Initialization
(Keeping the robot suspended is recommended.)
- Press
RB+Btogether to put the robot into the initial posture. - Check that the robot is normal: Briefly observe the motors for any anomalies (such as no response or abnormal noises).
- Stand the robot up: If everything is normal, stand the robot up in this state with both feet on the ground. The operator should help maintain the initial-posture standing state so that external forces do not disturb posture initialization.
3.3 Switch to Motion State
(Initial-posture initialization is now complete. Keeping the robot suspended is still recommended; release the lanyard only after the switch has succeeded and the robot is stable.)
- Walking state: Press
RB+Xtogether. The robot enters the walking state and can move omnidirectionally on flat ground.
Shutdown and De-energization
4.1 Termination Shutdown (De-energization Button)
- Press Start. The control program exits automatically and the robot motors de-energize immediately. The robot will collapse under gravity.
- Restart: Return to Section 3.1 to restart the program.
Gamepad Motion Control
Controller power indicator colors: A solid light means the controller is connected. White indicates a 2.4G wireless connection, blue indicates Bluetooth, and green indicates a USB wired connection. A flashing red battery indicator means the battery is low.
Controller mode switch: Located on the bottom/back of the controller near the USB-C port. It has three positions: USB, BT, and RF.
USB: USB wired mode, connecting to the PC with a USB-C data cable.BT: Bluetooth mode, used to connect to the robot PC via Bluetooth.RF: 2.4G wireless mode, used with a 2.4G USB receiver. The receiver is stored in the controller box by default.
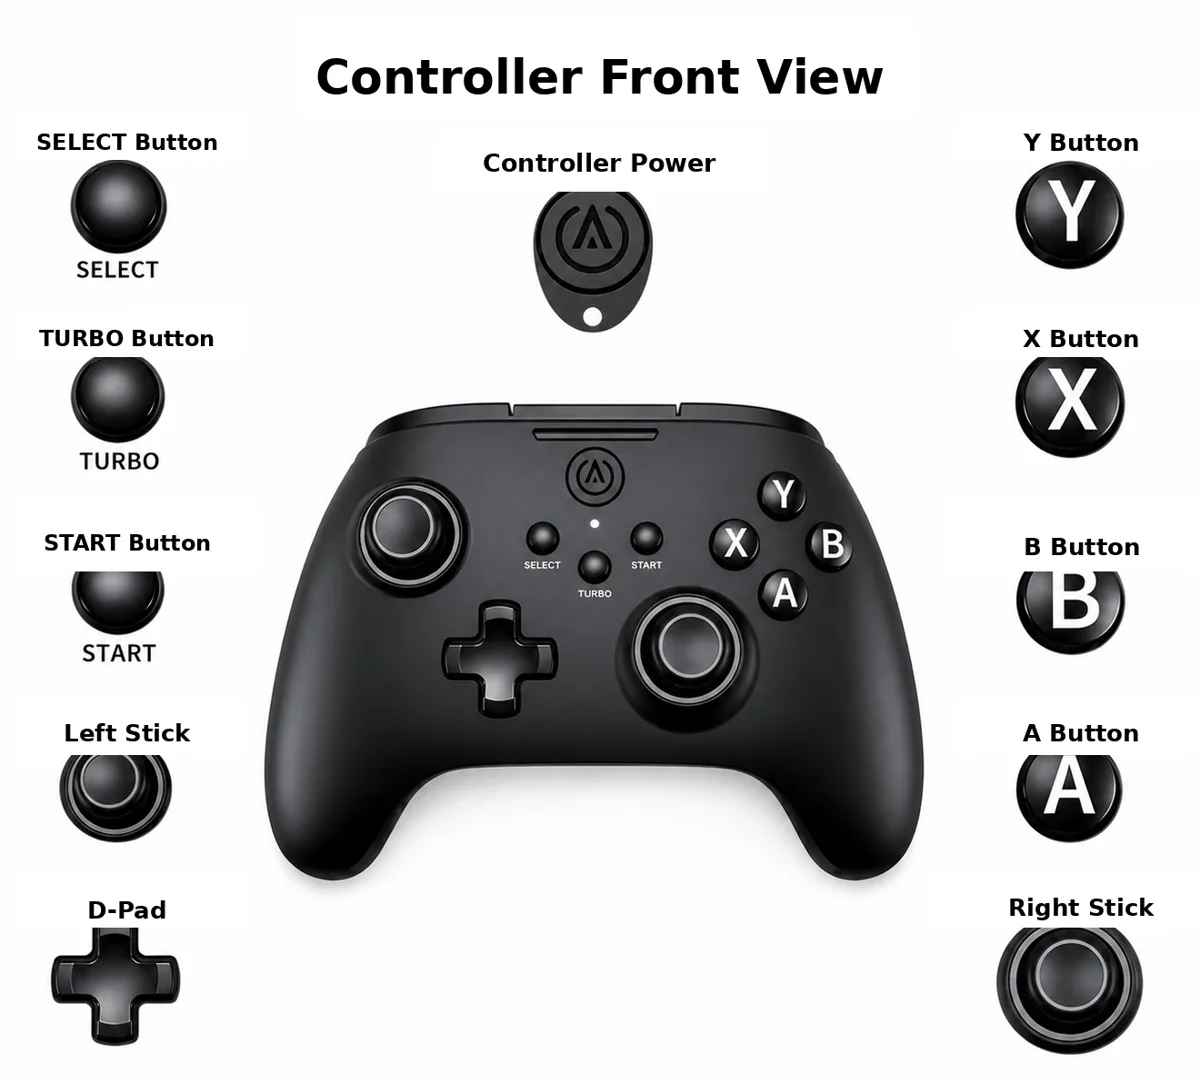
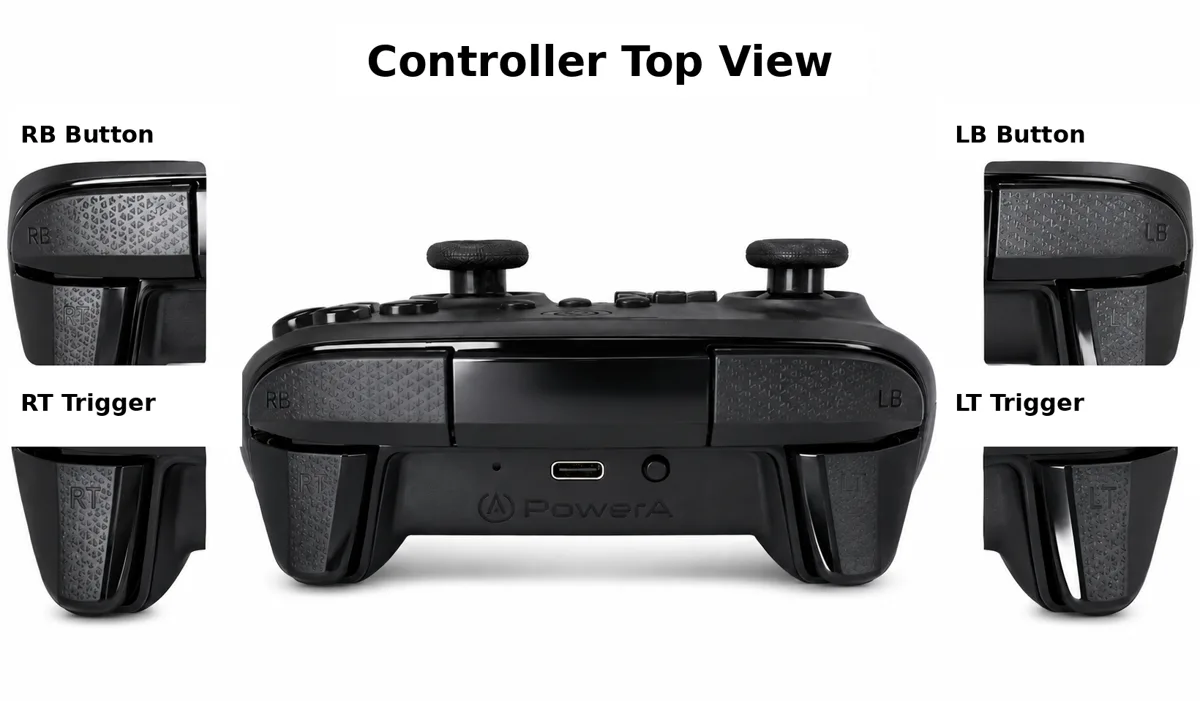
Movement Direction Control
In Walking, High-speed Run, and Medium-speed Run modes, use the following inputs to move the robot:
| Control | Operation | Effect |
|---|---|---|
| Right stick | Push forward or backward | Forward / Backward |
| Left stick | Push left or right | Left translation / Right translation |
| D-pad | Press ← or → | Turn left / Turn right |
Mode List
| Mode Level | Mode Name | Button Combination | Switchable Modes | Notes |
|---|---|---|---|---|
| Normal | Walking | RB + X | All modes except Recovery | Omnidirectional movement, with some obstacle-crossing ability (10–15 cm steps) |
| Normal | Zero Torque | RB + A | Initial Posture / Zero-position | Joints output no torque and can be rotated freely |
| Normal | Initial Posture | RB + B | Walking / Zero Torque / Zero-position / Recovery | Joints hold the initial posture |
| Normal | Zero-position | RB + Y | Initial Posture / Zero Torque | All joints hold the zero position |
| Advanced | Dance | LB + X | Walking / Zero Torque / press X to pause or resume | Automatically returns to Walking after completion. While paused, the robot may move to keep its balance (make sure there are no obstacles within 1 m of the robot) |
| Advanced | Recovery | LB + A | Zero Torque | Use only when the robot is lying face down or on its back. After standing up, it automatically returns to Walking (make sure there are no obstacles within 1 m of the robot) |
| Advanced | High-speed Run | LB + Y | Walking | Up to about 4 m/s, no obstacle-crossing ability |
| Advanced | Medium-speed Run | LB + B | Walking | Up to about 2 m/s, no obstacle-crossing ability |
| Advanced | Front Flip | LT + Y | Zero Torque | Keep 3 m in front of the robot clear of obstacles. Automatically returns to Walking after completion. Run without dummy hands installed |
| Normal | Clap | RT + B | Walking / press X to pause or resume | Automatically returns to Walking after completion |
| Normal | Wave | RT + A | Walking / press X to pause or resume | Does not automatically return to Walking |
Custom Program (SDK) Control
For developers who want to control the robot with custom algorithms, ROS, or other programs.
The operating environment and low-level programs are pre-configured and work out of the box.
- SDK and ROS 2 example: (provided by HumansX to system users)
Packing and Transportation
- Avoid limits: Do not leave joints in mechanical dead zones or at extreme limit positions.
- Isolation protection: Insert the original foam cushioning to prevent direct contact between metal casings during transport, especially between two motor housings.
See the Packaging Instructions page for the full packing procedure.