
Humanoid Body ODM
Your own-brand humanoid, in as little as 6 months.
Developing a humanoid robot from scratch typically takes 2–3 years and specialists in AI motion control, hardware and mass production. With body ODM based on BXI Elf3, you can build on proven hardware and motion-control algorithms, customize the exterior, computing unit, sensors and more to your specifications, and bring your own-brand humanoid to market quickly.
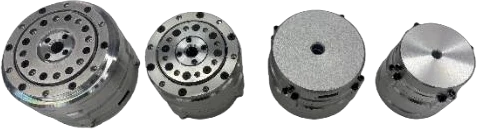
Joint modules
In-house hollow planetary motors. Just three sizes — 85, 70 and 50 — make up the whole body.
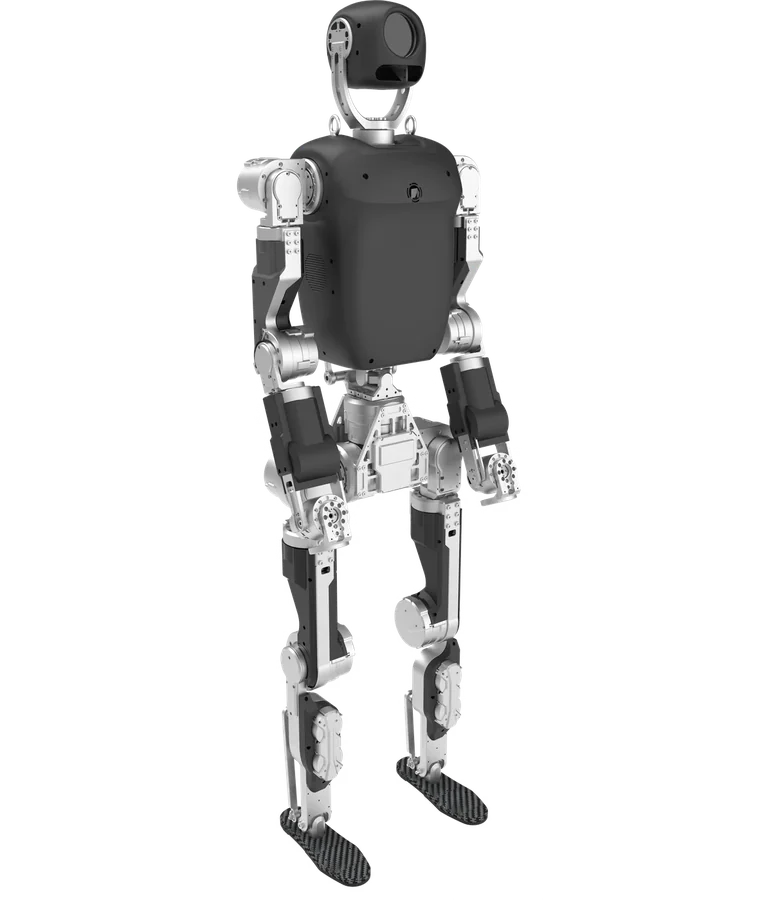
Mechanical design
A 31-DoF body structure proven in competitions and customer deliveries.
Dedicated electronics & control
Whole-body control at over 1,000 Hz, with an open architecture supporting x86 and ARM.
Motion-control algorithms
State-of-the-art reinforcement-learning control. Walking, running, jumping and dancing are ready to use.
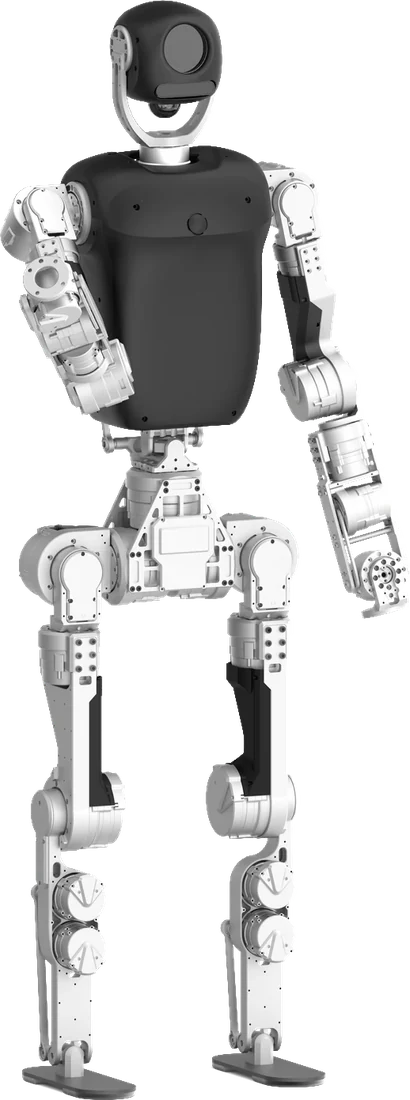
Your own-brand humanoid
- Custom exterior design, ready for mass production
- Walking, running, jumping and dancing
- Conversational AI via LLM APIs
- Continuous OTA updates
Design
Exterior Design
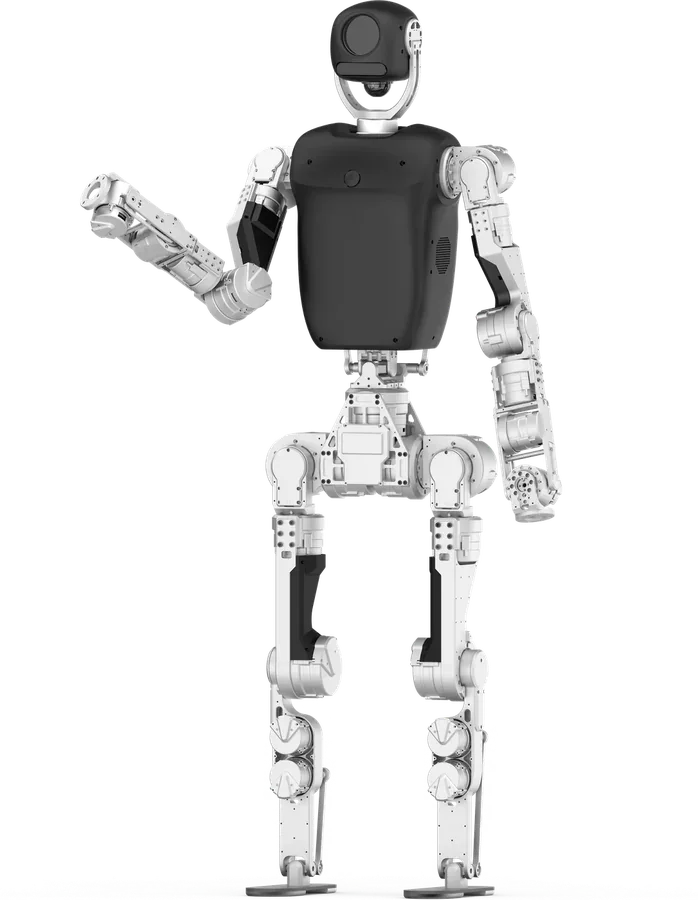
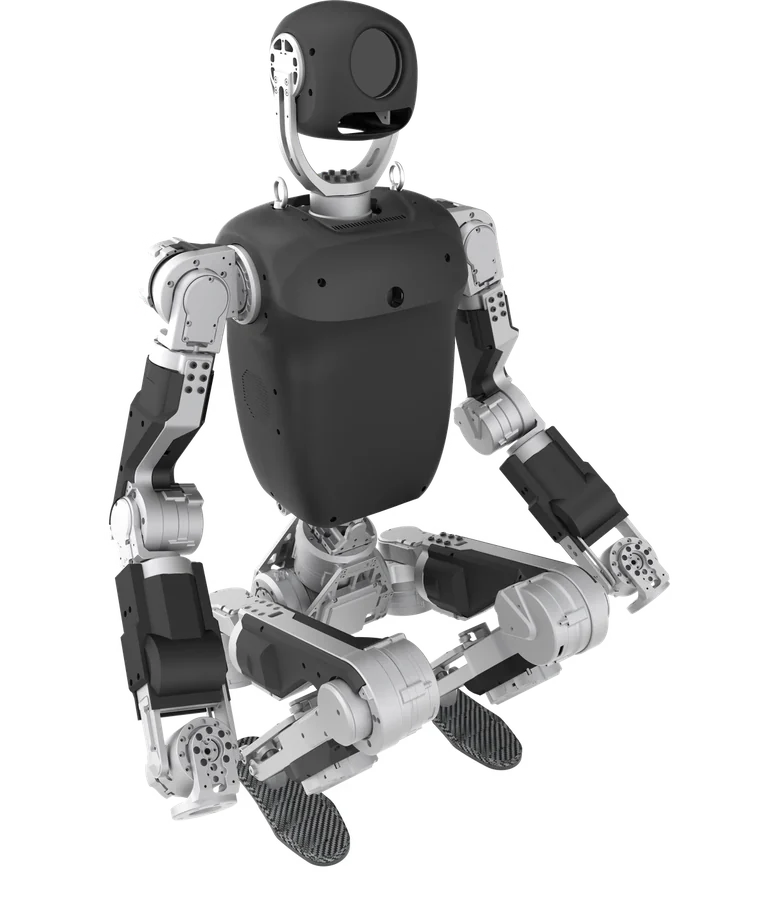
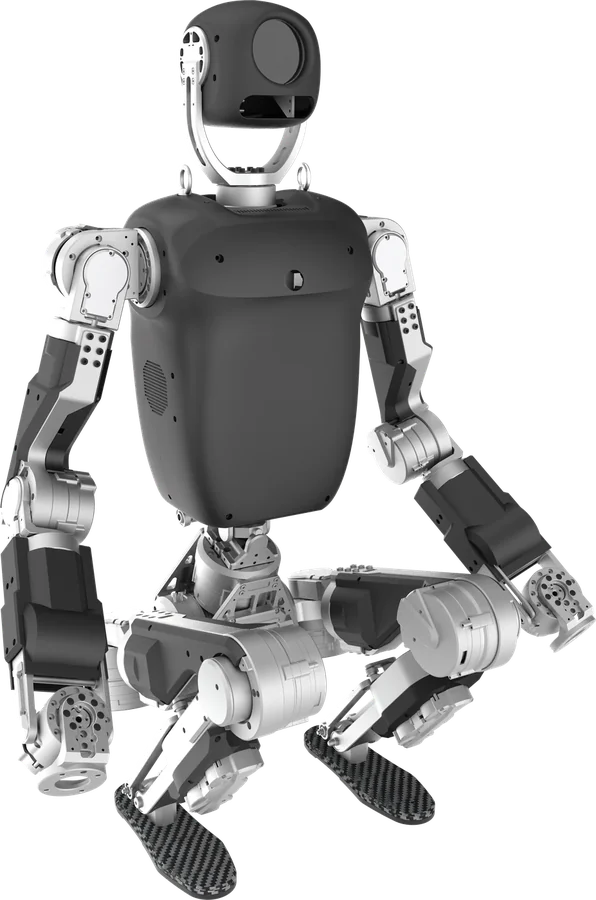
A refined design combining human-like proportions with aluminum and carbon components. With 31 DoF across the whole body, it naturally expresses a wide range of postures — standing, crouching and sitting.
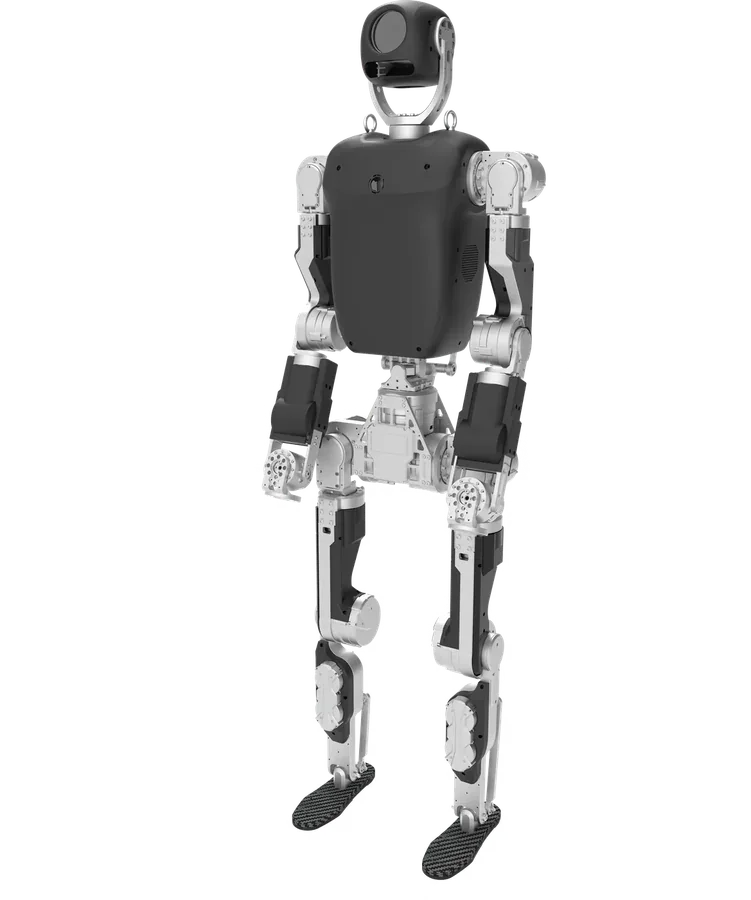
Dynamic Motion
Highly dynamic motion, proven in the real world.
Motion control validated not only in simulation but in real competitions and field use. The robot reliably performs highly dynamic movements such as running, jumping, dancing and climbing over obstacles.
Customization
Customization Options
Start from a mature standard platform and customize only what you need — building your own-brand product while keeping development cost and time down.
| Item | Development cost | Typical lead time | Notes |
|---|---|---|---|
| Exterior design (ID) | Low | Approx. 1.5 months | Exterior shape, colors, logo, etc. |
| Computing unit | Low | Approx. 1.5 months | Supports NVIDIA Jetson Thor and more |
| Sensor | Low | From a few weeks | Depends on requirement complexity |
| Mechanical structure | High | 3–6 months | Evaluated case by case |
| Motors | High | 3–6 months | Standard motors recommended |
| Height | High | 3–6 months | Changes not recommended |
* Costs and lead times are estimates. We provide individual quotes based on your specifications.
Why Body ODM
Comparing Development Paths
| In-house from scratch | Buy an off-the-shelf robot | HumansX Body ODM | |
|---|---|---|---|
| Development time | 2–3 years | Immediate | As little as 6 months |
| Initial cost | Very high | Low | Reasonable |
| Brand | Your own brand | Manufacturer's brand | Your own brand |
| Customizability | Unlimited | Almost none | Hardware and algorithms, step by step |
| Mass production | Must build your own | None | Use existing production lines |
| Risk | Risk of project failure | Dependence on a vendor | Proven, low risk |
Joint Modules
Joint Modules Built for Humanoids
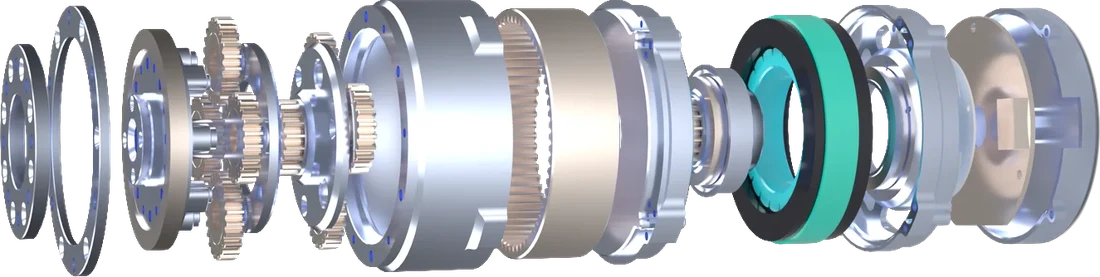
The BXI-50/70/85 hollow planetary series. Just three motor types are enough to build a humanoid with more than 30 DoF, greatly reducing design, manufacturing and maintenance costs.
Modular design
Three motor types cover the whole body, with a torque range of 25–150 N·m that can be tuned and customized.
Planetary + hollow structure
The hollow shaft routes cables internally for better reliability and range of motion. The planetary gearbox is highly shock-resistant and withstands falls.
True dual encoders
Direct measurement on both the motor and output sides improves end-effector control accuracy.
Field-proven
Validated through demanding tests and competitions on multiple humanoids, and continuously improved.
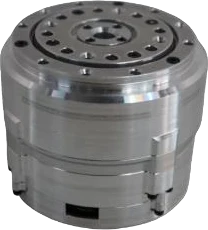
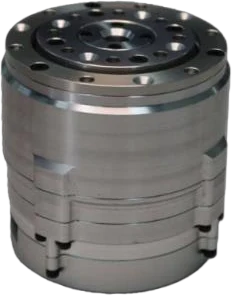
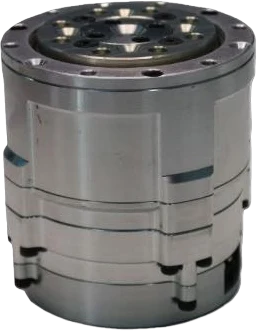
| Item | BXI-50 | BXI-70 | BXI-85 |
|---|---|---|---|
| Rated torque | 7 N·m | 15 N·m | 40 N·m |
| Peak torque | 25 N·m | 50 N·m | 150 N·m |
| Peak phase current | 30 A(rms) | 60 A(rms) | 90 A(rms) |
| Outer diameter × height | 64 × 65.5 mm | 81 × 66.5 mm | 99 × 71.5 mm |
| Hollow diameter | 6 mm | 9 mm | 10 mm |
| Weight | 0.5 kg | 0.8 kg | 1.4 kg |
| Common specifications | Rated voltage 24–48 V / no-load speed 200 rpm / rated speed 100 rpm / gear ratio 19.5 / cross-roller bearing / dual encoders (motor side: magnetic, output side: inductive) / MIT protocol with hybrid torque, position and velocity control / CAN, CAN FD (RS485 coming soon) | ||
Motion Control
Motion Control ("Cerebellum") Solution
We develop and adapt reinforcement-learning-based motion control for your robot. With a systematic pipeline from data to real hardware, we deliver highly dynamic motion ready for exhibitions and performances.
Automatically extracted from human videos, or motion capture
Automatic conversion of human motion into robot joint trajectories
Reinforcement learning in parallel simulation environments
Quality validation in high-fidelity simulation
Deploying the control policy to real hardware
Applications
Main Applications
Exhibitions & performances
Demonstrations of dynamic motion such as walking, running, jumping and dancing
Guidance & patrol
Guiding visitors in exhibition halls and facilities with precise navigation and multilingual AI commentary
Teleoperation & data collection
Collecting AI training data with VR, exoskeletons and data-capture devices
Research & development
A platform for embodied AI and VLA model research, or for developing your own robot products
HumansX Solutions
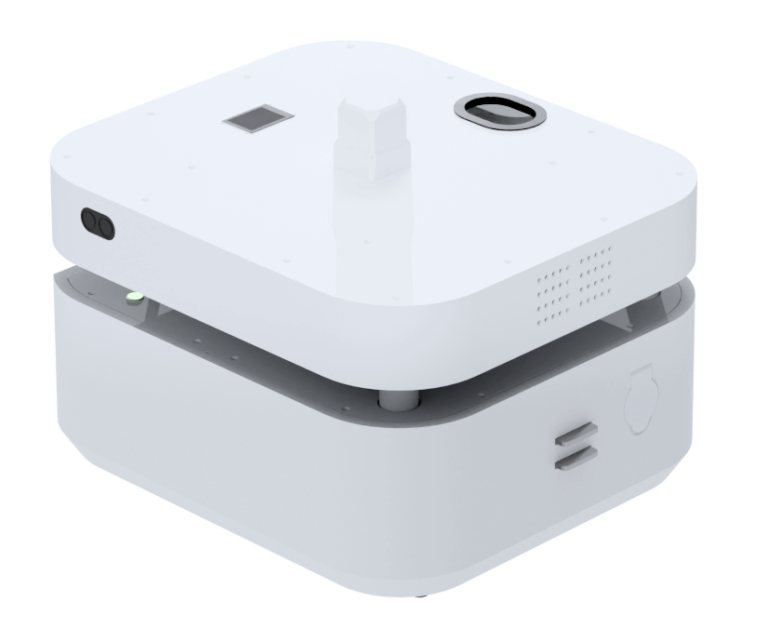
Combine with Hands and Bases
Combine HumansX Physical AI solutions to configure a robot for your application.
Specifications
BXI Elf3 Main Specifications
| Height | 145 cm |
|---|---|
| Weight | 35–40 kg |
| Total DoF | 31 (7 per arm / 6 per leg) |
| Payload per arm | 5 kg |
| Max. speed | 5 m/s |
| Operating time | 1 hour or more |
| Peak torque | Shoulder 50 N·m / elbow 50 N·m / wrist 25 N·m / knee 150 N·m / thigh 150 N·m |
| Sensor | LiDAR + depth camera |
| Computing unit | NVIDIA Jetson Thor supported |
| Conversational AI | Supported (LLM API integration) |
| Secondary development | Fully open |
* Specifications are subject to change without notice and vary depending on customization.
Contact
Consult Us About Humanoid ODM
We will propose the best customization plan for your application, budget and schedule. Feel free to contact us.