Physical AI Education Kit
UNI-WR2S
Portable ROS/SLAM Learning Robot
From the desktop to real-world navigation.
Overview
From Desktop to Real-World Navigation
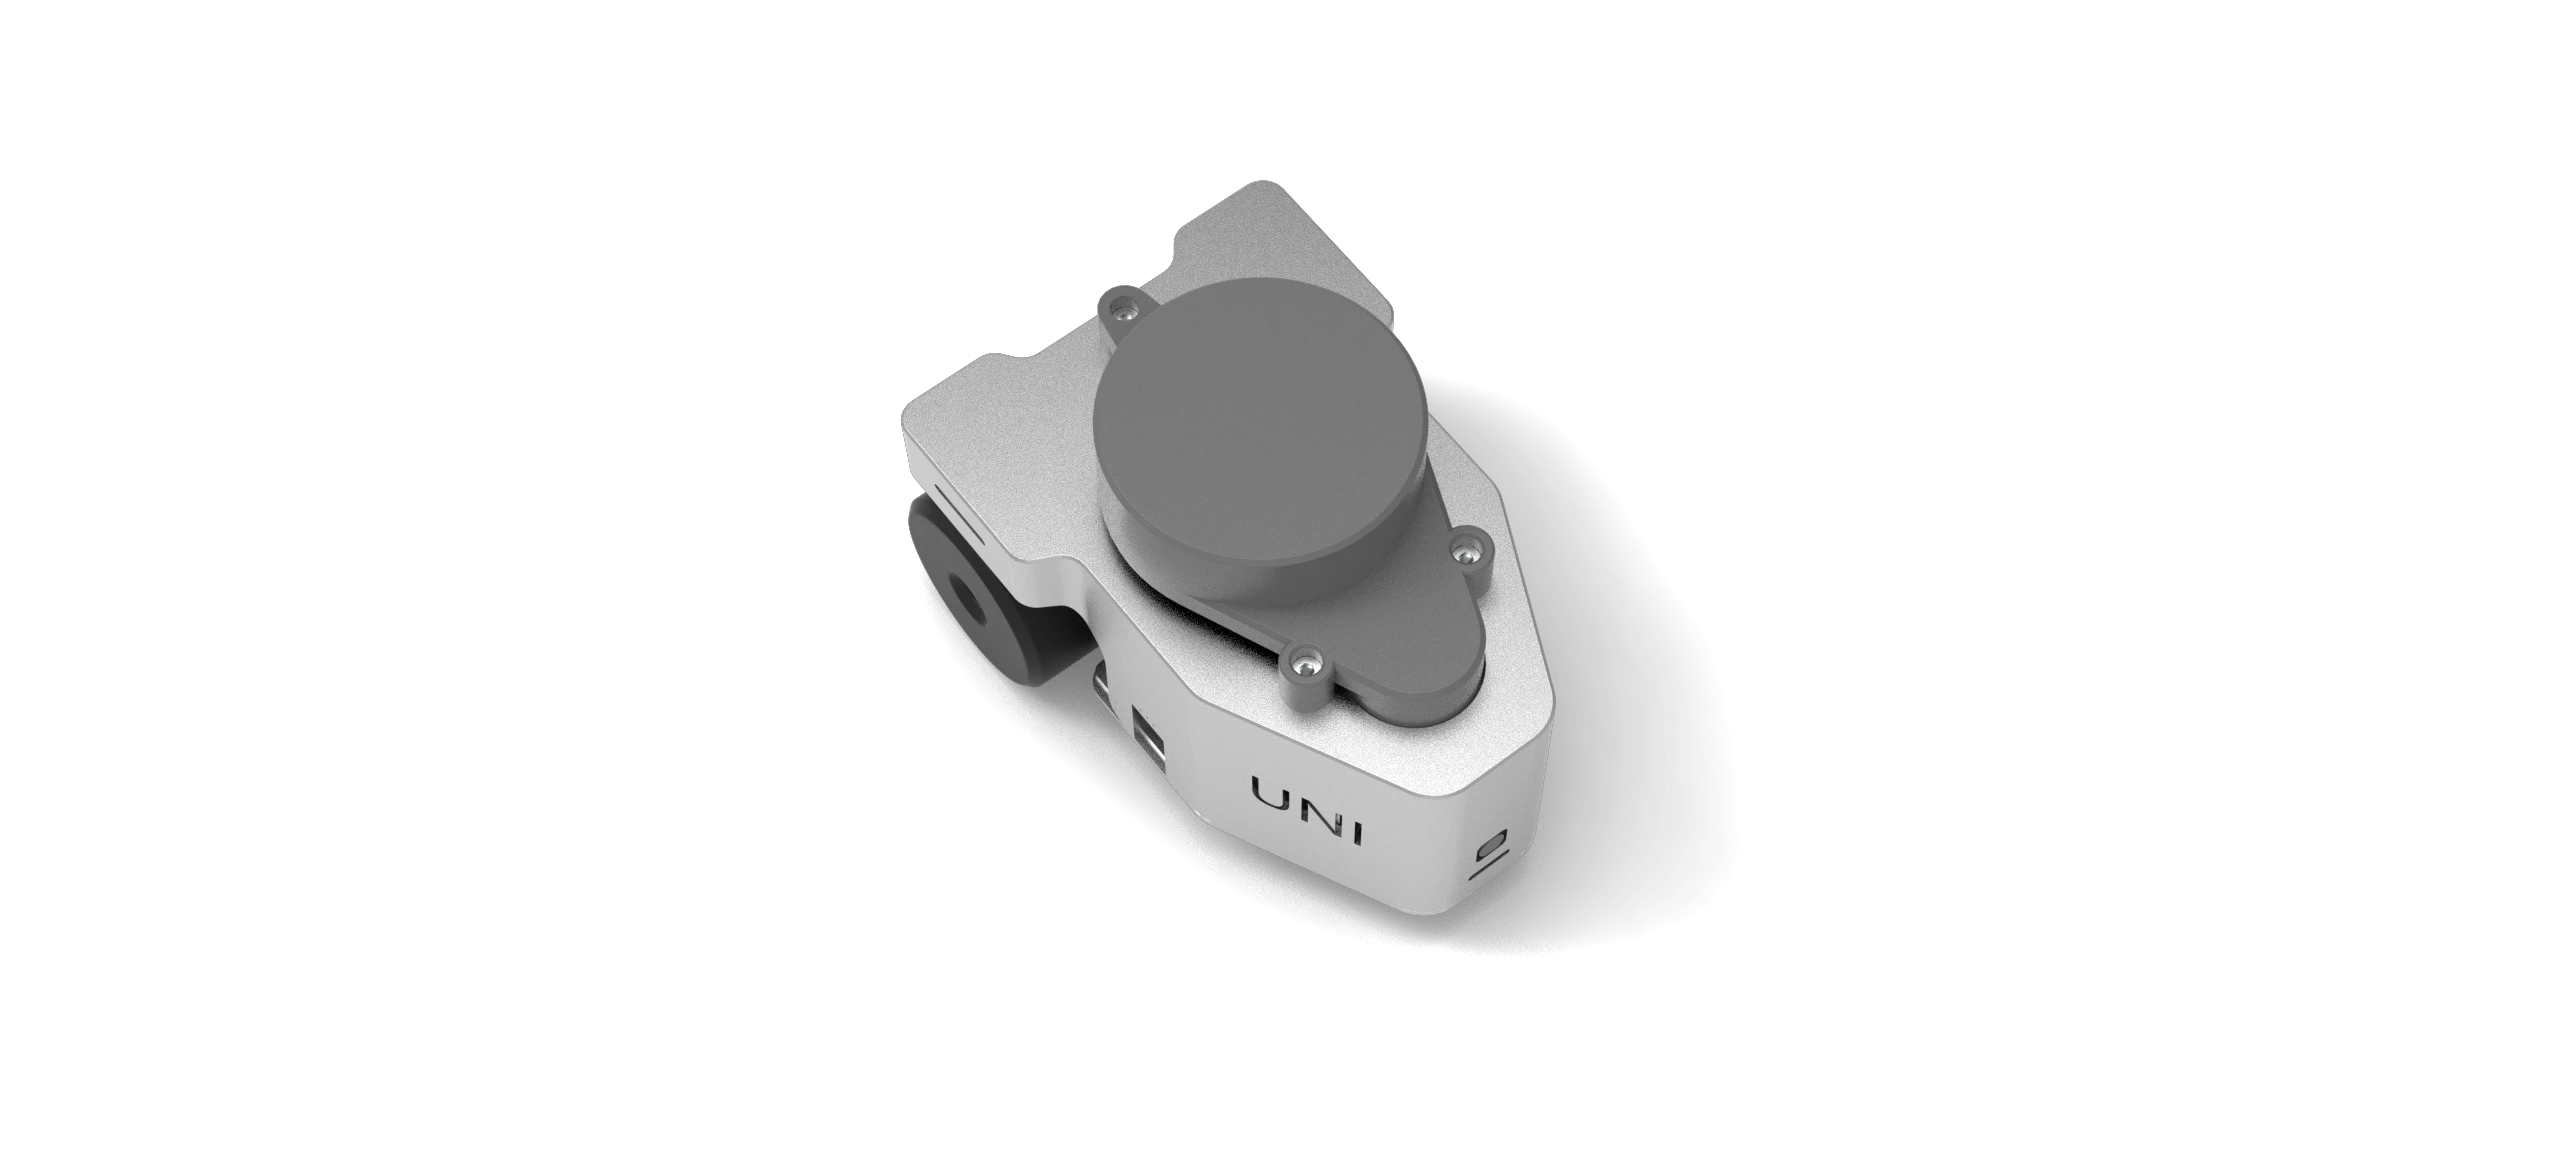
UNI-WR2S is a portable desktop robotic platform designed for ROS and SLAM navigation education.
Supports practical exercises for courses such as “ROS,” “Mobile Robot Navigation and Localization,” and “Automatic Control (PID).”
Unlike conventional simulation-centric approaches or methods requiring large-scale experimental setups, UNI-WR2S provides a portable hardware and desktop-based environment, enabling a systematic breakdown of the ROS engineering workflow.
Enables validation of navigation algorithms and package development on a real robot, anytime and anywhere.
■ Applications & Use Cases
Features
Key Features
Portable Learning Model
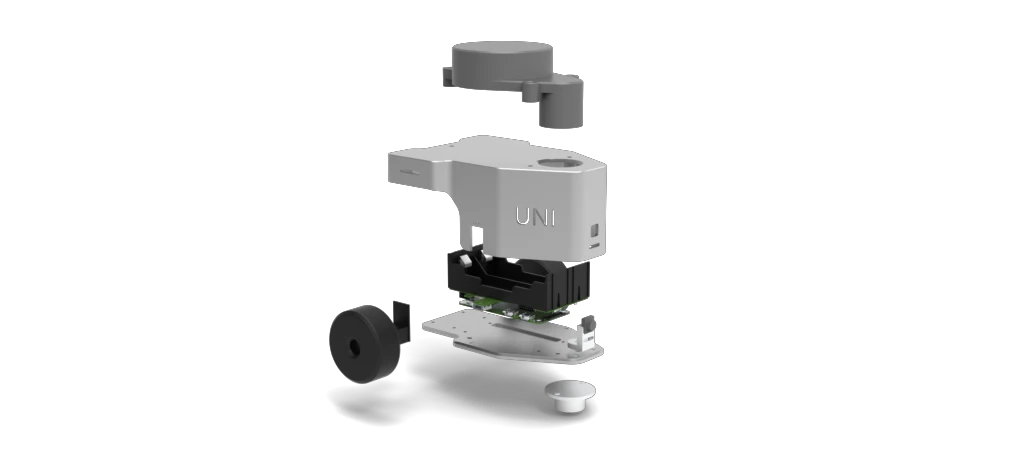
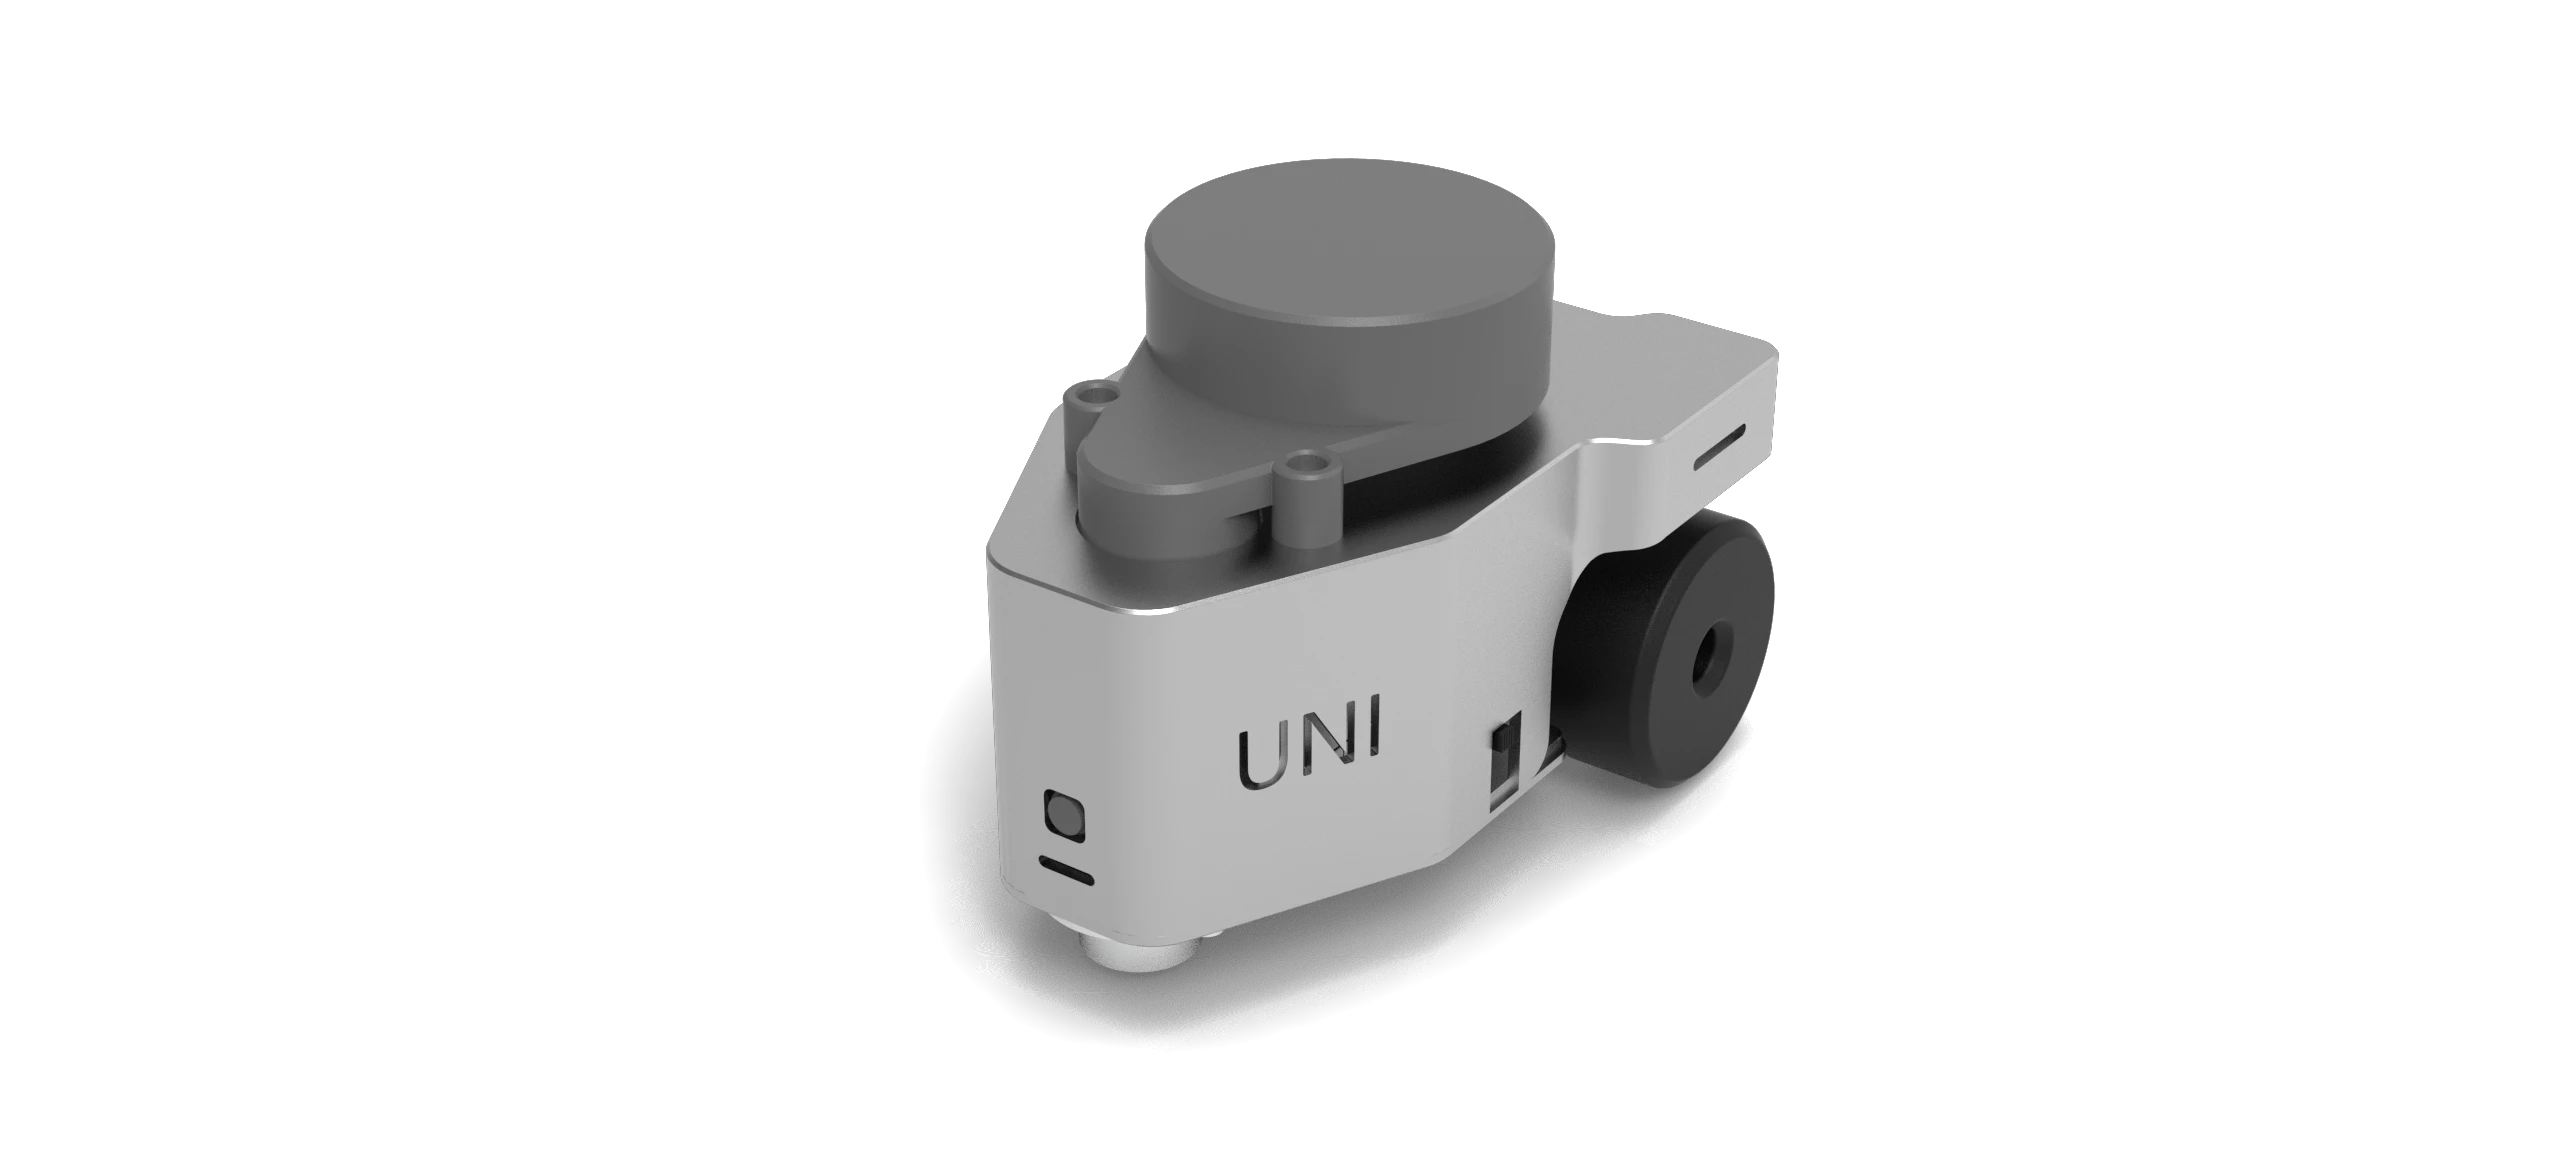
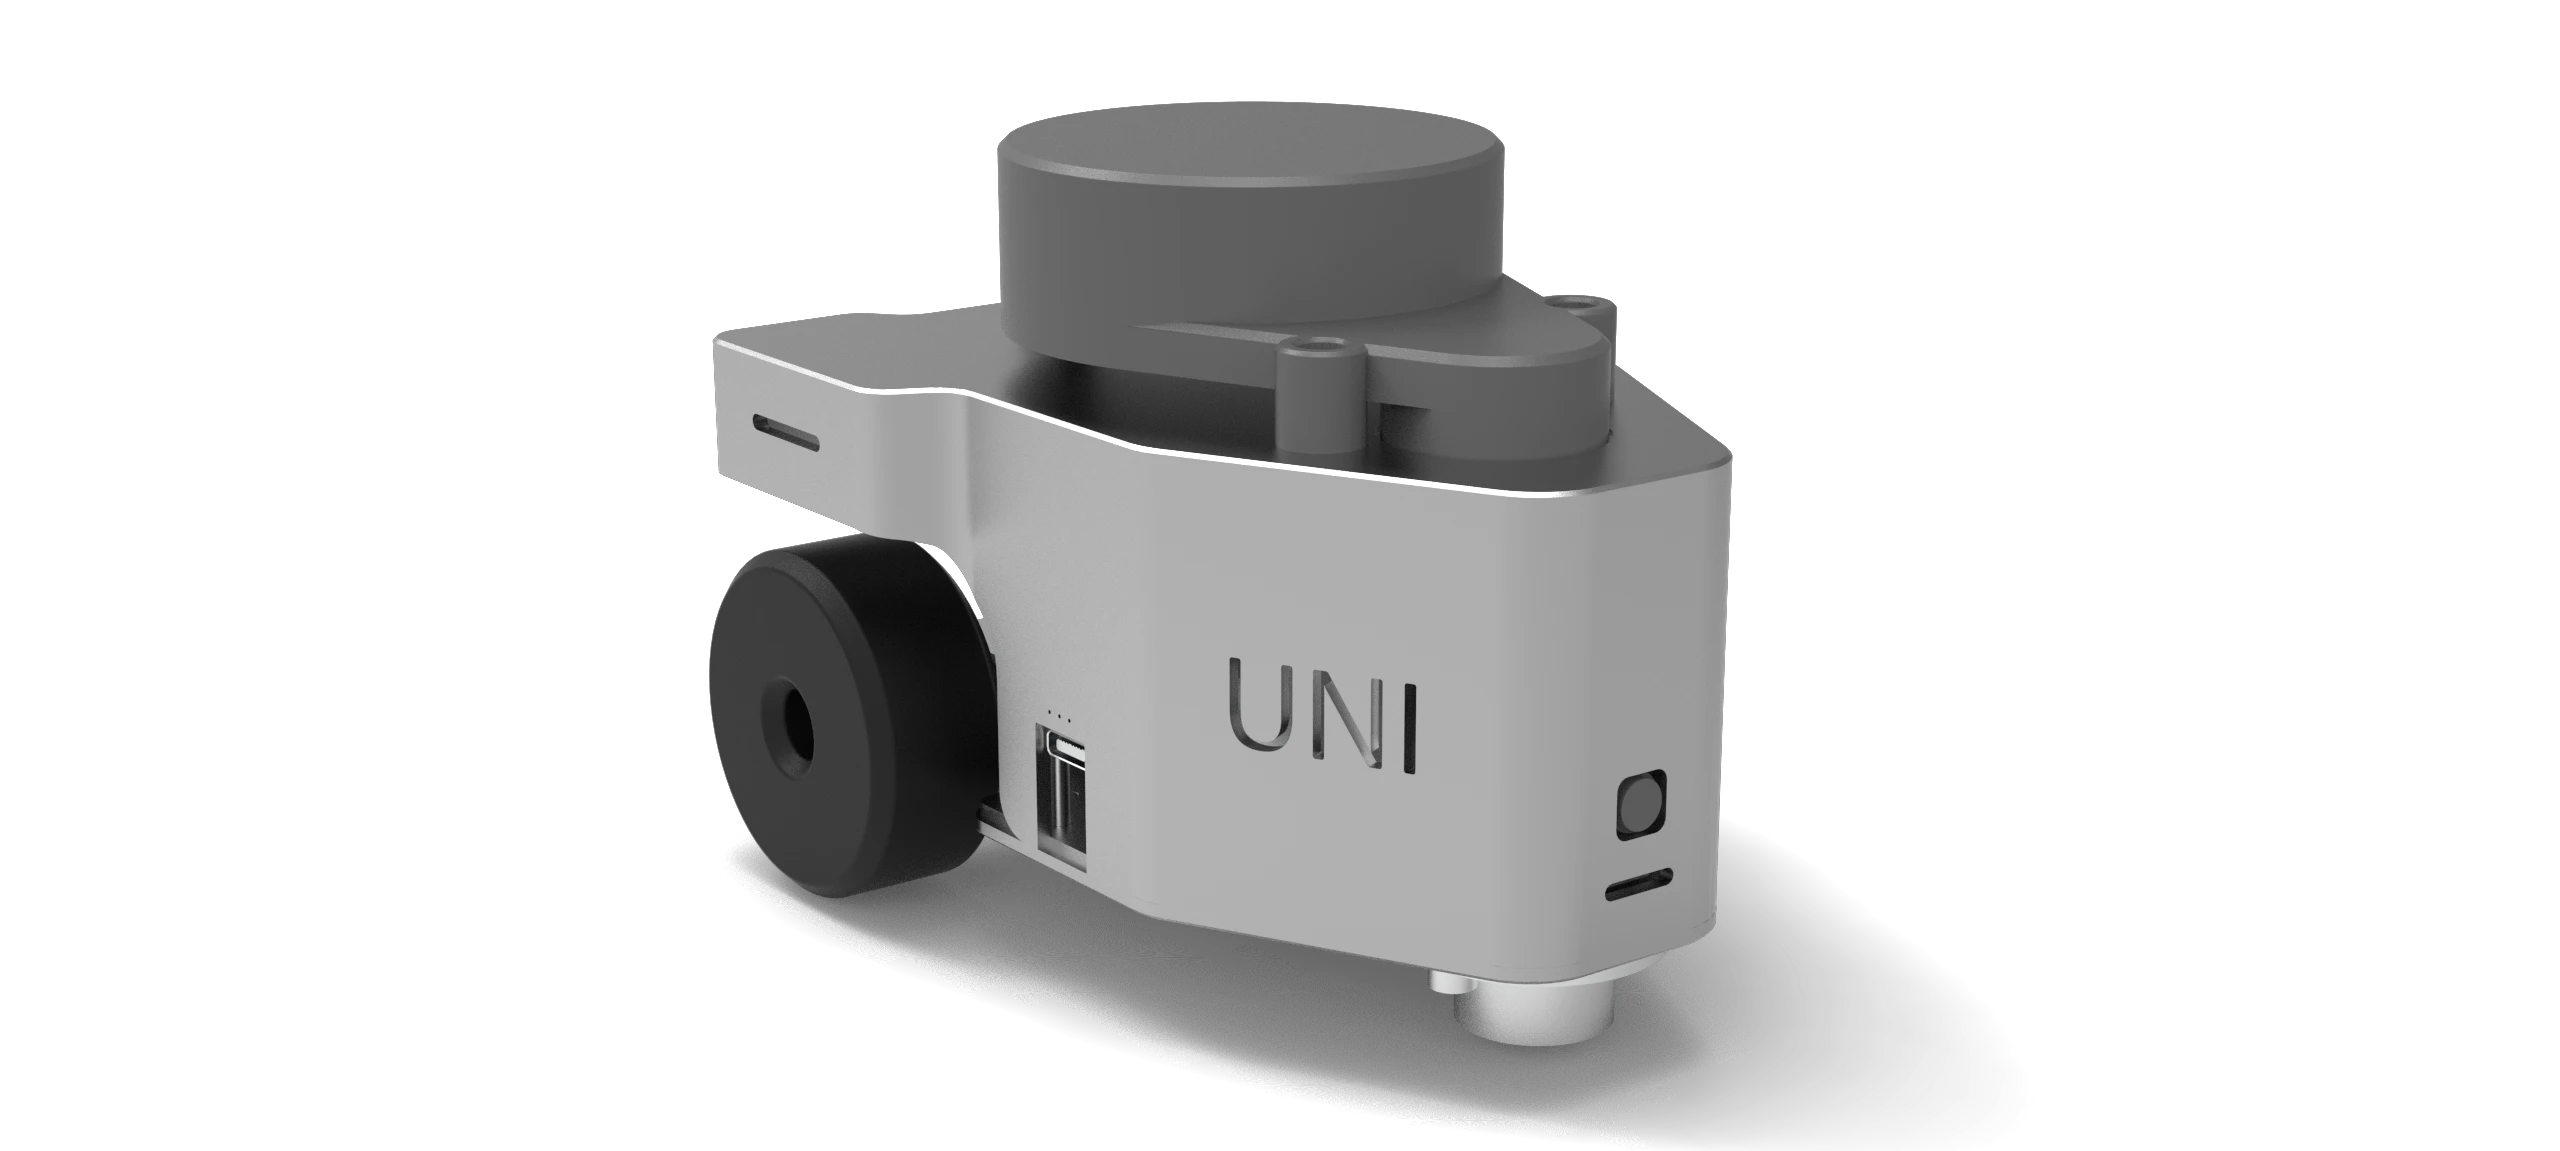
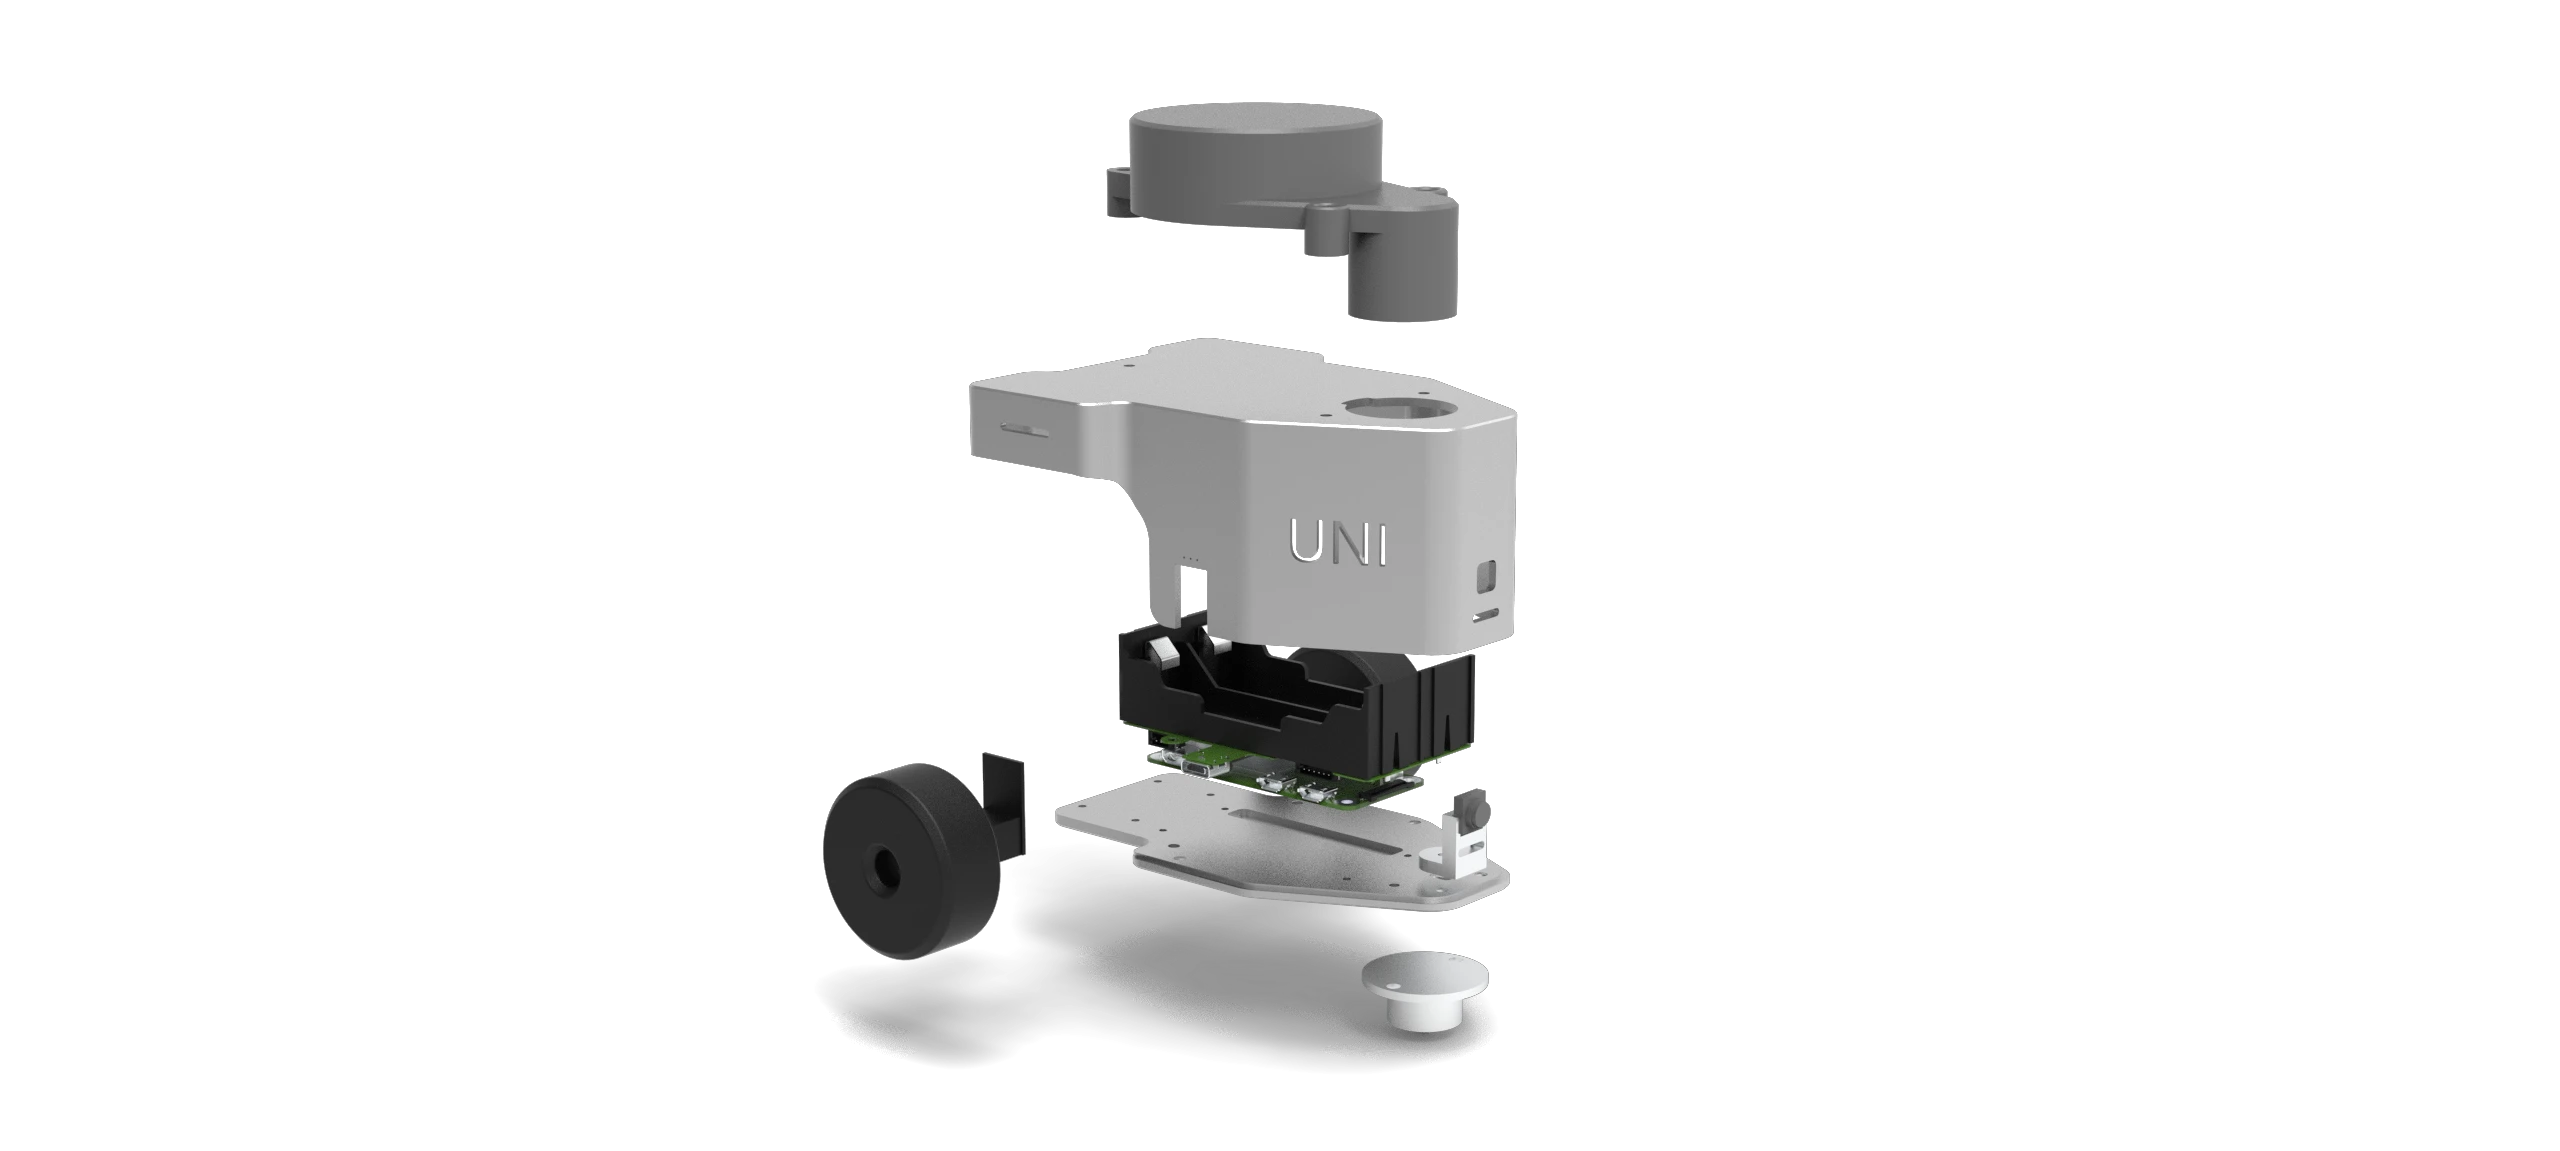
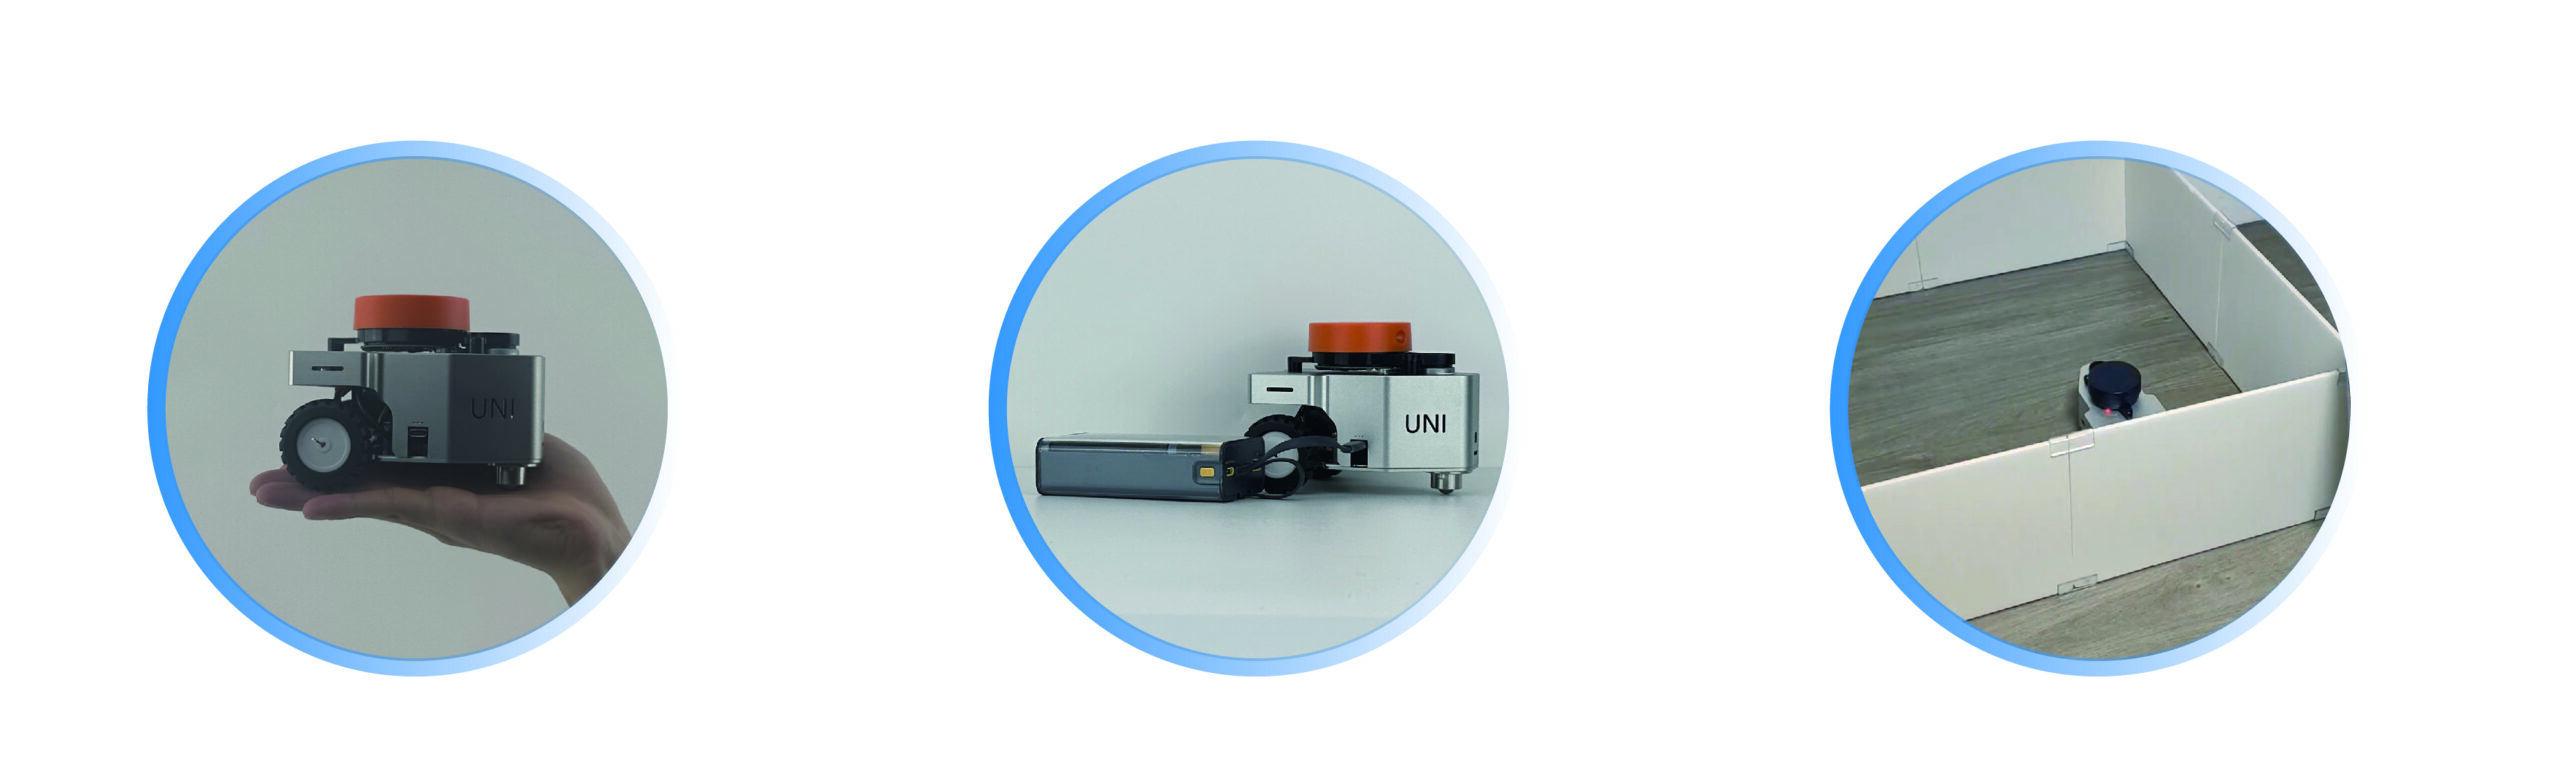
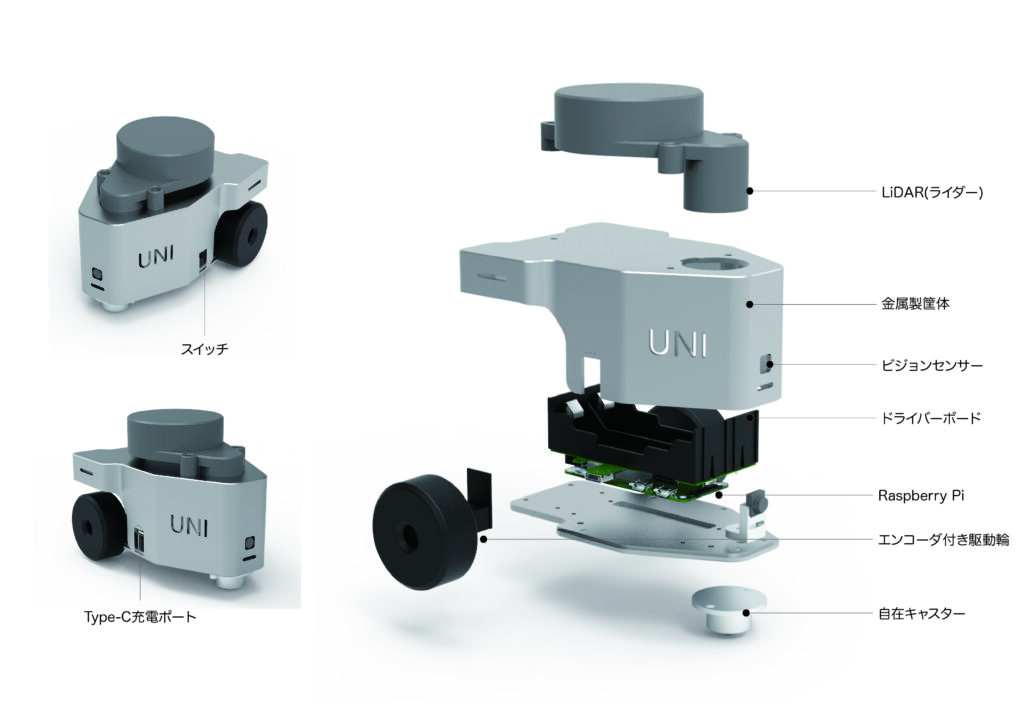
Featuring a compact full-metal body smaller than a human palm, the device includes a USB Type-C charging port and supports power delivery via mobile power banks. It is designed for rapid debugging across classrooms, laboratories, and on-site environments.
Desktop SLAM Lab Environment
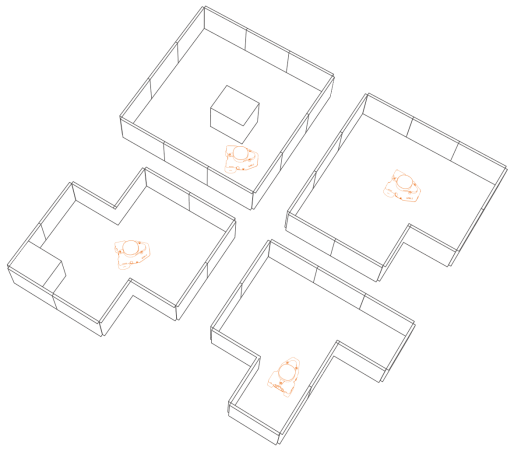
A SLAM environment that can be started on a compact 60 cm × 60 cm desktop. In addition to a reachable and compact operating area, it can be expanded up to 1.2 m × 1.2 m using modular panels. Enables rapid construction of diverse navigation courses.
Systematic Breakdown of ROS Implementation
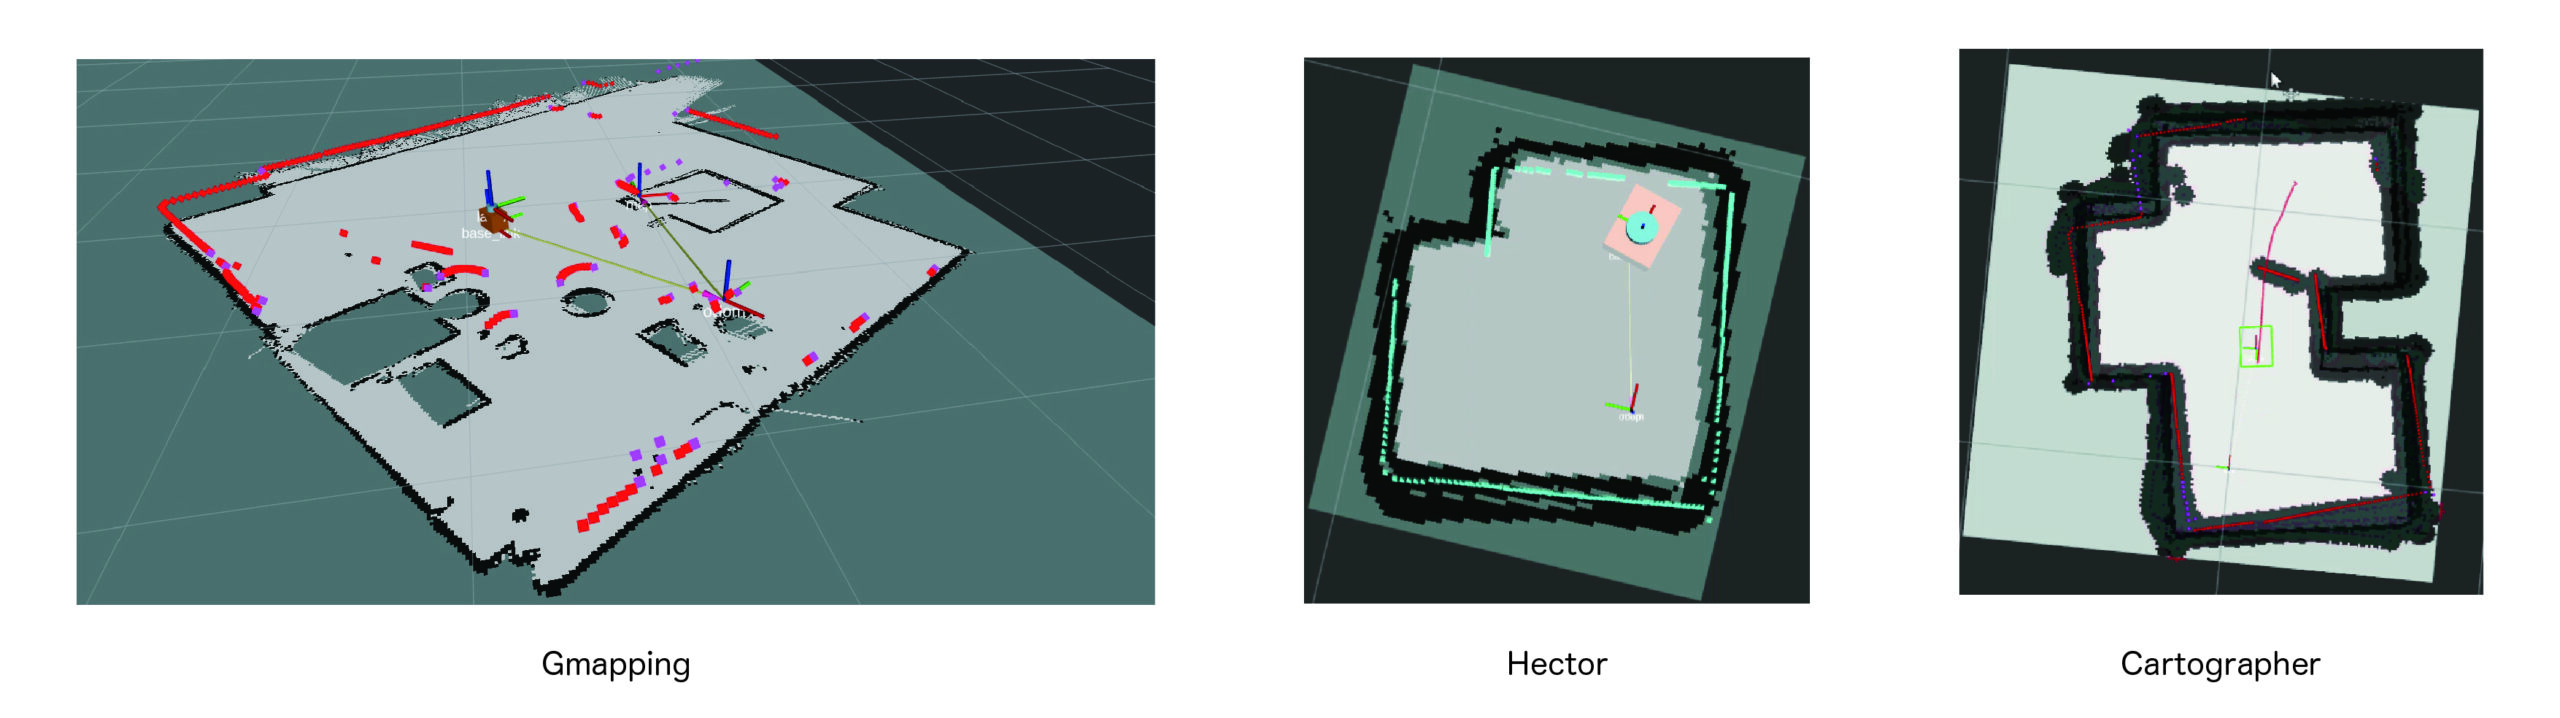
A five-stage learning path runs from principles and framework, through feature demos, structural breakdown and ROS package configuration, to full parameter tuning. Combined with the three major navigation algorithms — Cartographer, Hector and Gmapping — students learn real-world engineering implementation methods.
Specifications
Specifications
Basic Specifications
| OS Environment | Ubuntu / ROS (Pre-installed) |
|---|---|
| Configuration | Two-Wheel & Three-Wheel Differential Drive Chassis |
| Controller | Broadcom BCM2710A1, quad-core 64-bit SoC (Arm Cortex-A53 @ 1GHz) |
| Drive System | 7-Bit Encoder Motor |
| Chassis Configuration | 4-Wheel Mecanum Omnidirectional Chassis |
| Navigation System | Cartographer / Hector / Gmapping (Laser SLAM) |
| Maximum Stable Speed | 0.16m/s |
| Position Accuracy | Positioning error < 5 mm within 1 m range |
| Straight-Line Accuracy | Straight-line deviation < 1 cm over 1 m travel (approx. 1.5°) |
| Dimensions | 130mm(W) x 97mm(D) x 98mm(H) |
| Weight | 580g |
| Power Supply | Built-in Battery (≥4 Hours Continuous Operation), USB Type-C Charging |
| Accessories | USB Type-C Cable (Approx. 1.5 m) ×1 (AC Adapter Included) |
Sensor configuration
Sensor fusion for SLAM navigation integrates odometry feedback, pose estimation, and environmental mapping, enabling real-world data acquisition for navigation algorithms.
| Top-Mounted LiDAR Sensor | Outer diameter: 62 mm or less, range: 0.1–10 m, sampling frequency: 10 Hz |
|---|---|
| Wheel Encoder | Dual Configuration with PID Control and Odometry Feedback |
| IMU / Gyroscope Sensor | Supports Pose Estimation |
| Expansion Interface | Supports External Sensors and Marker Connectivity |
Control Configuration
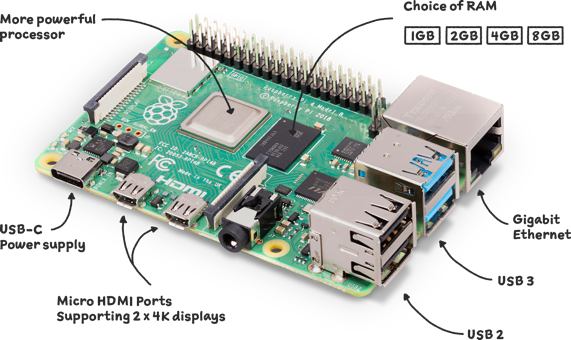
Built around a Raspberry Pi–based control architecture, integrating PID motor drivers and power management, with one-button boot and recovery for ease of use. Suitable for classroom demonstrations and scalable deployment.
Curriculum
Experiment Items
Robotic Vision
An integrated practical learning workflow covering everything from basic image processing to deep learning and multimodal perception.
■ OpenCV Vision
・Color Recognition / Shape Recognition / QR Code Recognition / Barcode Recognition
・Color Marker Detection (Integrated Processing + Filtering)
■ AI Vision - YOLO
・YOLO Model Integration and Deployment
・Dataset Annotation, Model Training, and Deployment
・Object Detection
・Face Detection
■ AI Vision - Qwen multimodal large model
・Integration and deployment of the Qwen multimodal API
・Object Detection and Labeling
Large-Scale Model Integration and Application
Focused on end-to-end AI model practice integrating voice interaction, multimodal perception, and robotic execution.
■ Voice Interaction
・Speech recognition (ASR) integration and implementation - Qwen
・Semantic understanding (LLM) deployment - DeepSeek
・Speech synthesis (TTS) integration and implementation - Volcano Engine
・LLM-Based Voice Interaction Implementation
・Implementation of Voice-Controlled Calculator Functionality
・Implementation of Voice-Controlled Music Playback
■ Multimodal Visual Perception
・Integration and deployment of the Qwen multimodal API
・Object Detection and Labeling
■ Integration with Robotic Applications
・MCP-Based Perception and Grasping Task Planning
・MCP-Based Navigation Task Planning
Robot Body
Robot Chassis and Arm Kinematics & Control Strategy Practice
■ Mobile Base Control
・Encoder-Based Motor PID Control
・Omnidirectional Base Kinematics Control
・Gyro-Assisted Odometry Control for Omnidirectional Mobile Base
■ Robot Arm Control
・Servo Motor Position Control
・Robot Arm Kinematics Control
・Robot Arm Trajectory Interpolation Control
ROS
Master core ROS skills including topic, service, and parameter management, as well as motion planning with MoveIt!.
■ Basic ROS Operations
・Turtlesim Control Using Topics, Services, and Parameters
・Package porting and execution - keyboard control of turtlesim
■ Robot Arm Motion Planning with MoveIt!
・Robot Arm URDF Configuration
・Robot Arm Kinematic Model Configuration with MoveIt!
・Robot Arm Motion Planning with RViz
Mobile Robot Navigation and Localization
Comprehensively covers system interfaces, mapping, and navigation workflows, enabling practical multi-point navigation implementation.
■ Mapping
・Map Project Settings
・New Map Construction
■ Navigation
・Point Navigation
・Autonomous Obstacle Avoidance Navigation
・Multi-Point Navigation
FAQ
UNI-WR2S FAQ
What is UNI-WR2S?
A palm-sized, portable desktop robot designed for ROS and SLAM navigation education. Students can test navigation algorithms and develop packages on a real robot right on their desk.
Which SLAM algorithms does it support?
It supports three laser SLAM algorithms: Cartographer, Hector and Gmapping. With LiDAR, wheel encoders and an IMU, position error is under 5 mm per 1 m traveled.
How much space does it need?
Experiments start on a 60 cm square desk area and expand up to 1.2 m square with modular panels. The robot measures 130×97×98 mm, weighs 580 g, charges via USB Type-C and runs for over 4 hours.
Which courses is it suited for?
Hands-on exercises for introductory ROS, mobile robot navigation and localization, and PID control. For adoption and demos, contact HumansX (https://humansx.co.jp/contact/).
Contact
Consultation on Deployment, Demos and Quotes
From product selection to integrating robots into your classes or research, feel free to contact us.