Physical AI Solution — Hand
Official Distributor in Japan — HumansXWuji Hand 2
A 20-DoF, direct-drive dexterous robotic hand
Paired with the Wuji Glove teleoperation glove for an end-to-end workflow from data collection to training
About
Human-level dexterity,
for research and development.
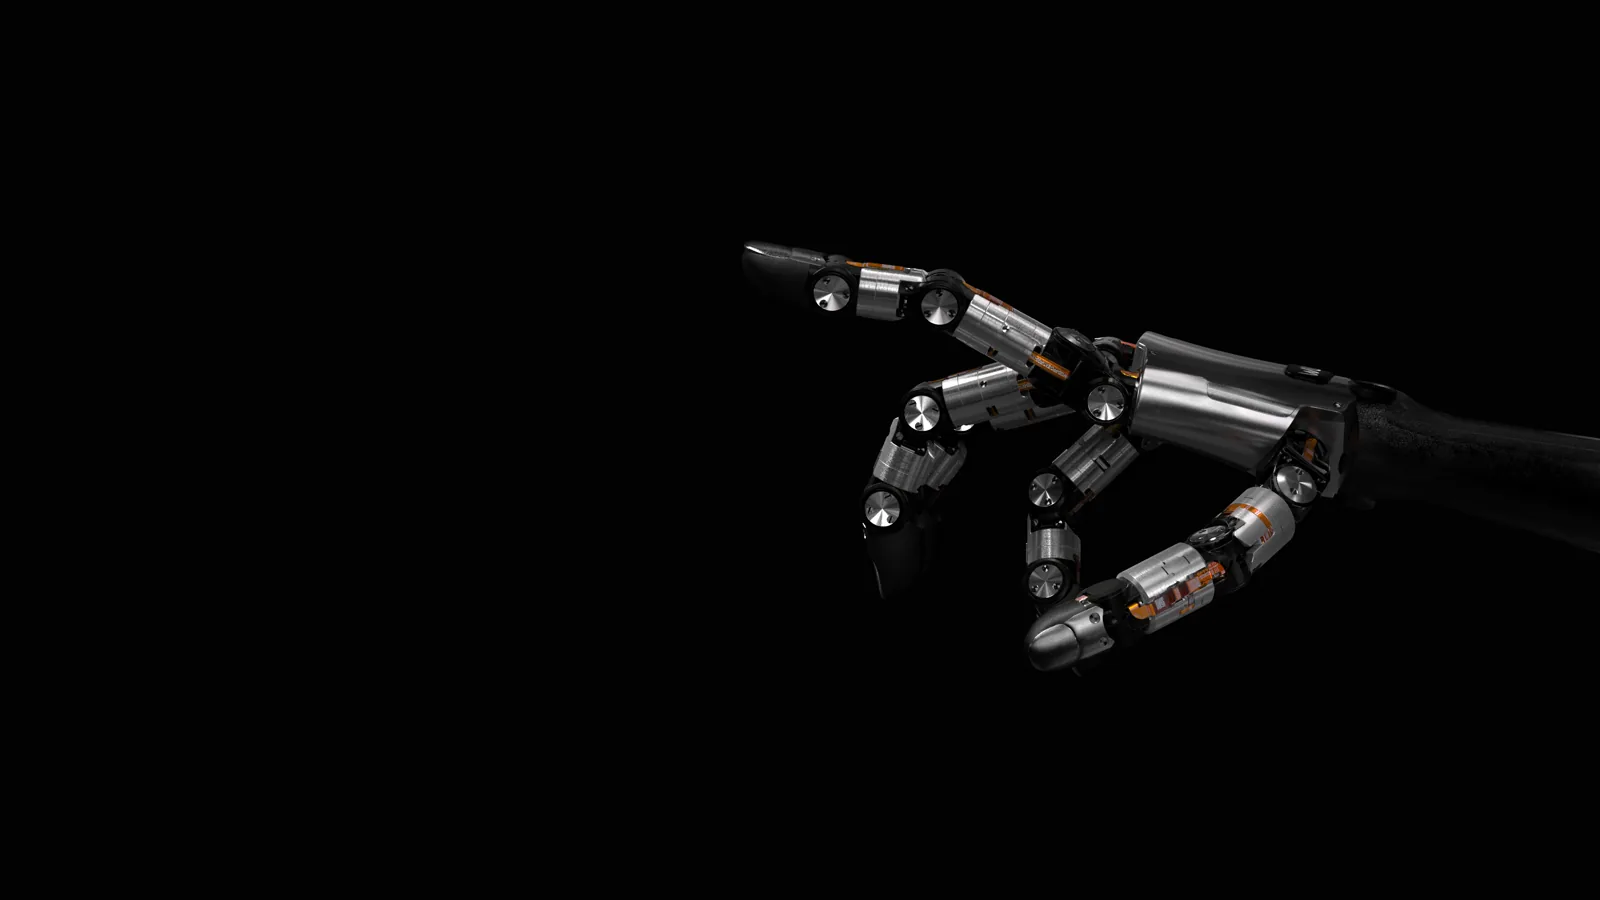
Wuji Hand 2 is a five-fingered dexterous robot hand developed by Wuji Technology. All 20 degrees of freedom (4 per finger) are directly driven by motors, reproducing full thumb opposition and finger abduction. MIT-style hybrid force/position control enables delicate pinching, twisting and pressing.
As the official distributor in Japan, HumansX supports you in Japanese from product selection and demos to post-installation technical support.
Core Technology
Four core technologies behind its dexterity
Biomimetic skeleton and soft skin
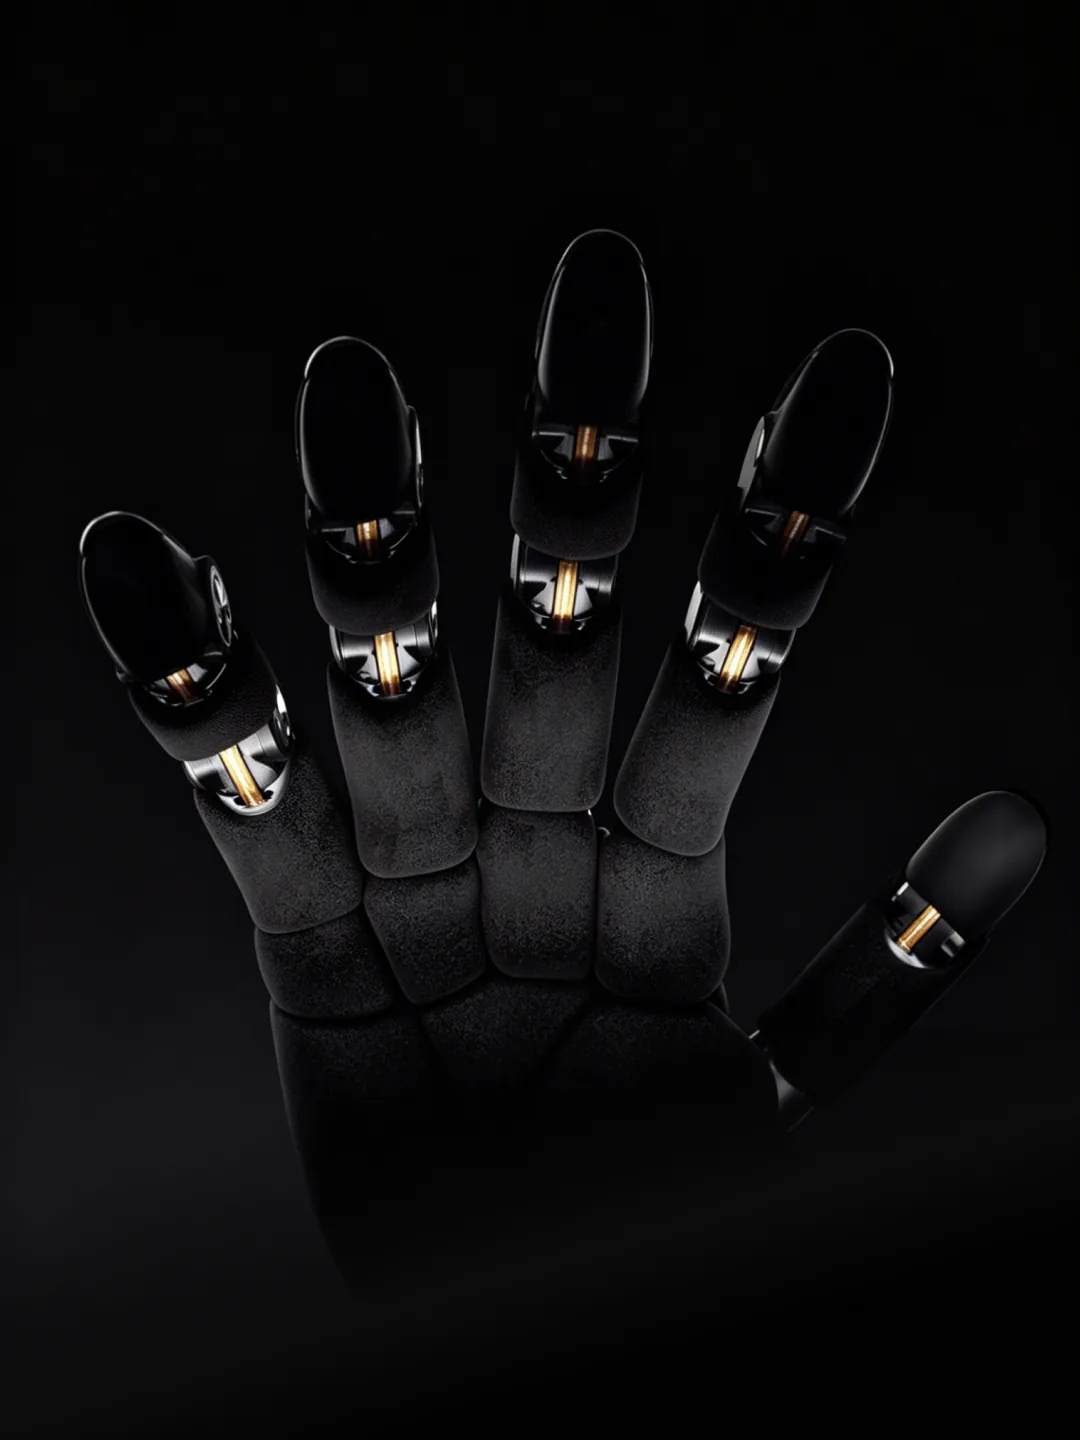
A three-layer structure of skeleton, soft pad and skin. Human-like compliance lets it grasp objects without damaging them.
Direct drive with high force transparency
Serial direct-drive joints with no nonlinear coupling mechanisms. Fully back-drivable, so external forces are sensed accurately.
Fingertips with multi-axis force sensing
Multi-axis force/torque sensors are built into the fingertips, supporting precise pinching and fine work using the fingernails.
Compact yet powerful
About 180 × 80 × 40 mm — close to a human hand — with fingertip peak force of 12 N or more and joint backlash under 1°.
Dexterity
20 DoF for a wide range of hand poses
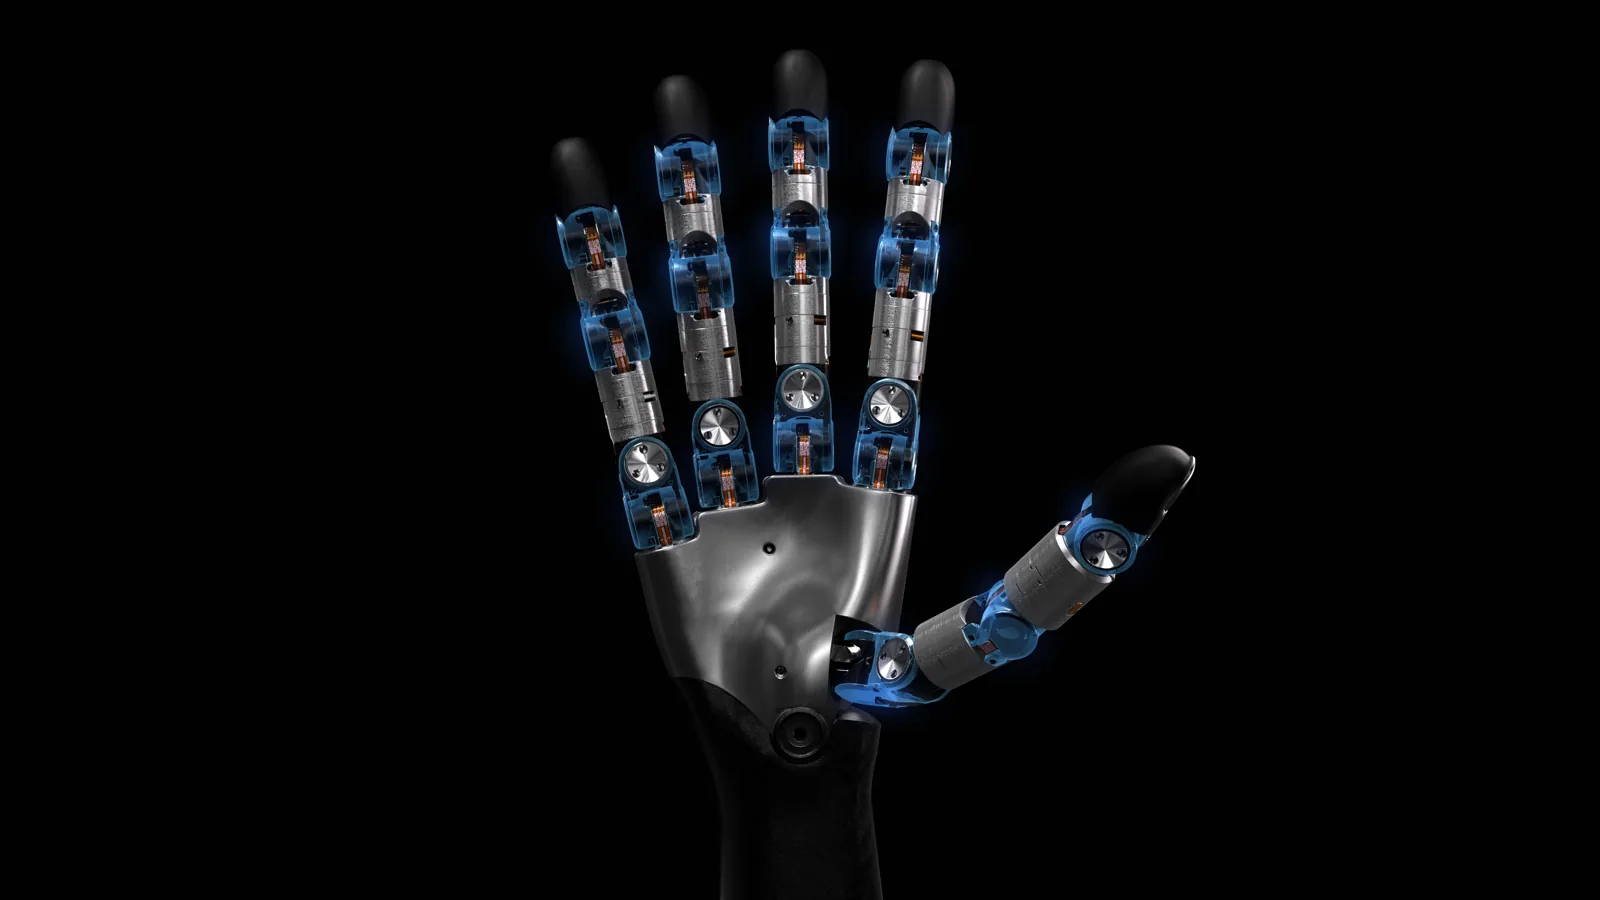
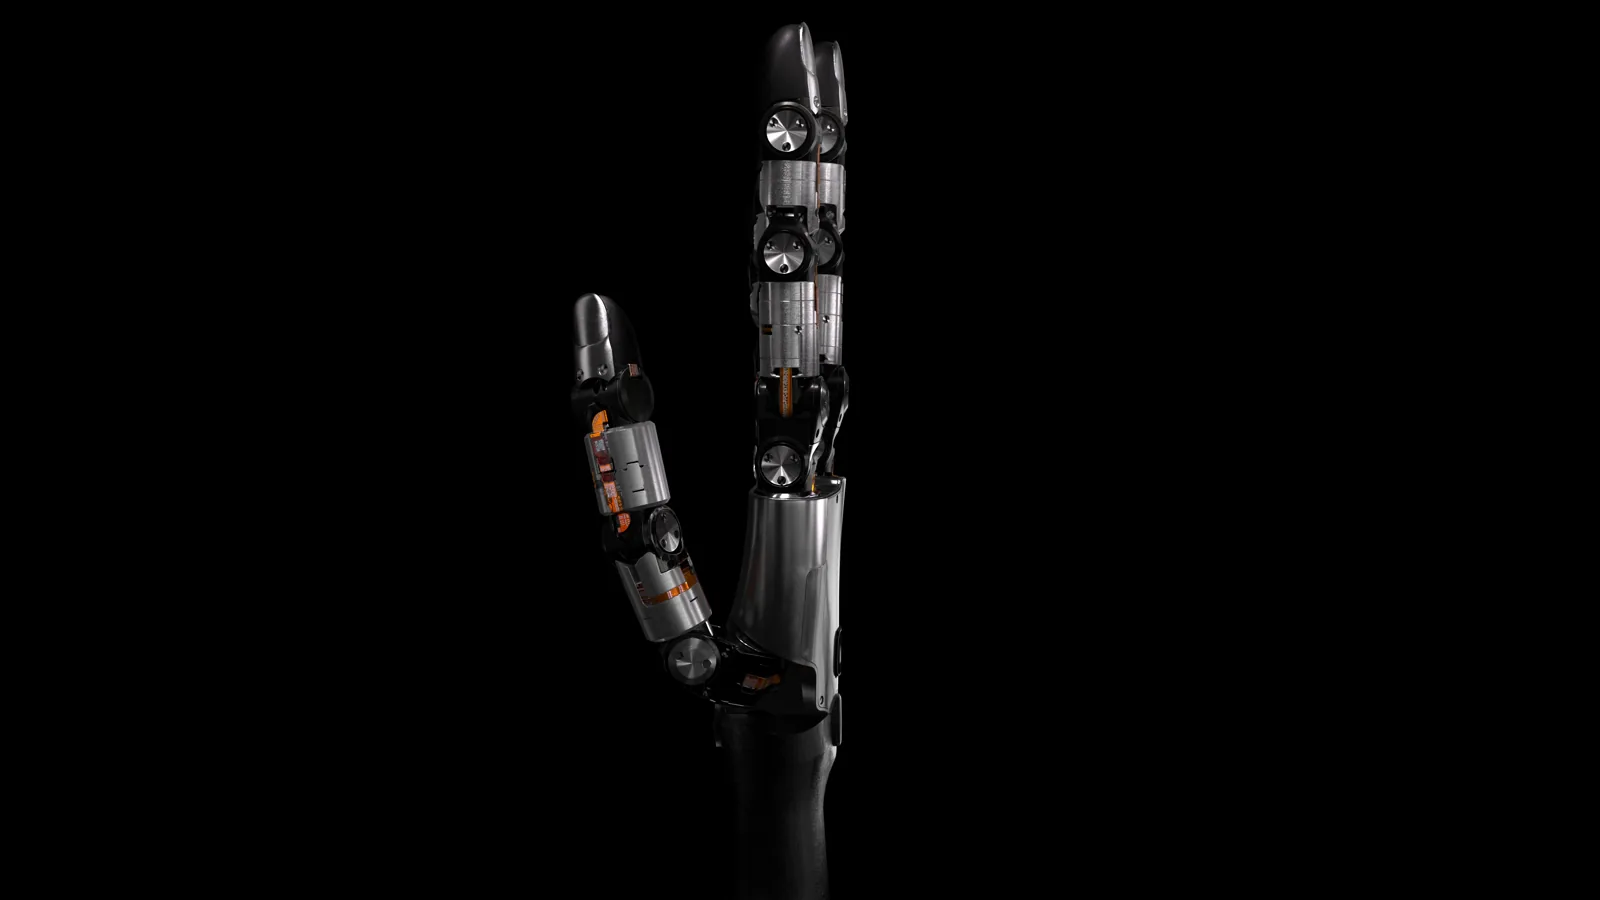
With 4 DoF per finger and 20 DoF in total, a single hand reproduces basic human hand motions such as pinching, grasping and pointing. Hover over the buttons below to see each motion in action.
* The 3D model is an illustration based on design data published by the manufacturer. The actual appearance and range of motion may differ.
Robustness
Designed for long-term, stable operation
From durability to ease of integration, it minimizes maintenance effort and recovery time after failures, so you can focus on your research and development.
Impact-resistant and durable
A robust structure that withstands contact and impacts during experiments.
Modular, quick assembly
The modular design makes part replacement and maintenance easy.
EtherNet communication
Stable connection to host systems via 100BASE-T (RJ45).
12 V DC power
Ships with a 12 V 20 A power adapter, ready to use out of the box.
Software Ecosystem
Covering the entire workflow, from development to training
Wuji SDK & CLI
Python / C interfaces for device discovery, state reading and command output. Real-time visualization provides one-stop development and debugging.
Native ROS 2 support
Integrates seamlessly into existing robot systems.
MuJoCo / Isaac Sim
High-fidelity simulation models in URDF, MJCF and USD formats for Sim-to-Real training.
Teleoperation
Supports teleoperation from multiple input devices, including the Wuji Glove.
Specifications
Wuji Hand 2 Main Specifications
| Structure | Active DoF | 20 DoF (4 per finger) |
|---|---|---|
| Finger configuration | Full opposition and lateral (abduction) movement | |
| Drive System | Direct-drive rotary joints (back-drivable) | |
| Dimensions | Approx. 180 × 80 × 40 mm | |
| Weight | Approx. 800 g (incl. soft pads and cables, excl. base) | |
| Min. grasping diameter | 0 mm | |
| Sensing | Fingertip force sensing | Multi-axis force/torque sensing |
| Control | Control rate | 1000 Hz × 20 axes |
| Control mode | MIT hybrid force-position control | |
| Performance | Fingertip peak force | ≥ 12 N |
| Open/close speed | ≥ 4 cycles/s | |
| Joint backlash | < 1° | |
| Communication & Power | Communication | EtherNet(100BASE-T / RJ45) |
| Operating voltage | 12 V DC | |
| Software | Supported environments | Python / C SDK、CLI、ROS 2、URDF / MJCF / USD |
* Specifications may differ from final production models. All parameters are subject to the actual sales model.
Wuji Glove
With a data glove,
human hand motion directly to robots.
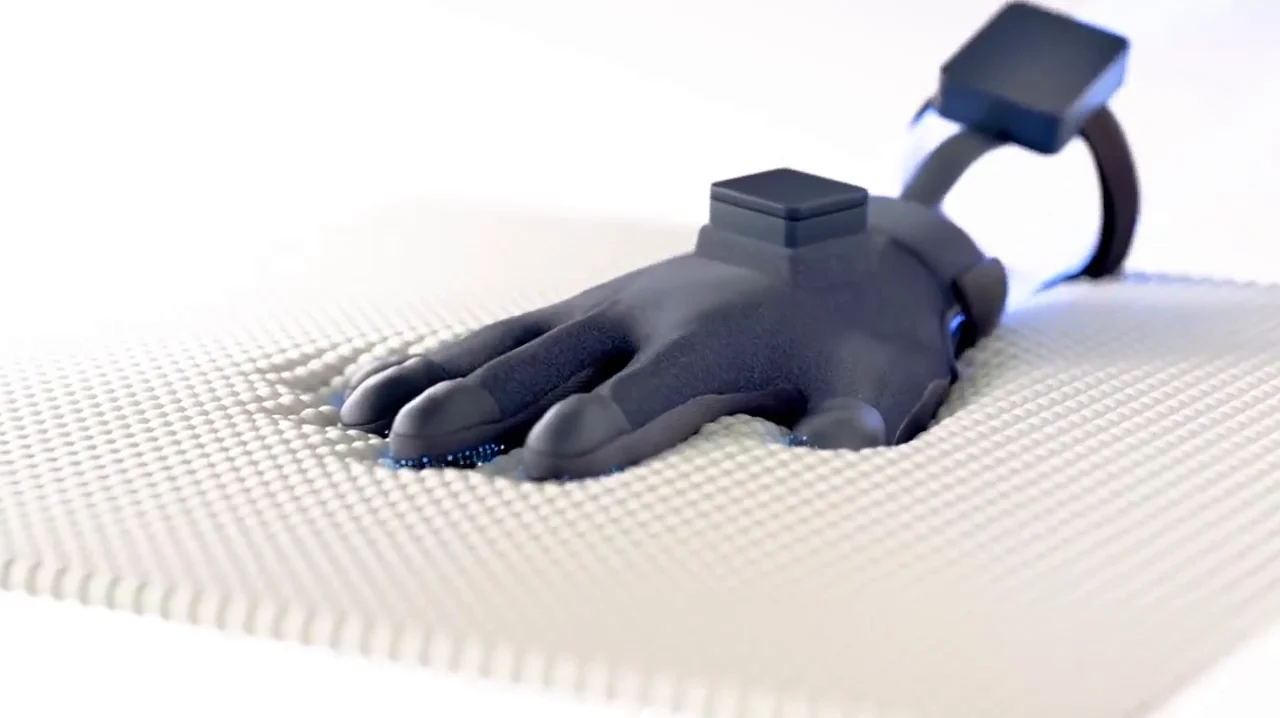
A teleoperation glove that captures fingertip position and orientation precisely with electromagnetic motion capture. Combined with Wuji Hand 2, it covers everything from collecting dexterous manipulation data to training.
- 6-DoF electromagnetic tracking, position accuracy ≤ 2 mm, orientation accuracy < 5°, 120 Hz output
- 6-axis wrist IMU (800 Hz); motion-to-data latency ≤ 10 ms
- Lightweight fabric design, glove body 67.5 g
- USB Type-C power, RJ45 (100BASE-TX) connection, Python SDK / CLI support
Capture human hand motion with the glove
Converted to robot hand joints in real time
Wuji Hand 2 reproduces the same motion
Train AI models with the collected data
Complete Solution
Wuji Hand 2 × Wuji Glove
Deploy it as a complete dual-arm system.
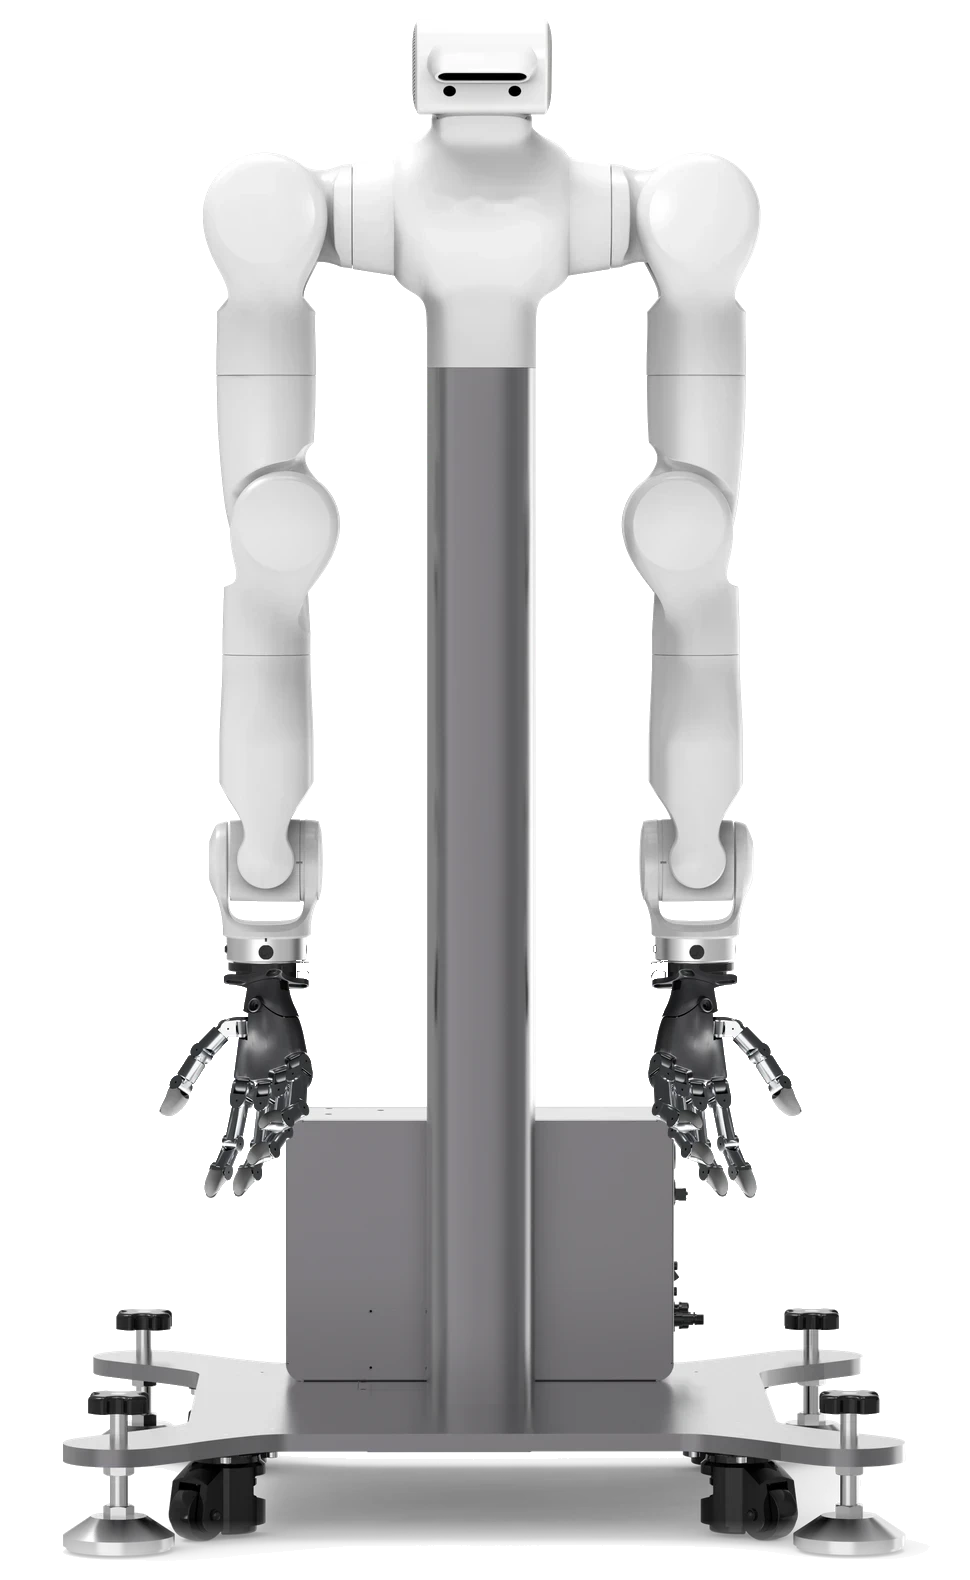
We also offer the Dual-Arm Data Collection System, combining a force-controlled dual-arm robot with Wuji Hand 2 (left & right), Wuji Glove, VR teleoperation and synchronized recording software. Start collecting bimanual data right after delivery, with no integration work.
Use Cases
Main Use Cases
- Research on embodied AI and dexterous manipulation at universities and research institutes
- Collecting imitation-learning data through teleoperation
- Mounting on humanoid robots as an end effector
- Sim-to-Real validation using simulation (MuJoCo / Isaac Sim)
- Technical validation toward automating precision tasks such as grasping and assembly
FAQ
Wuji Hand 2 FAQ
What is Wuji Hand 2?
A 20-DoF dexterous robot hand with direct drive on every joint, developed by Wuji Technology. It reproduces full thumb opposition and finger abduction for delicate pinching, twisting and pressing. HumansX is the authorized distributor in Japan.
What are the key specifications?
20 axes controlled simultaneously at 1000 Hz, fingertip peak force of 12 N or more, 4+ open/close cycles per second and joint backlash under 1°. It measures about 180×80×40 mm and weighs about 800 g.
Which development environments are supported?
Python / C SDKs and CLI with native ROS 2 support, plus URDF / MJCF / USD simulation models for MuJoCo and Isaac Sim.
Can it be used for teleoperation and data collection?
Yes. Combined with the Wuji Glove data glove, human hand motion is mirrored to the robot hand in real time, and you can collect manipulation data for imitation learning.
Contact
Contact us for pricing and lead times
For pricing, lead times and demo units of Wuji Hand 2 and Wuji Glove, please contact HumansX, the official distributor in Japan.