Physical AI Solution — Data Glove
Official Distributor in Japan — HumansXWuji Glove
Fingertip position, orientation and hand motion, captured as data.
A data glove for teleoperation and imitation-learning data collection
About
Human hand motion,
captured exactly as it moves.
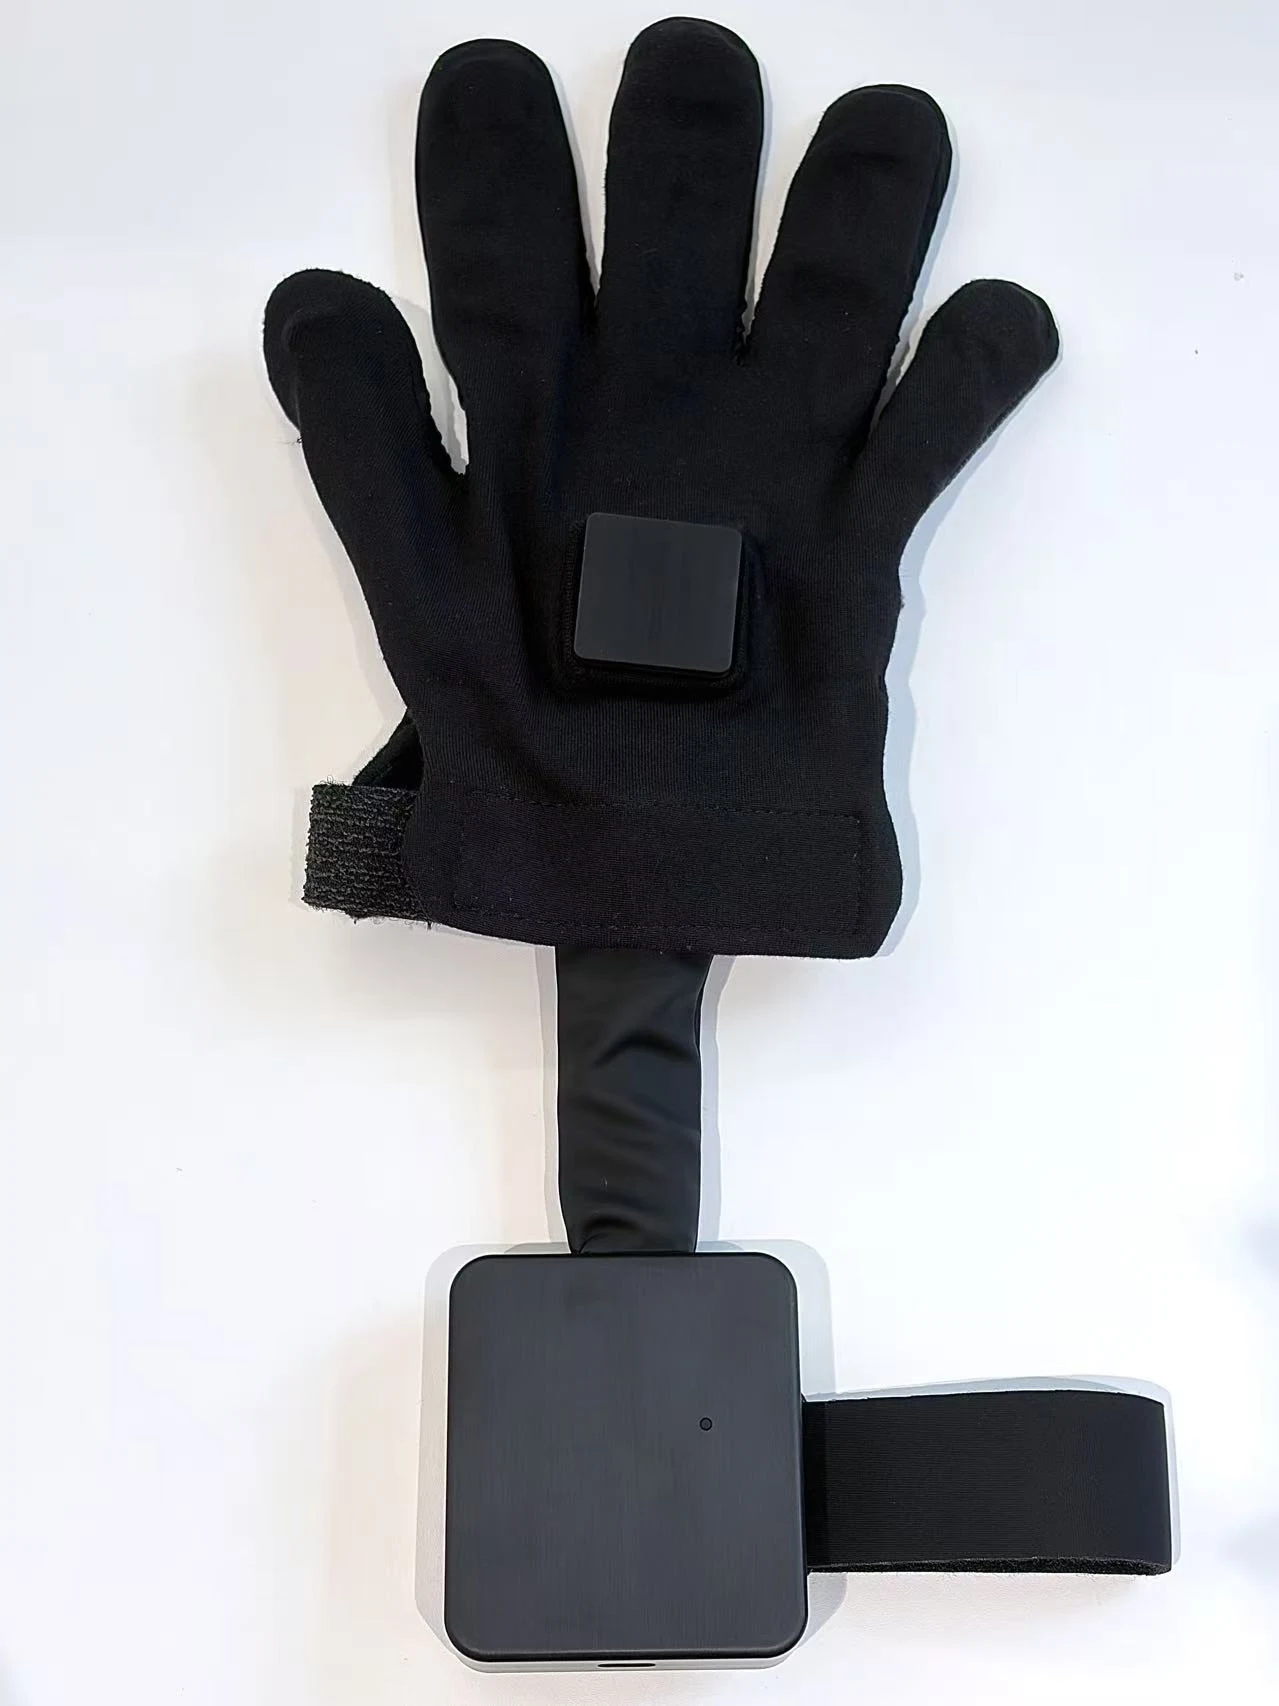
Wuji Glove is a data glove developed by Wuji Technology. Electromagnetic (EMF) tracking on the five fingertips and the back of the hand captures hand position, orientation and each finger's joint angles in real time.
Use it to teleoperate multi-fingered robot hands, or on its own for data collection and research. As the authorized distributor in Japan, HumansX supports you from product selection and demos to post-installation technical support.
Core Technology
Four core technologies for high-quality manipulation data
Electromagnetic motion tracking
6-DoF electromagnetic (EMF) receiver modules on the fingertips and back of the hand. Position accuracy ≤ 2 mm and orientation accuracy < 5° capture hand motion with far less drift accumulation than IMU-only designs.
Real-time whole-hand analysis
Sensor data and kinematic algorithms compute each finger's flexion, abduction and the overall hand pose in real time through inverse kinematics.
Low latency with IMU
Combined with a 6-axis IMU, motion-to-data latency is ≤ 10 ms (wired), enabling real-time teleoperation.
Lightweight, all-fabric
Glove body 67.5 g, fabric thickness 6.55 mm. The soft fabric fits the hand and keeps the wearer comfortable through long data-collection sessions.
Teleoperation × Wuji Hand 2
Human hand motion,
transferred straight to the robot hand.
Paired with the 20-DoF Wuji Hand 2, it delivers an end-to-end workflow from collecting dexterous manipulation data to training AI models. Gesture control and teleoperation with Apple Vision Pro are also supported.
Capture human hand motion with the glove
Converted to robot hand joints in real time
Wuji Hand 2 reproduces the same motion
Train AI models with the collected data
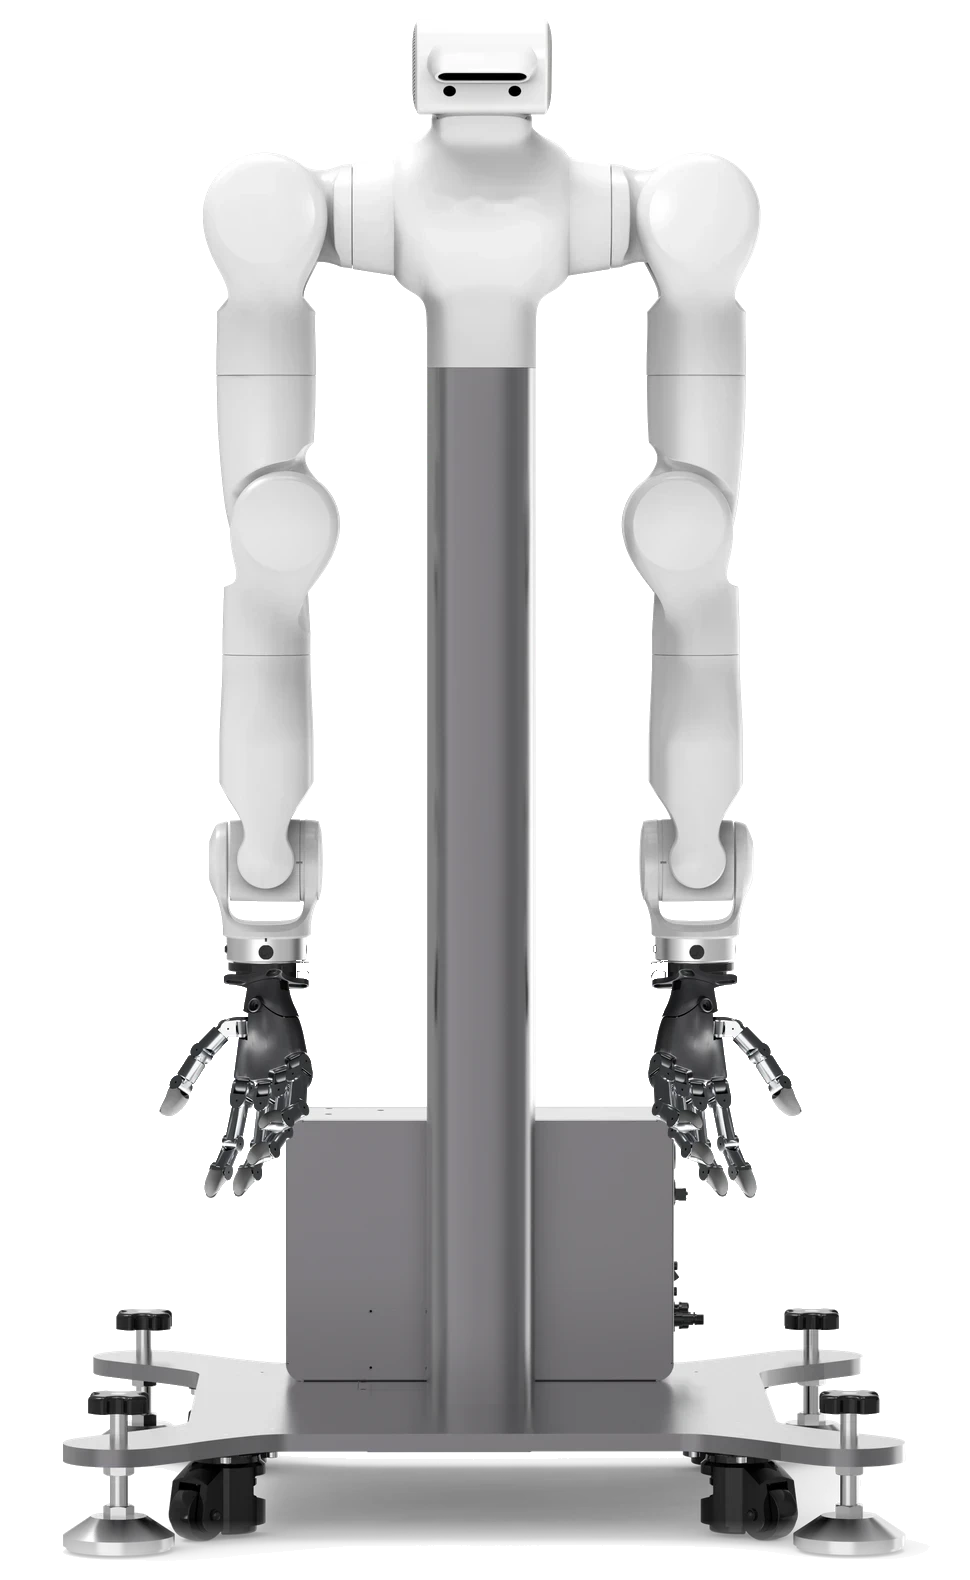
Complete Solution
Wuji Hand 2 × Wuji Glove
Deploy it as a complete dual-arm system.
We also offer the Dual-Arm Data Collection System, combining a force-controlled dual-arm robot with Wuji Hand 2 (left & right), Wuji Glove, VR teleoperation and synchronized recording software. Start collecting bimanual data right after delivery, with no integration work.
Use Cases
Main Use Cases
Data collection
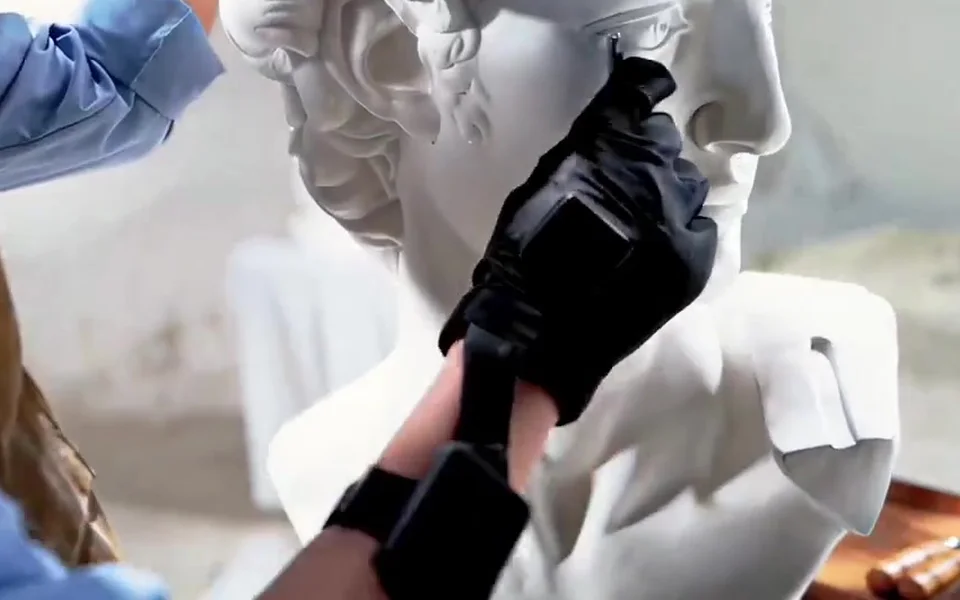
Record human hand motion during work as imitation-learning data.
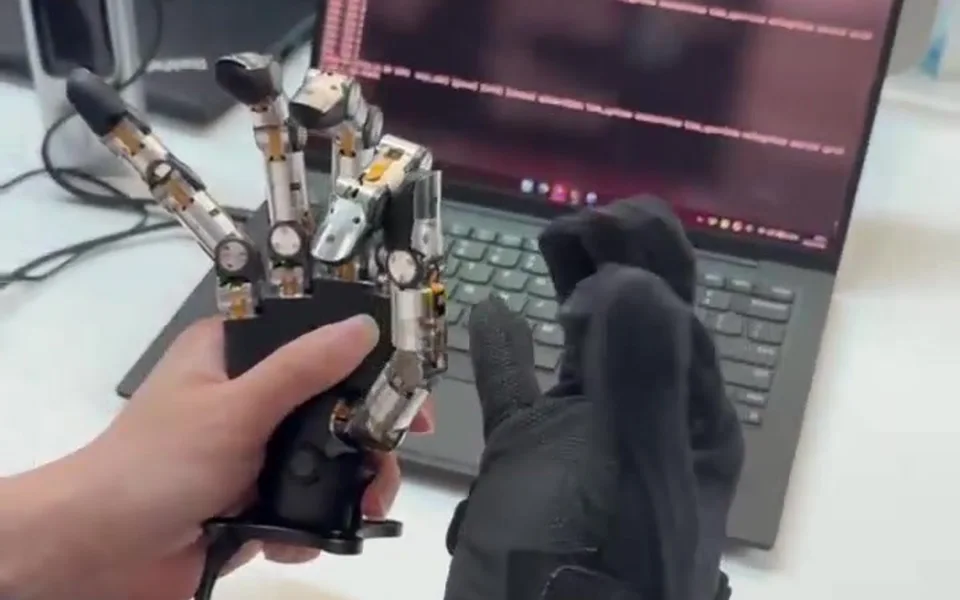
Teleoperation
Control multi-fingered robot hands such as Wuji Hand 2 in real time.
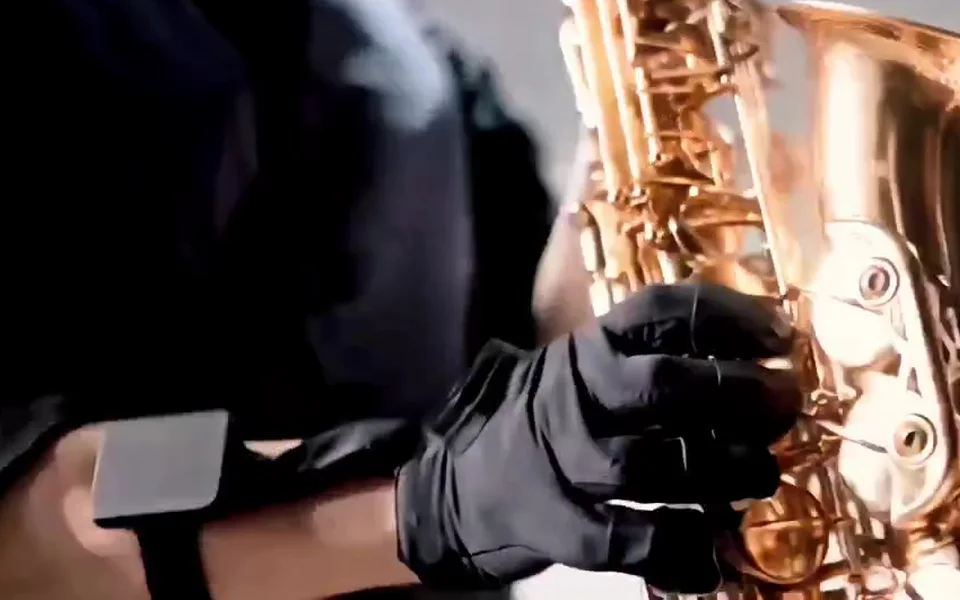
HCI and ergonomics research
Quantitatively analyze how force is applied and how the hand is used during grasping and manipulation.
VR / AR
Gesture control and teleoperation with Apple Vision Pro.
Specifications
Wuji Glove Key Specifications
| Dimensions & weight | Size (L × W) | 215 × 195 mm |
|---|---|---|
| Thickness (fabric / structure) | 6.55 mm / 35 mm | |
| Total length (incl. cable) | 340 mm | |
| Weight | Glove 67.5 g / with cable 192.6 g | |
| Tracking | Electromagnetic (EMF) | 5 receiver modules (6 DoF each) |
| Position / orientation accuracy | ≤ 2 mm RMS / < 5° RMS | |
| Tracking range | Within 30 cm | |
| Latency (wired) | ≤ 10 ms | |
| Output rate | 120 Hz | |
| IMU | 6-axis IMU | |
| Communication & Power | Communication | Ethernet (100BASE-TX / RJ45, via included adapter) |
| Power Supply | USB Type-C (5 V / 1 A) | |
| Software | Supported environments | Wuji Studio, Python SDK / CLI, ROS 2 (Windows / Linux) |
| Integrations | Wuji Hand 2, Apple Vision Pro | |
| Environment | Operating temp. / humidity | -5 to 40 °C / below 55 %RH |
| Accessories | Pair (L/R) | Glove (1 left, 1 right), data collection boards (with arm straps), USB-C – Ethernet power adapters, USB-C to USB-C cables, USB power cables, LAN cables, carrying case |
* EMF sensors are affected by metal and ferromagnetic materials; keep them at least 3 cm away. To obtain absolute wrist position, use an external tracker (mounting interface provided).
* Sold only as a left/right pair; single-hand units are not available. Specifications are subject to change without notice. Final specifications follow the production model.
Comparison
Compare with other
data gloves
We compare Wuji Glove, LITCHI T1 Pro and MANUS Metagloves Pro on tracking method, latency and camera integration, with guidance on choosing by use case.
- Wuji Glove: high-precision teleoperation and data collection (with Wuji Hand 2)
- LITCHI T1 Pro: wireless, low-latency teleoperation and on-site data collection synced with a first-person camera
- MANUS Metagloves Pro: motion capture & VR
FAQ
Wuji Glove FAQ
What is Wuji Glove?
A data glove that records fingertip position, orientation and whole-hand motion using electromagnetic motion tracking. Developed by Wuji Technology and sold and supported by HumansX as the authorized distributor in Japan.
How does the tracking perform?
Output rate is 120 Hz. Electromagnetic tracking gives fingertip position accuracy of 2 mm or better, with motion-to-data latency of 10 ms or less (wired).
Which robot hands can it be paired with?
It supports real-time teleoperation of the 20-DoF Wuji Hand 2 and gesture control with Apple Vision Pro, and can also be used on its own for data collection and research.
Can I use it without a robot hand?
Yes. Wuji Glove records the position and orientation of each finger and the joint angles of the whole hand on its own, so you can collect human hand-motion data without connecting a robot hand. Use Wuji Studio or the Python SDK to record and review data.
What development environment does it use?
Wuji Studio, Python SDK / CLI and ROS 2 (Windows / Linux). Communication is via Ethernet and power via USB Type-C (5 V / 1 A).
Contact
Contact us for pricing and lead times
For Wuji Glove pricing, lead times and demo units, contact HumansX, the authorized distributor in Japan.