Physical AI Solution — Data Glove
Official Distributor in Japan — HumansXLITCHI T1 Series
Teleoperation and imitation learning data collection in one glove. Wireless and low-latency, it captures hand motion with high precision,
用途に合わせて T1 Lite・T1・T1 Pro(触覚センシング搭載)の3モデルから選べます
Developer: LITCHI / HumansX handles sales and deployment support as the authorized distributor in Japan
Movie
LITCHI T1 Pro プロモーション動画
無線・低遅延のモーショントラッキング、高密度の触覚センシング、マイクロ秒級の両手同期まで。T1 Proの特長を約1分でご紹介します。
Data in Action
Capture all of this data from a single task
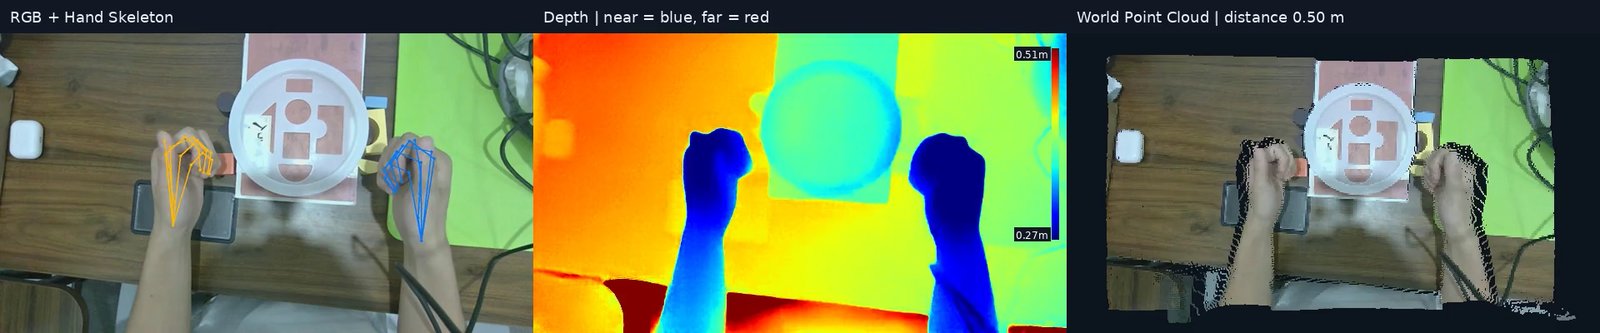
RGB video (left), optimized depth (center) and world-coordinate point cloud (right) collected at a real work site. Glove and Ego device data are recorded in sync.
About
Human hand motion,
straight into robot training data.
The LITCHI T1 Series is a glove for teleoperation and data collection developed by LITCHI, a Physical AI infrastructure company with the motto “Let Intelligence Flow”. Multi-IMU pose tracking reproduces hand motion with high precision, and by syncing with the first-person (Ego) data collection device it records both “what the operator sees” and “how the hands move” at real work sites.
It captures data reliably even near motors and high-current wiring, making it well suited to teleoperation close to robots. LITCHI runs its own end-to-end collection, processing and quality control of real-task data, and the T1 is the equipment used in that work. As the authorized distributor in Japan, HumansX supports you in Japanese from product supply to collection setup and technical support.
Demo: a single T1 glove teleoperating several robot hands with different designs at the same time
Model Lineup
Three models for different applications
T1 Lite|軽量モデル
7 IMU による軽量なモーションキャプチャ。遠隔操作、ジェスチャー取得、模倣学習の入門に。
T1|高精度モデル
11 IMU で指1本1本の細かな動きまで記録。静的姿勢精度 0.05° 以下、無線伝送遅延 2 ms。※触覚センサは非搭載(IMU のみ)。
T1 Pro|IMU+触覚 フル機能モデル
11 IMU に加え、手のひら全面 368 点(600 点に拡張可)の触覚センサで、どこに・どれだけの力で触れたかまで記録。
触覚・接触力のデータが必要な場合は T1 Pro、または Wuji Glove をお選びください。モデルごとの違いは下記の仕様表をご覧ください。
Ego Device
Ego データ収集デバイス「LITCHI EGO」と組み合わせて
A data collection device that records hands-on work from a first-person view. Four wide-angle RGB cameras and one structured-light stereo depth camera capture tasks within 1.5 m in 3D, recorded in sync with T1 glove data.
- RGB × 4 + depth camera × 1
- Built-in 9-axis IMU and four microphones
- Weight under 400 g
First-person video and depth
A hybrid of four wide-angle RGB surround cameras and one structured-light stereo depth camera, accurately recording close-range work within 1.5 m.
- RGB up to 1920 × 1200 @ 30 fps, global shutter
- Depth 1280 × 800 @ 30 fps, spatial accuracy < 0.5% (at 1 m)
- Weight under 400 g
Glove, video and audio in sync
Equipped with a 9-axis IMU (500 Hz) and four microphones. Image-to-IMU sync error is under 1 ms, and external trigger signals are supported.
- Image-to-IMU sync error < 1 ms
- External trigger supported
- Video encoding H.264 / H.265
Multimodal Data
Training-ready data from a single task
For the same task, RGB video, optimized depth and world-coordinate point clouds are recorded in sync.
Vision
First- and third-person RGB, raw and optimized depth, IMU.
Motion & contact
手の関節、3次元位置姿勢、触覚。
Space & objects
Camera pose, 6-DoF pose of manipulated objects, scene point cloud.
Task annotation
Task instructions, subtasks, atomic actions, states and outcomes.
Use Cases
Use cases
- Data collection for imitation learning of humanoids and dual-arm robots
- Motion recording at real work sites such as factories, logistics and food processing
- Teleoperation of multi-finger robot hands
- Building first-person data for foundation models such as VLA
Specifications
T1 Series key specifications
| T1 Lite | T1 | T1 Pro | |
|---|---|---|---|
| 位置づけ | 軽量モーションキャプチャ | 高精度モーションキャプチャ | IMU+触覚 フル機能 |
| IMU configuration | 7 IMU | 11 IMU | 11 IMU |
| センサフュージョン | 6軸 | 6軸 | 6軸 |
| Sampling | IMU 1000 Hz/姿勢推定 500 Hz | IMU 1000 Hz/姿勢推定 500 Hz | IMU 1000 Hz / pose estimation 500 Hz / tactile 200 Hz (expandable to 400 Hz) |
| Static attitude accuracy | ≤ 0.05° (roll / pitch) | ≤ 0.05° (roll / pitch) | ≤ 0.05° (roll / pitch) |
| Tactile sensor | — | — | Full palm, 368 points (expandable to 600), 9 points/cm², detection 30 g–1500 g, repeatability ±15% FS |
| Communication | 無線(PHY 6.8 Mbps)・伝送遅延 2 ms | 無線(PHY 6.8 Mbps)・伝送遅延 2 ms | 無線(PHY 6.8 Mbps)・伝送遅延 2 ms |
| Sync | 同期誤差 < 1 ms | 同期誤差 < 1 ms | Sync error < 1 ms, left-right hand sync at microsecond level |
| 全データチャネル出力 | 100 Hz | 100 Hz | 100 Hz |
| Magnetic interference countermeasures | — | — | Supported (no magnetometer / reduced weighting) |
| Robot environment | Stable capture even near motors and high-current wiring | Stable capture even near motors and high-current wiring | Stable capture even near motors and high-current wiring |
| Main Applications | 遠隔操作・ジェスチャー取得・模倣学習 | 遠隔操作・高精度ジェスチャー取得・模倣学習 | 器用な操作の学習・エンボディドAIデータセット・動作と力の解析 |
Ego Data Collection Device (EgoDepth)
| Hardware | Wide-angle RGB surround camera × 4 + structured-light stereo depth camera × 1 |
| RGB × 4 + depth, IMU, audio / under 400 g | |
| Depth | 1280 × 800, 848 × 480, 640 × 480 @ 30 fps (Y16) |
| H 90°, V 65° / spatial accuracy < 0.5% (at 1 m) | |
| RGB (per camera) | Up to 1920 × 1200 @ 30 fps, global shutter |
| H 165°, V 130° / tilted 30° downward | |
| IMU & sync | DCM630 9-axis, 500 Hz |
| Image-to-IMU sync error < 1 ms, external trigger supported | |
| Processing & connectivity | RK3576 (8-core, 6 TOPS NPU) / 2 GB LPDDR4X + 64 GB eMMC (TF card supported) |
| Wi-Fi 6, Bluetooth 5.4, USB 3.0 (host / device) | |
| Software | Orbbec SDK supported / video MP4, PTS / IMU CSV, audio files |
| Audio | 4 / 1 W, 8 Ω |
* Manufacturer’s published values (based on in-house lab tests). Please contact us for detailed specifications, configurations and pricing. Specifications are subject to change without notice.
※ 製品カタログ(T1 Pro・日本語版 PDF)と T1 シリーズ仕様書(英語版 PDF)は、サポートセンターからダウンロードいただけます。
Comparison
Compare with other
data gloves
Wuji Glove・LITCHI T1 Pro・MANUS Metagloves Pro を、トラッキング方式・触覚・遅延・カメラ連携などの観点で比較した表と、用途別の選び方をまとめました。
- Wuji Glove: teleoperation and data collection with tactile sensing (Wuji Hand 2 integration)
- LITCHI T1 Pro: wireless, low-latency teleoperation and on-site data collection synced with a first-person camera
- MANUS Metagloves Pro: motion capture & VR
FAQ
FAQ
T1 Pro 1台で何が記録できますか?
11 IMU による手指の関節・3次元姿勢・両手の同期動作に加え、手のひら全面 368 点の触覚データを同時に記録できます。頭部装着型の LITCHI EGO と組み合わせれば、一人称視点の映像・深度まで同じ時間軸で取得できます。
Can I use it without a robot hand?
はい。T1 Proは単体で手の姿勢・空間動作・両手の同期動作(T1 Pro は触覚・圧力も)を記録できるため、ロボットと接続しなくても人の手のお手本データを収集できます。まず作業者の動作データを集めておき、後から模倣学習や遠隔操作に活用するといった使い方も可能です。
How does it differ from Wuji Glove?
Wuji Glove は電磁式トラッキングと手のひら全面の触覚センサ(526点)を備え、Wuji Hand 2 との遠隔操作に強みがあります。LITCHI T1 Proは無線・IMU 方式で、一人称カメラとの高精度同期を前提とした「現場でのマルチモーダルデータ収集」に強みがあります。
Can you also handle data collection, not just equipment?
Yes. In addition to equipment, we offer a data collection service that covers task definition, collection, processing, annotation and quality checks in one package.
Are demos or evaluations available?
Please contact HumansX about demos and evaluations. We will suggest the best approach after learning about your application.
Contact
Contact us for pricing, lead times and demos
LITCHI T1 シリーズ(T1 Lite・T1・T1 Pro)、Ego データ収集デバイス、データ収集サービスについて、日本正規代理店の HumansX までお気軽にご相談ください。