How Do You Collect Imitation Learning Data? Training a Robot's "Hands" with Data Gloves and Teleoperation
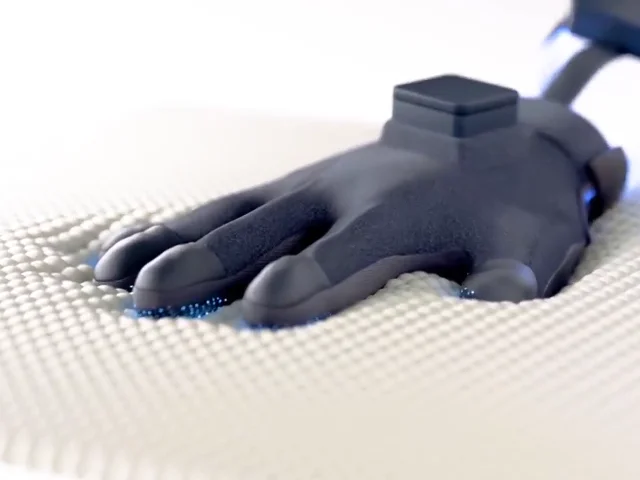
In imitation learning for dexterous robot manipulation, the key is how to record human hand motion and touch. This guide explains data collection with teleoperation and data gloves, the equipment needed and how to choose it.