Physical AI Solution — Dual-Arm Data Collection
With Wuji Hand 2 & Wuji GloveDual-Arm Data Collection System
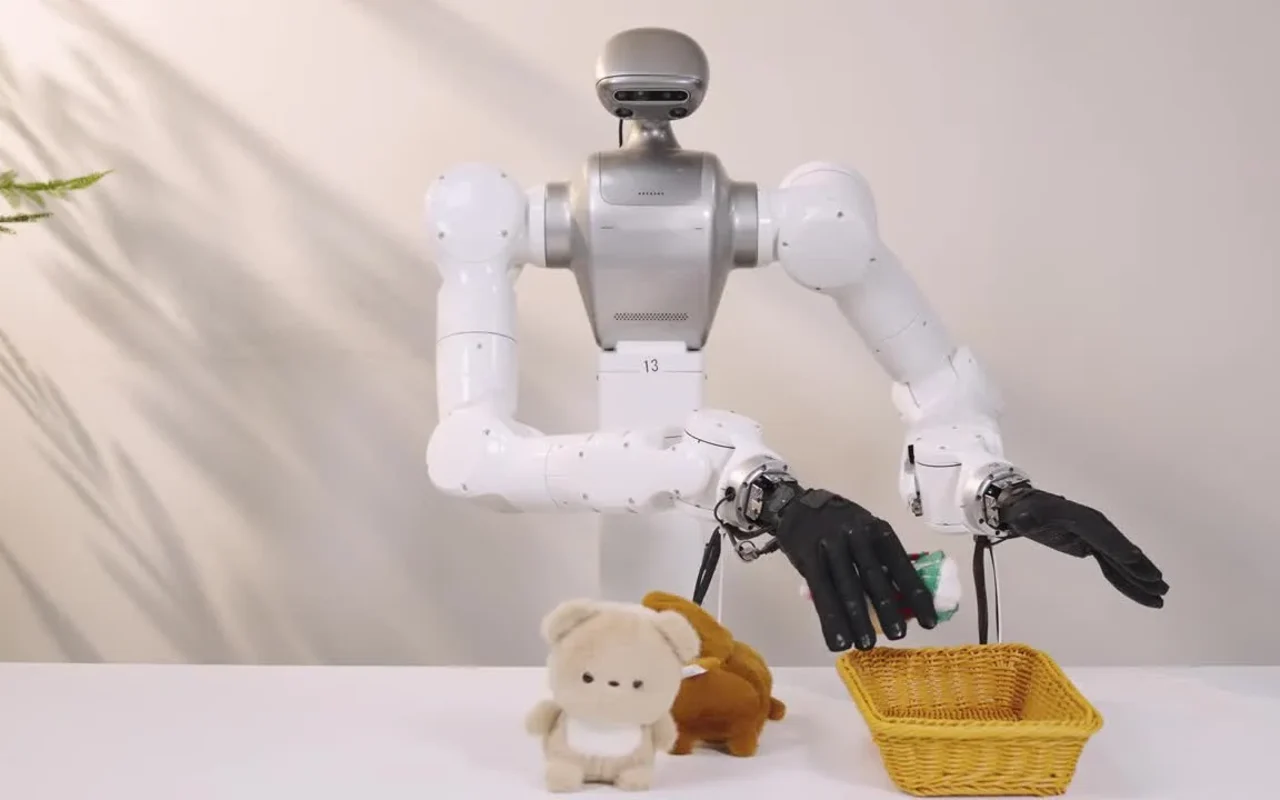
Wuji Hand 2 and Wuji Glove on a force-controlled dual-arm robot.
Start collecting bimanual data the day it arrives.
Two Roles
One system, two roles.
Collect real-robot data
as it happens.
- Reproduce skilled hand and arm motions on the real robot
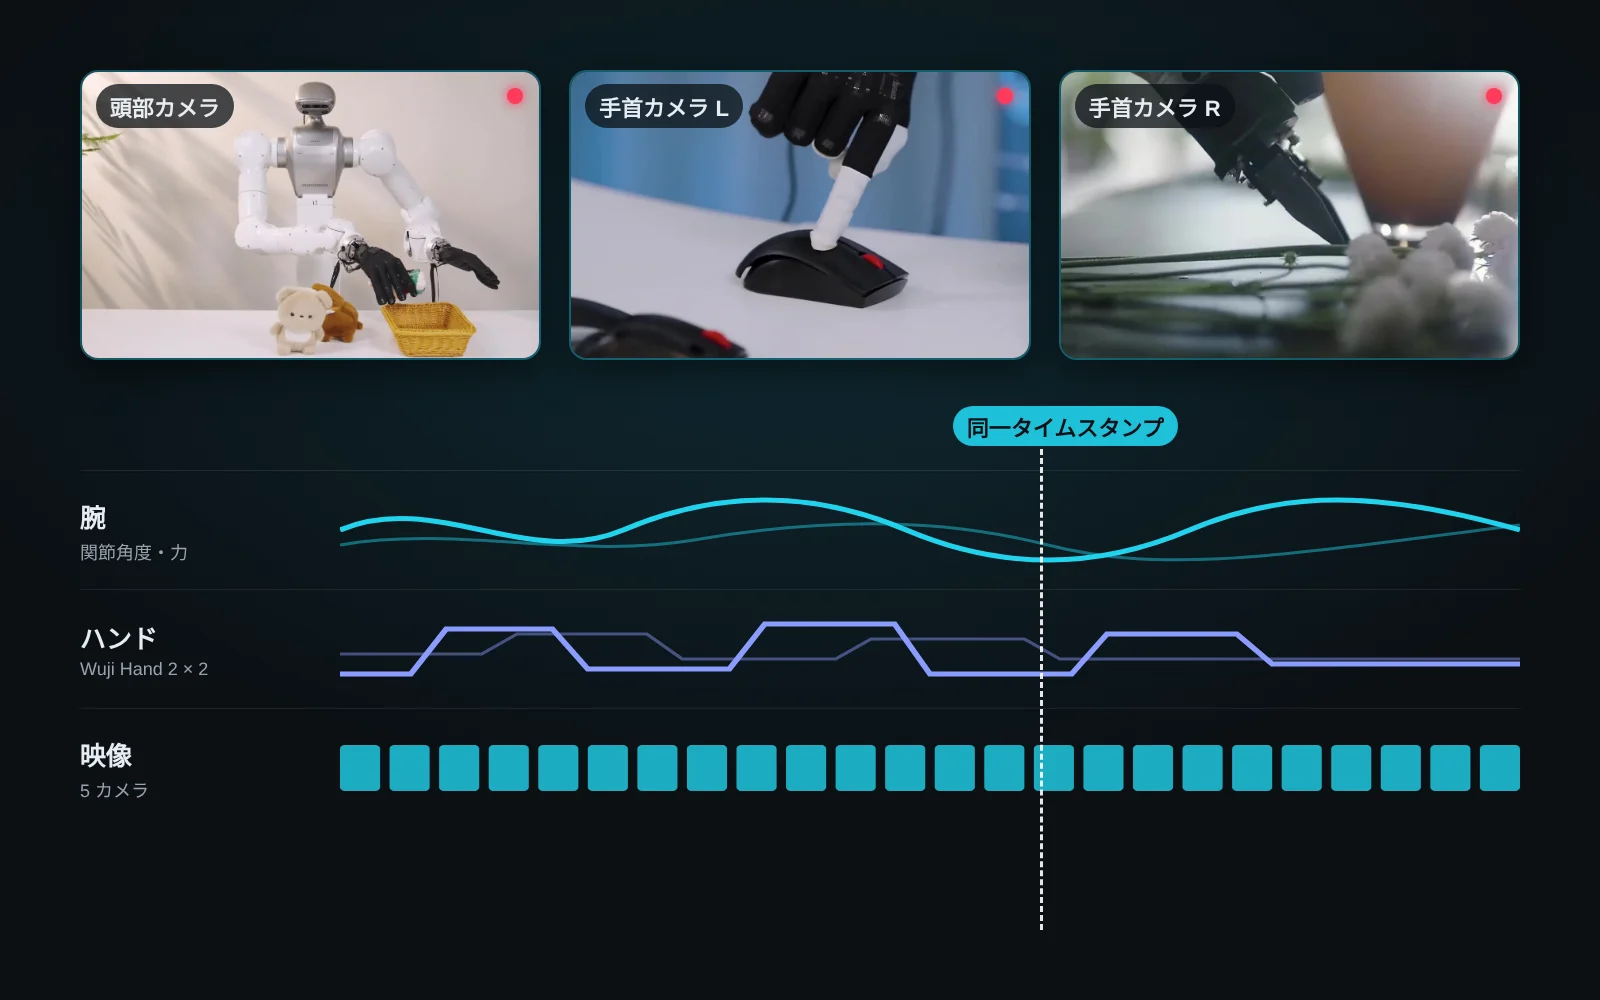
- Record arms, hands and 5 cameras on a synchronized timeline
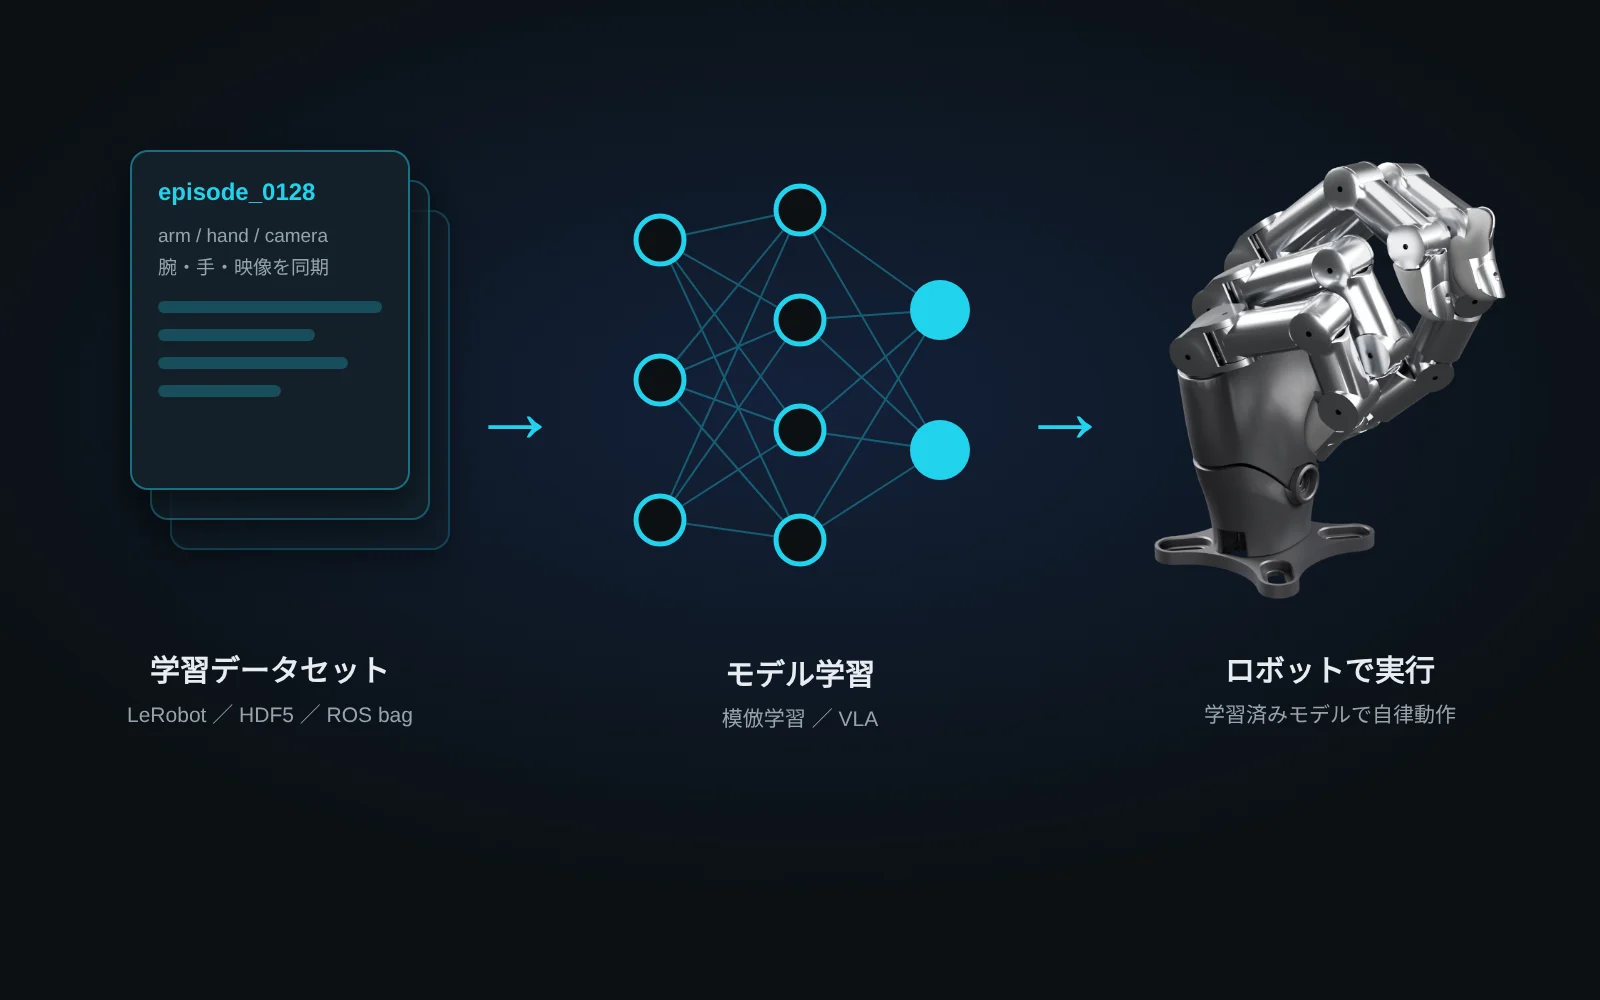
- Export to LeRobot / HDF5 and start training right away
Validate and deploy
trained models on the real robot.
- Evaluate trained models directly on the real robot (Sim2Real)
- Run models on the robot with onboard Jetson
- Trial operation in real environments, from lab to field
Collect → train → validate on the same system, for a faster improvement cycle.
System
System Configuration
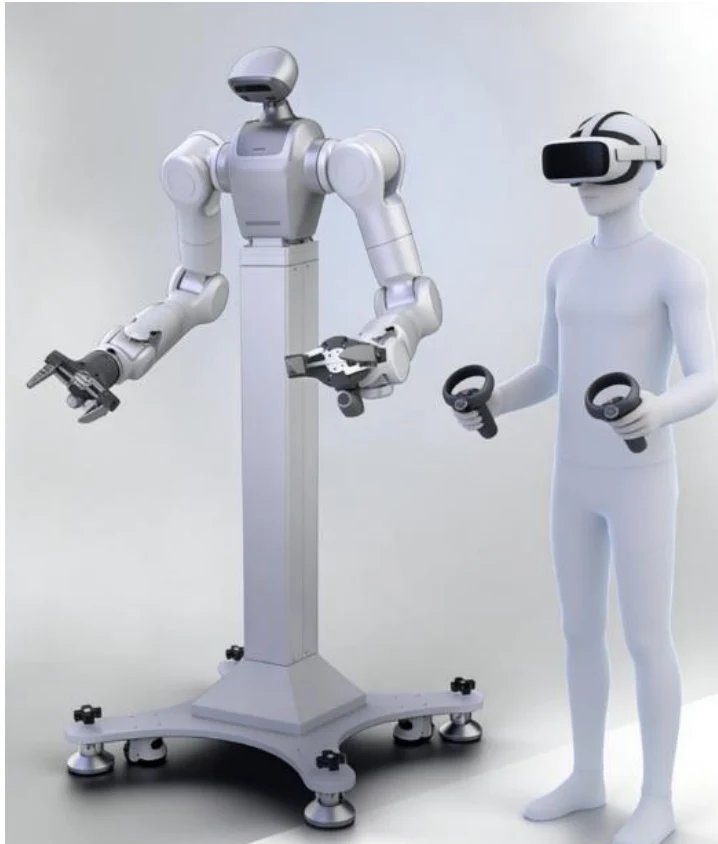
Operator
Teleoperation
Robot
- 1Multi-camera5 cameras on head and wrists, synchronized multi-view recording
- 27-DoF force-controlled arm ×2Arm: Marvin Pro
- 3Wuji Hand 2 ×220-DoF dexterous handProduct page →
- 4Control & recording PCNVIDIA Jetson AGX Orin
- 5StandWith casters and leveling feet
* The diagram is for illustration. Number of cameras, stand, etc. can be changed on request.
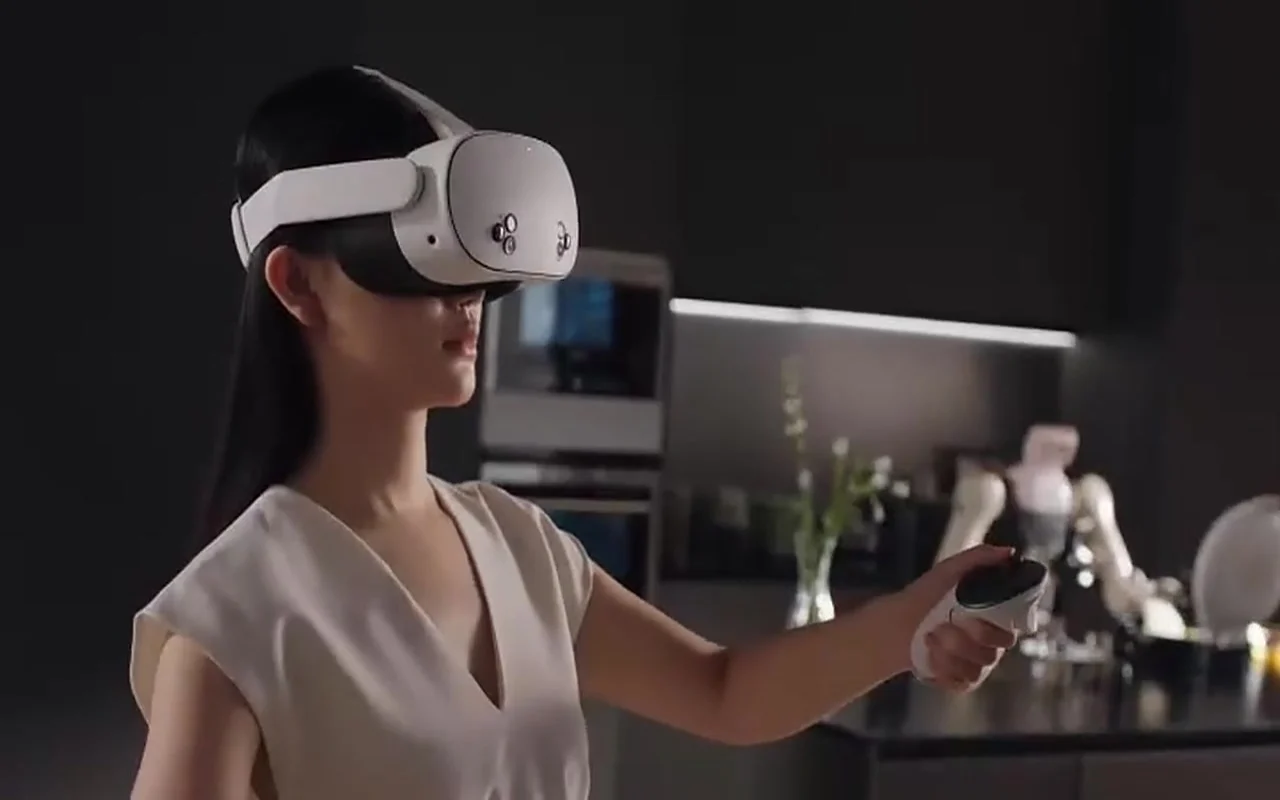
Teleoperation
Put on VR,
and move both arms as you are.
Watch the robot’s head-camera view in VR and simply move your hands and arms. Skilled motions are sent to the robot in real time and recorded directly as training data.
* Image for illustration. The standard configuration uses Wuji Glove for finger input and Wuji Hand 2 as end effectors.
Easy Start
Start collecting data in 4 steps, the day it arrives
Delivered assembled and calibrated. Just power on, put it on, and move.
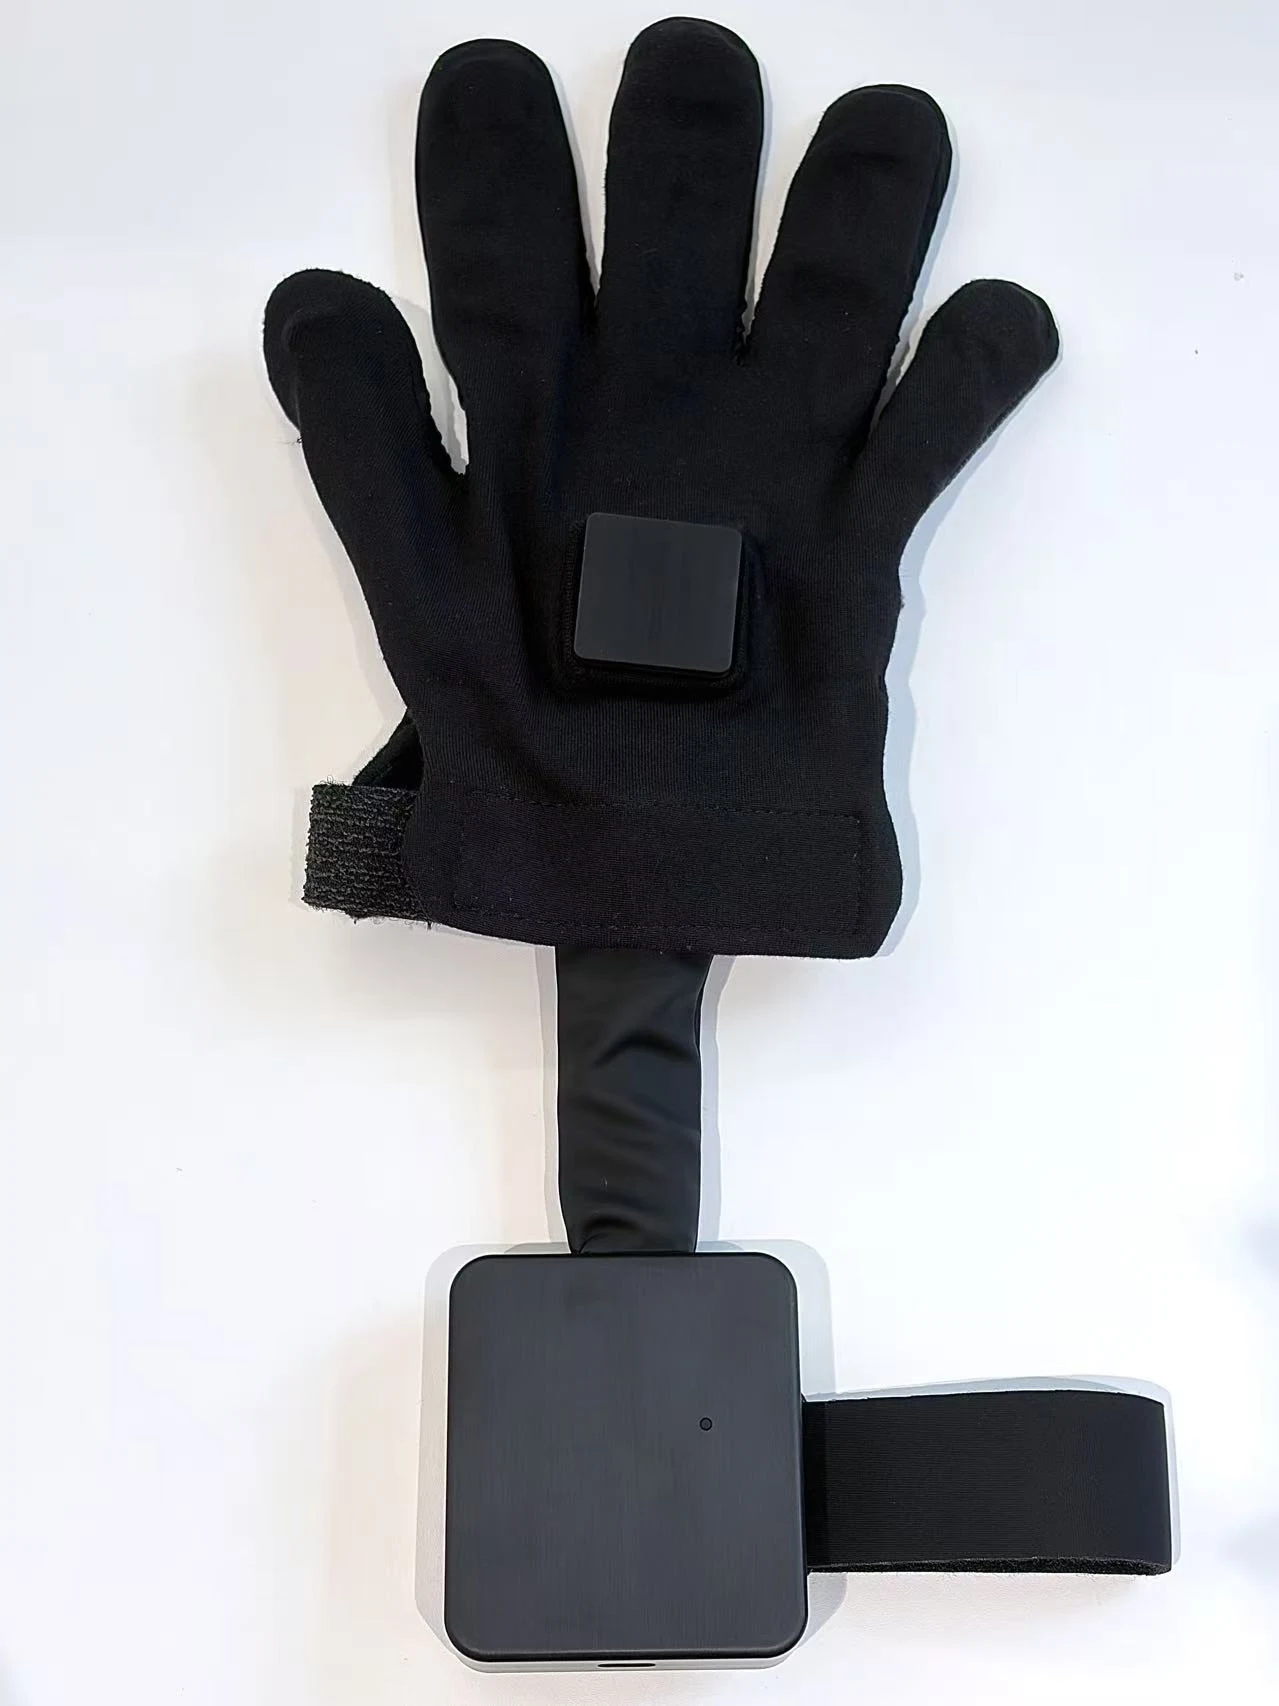
- 01Put on and operateWear Wuji Glove and VR, then simply move your hands and arms
- 02The robot reproducesThe dual arms and Wuji Hand 2 perform the same motion in real time
- 03One-click recordingArms, hands and 5 cameras recorded automatically on one timeline
- 04Straight to trainingExport to LeRobot / HDF5 for imitation learning and VLA
 STEP 01 / 04
Use Cases
Collect data for tasks like these
* Videos show example configurations.
Development Platform
The ideal platform for your own development
Open hardware, software and data. Use it directly to develop your own algorithms and applications.
Python · C++Arm control SDKJoint and Cartesian control and kinematics via API, with sample code.Python · ROS 2Wuji Hand 2 SDKDirectly control the 20-DoF hand. Glove retargeting is also open source.URDF · STEP3D models & CAD dataReady for simulation and for designing fixtures and end effectors.Technical documents →LeRobot · HDF5Open data formatsNo proprietary formats. Connects directly to your existing training pipeline.NVIDIA JetsonEdge AI executionRun trained models on the robot with the onboard Jetson AGX Orin.SupportTechnical support in JapaneseFrom operation training to technical questions during development, HumansX supports you.Specifications
Dual-Arm Data Collection System — Key Specifications
| Dual-arm robot | DoF | 7 DoF × 2 (force control) |
|---|---|---|
| Configuration | Fixed-base dual-arm (arm: Marvin Pro) | |
| Control mode | Position control + impedance control | |
| Control rate | 500 Hz | |
| Hand | Robotic hands | Wuji Hand 2 × 2 (left & right, 20 DoF each) |
| Teleoperation | Finger input | Wuji Glove |
| Arm & viewpoint input | VR headset | |
| Latency | End-to-end ≤ 100 ms | |
| Video streaming | Real-time video streaming to VR (2560×720, 30 fps) | |
| Sensing | Cameras | 5 in total on head, wrists, etc. (configurable) |
| Computer | NVIDIA Jetson AGX Orin | |
| Communication | Ethernet / CAN-FD, ROS 2 supported | |
| Data | Recorded data | Arm joint and force data, hand joint data and multi-view video, time-synchronized |
| Output formats | HDF5 / RLDS / ROS bag / LeRobot (v3.0) | |
| Recording rate | 500 Hz (all data time-synchronized) | |
| Visualization | Playback and visualization with Rerun; check data before and after conversion | |
| Power Supply | Supply voltage | DC 48 V (±15%) |
| Power consumption | Average 300 W / peak 600 W | |
| Integration | Lead time | Approx. 10–12 weeks after order (depends on configuration) |
| Services | Installation, calibration, functional check and operation training (in Japanese) |
* Specifications are subject to change without notice. Configuration can be customized on request.
FAQ
Dual-Arm Data Collection System — FAQ
What is the Dual-Arm Data Collection System?
It combines a force-controlled dual-arm robot with Wuji Hand 2 (left & right) and Wuji Glove, covering everything from collecting teleoperated demonstration data to exporting training data. HumansX configures and tunes the system and delivers it ready for data collection on arrival.
How is it different from buying Wuji Hand 2 alone?
With Wuji Hand 2 alone, you need to prepare and integrate the arms, teleoperation environment and data recording yourself. With this system, HumansX provides and tunes all of it as one package, so you can start research without integration work.
What formats can the collected data be exported in?
Arm, hand and camera data are recorded in sync and can be exported as HDF5, ROS bag or LeRobot format, ready for imitation learning and VLA model training.
Can I buy the robot arm alone?
This system is offered as a complete package including Wuji Hand 2, Wuji Glove and data collection software. Please contact us about customizing the configuration.
Can we develop or modify the software ourselves?
Yes. We provide the arm control SDK (Python / C++), the Wuji Hand 2 SDK and retargeting, and URDF / STEP data, so you can use it as a base for developing your own algorithms and applications. HumansX also answers technical questions during development in Japanese.
Please tell me about pricing, lead time and demos.
Pricing depends on the configuration; please contact us via our inquiry form. Lead time is approx. 10–12 weeks after order. We also welcome demo requests.
Contact
Contact us for pricing and lead times
For pricing, configuration, lead time and demos of the Dual-Arm Data Collection System, please contact HumansX, the official Japan distributor of Wuji.