
Physical AI Solution — Data Glove
Official Distributor in Japan — HumansXWuji Glove
Turn touch and hand motion directly into data.
A tactile data glove for everything from teleoperation to imitation-learning data collection
About
Capture the “feel” and “motion”
of the human hand — together.
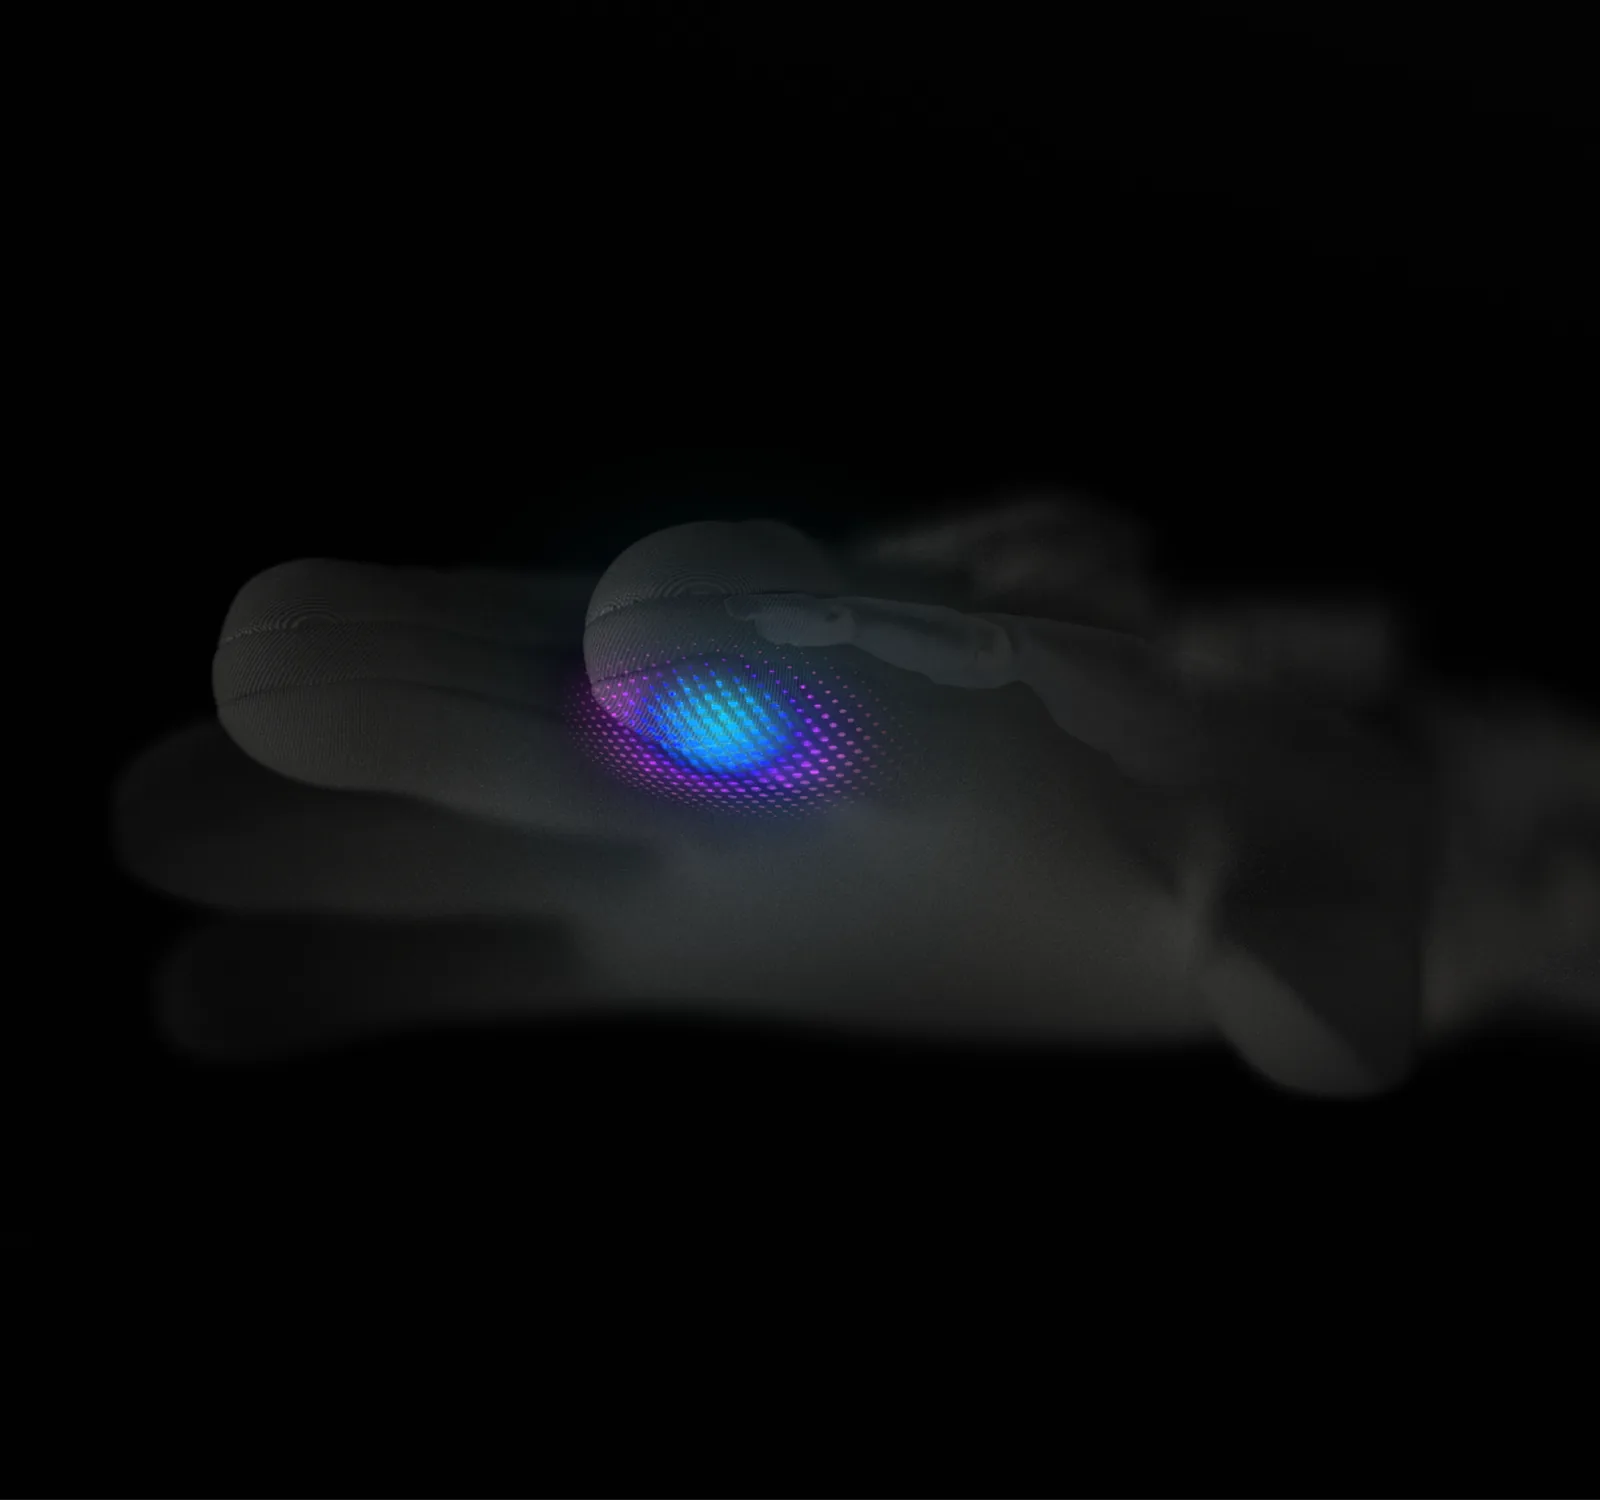
Wuji Glove is a tactile data glove developed by Wuji Technology in Shenzhen, China. High-density pressure sensors across the entire palm capture contact force and distribution, while electromagnetic tracking on the fingertips and back of the hand captures hand position and orientation in real time.
Use it to teleoperate multi-fingered robot hands, or on its own for data collection and research. As the authorized distributor in Japan, HumansX supports you from product selection and demos to post-installation technical support.
Core Technology
Four core technologies for high-quality manipulation data
Full-palm tactile sensing
A 24×31 pressure-sensor matrix (526 points) covers the entire palm, recording contact force and distribution at 120 FPS with 0.1 N resolution.
Electromagnetic motion tracking
Five 6-DoF electromagnetic (EMF) receiver modules on the fingertips and back of the hand capture hand motion with ≤ 2 mm position accuracy and < 5° orientation accuracy.
Low latency with IMU
Combined with a 6-axis IMU, motion-to-data latency is ≤ 10 ms (wired), enabling real-time teleoperation.
Lightweight and durable
The glove weighs just 67.5 g and withstands over 100,000 press and bend cycles each — ready for long data-collection sessions.
Lineup
Two types for different applications
Motion Capture Version
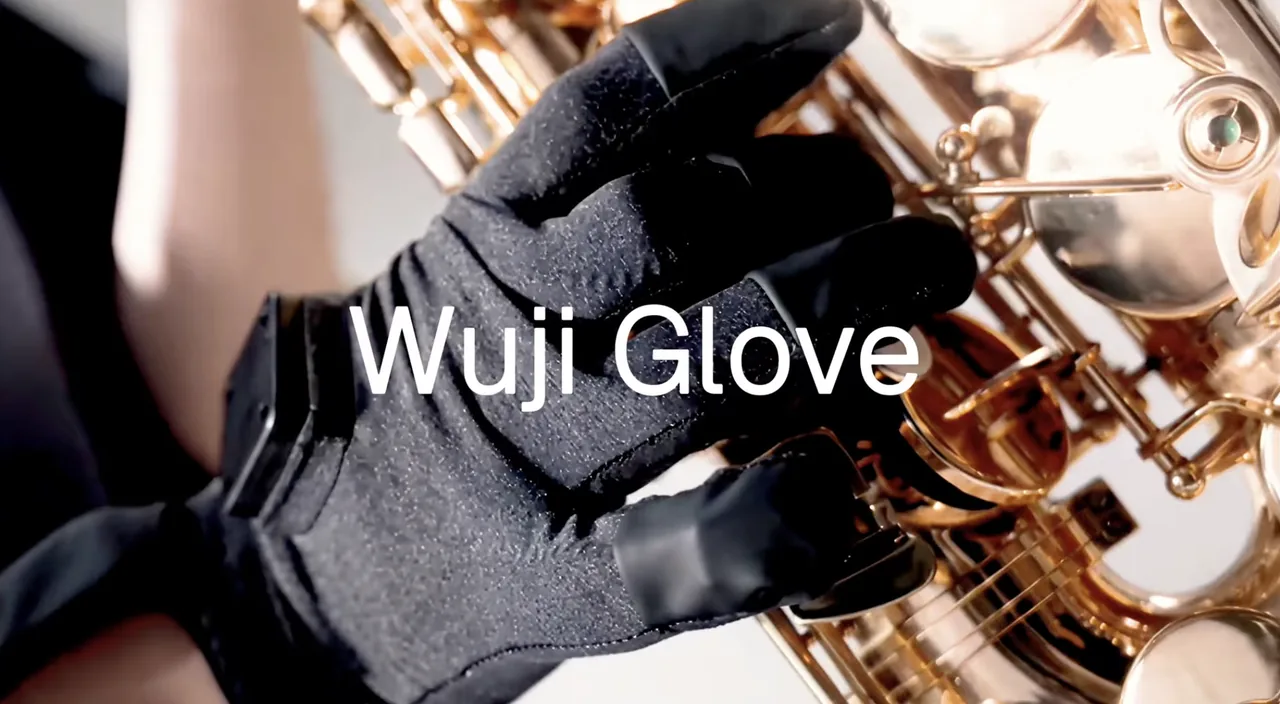
Worn on the human hand. In addition to tactile sensing, it features EMF and IMU motion capture, recording hand pose and touch simultaneously — ideal for data collection and teleoperating multi-fingered robot hands.
Tactile Sensing Version
Fitted onto the Wuji Hand to capture tactile data on the robot side. Visualize and record the pressure distribution when the robot touches an object.
Teleoperation × Wuji Hand 2
Human hand motion,
transferred straight to the robot hand.
Paired with the 20-DoF Wuji Hand 2, it delivers an end-to-end workflow from collecting dexterous manipulation data to training AI models. Gesture control and teleoperation with Apple Vision Pro are also supported.
The glove captures human hand motion and touch
Converted to robot hand joints in real time
Wuji Hand 2 reproduces the same motion
Train AI models with the collected data
Use Cases
Main Use Cases
Data collection
Record human hand motion and touch during tasks as imitation-learning data.
Teleoperation
Control multi-fingered robot hands such as Wuji Hand 2 in real time.
HCI and ergonomics research
Quantitatively analyze how force is applied and how the hand is used during grasping and manipulation.
VR / AR
Gesture control and teleoperation with Apple Vision Pro.
Specifications
Wuji Glove Key Specifications
| Dimensions & weight | Size (L × W) | 215 × 195 mm |
|---|---|---|
| Thickness (fabric / structure) | 6.55 mm / 35 mm | |
| Total length (incl. cable) | 340 mm | |
| Weight | Glove 67.5 g / with cable 192.6 g | |
| Tactile sensor | Type & coverage | Pressure sensor matrix (full palm) |
| Sensing points | 526 points (24 × 31 matrix) | |
| Output rate | 120 FPS | |
| Range / resolution | 0–20 N / 0.1 N | |
| Spatial resolution / repeatability | 4 mm / ±6 % | |
| Durability | 100,000+ press and bend cycles each | |
| Tracking | Electromagnetic (EMF) | 5 receiver modules (6 DoF each) |
| Position / orientation accuracy | ≤ 2 mm RMS / < 5° RMS | |
| Tracking range | Within 30 cm | |
| Latency (wired) | ≤ 10 ms | |
| IMU | 6-axis IMU | |
| Communication & Power | Communication | Ethernet (100BASE-TX / RJ45, via included adapter) |
| Power Supply | USB Type-C (5 V / 1 A) | |
| Software | Supported environments | Wuji Studio, Python SDK / CLI, ROS 2 (Windows / Linux) |
| Integrations | Wuji Hand 2, Apple Vision Pro | |
| Environment | Operating temp. / humidity | -5 to 40 °C / below 55 %RH |
| Accessories | Per hand | Glove, data acquisition board (with arm strap), USB-C to Ethernet adapter (with power supply), USB-C cable |
* EMF sensors are affected by metal and ferromagnetic materials; keep them at least 3 cm away. To obtain absolute wrist position, use an external tracker (mounting interface provided).
* Available in left- and right-hand versions. Specifications are subject to change without notice; the production model's specifications apply.
FAQ
Wuji Glove FAQ
What is Wuji Glove?
A tactile data glove that records touch and hand motion together, using full-palm tactile sensors and electromagnetic motion tracking. Developed by Wuji Technology (Shenzhen); HumansX sells and supports it as the authorized distributor in Japan.
How accurate are the tactile sensing and tracking?
It outputs a 24×31 pressure-sensor matrix (526 points) at 120 FPS with 0.1 N resolution. Electromagnetic tracking achieves fingertip position accuracy of 2 mm or better, with latency from motion to data output of 10 ms or less (wired).
Which robot hands can it be paired with?
It supports real-time teleoperation of the 20-DoF Wuji Hand 2 and gesture control with Apple Vision Pro, and can also be used on its own for data collection and research.
What development environment does it use?
Wuji Studio, Python SDK / CLI and ROS 2 (Windows / Linux). Communication is via Ethernet and power via USB Type-C (5 V / 1 A).
Contact
Contact us for pricing and lead times
For Wuji Glove pricing, lead times and demo units, contact HumansX, the authorized distributor in Japan.