Design
Exterior Design
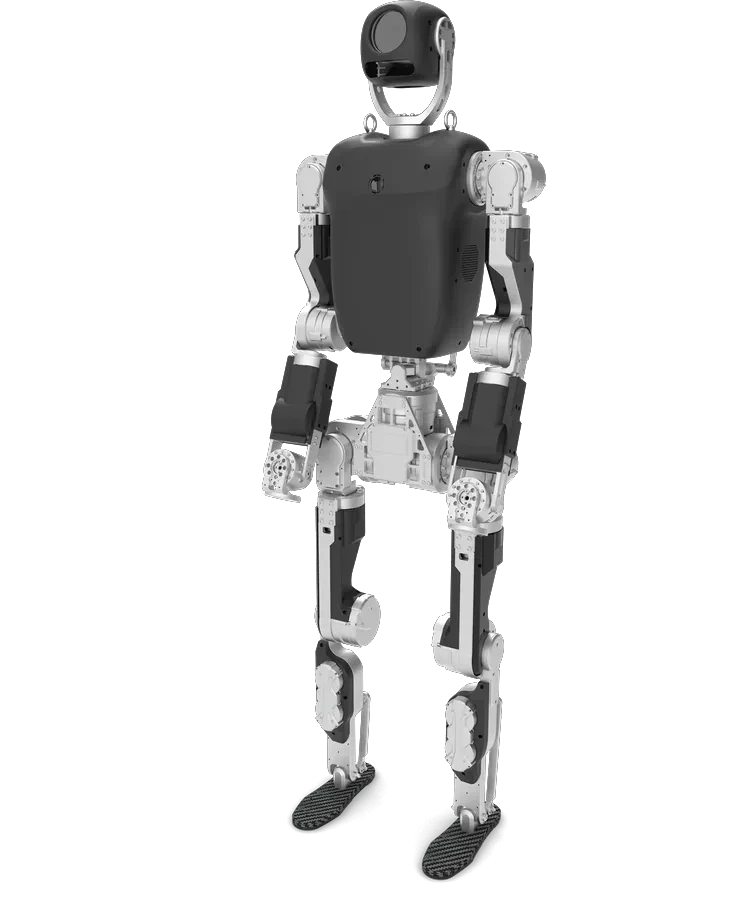
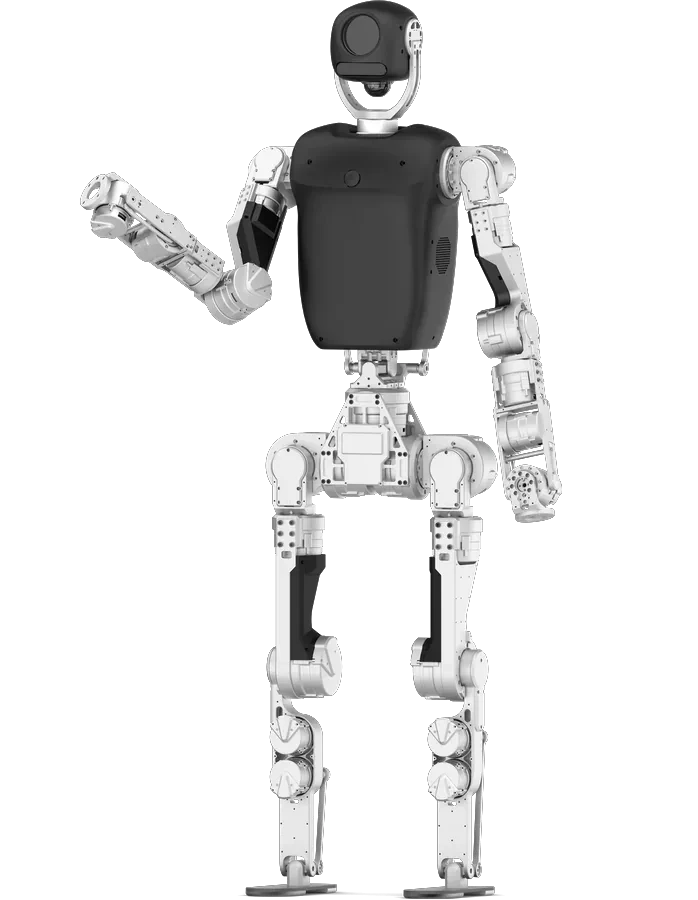
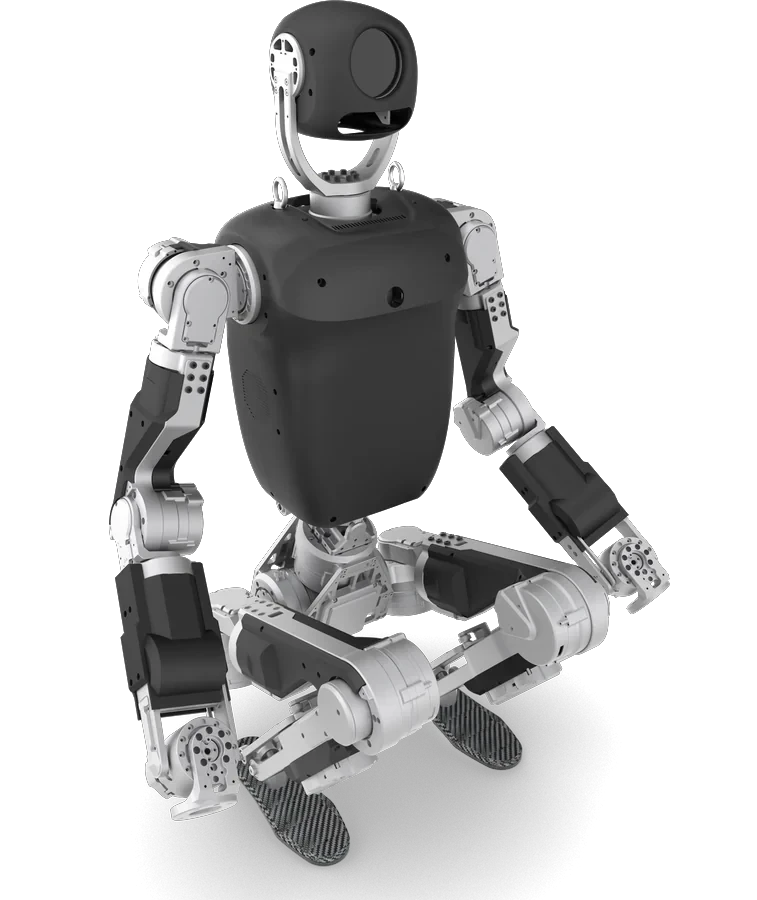
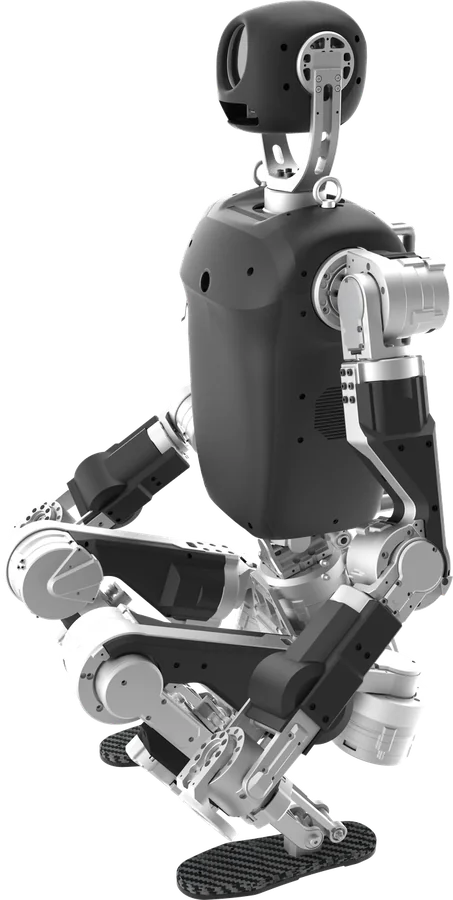
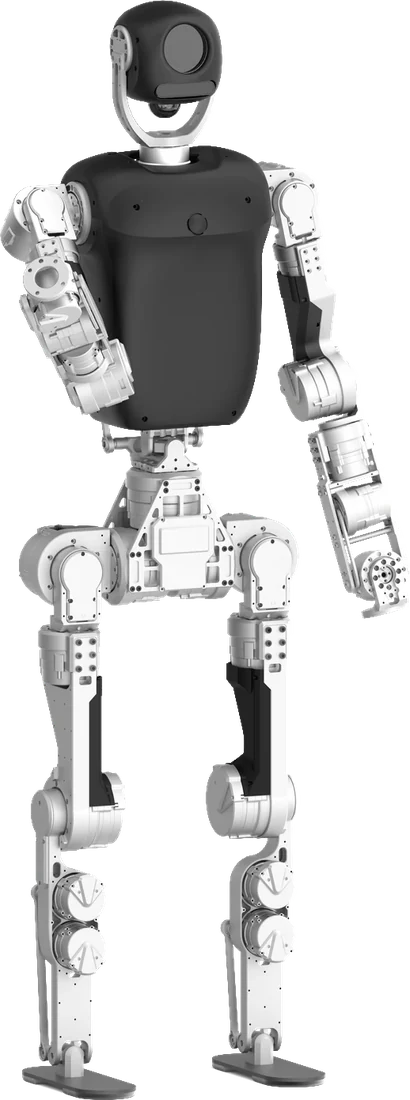
A refined design combining human-like proportions with aluminum and carbon components. With 31 DoF across the whole body, it naturally expresses a wide range of postures — standing, crouching and sitting.
Dynamic Motion
Highly dynamic motion, proven in the real world.
Motion control validated not only in simulation but in real competitions and field use. The robot reliably performs highly dynamic movements such as running, jumping, dancing and climbing over obstacles.
Joint Modules
Joint Modules Built for Humanoids
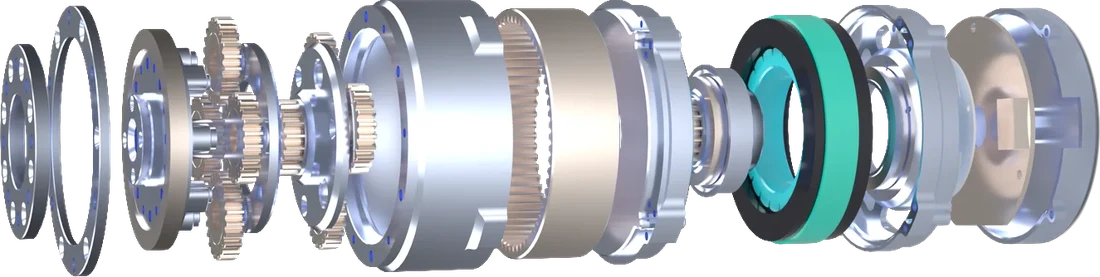
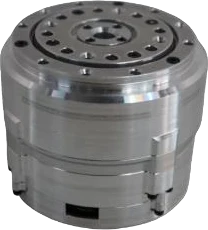
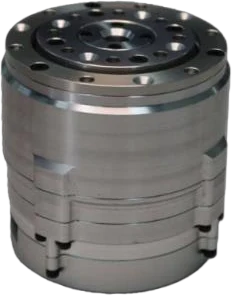
The BXI-50/70/85 hollow planetary series. Just three motor types are enough to build a humanoid with more than 30 DoF, greatly reducing design, manufacturing and maintenance costs.
Modular design
Three motor types cover the whole body, with a torque range of 25–150 N·m that can be tuned and customized.
Planetary + hollow structure
The hollow shaft routes cables internally for better reliability and range of motion. The planetary gearbox is highly shock-resistant and withstands falls.
True dual encoders
Direct measurement on both the motor and output sides improves end-effector control accuracy.
Field-proven
Validated through demanding tests and competitions on multiple humanoids, and continuously improved.
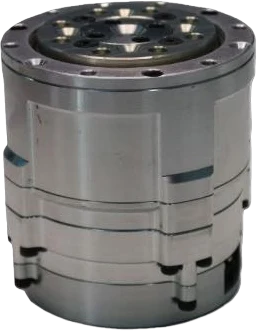
| Item | BXI-50 | BXI-70 | BXI-85 |
|---|---|---|---|
| Rated torque | 7 N·m | 15 N·m | 40 N·m |
| Peak torque | 25 N·m | 50 N·m | 150 N·m |
| Peak phase current | 30 A(rms) | 60 A(rms) | 90 A(rms) |
| Outer diameter × height | 64 × 65.5 mm | 81 × 66.5 mm | 99 × 71.5 mm |
| Hollow diameter | 6 mm | 9 mm | 10 mm |
| Weight | 0.5 kg | 0.8 kg | 1.4 kg |
| Common specifications | Rated voltage 24–48 V / no-load speed 200 rpm / rated speed 100 rpm / gear ratio 19.5 / cross-roller bearing / dual encoders (motor side: magnetic, output side: inductive) / MIT protocol with hybrid torque, position and velocity control / CAN, CAN FD (RS485 coming soon) | ||
Motion Control
Motion Control ("Cerebellum") Solution
Reinforcement-learning-based motion control enables highly dynamic whole-body movement. With a systematized pipeline from data to the real robot, it is ready for exhibitions and performances.
Automatically extracted from human videos, or motion capture
Automatic conversion of human motion into robot joint trajectories
Reinforcement learning in parallel simulation environments
Quality validation in high-fidelity simulation
Deploying the control policy to real hardware
Learn in simulation, deploy on the real robot
In a parallel simulation environment, we train the control policy with reinforcement learning so that BXI Elf3 tracks a reference motion (green) generated from human motion data. Even complex whole-body movements, including falling down and getting back up, are validated in Sim2Sim and then deployed on the real robot.
- Reinforcement learning
- Whole-body motion tracking
- Sim2Sim validation
- Real-robot deployment
Applications
Main Applications
Exhibitions & performances
Demonstrations of dynamic motion such as walking, running, jumping and dancing
Guidance & patrol
Guiding visitors in exhibition halls and facilities with precise navigation and multilingual AI commentary
Teleoperation & data collection
Collecting AI training data with VR, exoskeletons and data-capture devices
Research & development
A platform for embodied AI and VLA model research, or for developing your own robot products
HumansX Solutions
Combine with Hands and Bases
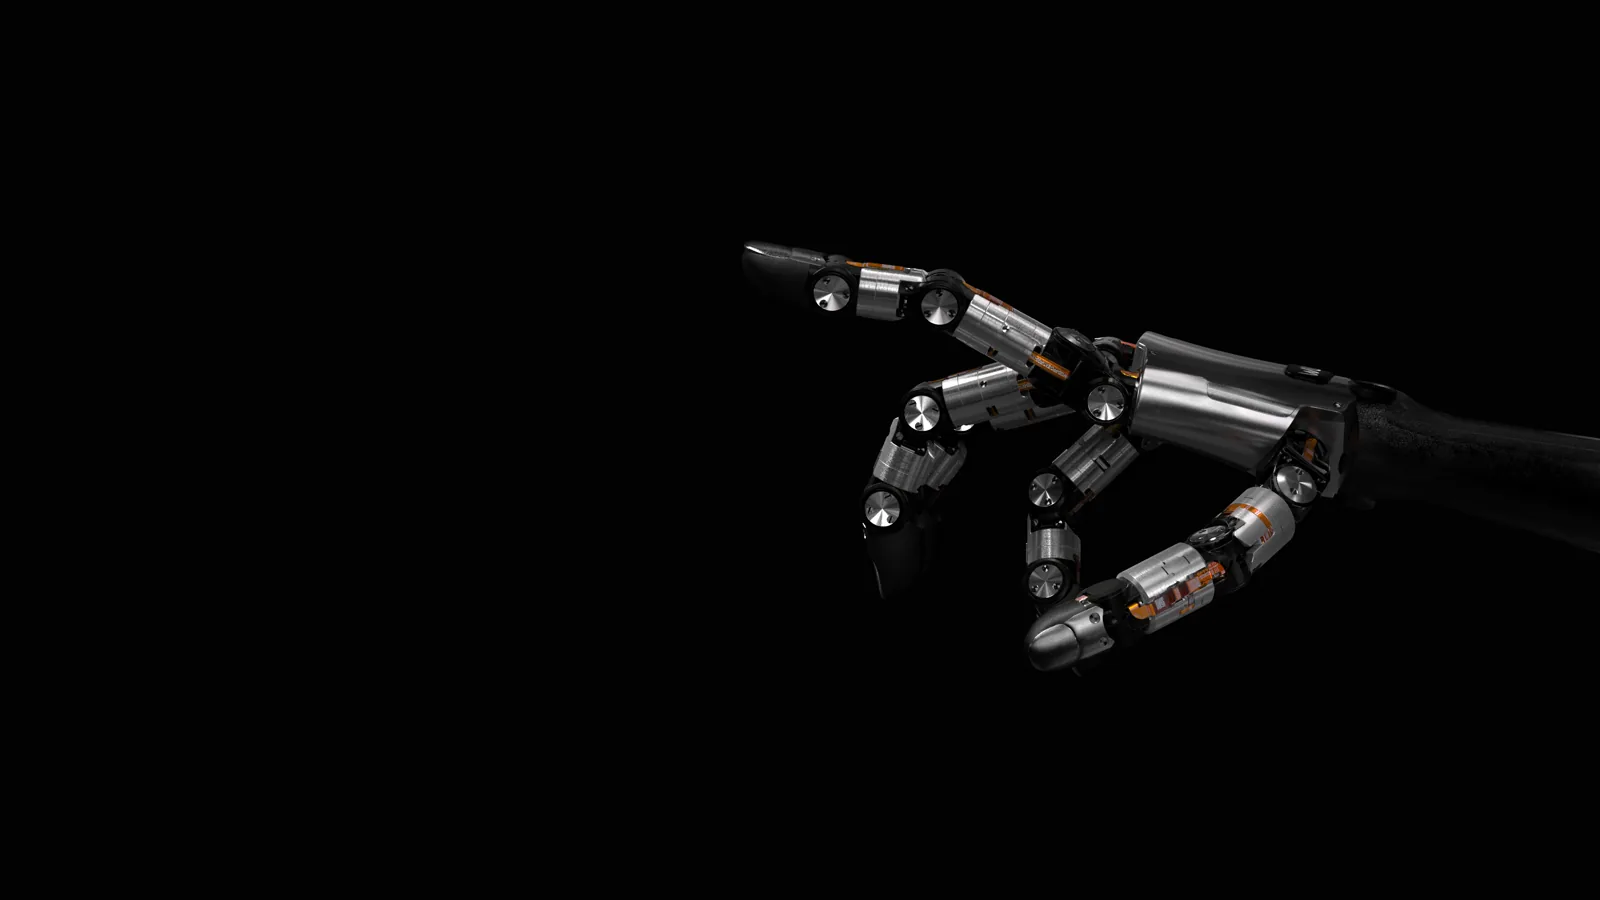
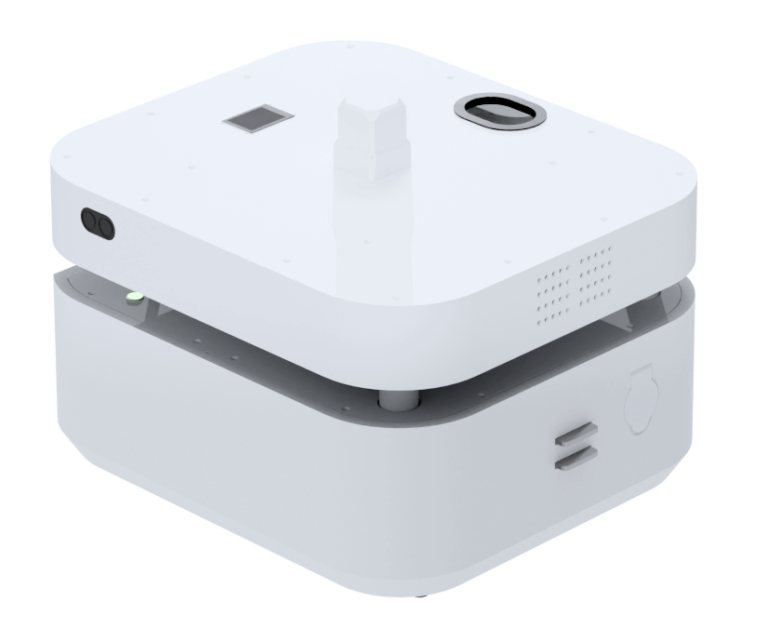
Combine HumansX Physical AI solutions to configure a robot for your application.
Specifications
BXI Elf3 Main Specifications
| Height | 145 cm |
|---|---|
| Weight | Approx. 38 kg |
| Total DoF | 31 (7 per arm / 6 per leg) |
| Payload per arm | 5 kg |
| Max. speed | Over 4 m/s (approx. 13 km/h) |
| Operating time | 1 hour or more |
| Peak torque | Shoulder 50 N·m / elbow 50 N·m / wrist 25 N·m / knee 150 N·m / thigh 150 N·m |
| Sensor | LiDAR + depth camera |
| Computing unit | NVIDIA Jetson Thor supported |
| Conversational AI | Supported (LLM API integration) |
| Custom Development | Fully open |
* Specifications are subject to change without notice and vary depending on customization.
Customization & ODM
Considering customization or ODM?
We also support customization of the exterior, sensors and compute unit based on BXI Elf3, as well as productization under your own brand. See the Custom Development page for the development process and cost guidance.
FAQ
BXI Elf3 FAQ
What is BXI Elf3?
A highly dynamic humanoid, 145 cm tall with 31 DoF. Suitable for research, development and demonstrations, it can walk, run, jump and dance on real hardware.
Can it be used for research and development?
Yes. HumansX provides development resources such as a ROS 2 control framework, URDF models and reinforcement-learning sample code, which you can use for motion-control research and testing on real hardware.
What are the key specifications?
The body weighs approx. 38 kg, the maximum speed is over 4 m/s and peak knee torque is 150 N·m. Whole-body control runs above 1,000 Hz.
Do you support customization and ODM?
Yes. We support customization of the exterior, sensors and compute unit, as well as productization under your own brand. See the Custom Development page for details.
Contact
Consult on BXI Elf3 deployment and demos
From research use and demonstrations to customization, we will propose the best fit for your application. Feel free to contact us.