
Physical AI Education Kit
RAI-P4
Embodied AI Task Planning Training Platform
From learning to practice — putting intelligence in motion.
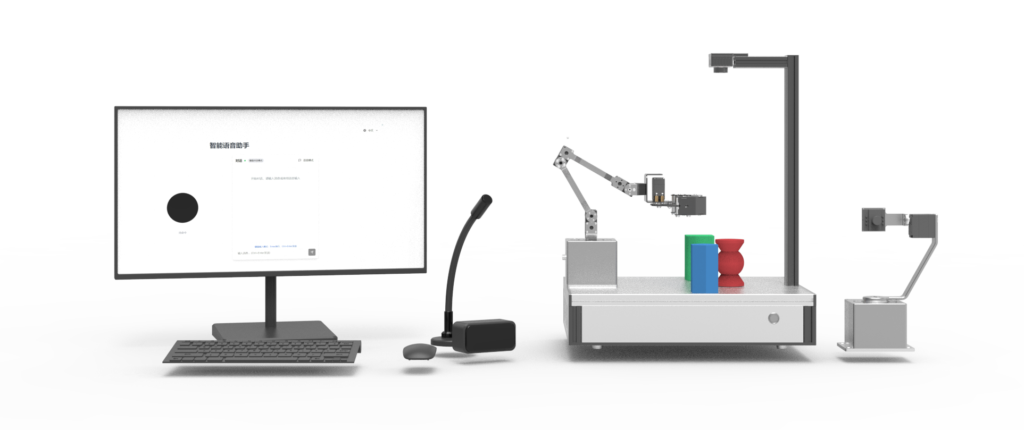
Overview
From Learning to Practice, Bringing Intelligence into Action
RAI-P4 is an embodied AI training platform that deeply integrates artificial intelligence and robotics technologies.
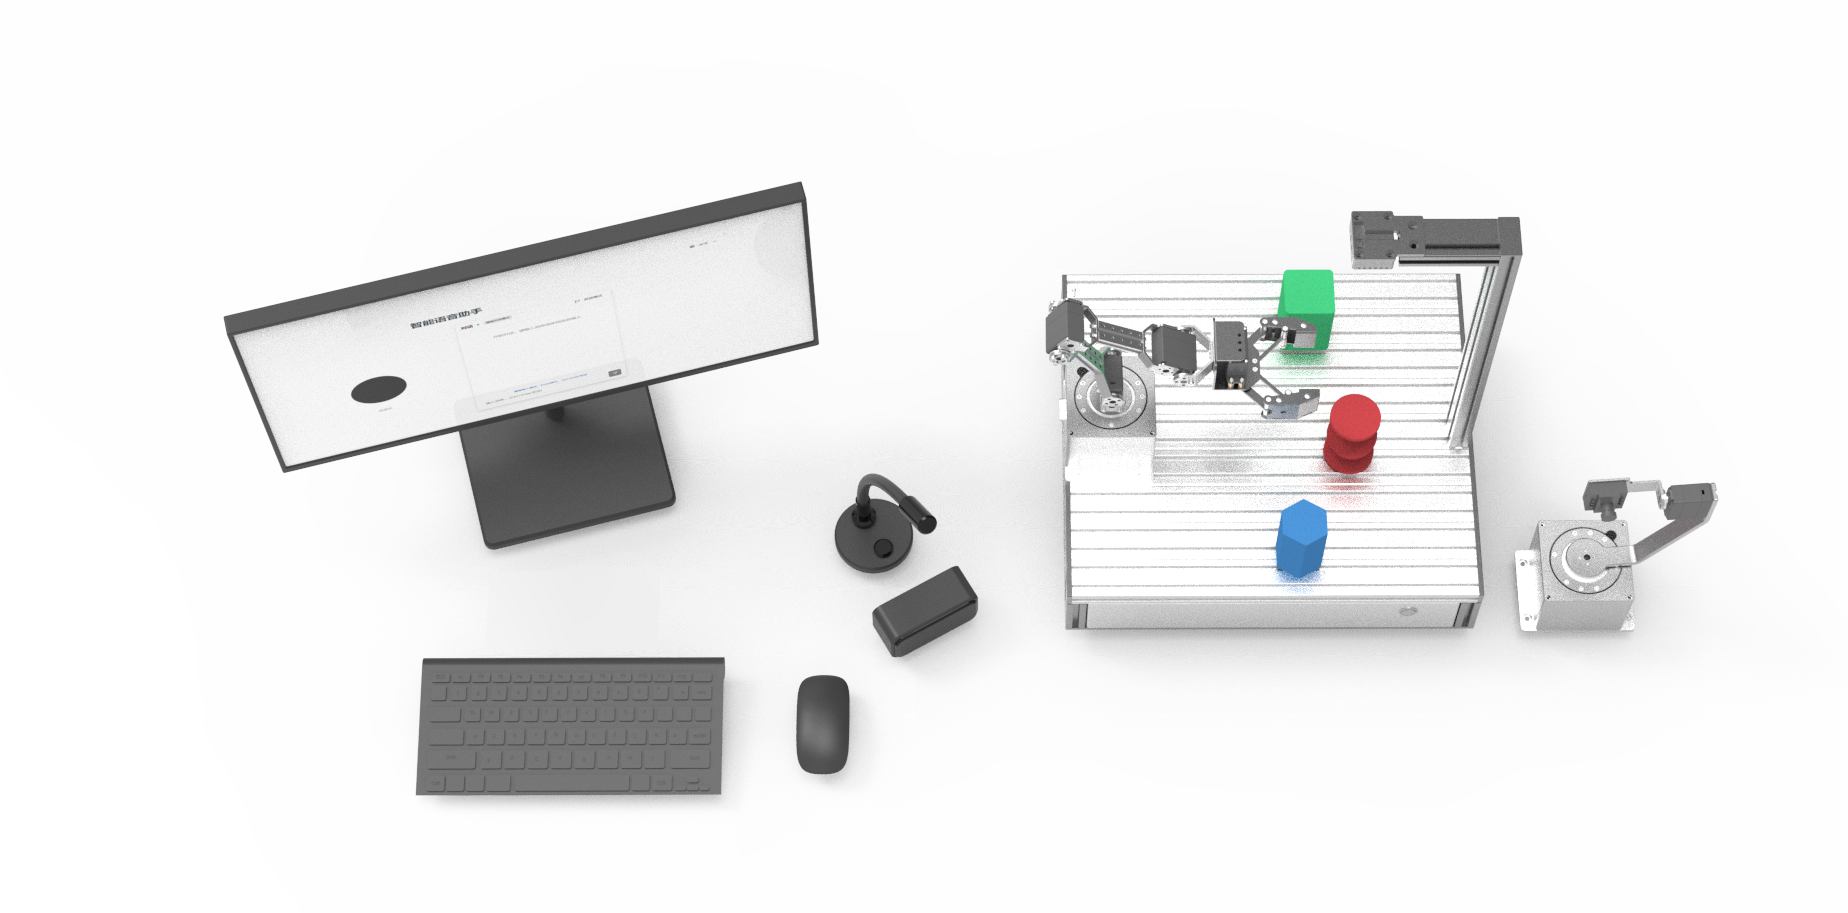
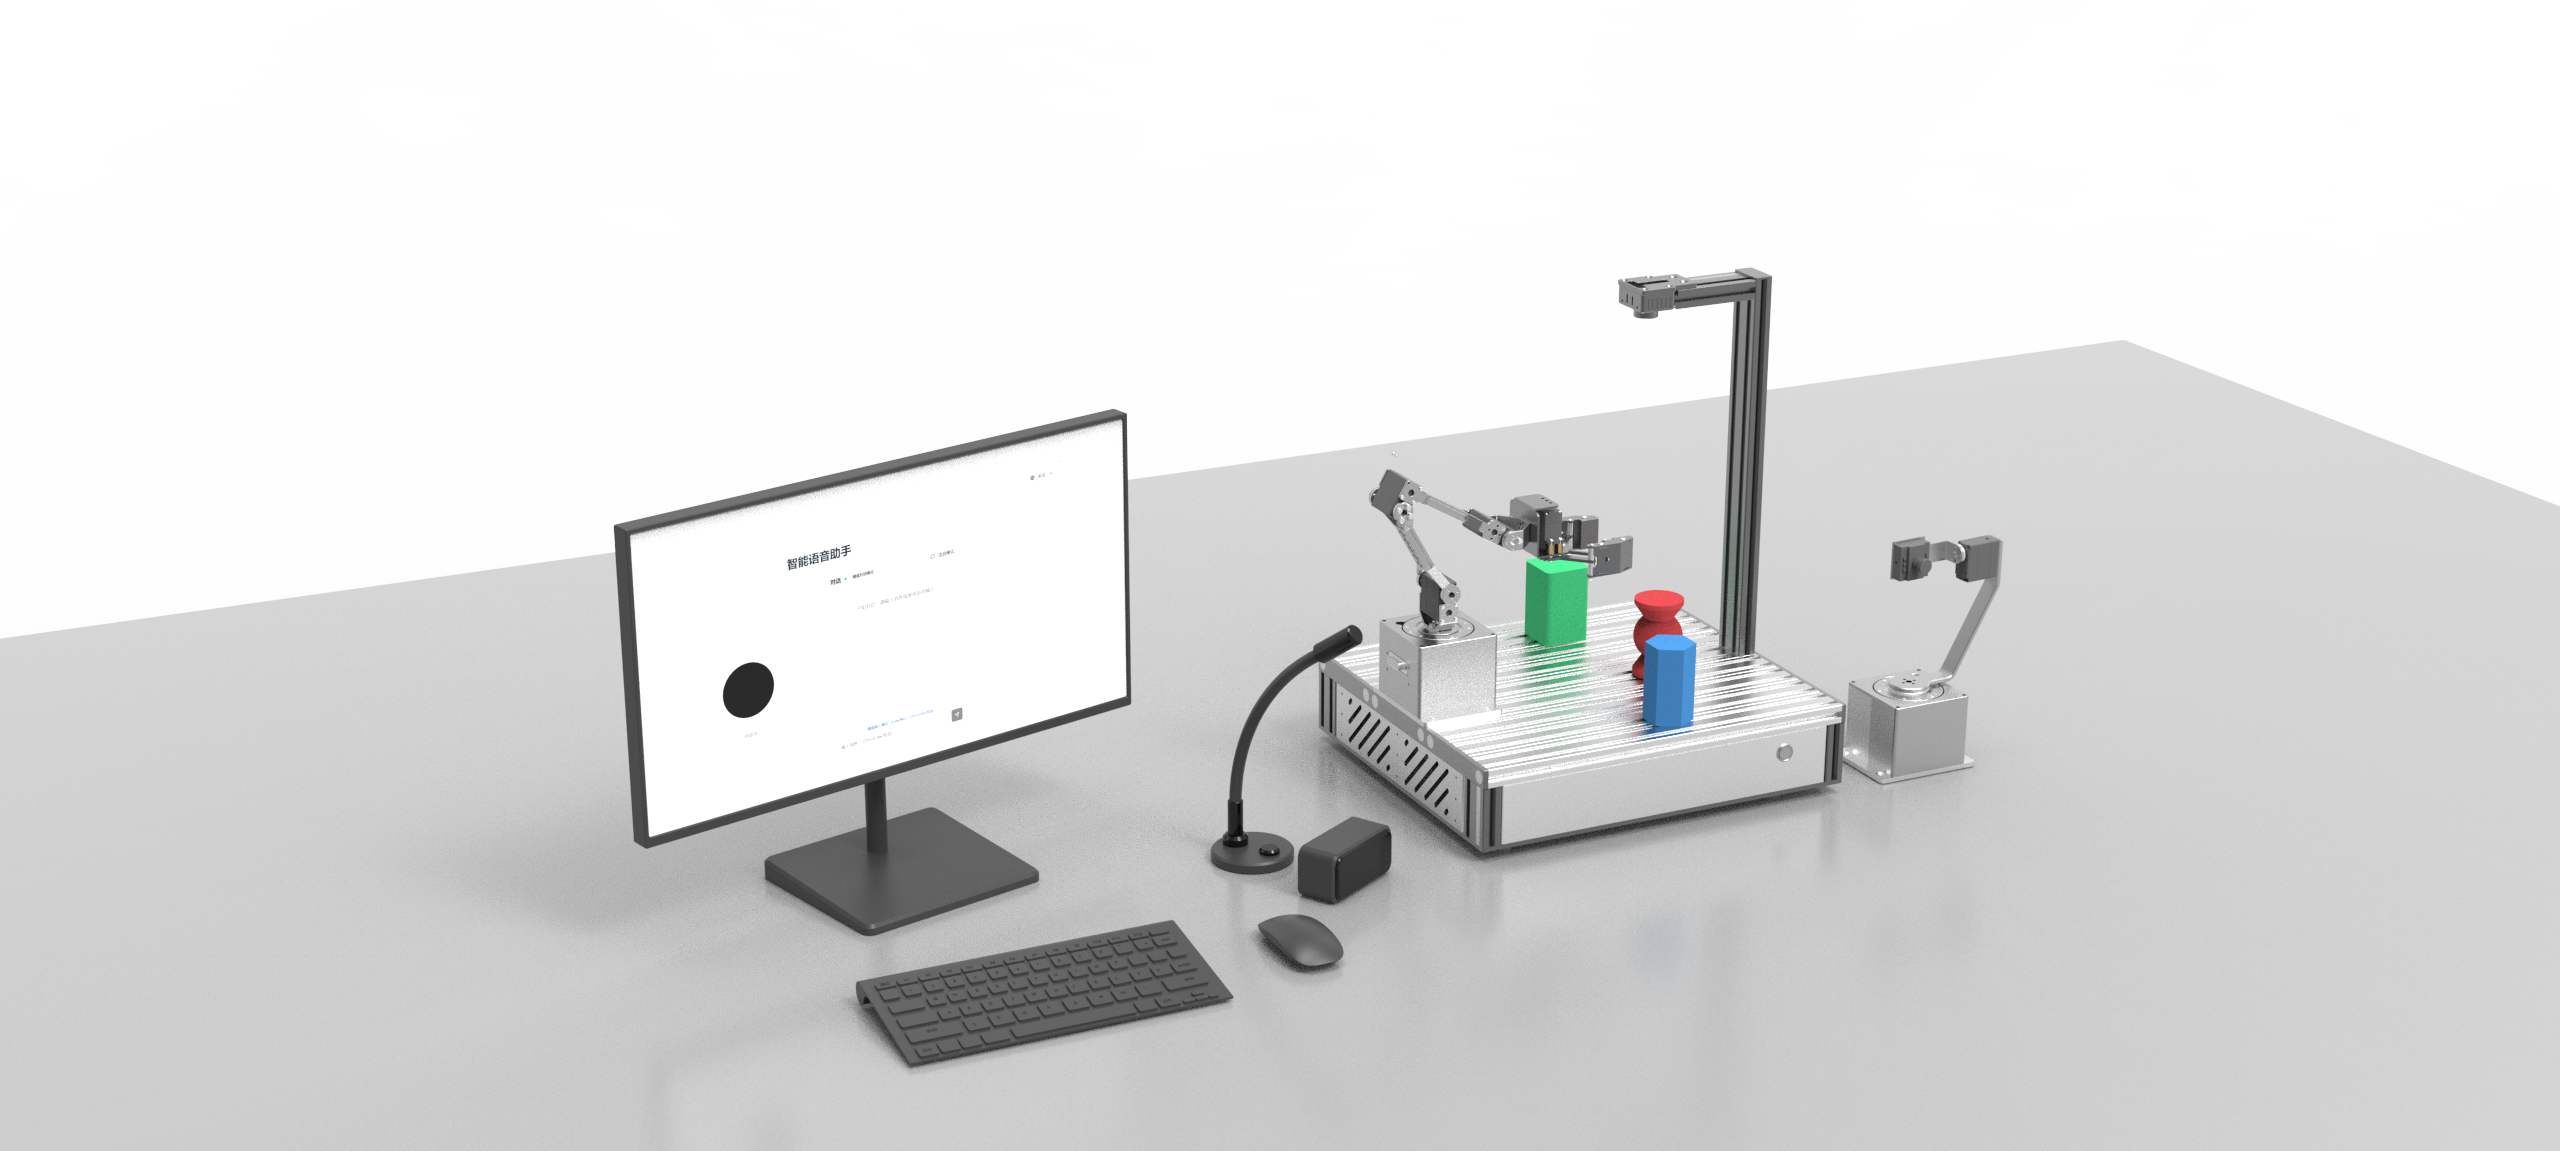
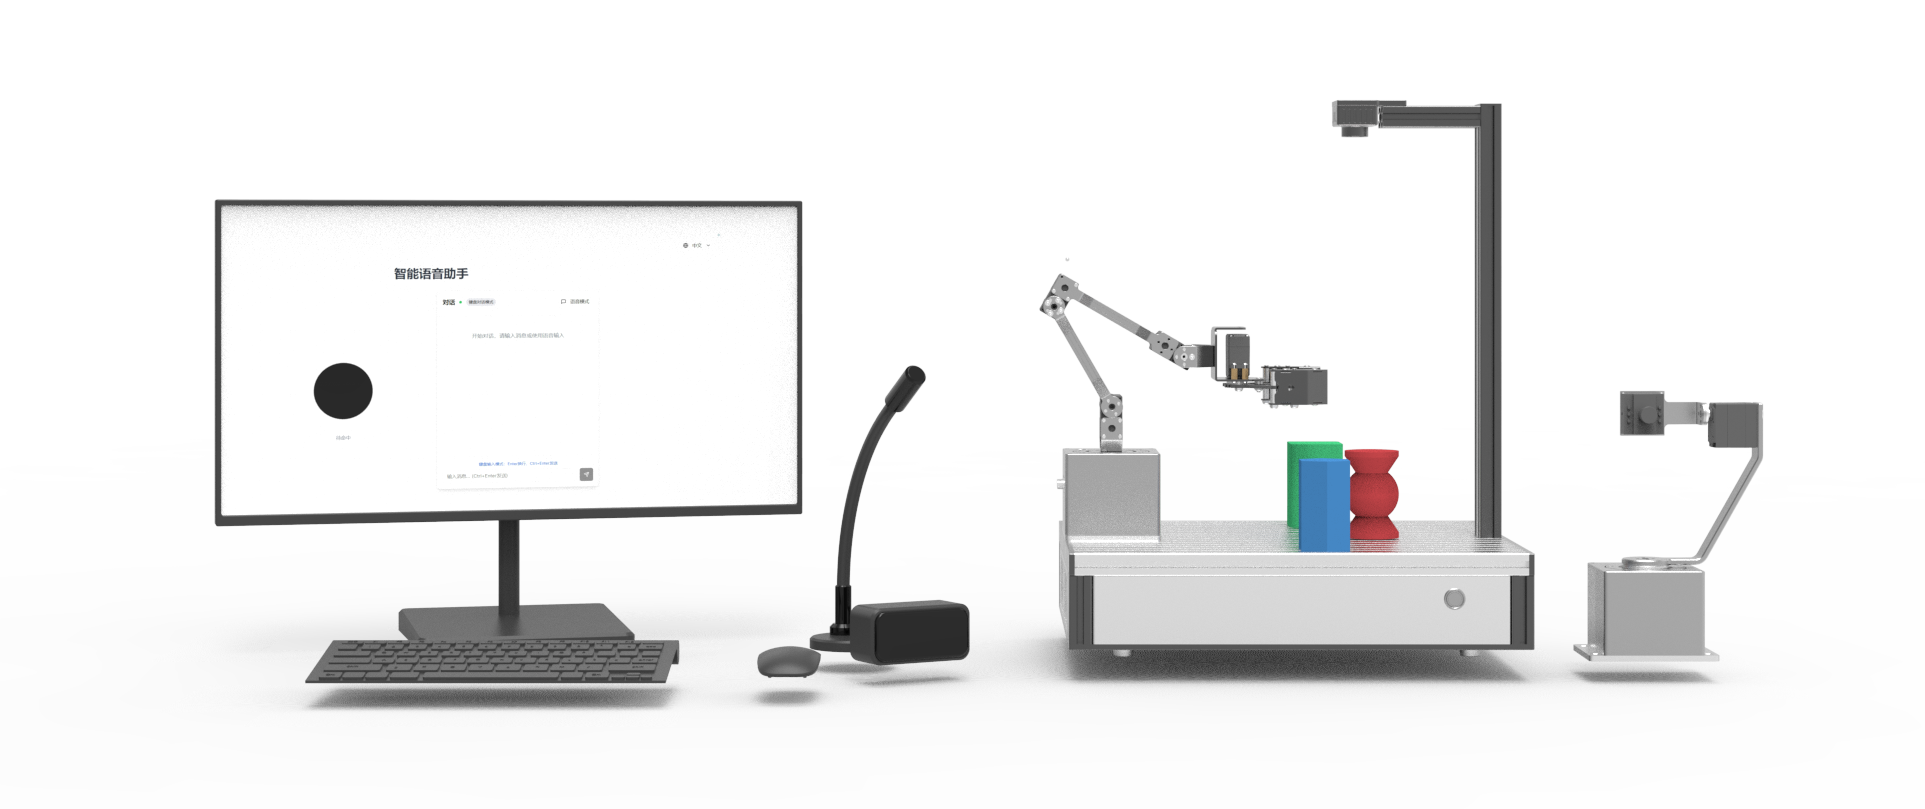
The system integrates AI voice, AI vision, a 4-DOF robotic arm, multiple sensors, and an AI embedded control board to provide a real-robot environment for implementing and debugging intelligent algorithms, seamlessly bridging theory and practice.
This platform provides diverse experimental scenarios based on a three-step process: embodied task planning, perception and decision-making, and action execution.
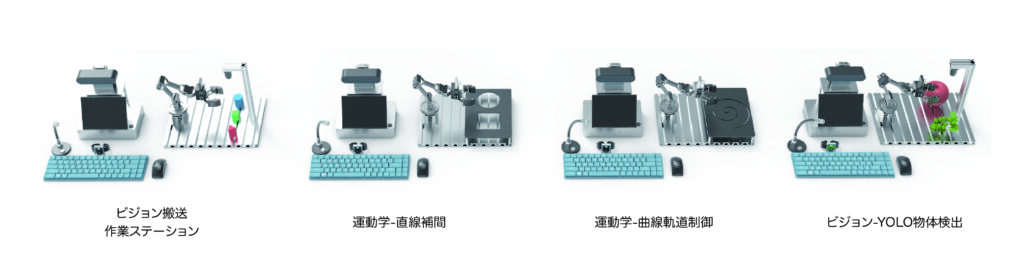
It covers a broad set of capabilities, including voice interaction, semantic task understanding, vision-based pan-tilt tracking, vision-guided robotic arm manipulation, kinematic trajectory control, and AI vision-based fruit and vegetable detection.
■ Applications & Use Cases
Features
Key Features
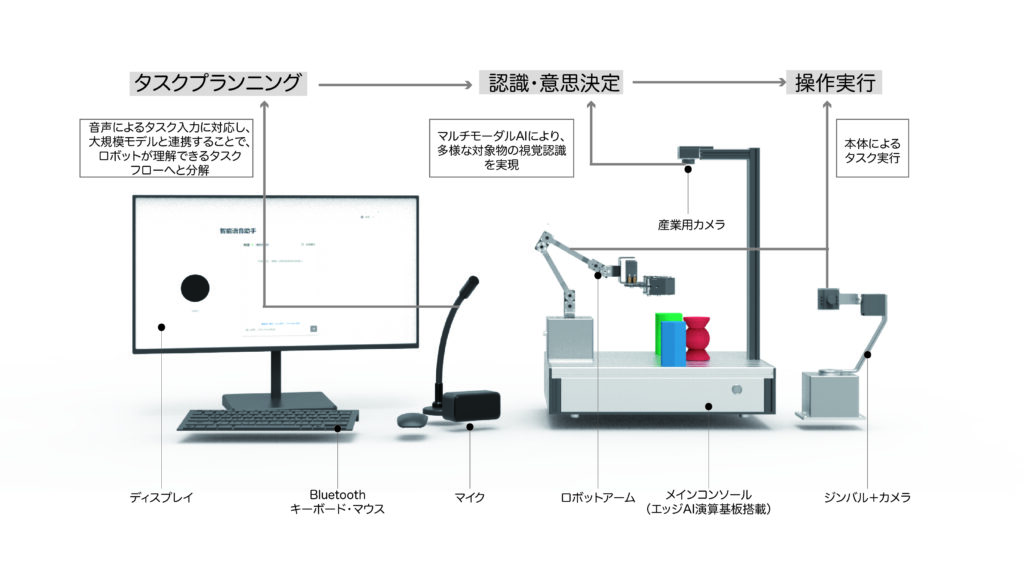
System Integration of AI and Robotics
Built around an intelligent robotic arm, the system integrates an AI voice interface, AI vision perception, and an AI embedded control board.
In addition, integrating devices such as a color recognition sensor and an attitude sensor, it enables educational training that covers the full pipeline from perception and decision-making to execution.
One-Stop Deployment
Fully calibrated at shipment, enabling immediate operation without additional equipment.
Featuring a compact 60 cm × 60 cm footprint, the system is designed for flexible use in laboratories and mobile classroom settings.
Step-by-Step Robot Arm Platform
Built on a 4-DOF robotic arm platform, with support for expansion to 6 DOF.
Students progressively develop system design skills through kinematics, control, simulation, and ROS-based practice.
Specifications
Specifications
Basic Specifications
| Robot Arm | 4-DOF Serial Arm with 1-DOF Gripper |
|---|---|
| Arm Length | 260mm |
| Payload Capacity | 300g |
| Gimbal Module | 2-DOF Gimbal with High-Resolution Camera Module |
| Monocular Camera Module | 720P / 2 Megapixels |
| Display Module | 13 inch |
| RDK X5 Board | ROS & Ubuntu (Pre-installed) / 10 TOPS Performance |
| Microphone and Speaker Module | For Voice Interaction |
| Wearable Gesture Module | Equipped with a gyroscope sensor, with a wearable strap for mounting. |
| Keyboard and Mouse | Logitech Wireless Bluetooth Keyboard and Mouse |
| Controller Module | Wireless Controller |
Software Configuration
Ubuntu, ROS2, and other essential software are pre-installed, allowing immediate development and demonstration right after unboxing.
Compatible with major frameworks including OpenCV, YOLO, and LLM SDKs, making it suitable for a wide range of applications from education to research.
Sensor configuration
Integrates a comprehensive set of feedback sensors for AI voice, visual perception, and robotic motion, enabling multimodal inputs for embodied task planning.
Microphone Array for AI Voice Interface
Pan-Tilt Camera Module for Vision
Color Recognition Sensor
Attitude Sensor
Object Recognition and Distance Sensing Expansion Interface
Controller Configuration
Built with an AI embedded control board and open I/O interfaces, enabling large-scale model inference and execution of vision algorithms.
It also enables robotic arm actuation and integration with various external devices, achieving unified hardware–software coordinated control.
Curriculum
Experiment Items
Large-Scale Model Integration and Application
■ Automatic Speech Recognition (ASR)
■ Natural Language Understanding (NLU) / LLM
■ Text-to-Speech (TTS)
■ Calculator Interaction via Function Calling
■ Music Playback Interaction via Function Calling
■ Task Planning for Cloud Vision System via Function Calling
■ Task Planning for Robot Vision Systems via Function Calling
Robot Vision and Machine Learning
■ Color Recognition
■ Shape Recognition
■ YOLO Deployment
■ Face Detection
■ Face Tracking and Workspace Detection
■ Vision-Based Workpiece Picking
Fundamentals of Robotics
■ Kinematics-Based Fixed-Point Motion for Robotic Arms
■ Kinematics-Based Linear Interpolation for Robotic Arms
■ Kinematics-Based Circular Interpolation for Robotic Arms
ROS
■ ROS Fundamentals
■ Keyboard-Based Robot Arm Control
■ Robot Arm Motion Planning with MoveIt!
■ Vision Detection Workstation
Sensor Detection and Control
■ Pose Detection
■ Robot Arm Control via Attitude Control
■ Vision Detection
■ Vision Tracking
■ Vision-Guided Manipulation
Embedded Systems Development and Applications
■ Linux Basics
■ Serial Communication Experiment
■ Socket Communication Experiment
■ Multithreading Experiment
■ GUI Design Experiment
Contact
Consultation on Deployment, Demos and Quotes
From product selection to integrating robots into your classes or research, feel free to contact us.