Physical AI Solution — Data Service
HumansX × LITCHIReal-World
Multimodal Data
Collected at real work sites, then processed, annotated and quality-checked.
We deliver data ready to train your robots.
Authorized distributor of LITCHI in Japan: HumansX (point of contact in Japan & project management)
About
From collection to delivery,
in one seamless flow.
Our data infrastructure covers device management, on-device quality checks, data transfer, annotation, QA, data augmentation and visualization, turning recordings of real work into multimodal embodied data ready for model training.
First-person cameras, third-person cameras and data collection gloves record visual, motion, spatial and contact information during real tasks.
Why
Broad, deep, accurate and stable
Covers real tasks
Handles different operators, objects, tools and environments, including one-handed, two-handed and continuous tasks.
Multimodal
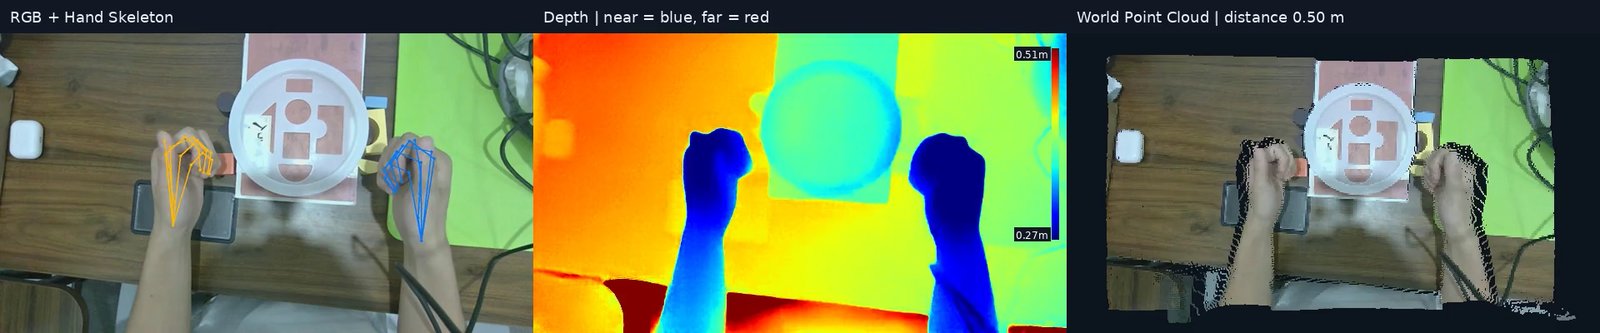
RGB, depth, IMU, hand joints, 6-axis force, tactile data and task semantics are recorded in sync.
Reconstructs space and physics
Reconstructs the spatial relationships and physical states of hands, objects and environment, and outputs accurate camera poses, point clouds and force data.
Standardized production
A reproducible pipeline from task definition and collection validation to processing, annotation, QA and version control.
Real Sites
Natural work, recorded as it happens at real sites
Real environments
Collected in real work environments, preserving natural work rhythm, environmental noise and task context.
Complex manipulation
Supports two-handed coordination, tool use, fine contact and continuous tasks.
Wide variation
Covers variation in operators, objects, spatial layouts, motion paths and outcomes.
Large-scale management
Managed by site, date, task and batch, with continuous tracking of volume, quality and progress.
We support a wide range of sites, including food service, agriculture, manufacturing and services.
What's Inside
What each data record contains
From a single task, we record the following four types of data in sync and deliver them together.
Video & depth
First- and third-person RGB video, plus raw and optimized depth and IMU data.
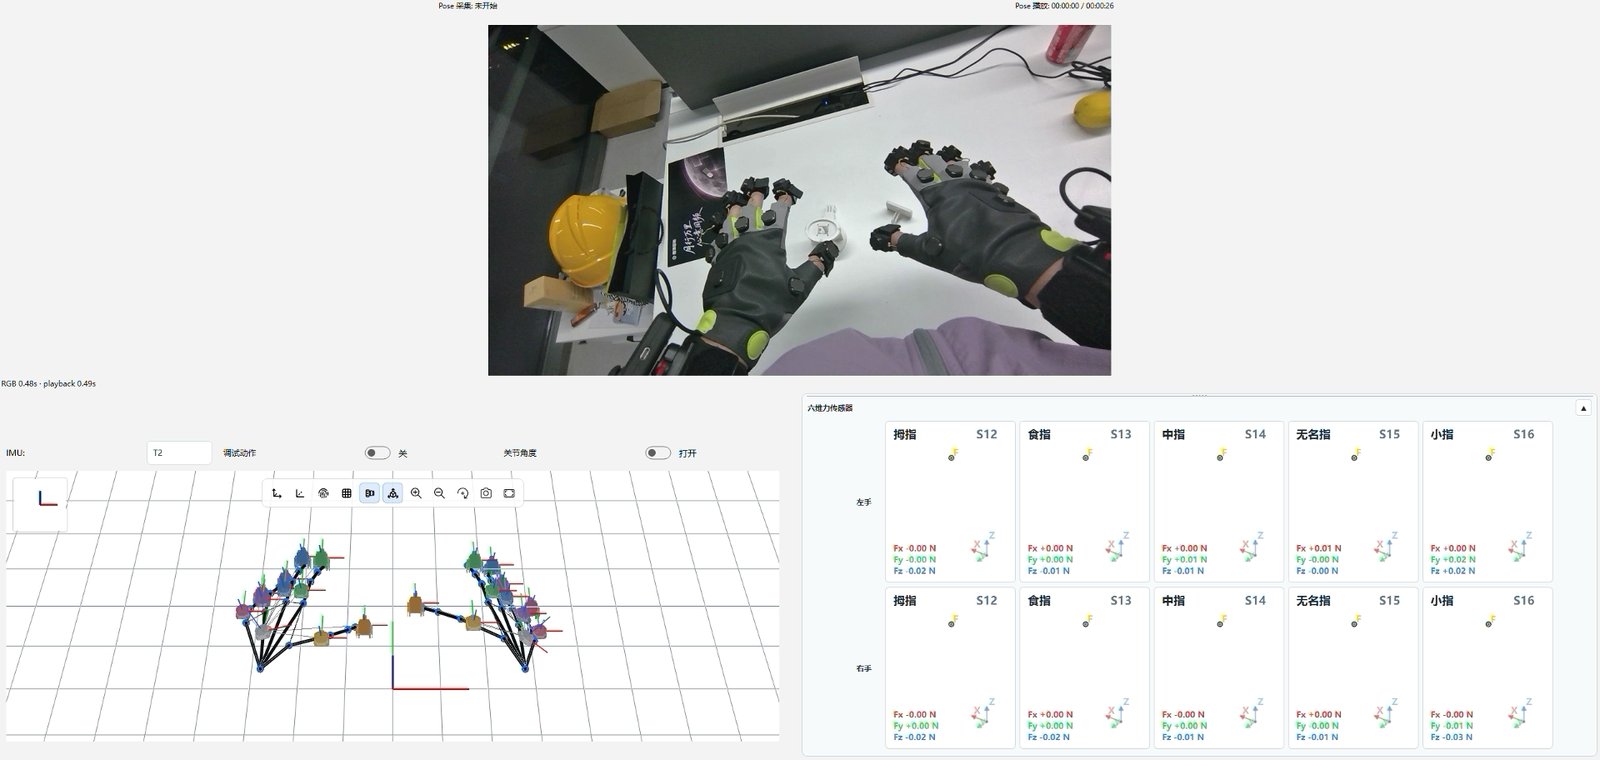
Hands & force
3D position and orientation of 21 hand joints, plus 6-axis force and tactile data capturing contact and force changes.
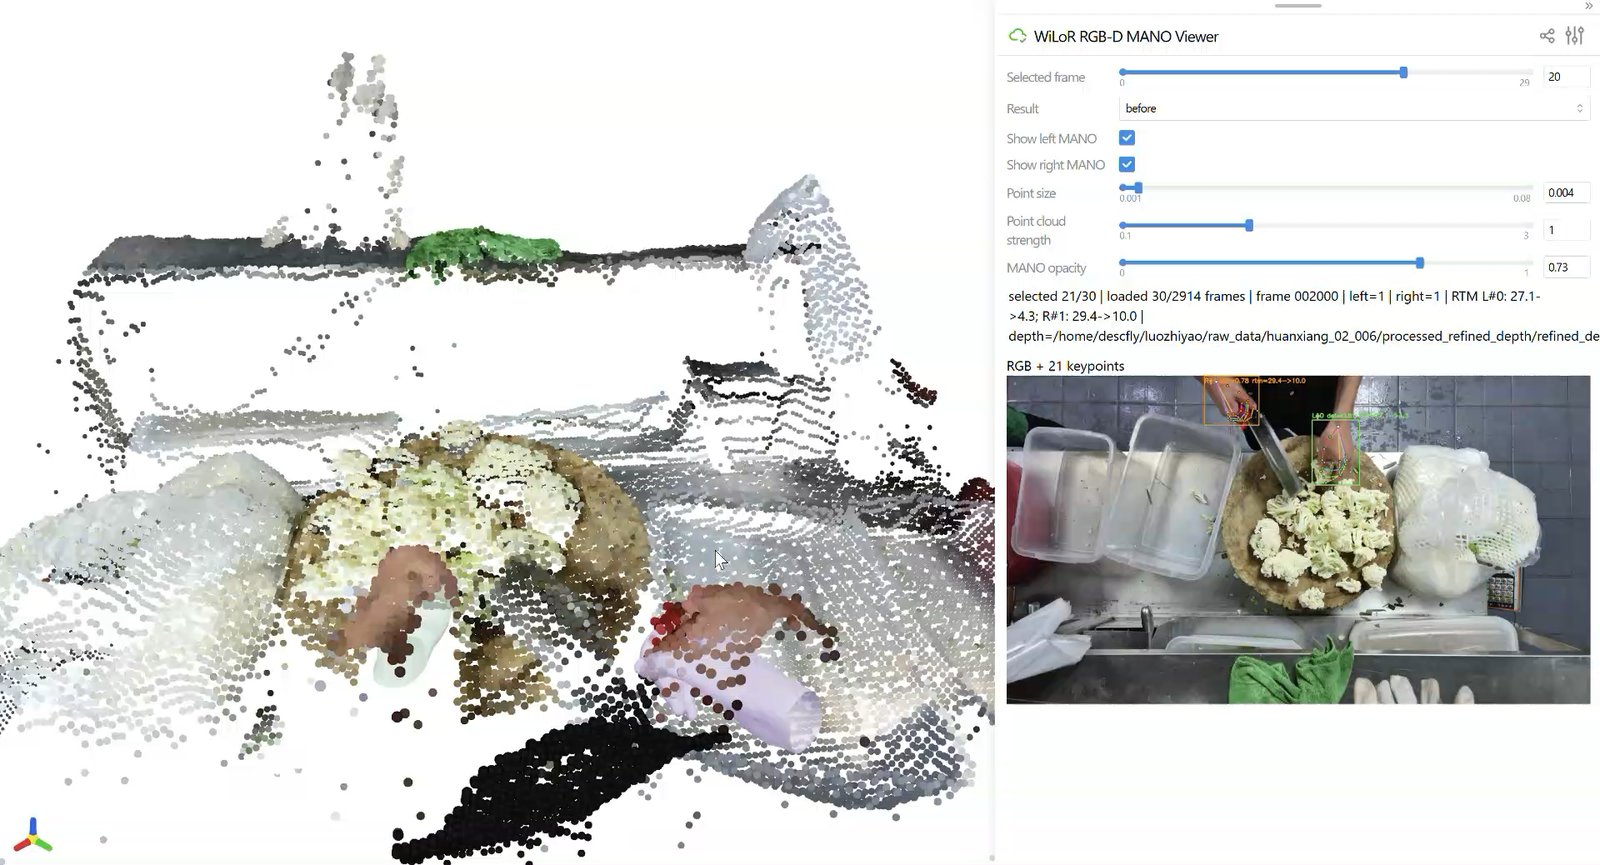
Position & shape
Camera poses, 6-DoF poses of manipulated objects and a point cloud of the whole scene.
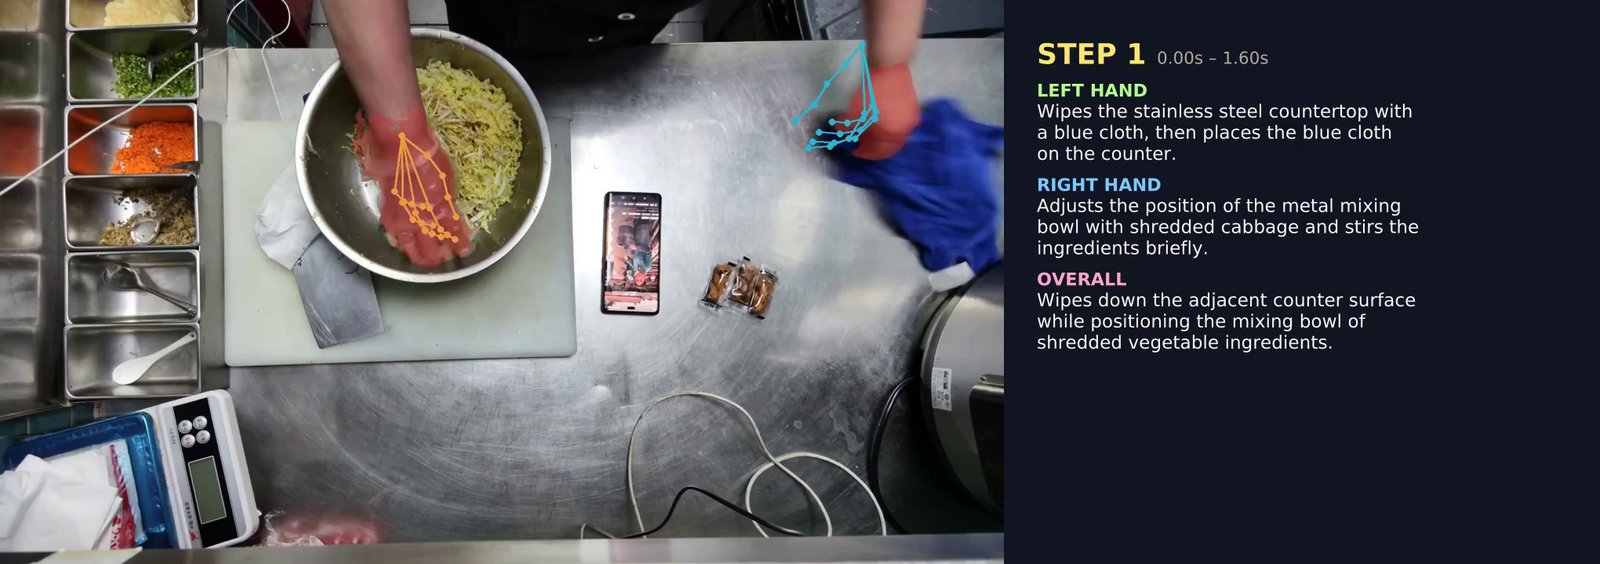
Semantics
Task instructions, subtasks, atomic actions, states and outcomes, annotated per time segment.
Quality
Whether data is usable for training
depends on spatial, motion and force accuracy
- Optimized depth and 3D space: reconstructs scene depth and geometry, plus the 3D layout of hands, objects and surroundings
- Accurate hand pose: records hand position, orientation and continuous motion trajectories in 3D space
- 6-axis force and tactile: captures contact and force changes during tasks with 3-axis forces and 3-axis moments
Process
From collection to delivery
Define task scope, site conditions, data items and acceptance criteria
Validate equipment setup, procedures and output format with a small pilot
Scale up collection with unified SOPs and parameters
Time sync, depth optimization, pose computation, task segmentation and semantic annotation
Check for anomalies and deliver with batch, version and quality records
Contact
Contact us about data collection
Tell us the target tasks, data volume, timeline and data format. HumansX will be your point of contact in Japan and propose the best collection plan.