 Documentation
Wuji Hand 2
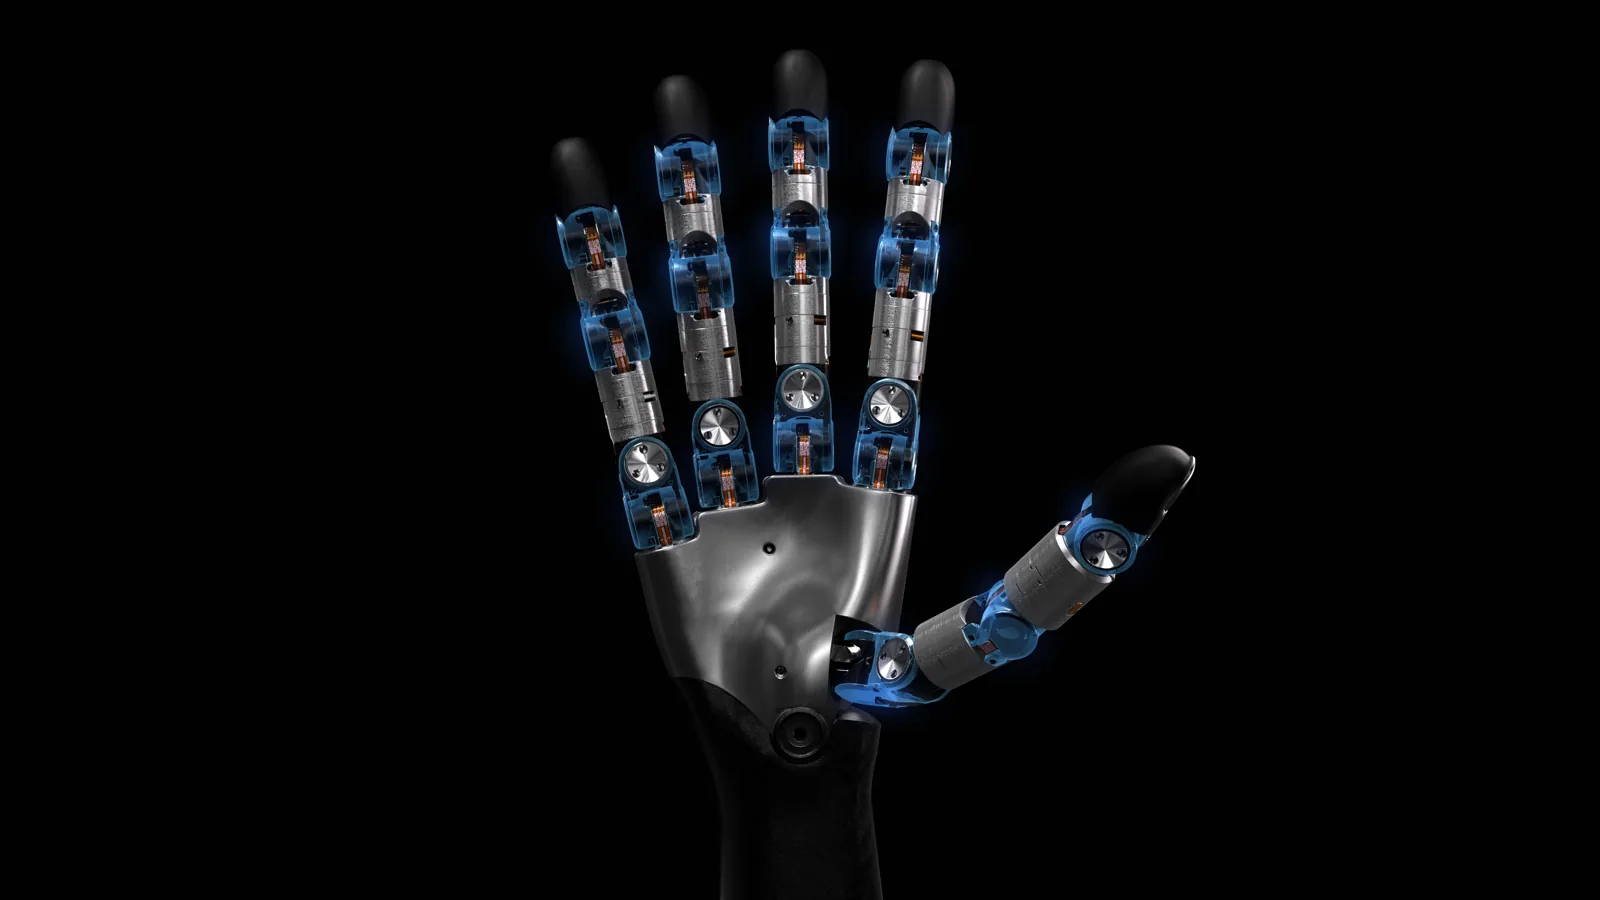
A 20-DoF, direct-drive dexterous robotic hand Paired with the Wuji Glove teleoperation glove for an end-to-end workflow from data collection to training
Human-level dexterity, for research and development.
Wuji Hand 2 is a five-finger dexterous robotic hand developed by Wuji Technology. All 20 degrees of freedom — four per finger — are directly driven by motors, reproducing full thumb opposition and finger abduction. MIT-style hybrid force-position control enables delicate manipulation such as pinching, twisting and pressing.
As the official distributor in Japan, HumansX supports you in Japanese from product selection and demos to post-installation technical support.
Four core technologies behind its dexterity
20 DoF for a wide range of hand poses
Designed for long-term, stable operation
From durability to ease of integration, it minimizes maintenance effort and recovery time after failures, so you can focus on your research and development.
Covering the entire workflow, from development to training
With a data glove, human hand motion goes directly to robots.
A teleoperation glove that captures fingertip position and orientation precisely with electromagnetic motion capture. Combined with Wuji Hand 2, it covers everything from collecting dexterous manipulation data to training.
- 6-DoF electromagnetic tracking, position accuracy ≤ 2 mm, orientation accuracy < 5°, 120 Hz output
- 6-axis wrist IMU (800 Hz); motion-to-data latency ≤ 10 ms
- Lightweight fabric design, glove body 67.5 g
- USB Type-C power, RJ45 (100BASE-TX) connection, Python SDK / CLI support
Capture human hand motion with the glove
Converted to robot hand joints in real time
Wuji Hand 2 reproduces the same motion
Train AI models with the collected data
Wuji Hand 2 × Wuji Glove Deploy it as a complete dual-arm system.
We also offer the Dual-Arm Data Collection System, combining a force-controlled dual-arm robot with Wuji Hand 2 (left & right), Wuji Glove, VR teleoperation and synchronized recording software. Start collecting bimanual data right after delivery, with no integration work.
Main Use Cases
- Research on embodied AI and dexterous manipulation at universities and research institutes
- Collecting imitation-learning data through teleoperation
- Mounting on humanoid robots as an end effector
- Sim-to-Real validation using simulation (MuJoCo / Isaac Sim)
- Technical validation toward automating precision tasks such as grasping and assembly