 Documentation
LITCHI T1 Series
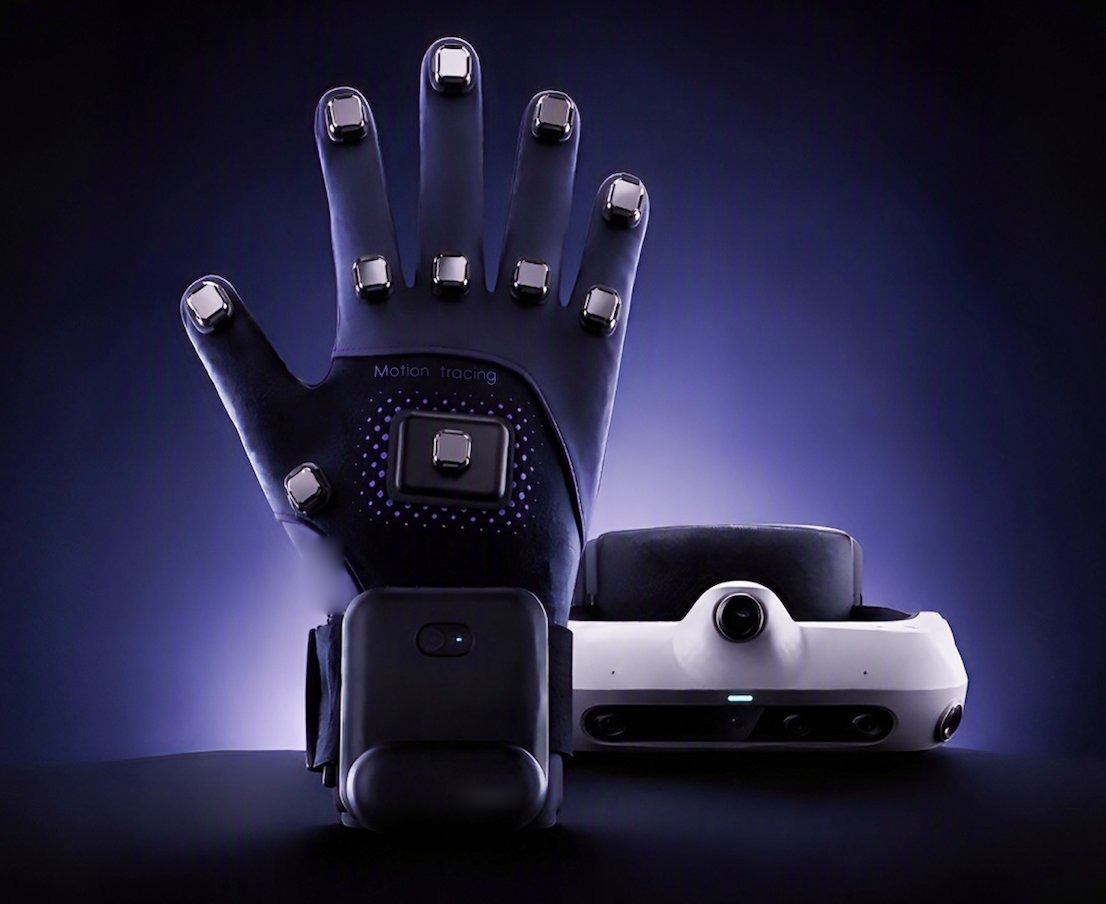
Teleoperation and imitation learning data collection in one glove. Wireless and low-latency, it captures hand motion with high precision, in three models to fit your use: T1 Lite, T1 and T1 Pro (with tactile sensing)
Human hand motion, straight into robot training data.
The LITCHI T1 Series is a glove for teleoperation and data collection developed by LITCHI, a Physical AI infrastructure company with the motto “Let Intelligence Flow”. Multi-IMU pose tracking reproduces hand motion with high precision, and by syncing with the first-person (Ego) data collection device it records both “what the operator sees” and “how the hands move” at real work sites.
It captures data reliably even near motors and high-current wiring, making it well suited to teleoperation close to robots. LITCHI runs its own end-to-end collection, processing and quality control of real-task data, and the T1 is the equipment used in that work. As the authorized distributor in Japan, HumansX supports you in Japanese from product supply to collection setup and technical support.
Demo: a single T1 glove teleoperating several robot hands with different designs at the same time
Three models for different applications
If you need tactile or contact-force data, choose T1 Pro or Wuji Glove. See the specification table for differences between models.
Combine with the LITCHI EGO egocentric data collection device
A data collection device that records hands-on work from a first-person view. Four wide-angle RGB cameras and one structured-light stereo depth camera capture tasks within 1.5 m in 3D, recorded in sync with T1 glove data.
- RGB × 4 + depth camera × 1
- Built-in 9-axis IMU and four microphones
- Weight under 400 g
- RGB up to 1920 × 1200 @ 30 fps, global shutter
- Depth 1280 × 800 @ 30 fps, spatial accuracy < 0.5% (at 1 m)
- Weight under 400 g
- Image-to-IMU sync error < 1 ms
- External trigger supported
- Video encoding H.264 / H.265
Training-ready data from a single task
Use cases
- Data collection for imitation learning of humanoids and dual-arm robots
- Motion recording at real work sites such as factories, logistics and food processing
- Teleoperation of multi-finger robot hands
- Building first-person data for foundation models such as VLA