Physical AI Education Kit
RAI-M4
Physical AI Learning Platform
Perception, decision and action — embodied AI, all in one.
Overview
From Language to Action
Perception, decision and action — embodied AI, all in one
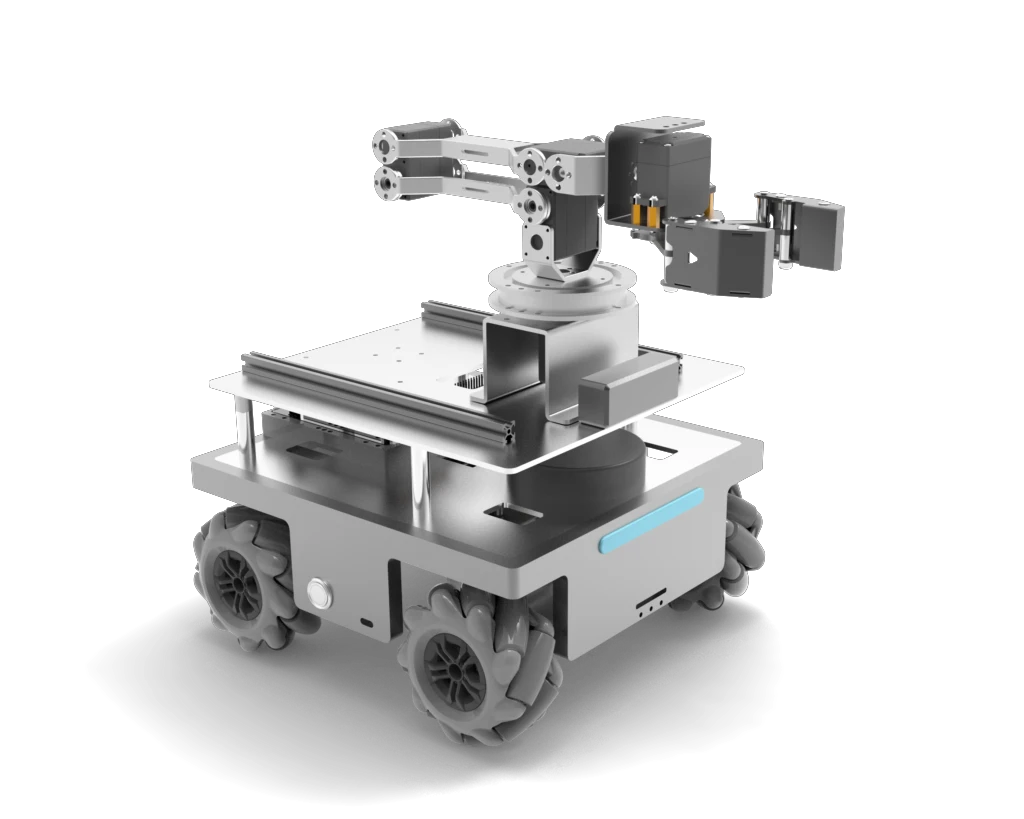
RAI-M4 combines planning, perception, and execution to deliver intelligent interaction and adaptive real-world performance.
Transforms natural language into action with multimodal perception for flexible real-world adaptation.
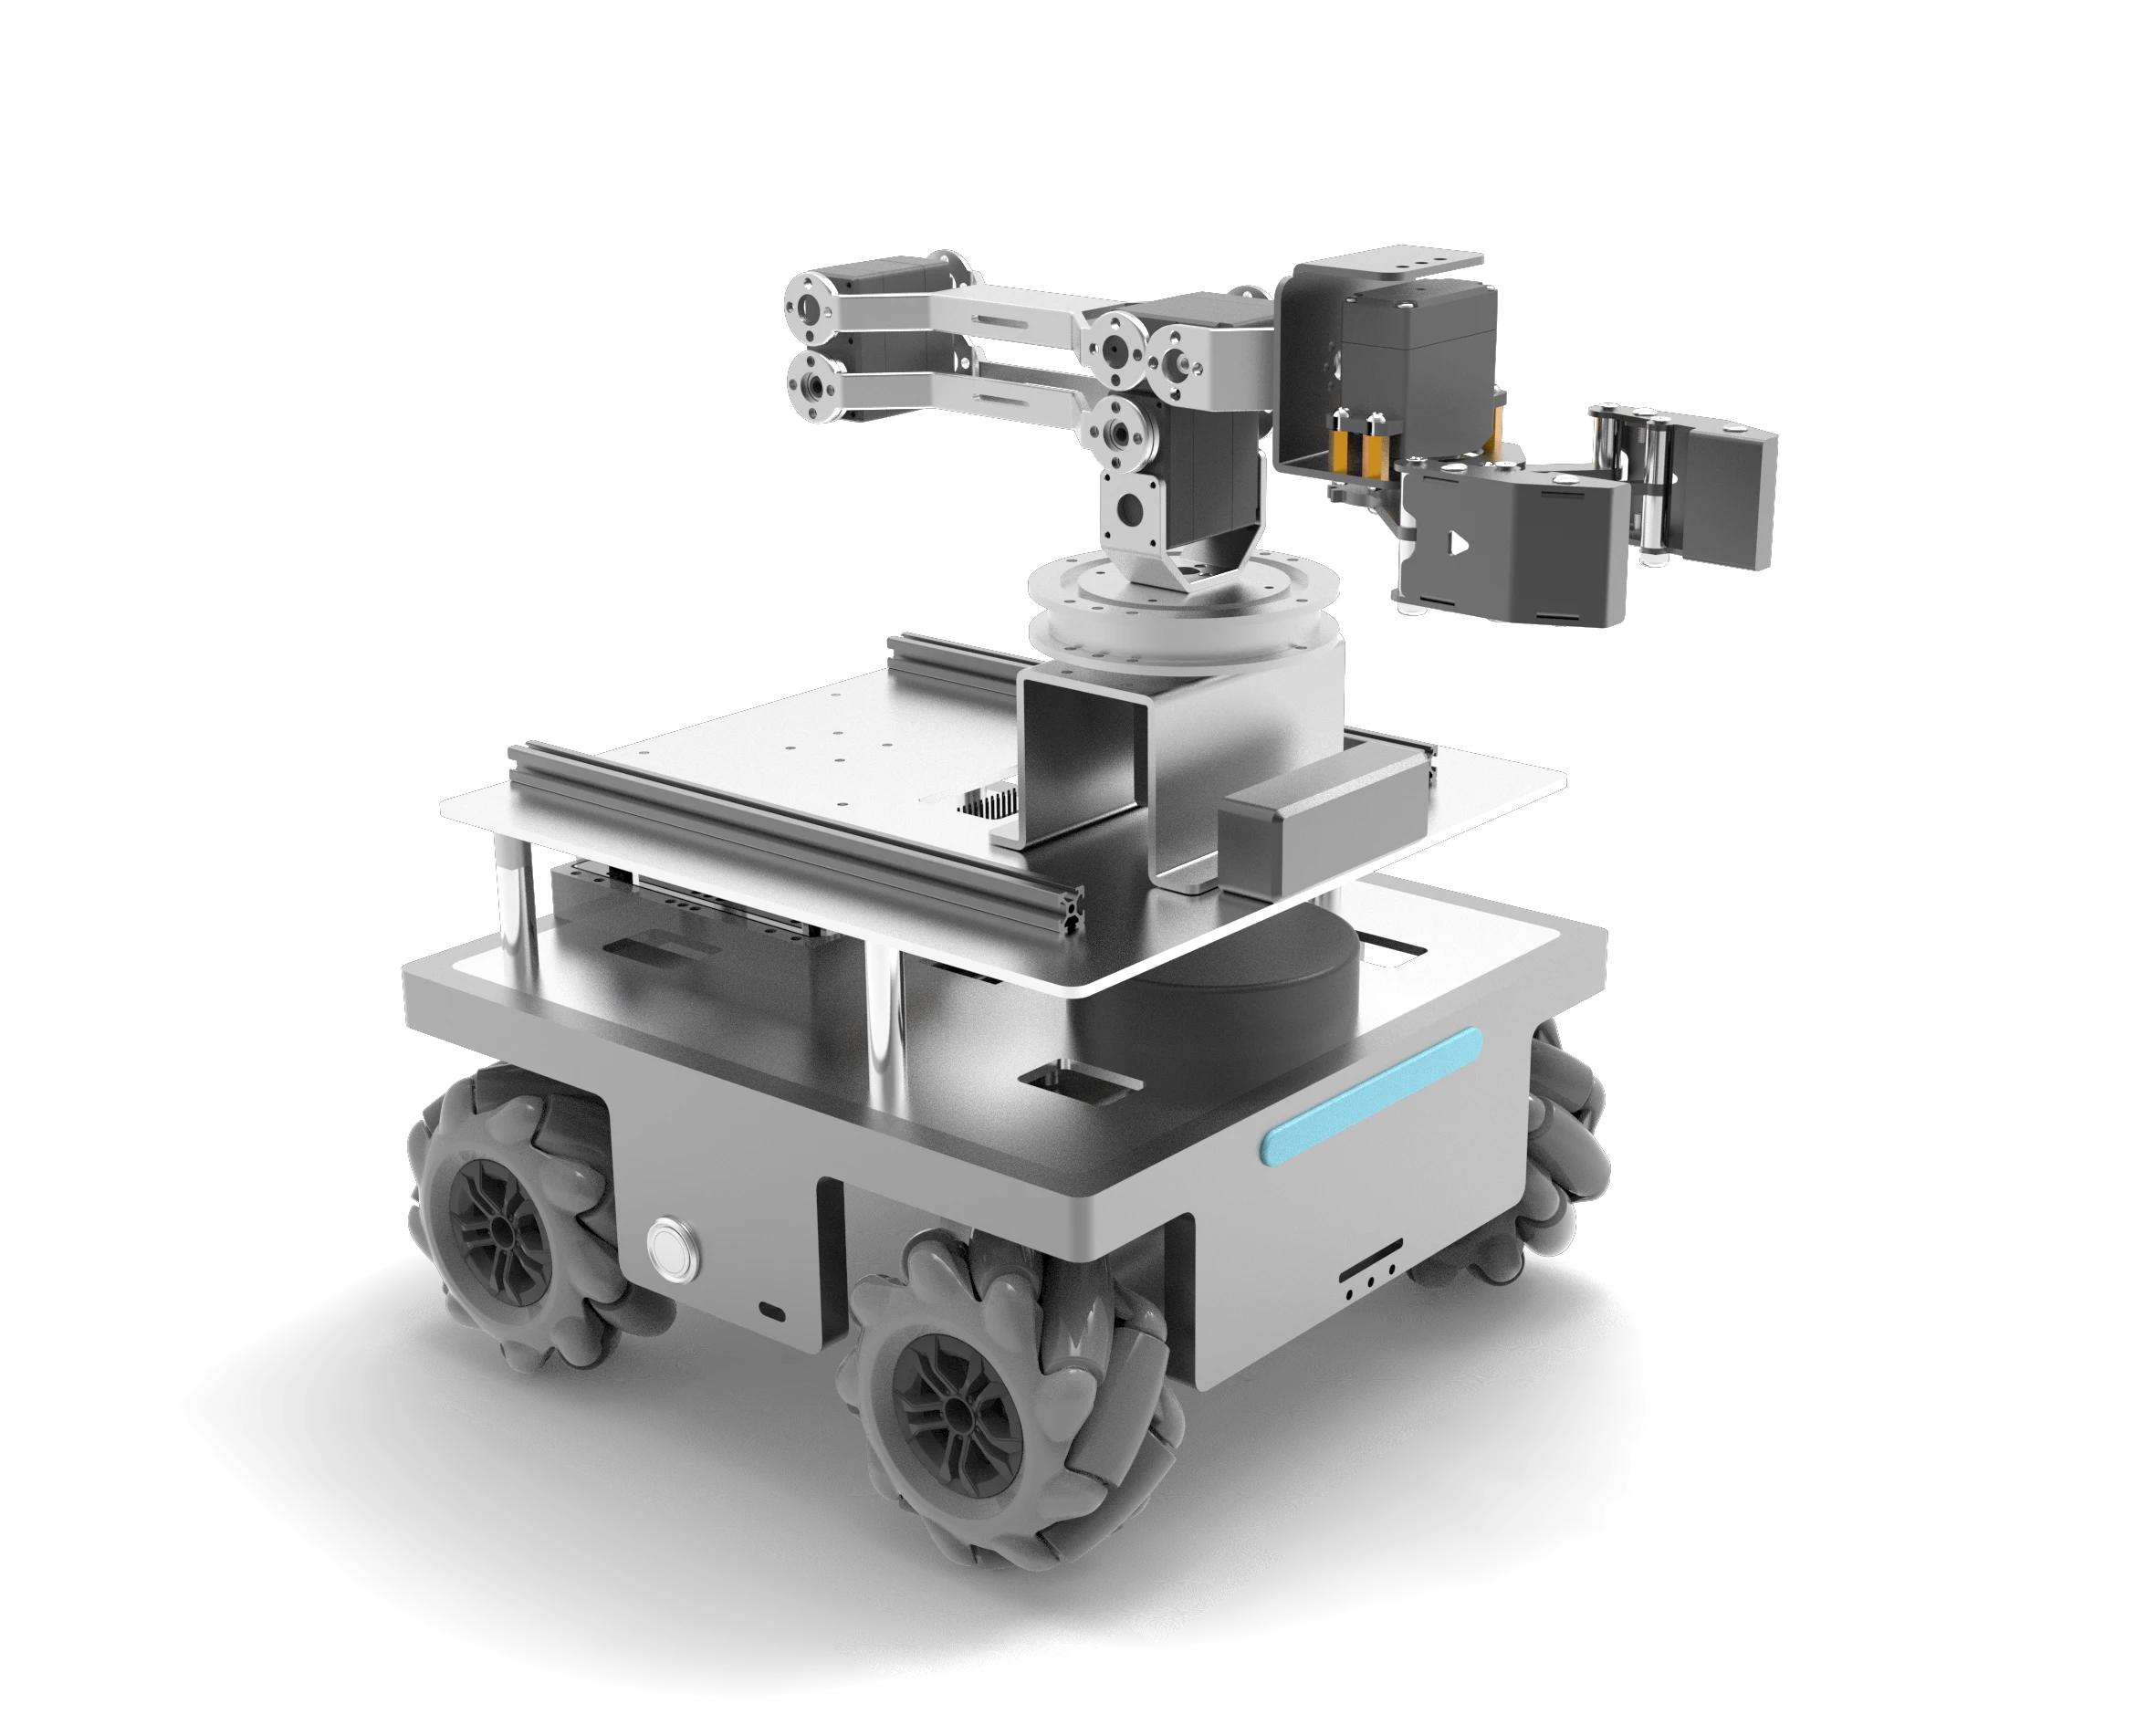
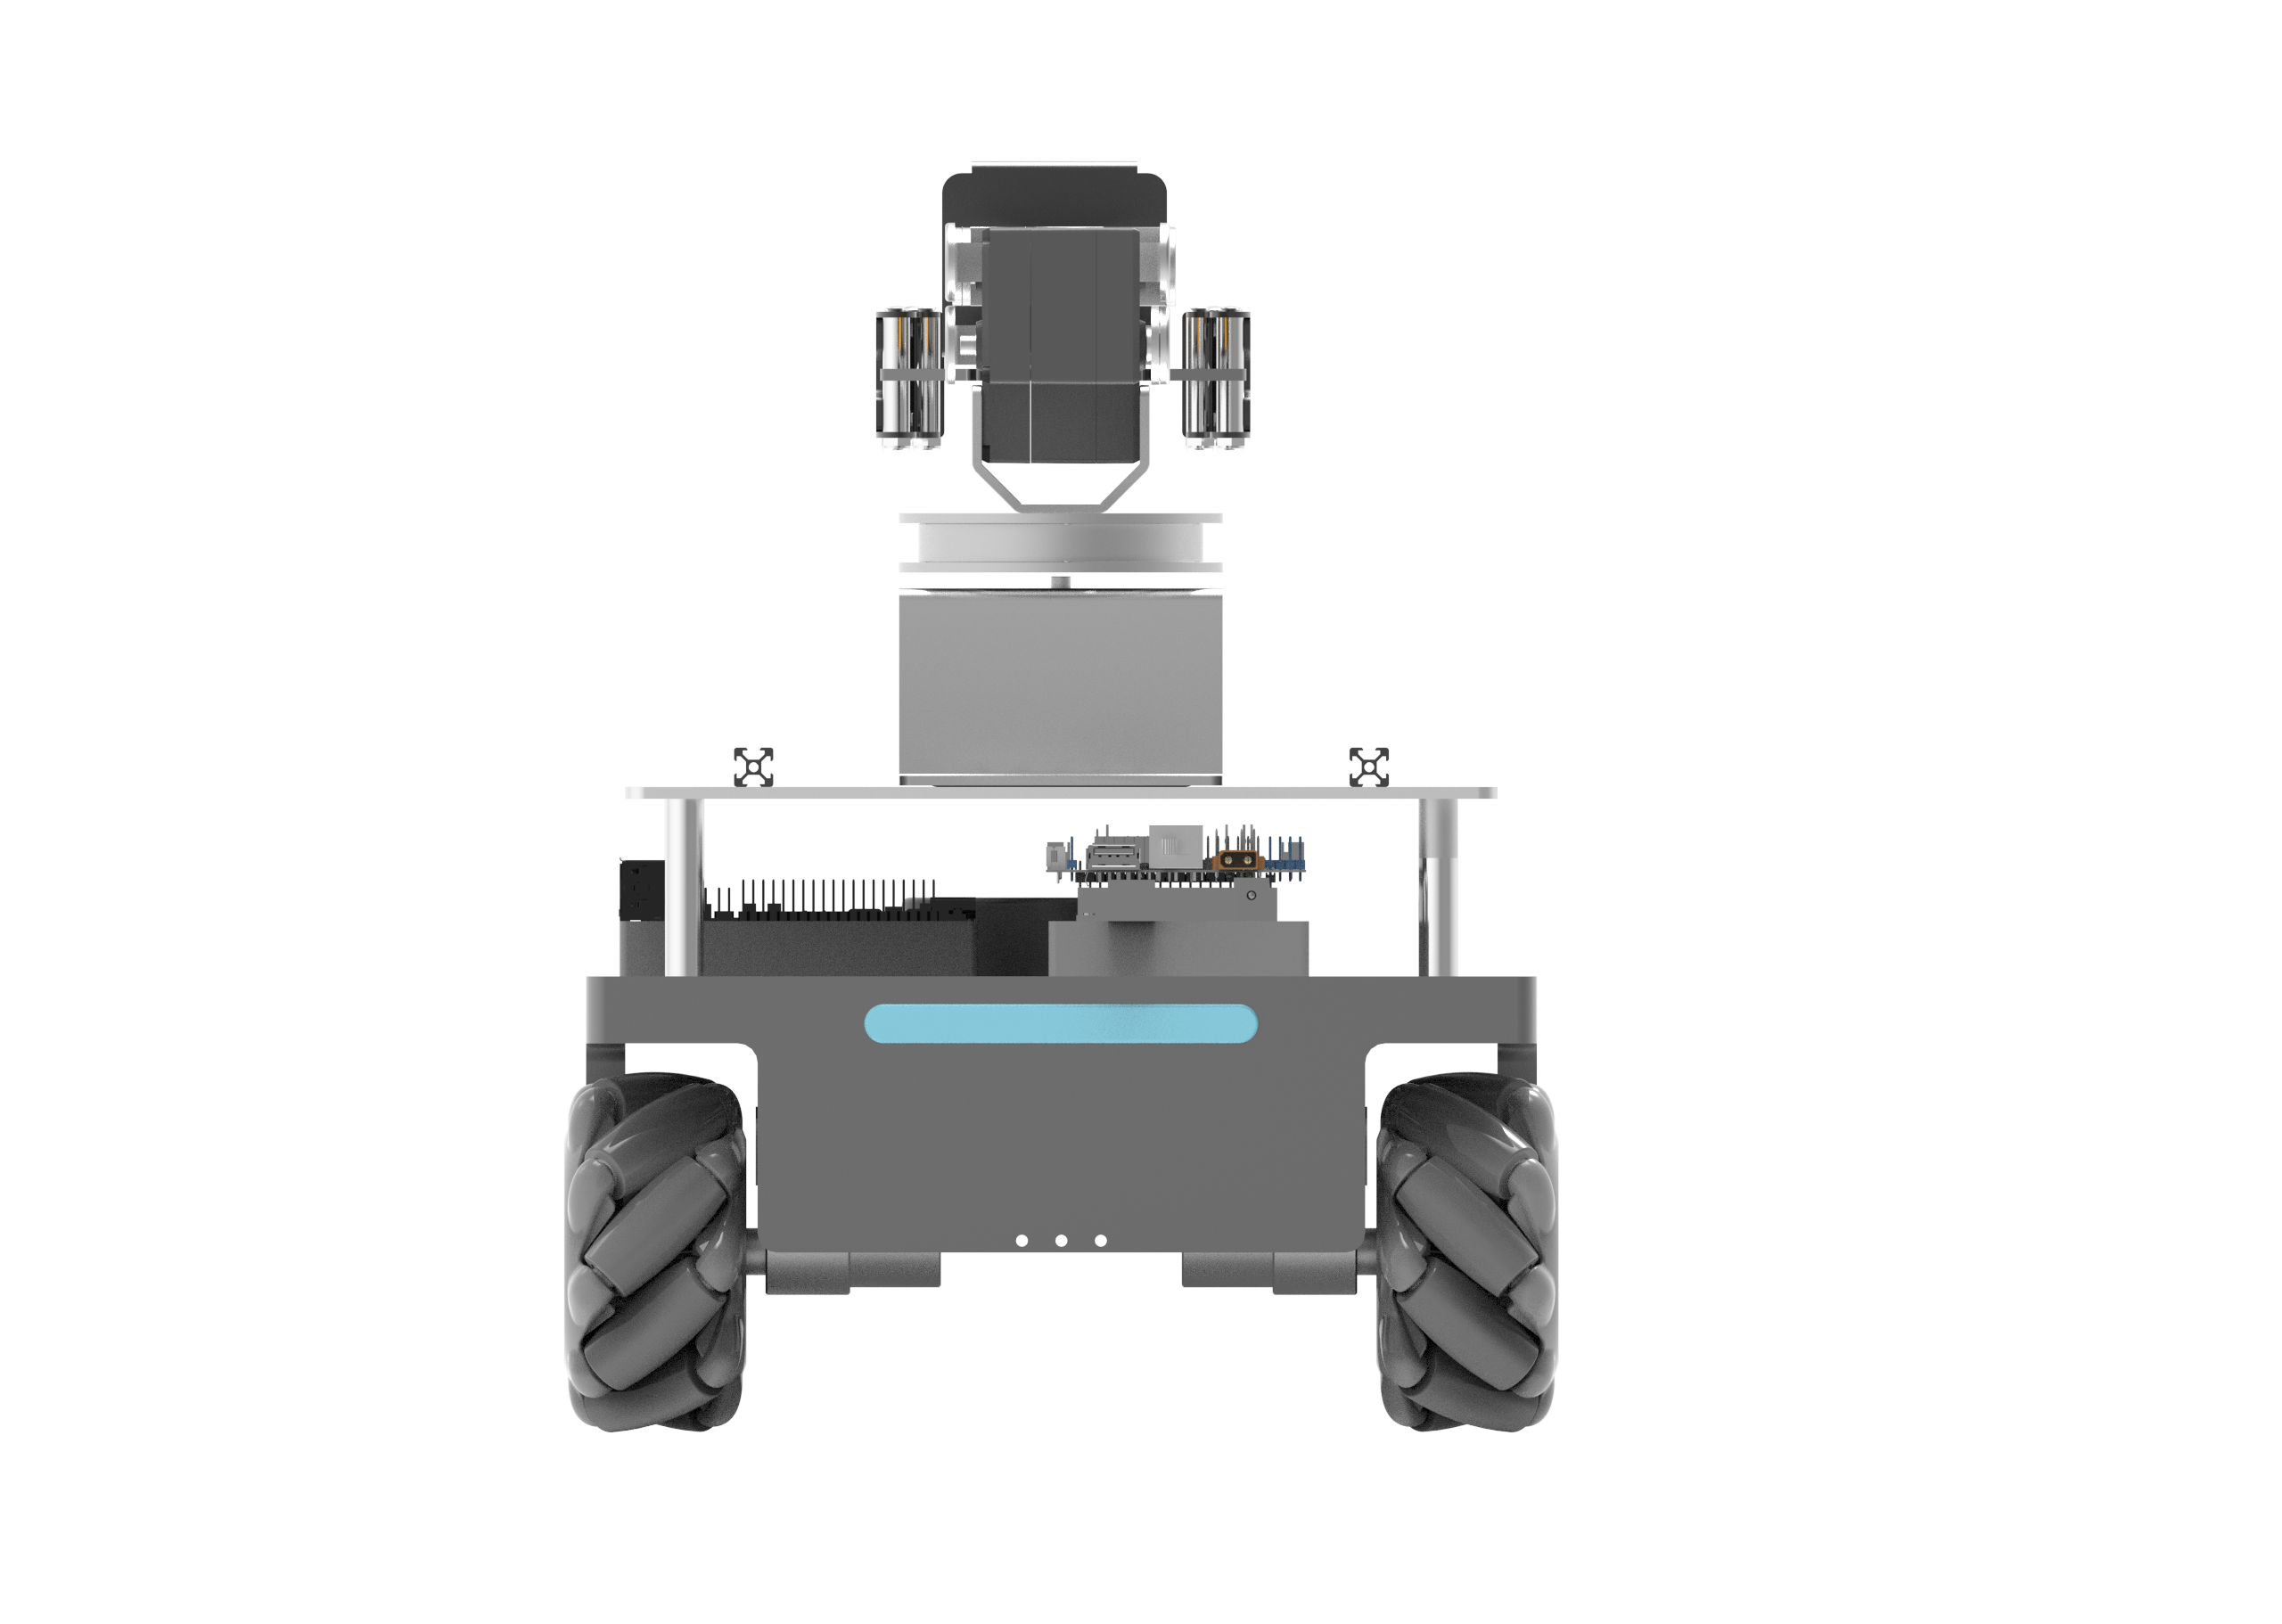
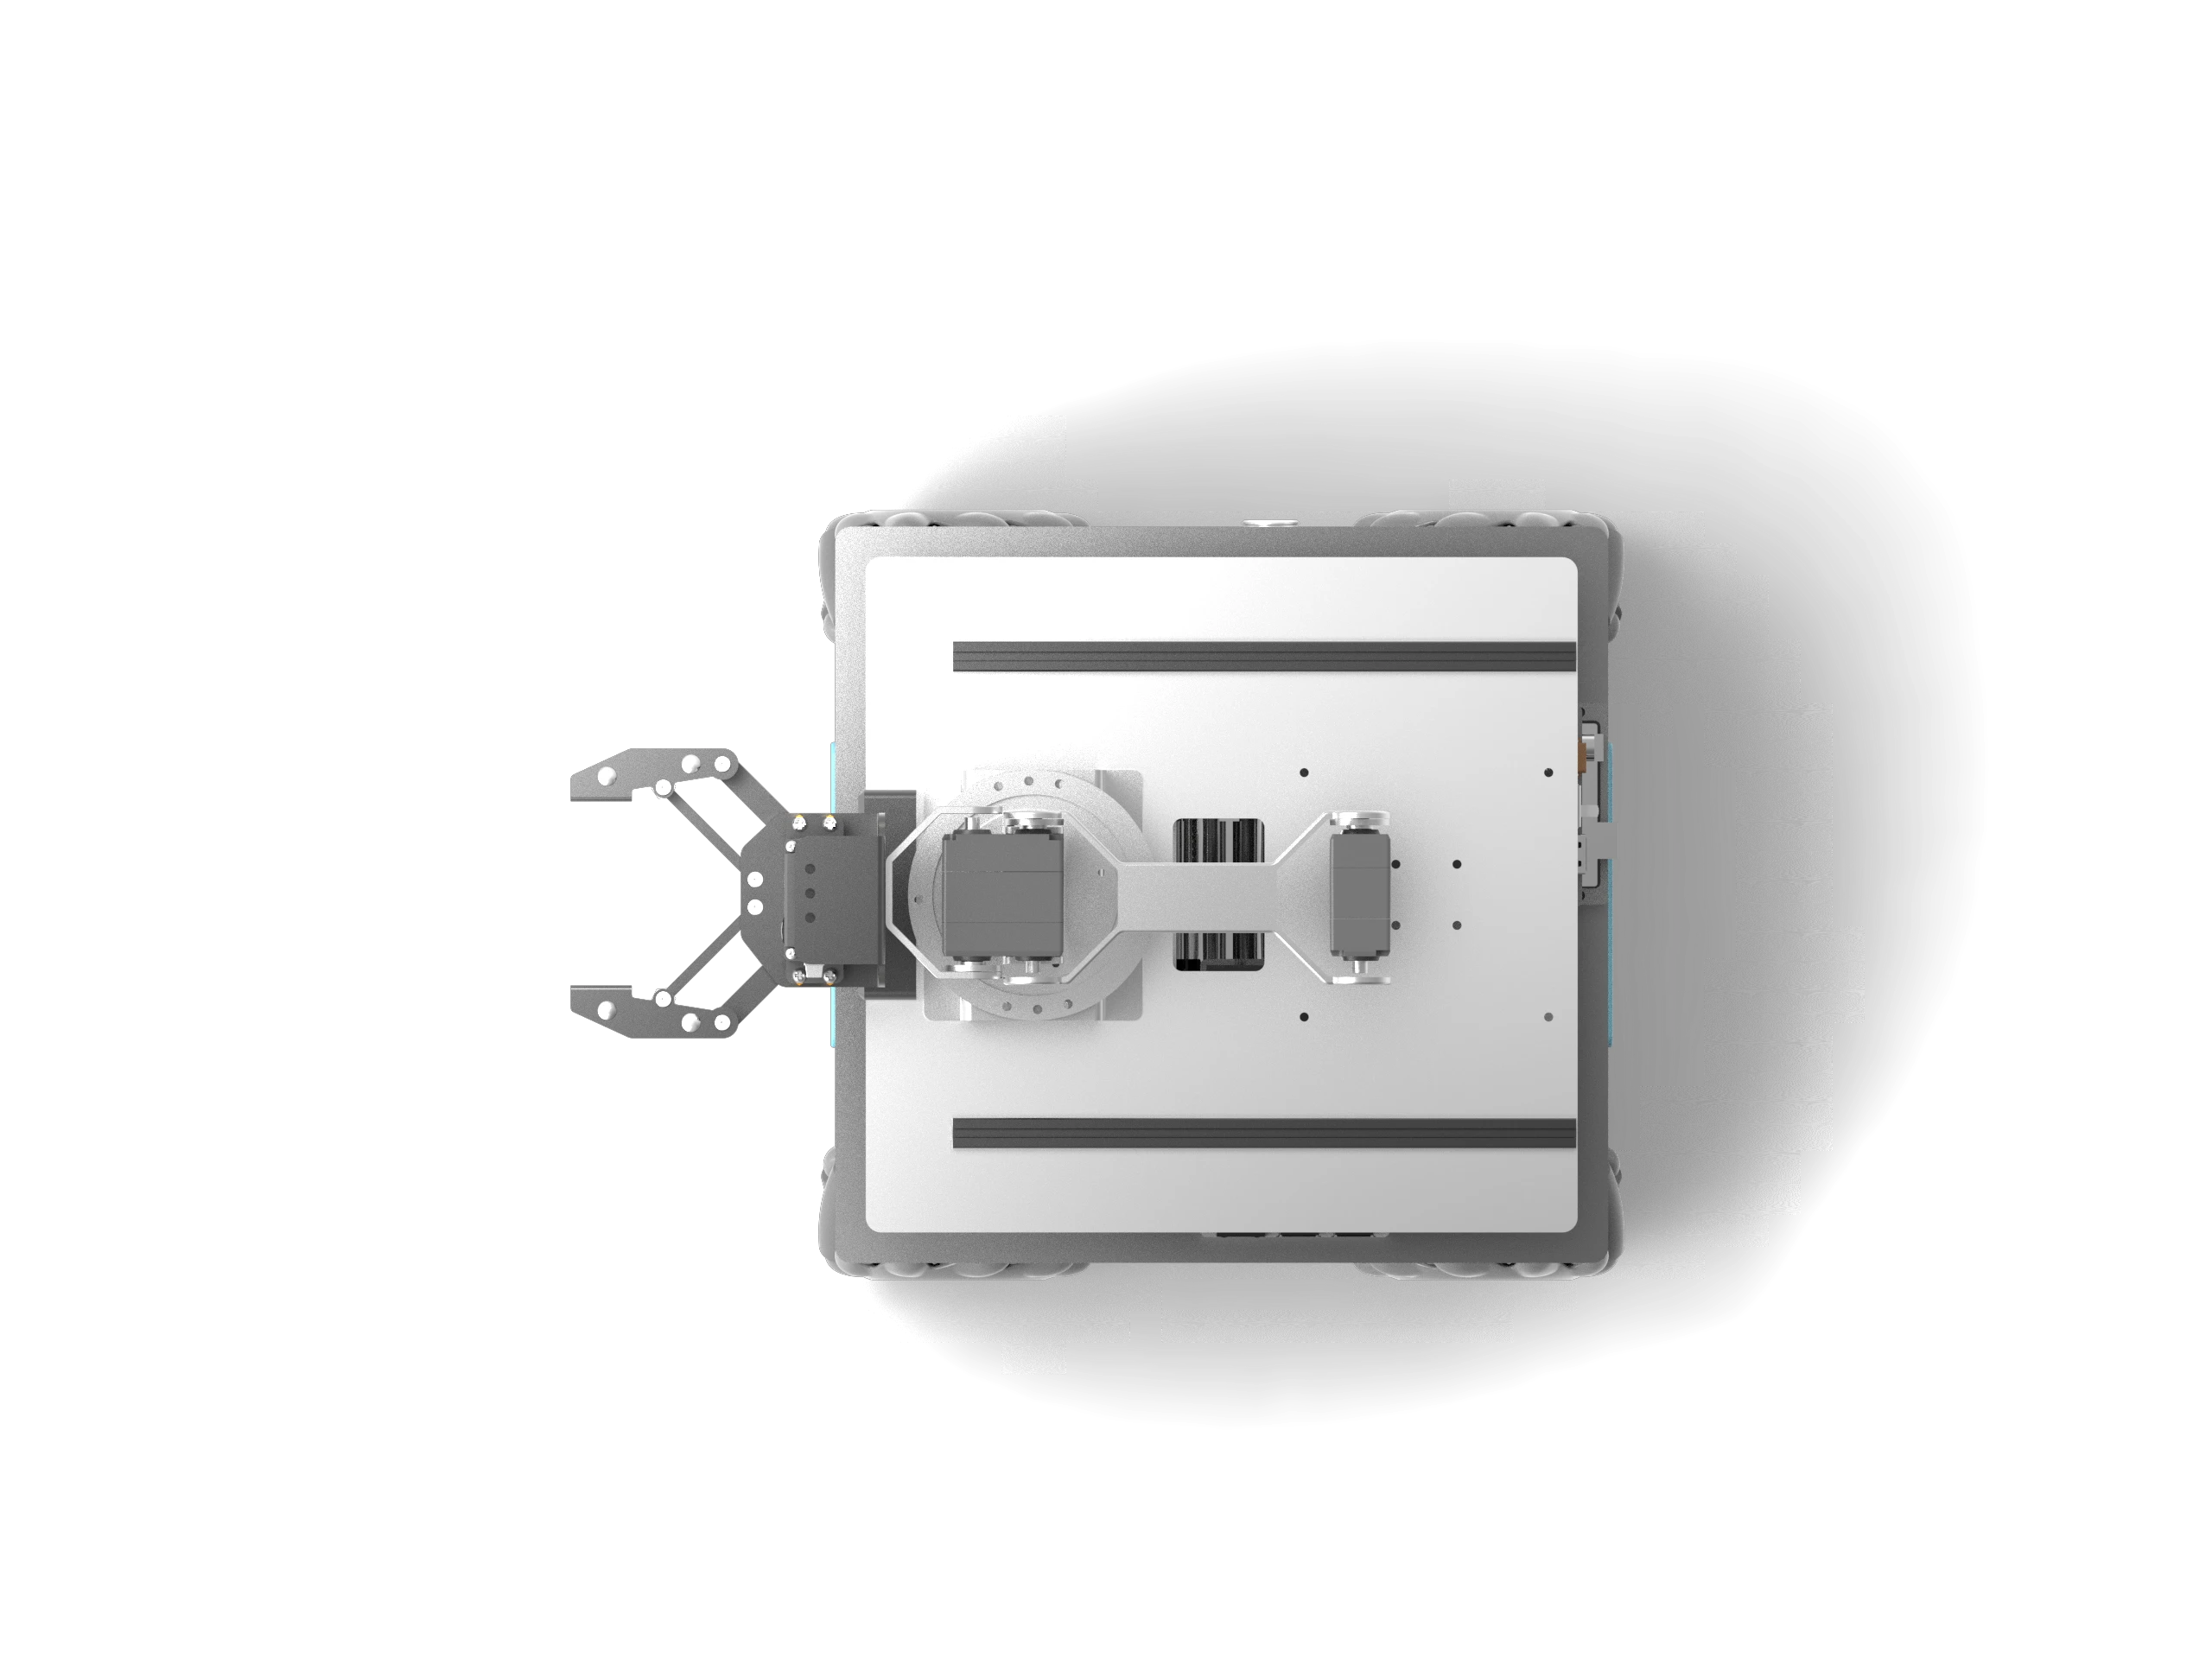
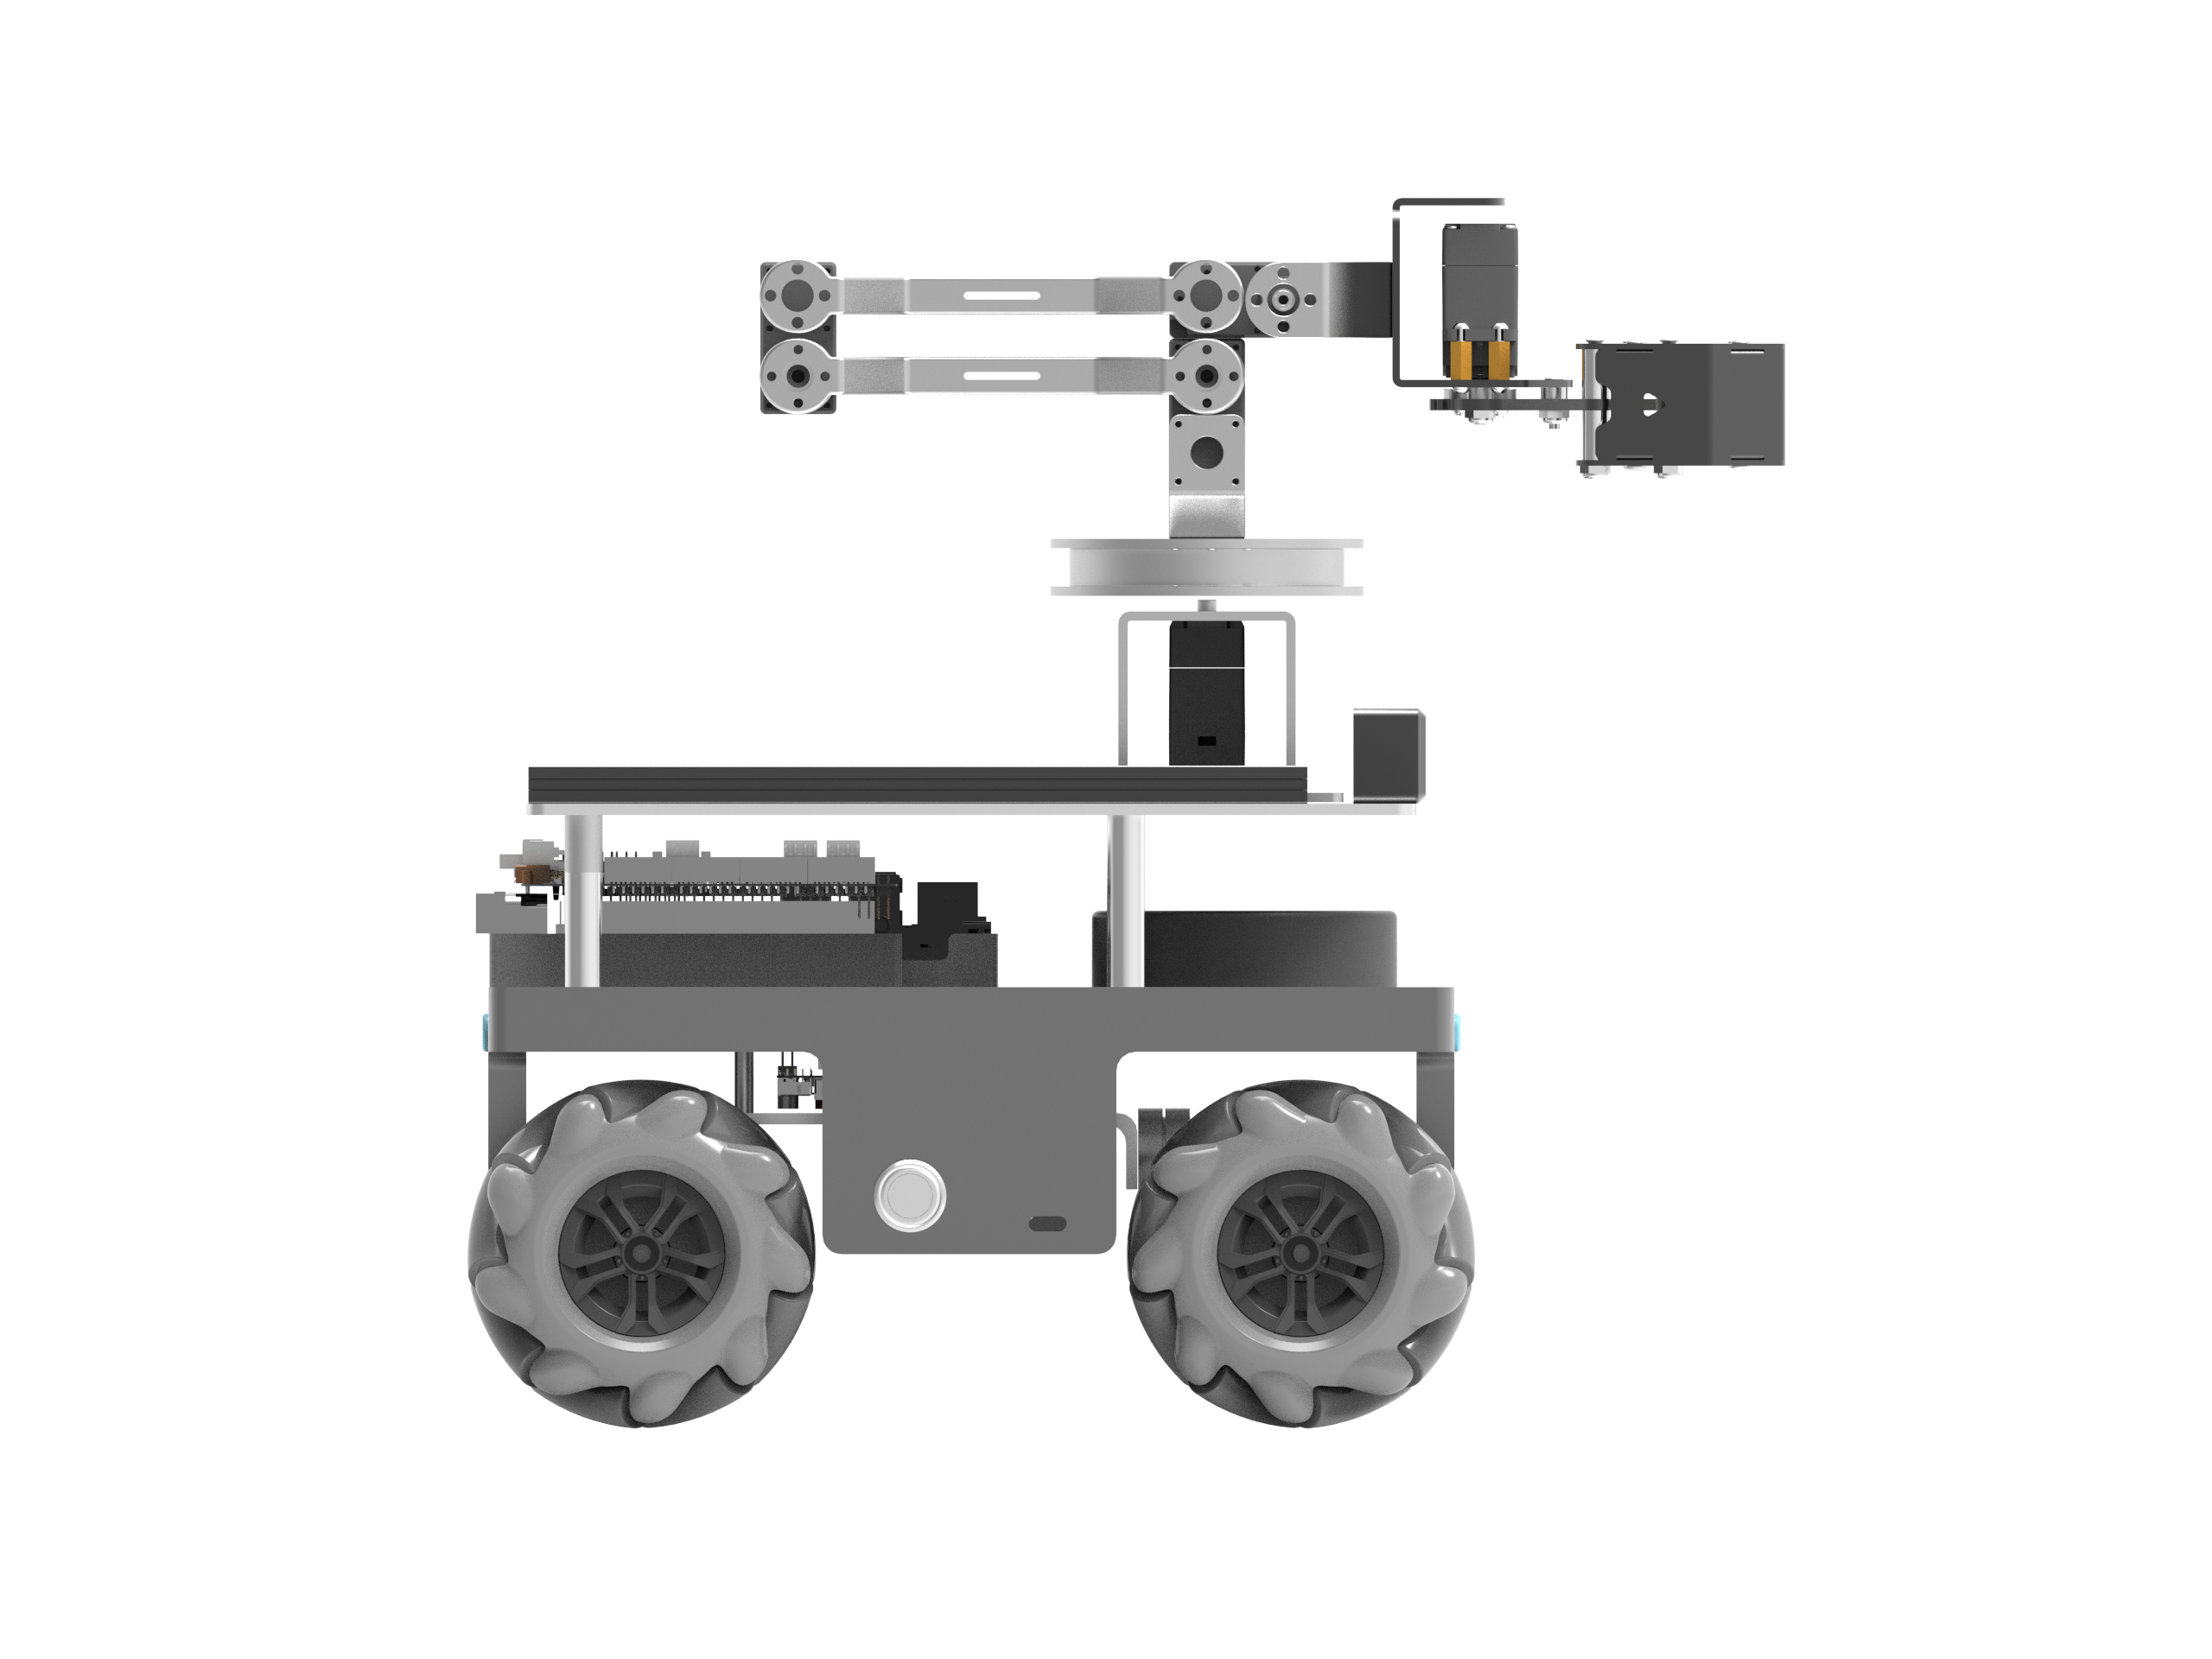
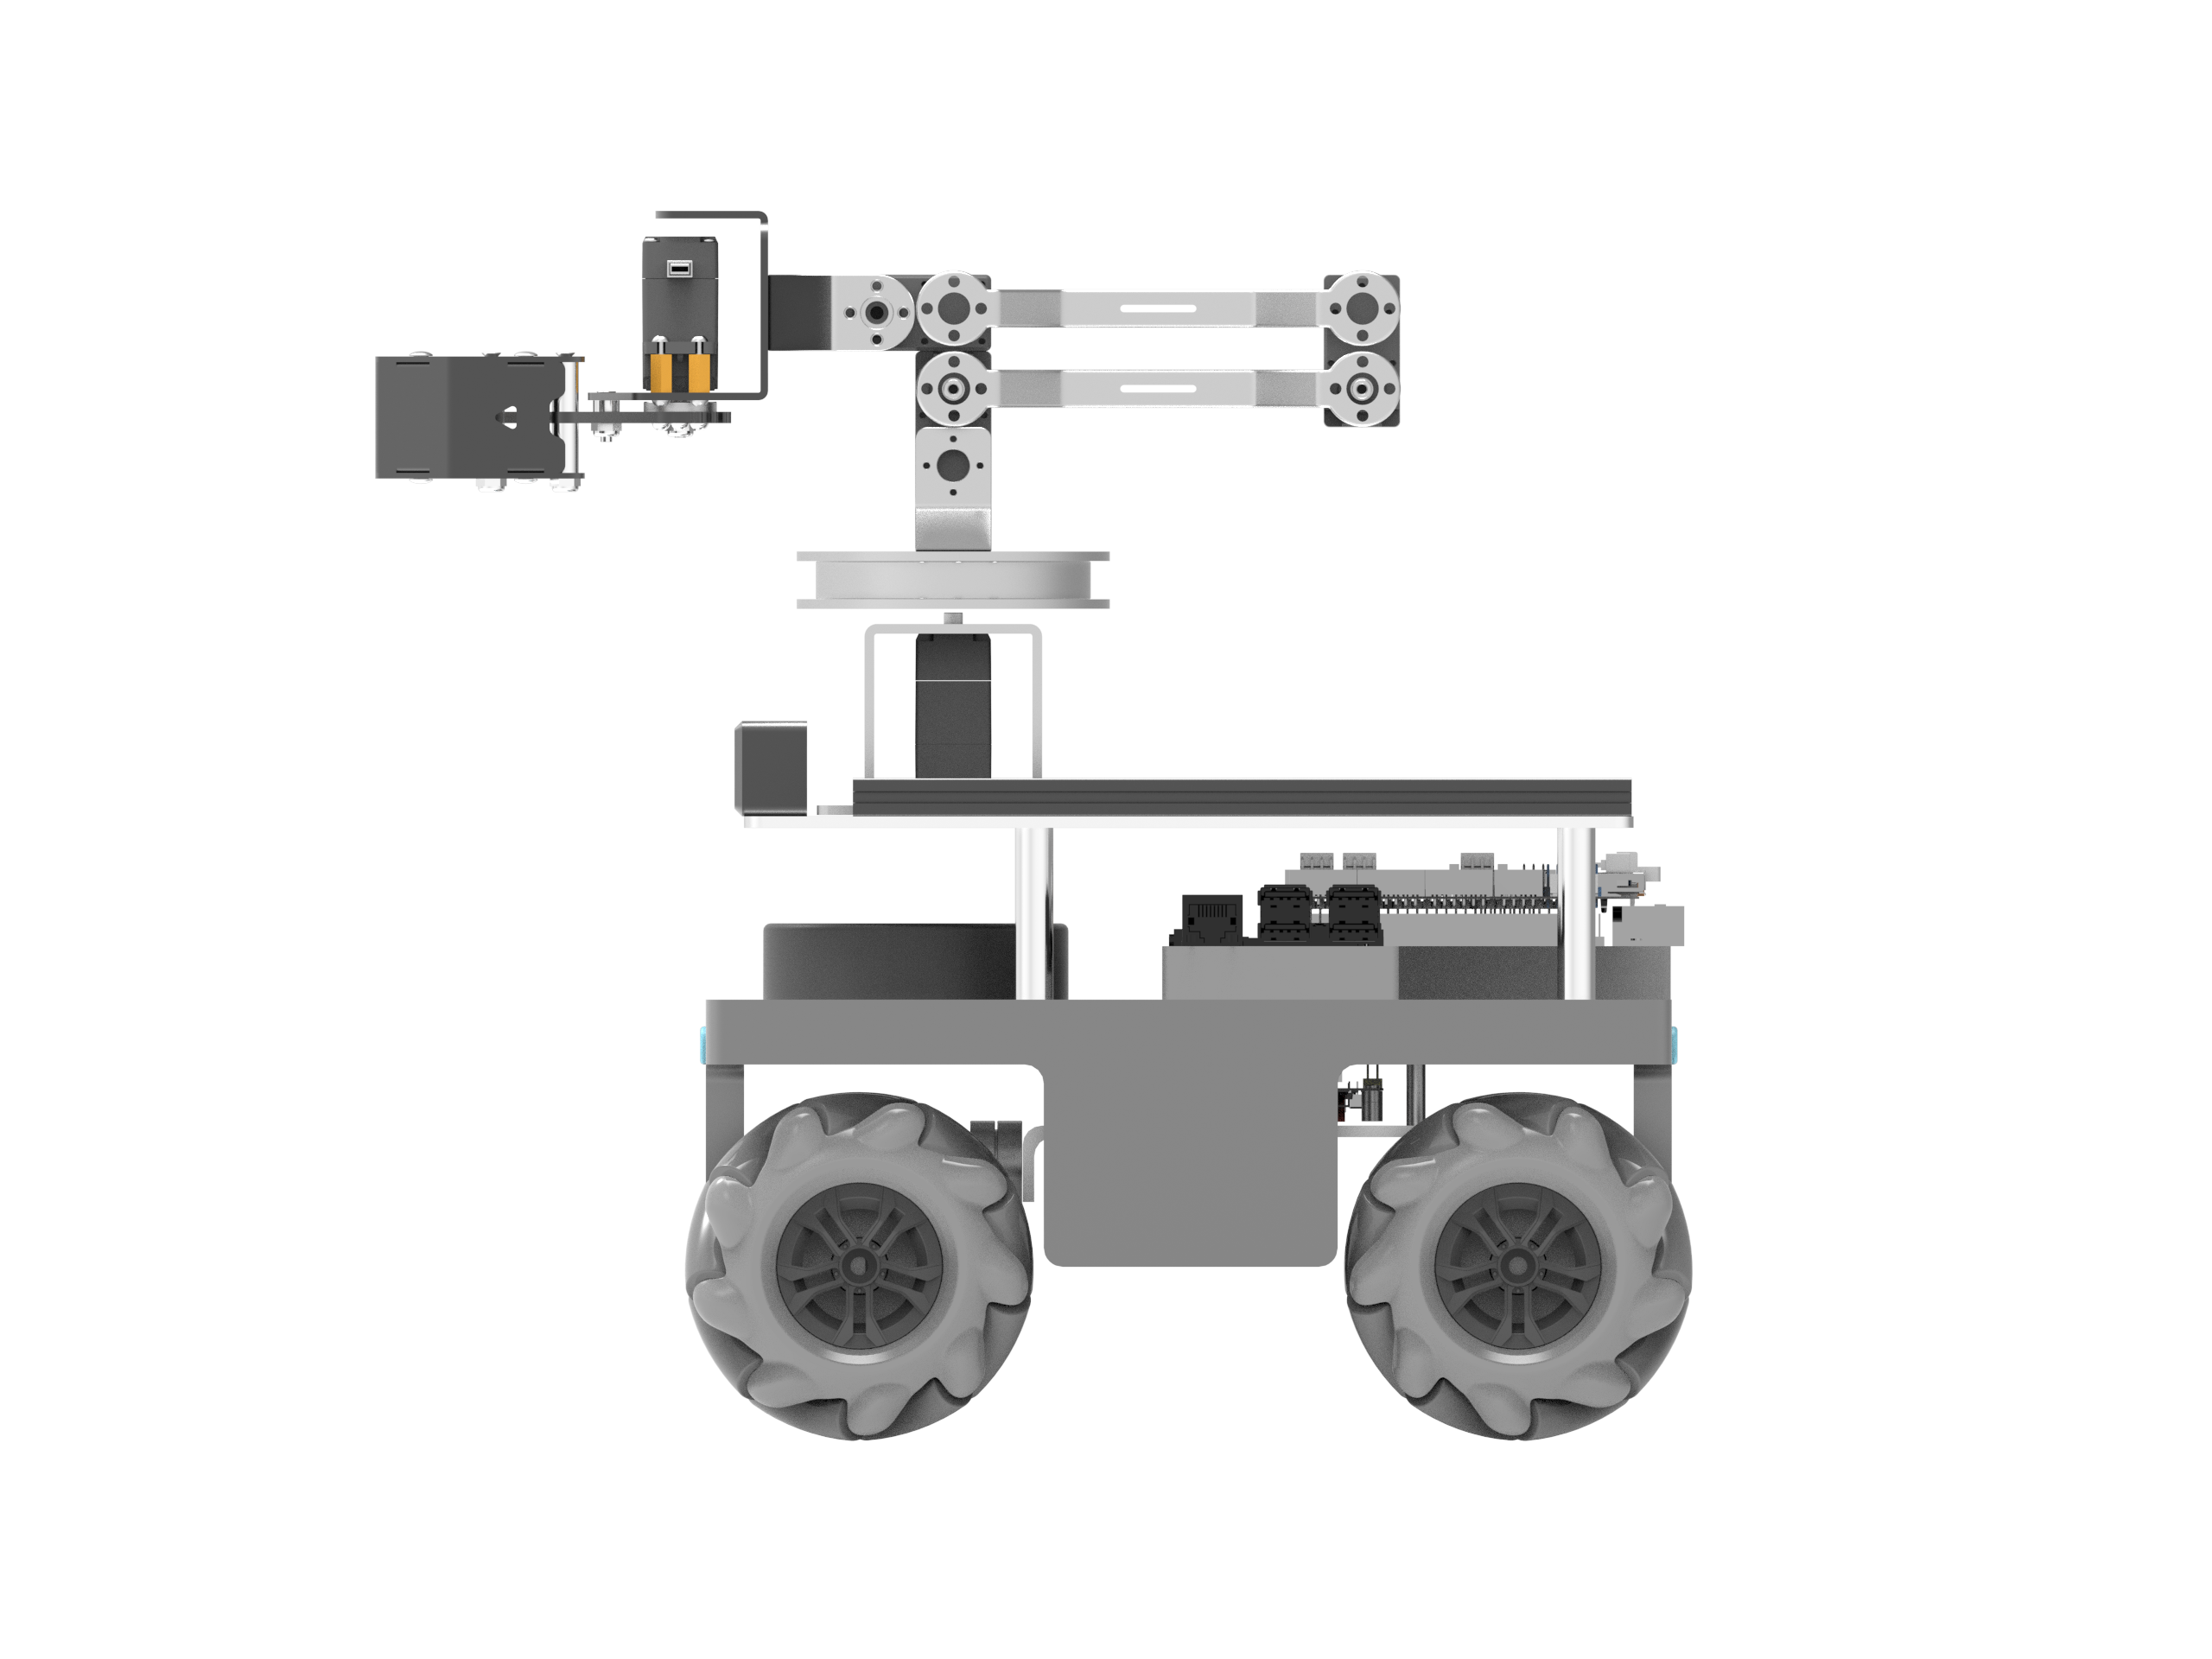
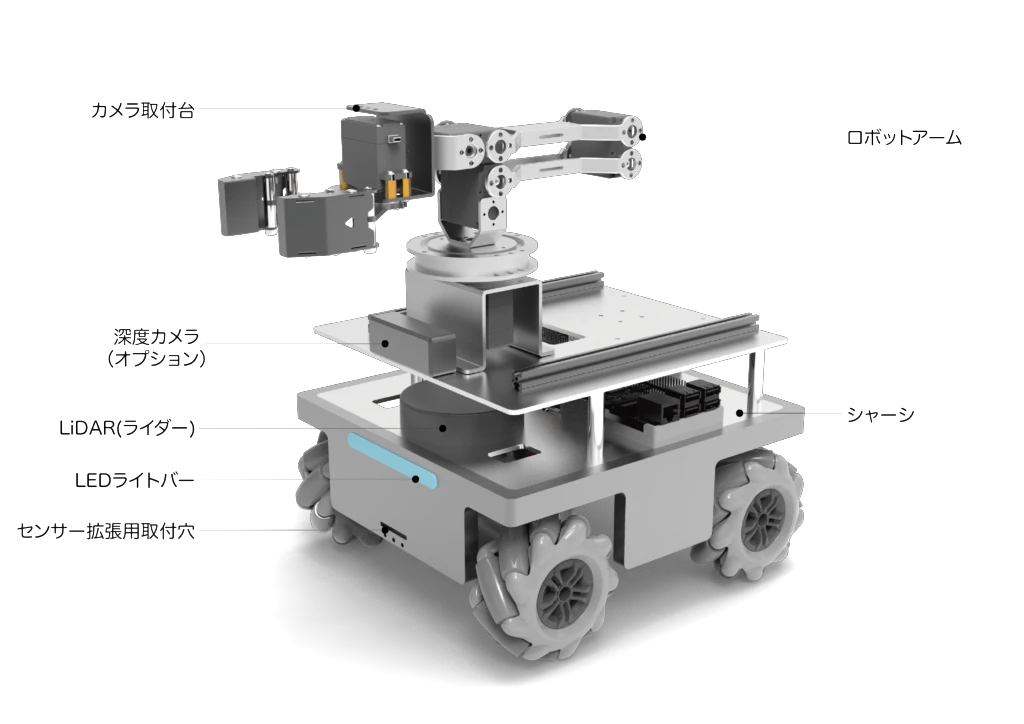
Equipped with omnidirectional mecanum-wheel mobility and a 4-DOF robotic arm, RAI-M4 delivers both agile movement and precise manipulation. A dual-controller architecture ensures smooth AI computing and responsive real-time control.
A practical robotics and AI platform built for hands-on learning across diverse educational scenarios.
■ Applications & Use Cases
Features
Key Features
AI-Powered Intelligence
Combines natural language understanding and multimodal perception for end-to-end task
planning and execution.
All-in-One Mobile Manipulation Platform
Integrates omnidirectional mobility with a robotic arm to enable flexible operation in
confined spaces.
Structured Hands-on Training Design
A modular, step-by-step learning structure designed for diverse educational
applications.
Specifications
Specifications
Basic Specifications
| OS Environment | Ubuntu 22.04 / ROS 2 |
|---|---|
| Algorithm Framework | OpenCV / YOLOv8 |
| Supported Language Models | Qwen / DeepSeek / ChatGPT / Gemini / Claude ※API Integration Support |
| Dimensions | ≥ 240mm × 240mm |
| Chassis Configuration | 4-Wheel Mecanum Omnidirectional Chassis |
| Rated Load | 10kg |
| Maximum Speed | 0.5m/s |
| Sensor | Built-in Gyro Sensor |
| Robot Arm | 4-DOF Serial Arm with 1-DOF Gripper |
| Arm Length | 240mm |
| Payload Capacity | 300g |
| Control System Architecture | Host PC: task planning, visual recognition, navigation control Low-level controller: PID control, servo control, interaction control (communication relay) |
Hardware Specifications
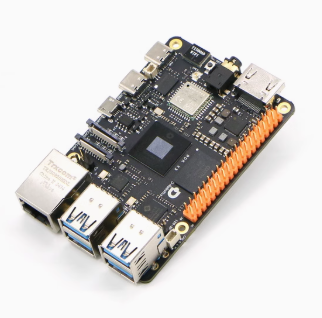
Edge Controller
| Model Number | RDK X5 |
|---|---|
| Computational Performance | 10 TOPS |
| CPU | 8-core Arm Cortex-A55 processor (1.5 GHz) |
| BPU | 10 TOPS |
| GPU | 32 FLOPS |
| Memory | 8GB LPDDR4 |
| Storage | microSD Card Support |
| Notes | YOLOv8 face detection runs at ~100 FPS. |
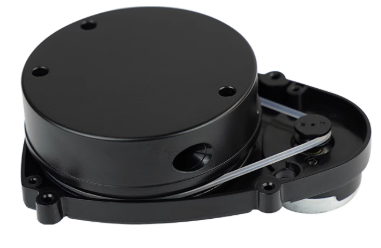
LiDAR Sensor
| Measurement Distance | 0.12~8 m |
|---|---|
| Sampling Rate | 4,000 Hz |
| Scan Rate | 5~10 Hz |
| Angular Resolution | 0.6°~1.2° |
| Weight | 135 g |
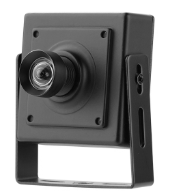
Vision Camera
| Type | High-Resolution RGB Camera |
|---|---|
| Resolution | 2MP |
| Interface | USB 3.0 |
| SNR | 27 dB |
| Operating Current | 80~280 mA |
Options
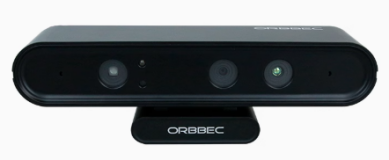
Depth Camera
| Depth Module Measuring Range | 0.6m~8m |
|---|---|
| Depth Module Resolution | Up to 1280×720 (90 fps) 2 megapixels |
| Depth Module Field of View (FOV) | Horizontal 54.8° / Vertical 45.5° |
| RGB Camera Module Resolution | Max 1920×1080 @ 30fps |
| RGB Camera Module Field of View (FOV) | Horizontal 66.1° / Vertical 40.2° |
Curriculum
Experiment Items
Robotic Vision
An integrated practical learning workflow covering everything from basic image processing to deep learning and multimodal perception.
■ OpenCV Vision
・Color Recognition / Shape Recognition / QR Code Recognition / Barcode Recognition
・Color Marker Detection (Integrated Processing + Filtering)
■ AI Vision - YOLO
・YOLO Model Integration and Deployment
・Dataset Annotation, Model Training, and Deployment
・Object Detection
・Face Detection
■ AI Vision - Qwen multimodal large model
・Integration and deployment of the Qwen multimodal API
・Object Detection and Labeling
Large-Scale Model Integration and Application
Focused on end-to-end AI model practice integrating voice interaction, multimodal perception, and robotic execution.
■ Voice Interaction
・Speech recognition (ASR) integration and implementation - Qwen
・Semantic understanding (LLM) deployment - DeepSeek
・Speech synthesis (TTS) integration and implementation - Volcano Engine
・LLM-Based Voice Interaction Implementation
・Implementation of Voice-Controlled Calculator Functionality
・Implementation of Voice-Controlled Music Playback
■ Multimodal Visual Perception
・Integration and deployment of the Qwen multimodal API
・Object Detection and Labeling
■ Integration with Robotic Applications
・MCP-Based Perception and Grasping Task Planning
・MCP-Based Navigation Task Planning
Robot Body
Robot Chassis and Arm Kinematics & Control Strategy Practice
■ Mobile Base Control
・Encoder-Based Motor PID Control
・Omnidirectional Base Kinematics Control
・Gyro-Assisted Odometry Control for Omnidirectional Mobile Base
■ Robot Arm Control
・Servo Motor Position Control
・Robot Arm Kinematics Control
・Robot Arm Trajectory Interpolation Control
ROS
Master core ROS skills including topic, service, and parameter management, as well as motion planning with MoveIt!.
■ Basic ROS Operations
・Turtlesim Control Using Topics, Services, and Parameters
・Package porting and execution - keyboard control of turtlesim
■ Robot Arm Motion Planning with MoveIt!
・Robot Arm URDF Configuration
・Robot Arm Kinematic Model Configuration with MoveIt!
・Robot Arm Motion Planning with RViz
Mobile Robot Navigation and Localization
Comprehensively covers system interfaces, mapping, and navigation workflows, enabling practical multi-point navigation implementation.
■ Mapping
・Map Project Settings
・New Map Construction
■ Navigation
・Point Navigation
・Autonomous Obstacle Avoidance Navigation
・Multi-Point Navigation
FAQ
RAI-M4 FAQ
What is RAI-M4?
A Physical AI learning platform integrating planning, perception and execution. It supports natural-language-to-task conversion and multimodal perception, with omnidirectional mecanum-wheel mobility and a 4-DoF robot arm for learning perception, decision-making and manipulation together.
Which large language models (LLMs) does it support?
It connects to APIs such as Qwen, DeepSeek, ChatGPT, Gemini and Claude, enabling voice dialogue that combines speech recognition, language understanding and speech synthesis, as well as task planning exercises with function calling.
What is the software environment and compute performance?
It runs Ubuntu 22.04 / ROS 2 with OpenCV and YOLOv8 support. The RDK X5 edge controller (10 TOPS, 8 GB memory) runs YOLOv8 face detection at about 100 fps.
Which courses and fields can it be used for?
Mobile robotics, motion control, AI model applications, machine vision, ROS navigation and localization. For pricing and demos, contact HumansX (https://humansx.co.jp/contact/).
Contact
Consultation on Deployment, Demos and Quotes
From product selection to integrating robots into your classes or research, feel free to contact us.