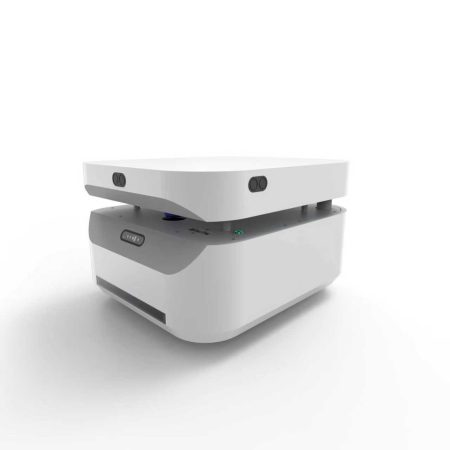
UX052

物流配送向け自律搬送AMRプラットフォーム


From Language to Action
Perceive. Decide. Act.

UX052は、2D LiDAR、深度カメラ、超音波センサー、IMUなどのマルチセンサー融合技術を搭載した、自律走行ロボットベース(AMR)。物流搬送・構内搬送・施設内運用など、多様なシーンに対応。

周囲環境を高精度に認識し、最適経路を自律的に計画。複雑な環境下でも、安全かつスムーズな自律走行を実現。

板金カバーと高剛性フレーム構造により、高い積載性能と耐久性を確保。モジュール設計を採用し、保守・拡張・二次開発にも柔軟に対応。


■ Applications & Use Cases

Mobile Robot Control

AI Model Applications

Robotics

Machine Vision

ROS

Navigation Control

Localization

Key Features


AI-Powered Intelligence

Combines natural language understanding and multimodal perception for end-to-end task

planning and execution.

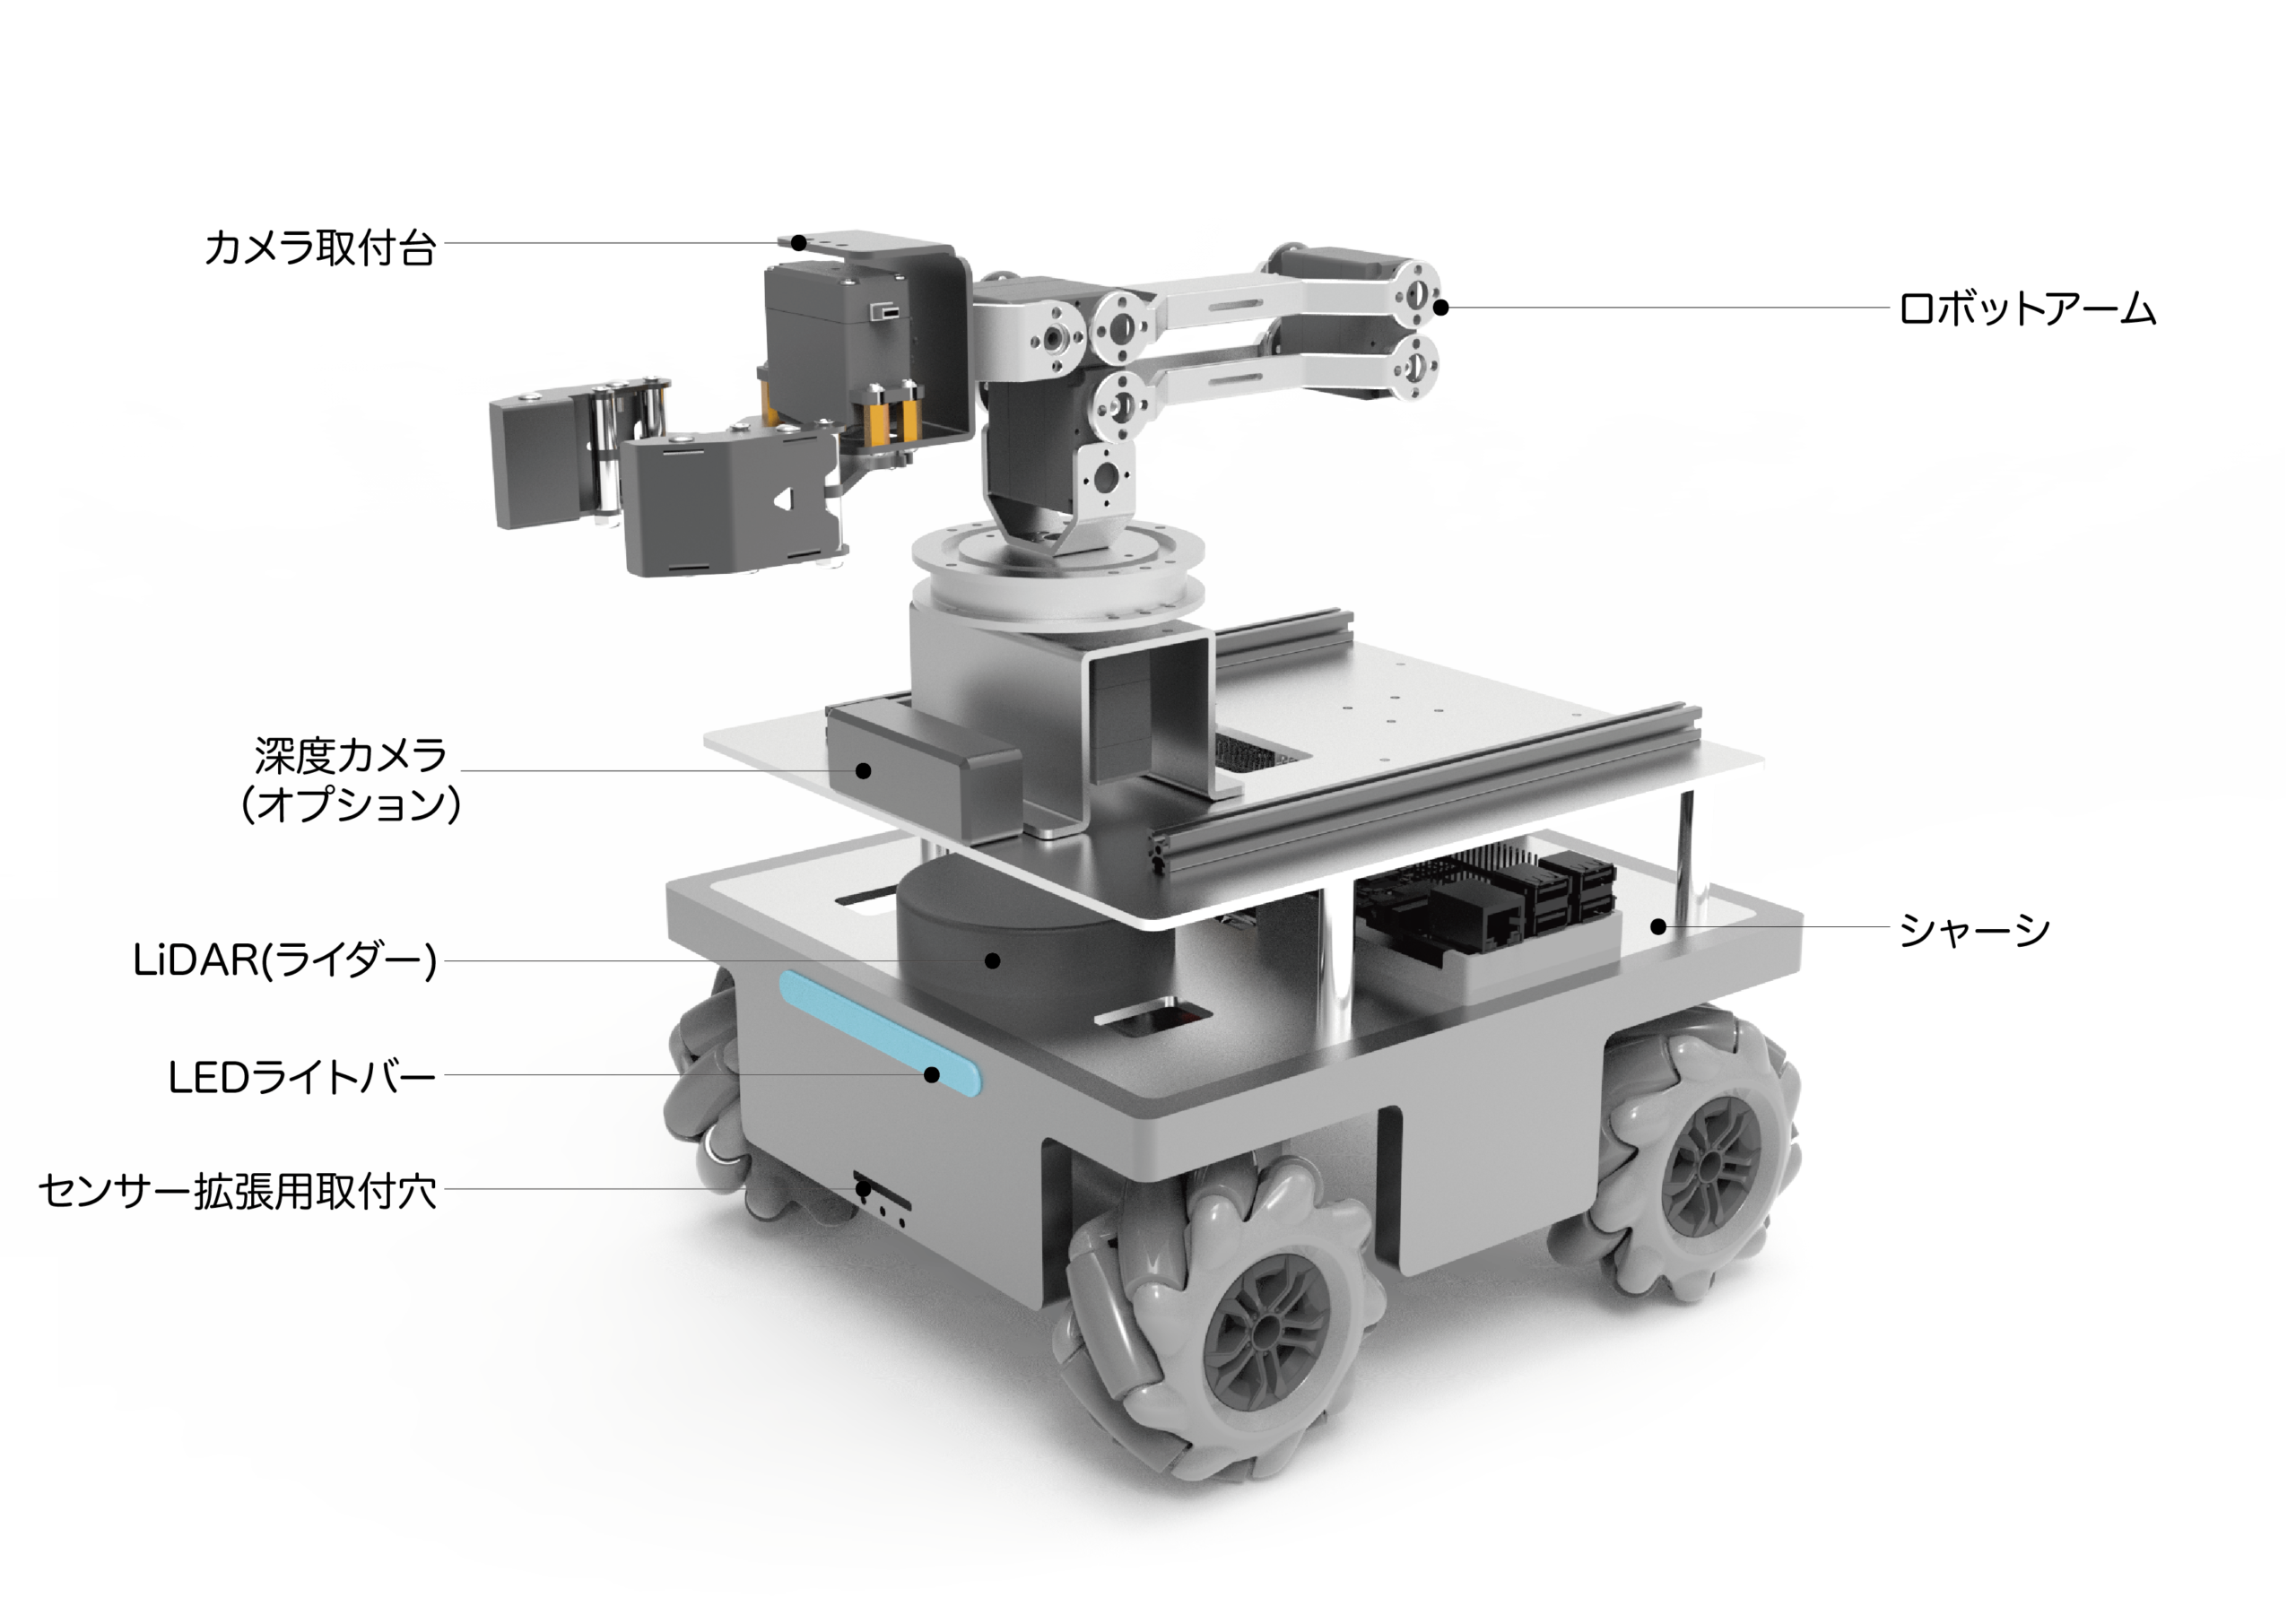
All-in-One Mobile Manipulation Platform

Integrates omnidirectional mobility with a robotic arm to enable flexible operation in
confined spaces.

Structured Hands-on Training Design

A modular, step-by-step learning structure designed for diverse educational

applications.

Specifications


■ 本体仕様

  Dimensions

  W555 x D480 x H348 mm

  本体重量

  60 kg

  定格積載

  90 kg

  走行構成

  6.5インチ駆動輪 x2、 3インチキャスター x4

  走行速度

  0 ~ 1.2 m/s

  走行モード

  双方向走行

  登坂能力

  10° 以下

  旋回性能

  360° 旋回対応

  最大旋回速度

  60 °/s

  最大段差乗越

  20 mm

  最小通過幅

  65 cm

  Navigation System


  レーザーSLAM、 ビジョン補助ナビゲーション、慣性ナビゲーション、

  超音波ナビゲーション

  センサー構成

   超音波センサー x3、 LiDAR x2、ビジョンカメラ x1、 オドメータ x1

  位置決め精度

  ±5 cm

  通信方式

  4G / Wi-Fi、 5Gアップグレード対応、Ethernetポート x1

  バッテリー

  リン酸鉄リチウム 24V 30Ah

  充電方式

  自動充電 / 手動充電

  充電時間

  4時間以下

  連続稼働時間

  7時間以下 (定格負荷)

■ 充電ステーション仕様

  Dimensions

  W290 x D155 x H275 mm

  入力電源

  AC 100 ~ 250V、 50/60 Hz

  充電電圧

  28.8V ± 0.2V

  充電電流

  10A以下

  ステーション出力

  300W、 最大充電電流 10A

  1日あたり消費電力量

  2 KWh 未満

Experiment Items


Robotic Vision

An integrated practical learning workflow covering everything from basic image processing to deep learning and multimodal perception.

■ OpenCV Vision

    ・Color Recognition / Shape Recognition / QR Code Recognition / Barcode Recognition

    ・Color Marker Detection (Integrated Processing + Filtering)

■ AI Vision – YOLO

    ・YOLO Model Integration and Deployment

    ・Dataset Annotation, Model Training, and Deployment

    ・Object Detection

    ・Face Detection

■ AI Vision – Qwen Multimodal Large Language Model

    ・Qwen Multimodal API Integration & Deployment

    ・Object Detection and Labeling


Large-Scale Model Integration and Application

Focused on end-to-end AI model practice integrating voice interaction, multimodal perception, and robotic execution.

 ■ Voice Interaction

 ・Qwen ASR Integration and Implementation

 ・DeepSeek LLM-Based Semantic Understanding

 ・Volcano Engine TTS Integration and Implementation

 ・LLM-Based Voice Interaction Implementation

 ・Implementation of Voice-Controlled Calculator Functionality

 ・Implementation of Voice-Controlled Music Playback

■ Multimodal Visual Perception

 ・Qwen Multimodal API Integration and Deployment

 ・Object Detection and Labeling

■ Integration with Robotic Applications

 ・MCP-Based Perception and Grasping Task Planning

 ・MCP-Based Navigation Task Planning
 

Robot Body

 Robot Chassis and Arm Kinematics & Control Strategy Practice


■ Mobile Base Control

・Encoder-Based Motor PID Control

・Omnidirectional Base Kinematics Control

・Gyro-Assisted Odometry Control for Omnidirectional Mobile Base

■ Robot Arm Control

・Servo Motor Position Control

・Robot Arm Kinematics Control

・Robot Arm Trajectory Interpolation Control


ROS

Master core ROS skills including topic, service, and parameter management, as well as motion planning with MoveIt!.

■ Basic ROS Operations

・Turtlesim Control Using Topics, Services, and Parameters

・Package Porting and Execution – Keyboard Control of Turtlesim

■ Robot Arm Motion Planning with MoveIt!

 ・Robot Arm URDF Configuration

 ・Robot Arm Kinematic Model Configuration with MoveIt!

 ・Robot Arm Motion Planning with RViz


Mobile Robot Navigation and Localization

Comprehensively covers system interfaces, mapping, and navigation workflows, enabling practical multi-point navigation implementation.

■ Mapping

    ・Map Project Settings

    ・New Map Construction 

■ Navigation

   ・Point Navigation

   ・Autonomous Obstacle Avoidance Navigation

   ・Multi-Point Navigation


Scroll to Top